
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 54 5 Solution Created 2026-10-03 Updated 2026-10-14
Use fixed spatial coordinates in a stationary heterogeneous Earth and define the operatorHere the elastic stiffness tensor has its minor and major symmetries, and the physical body force per unit volume is . The retarded elastodynamic Green tensor is the displacement in direction due to a unit physical force impulse in direction at :It satisfies the actual Earth's homogeneous boundary conditions, including zero traction on the free surface and continuity of displacement and traction at bonded internal interfaces. Integration through gives , with . No spherical symmetry is required.
For zero initial conditions, form the convolutionApplying to this expression uses the defining Dirac delta function to give . Causality gives zero initial conditions, and each Green column supplies the required boundary conditions. The positive-energy uniqueness argument then identifies this expression with the physical response. The source factor is because is force per unit mass, whereas the Green tensor was normalized to unit force.
A force dipole is a limiting pair of opposite point forces separated by a small vector. Put at and at , and hold fixed as . Expansion of the two Dirac delta functions givesIts resultant force is zero, and integration by parts gives its radiated displacement as . Thus the source derivative of the elastodynamic Green tensor represents a dipole with force direction and separation direction .
For the surface source choose a normal from the minus side to the plus side and defineThe same normal is used in both tractions. If the elastic coefficients are continuous through the surface, the distributional gradient of a piecewise smooth displacement is . Its stress therefore has a singular part . Taking the divergence includes the regular stress jump, so a field satisfying the source-free equations on both sides has equivalent sourceIn particular, the signs follow from the chosen jump convention, not from an unspecified orientation. The elastodynamic surface-jump representation is consequentlywith the Green tensor evaluated at . The first term is a surface distribution of forces, and the second is a surface distribution of dipoles.
One can derive the same formula without multiplying discontinuous material coefficients by a surface delta. Apply integration by parts on the two sides of to the field and the reciprocal Green field . Major symmetry cancels the volume strain terms; the spatial identity iswhen the temporal terms are handled by the retarded time convolution. More explicitly, take , extend the zero-initial-data solution causally to , and integrate over all source times. Integration by parts cancels the two temporal terms, with zero endpoint terms; the causal supports subsequently reduce the representation to . The Green impulse contributes on the left. The two outward face normals are and , so their sum on the right is . Moving it to the other side gives . The same identity applied to two force Green fields with interchanged source and receiver proves the reciprocal relation ; hence the displayed surface formula follows. On a bonded material interface the Green displacement and common Green traction are continuous: is then the unambiguous version of the dipole term, evaluated with the matching one-sided coefficients. External free-surface terms vanish because both tractions vanish.
For a fault in isotropic material, the Lamé parameters giveTangential slip obeys , and ordinary fault traction is continuous across the two faces. Therefore the source is a double-couple fault source withFor a uniform patch of area with and , its integrated seismic moment tensor isThe dipole is a force in the slip direction separated in the normal direction; the dipole is a normal force separated in the slip direction. Their equal and opposite torques cancel. The symmetric trace-free seismic moment tensor has eigenvalues , with zero resultant force and torque. A temporal stress drop on a fault is not a jump of traction between its two simultaneously matching faces; it does not add a single-force layer to this tangential-slip representation.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 54 4 Solution Created 2026-10-03 Updated 2026-10-14
Let be the solid exterior to the cavity, and choose outward from the solid, hence into the cavity on its boundary . Subtraction of the incident solution from the total solution gives the scattered displacement field equationsThe traction-free cavity condition for the total field gives on . The scattered field has zero initial displacement and initial velocity before the pulse reaches the cavity and satisfies an outgoing radiation condition, excluding an additional incoming elastic wave. Equivalently one seeks the causal response to this prescribed boundary traction. Although the incident plane pulse extends across an infinite plane, the causal scattered field from the bounded cavity has finite propagation distance at each finite time.
To prove energy uniqueness for traction-driven elasticity, take the difference of two solutions with the same initial conditions, body force, boundary traction and outgoing condition. It satisfiesFor a large enclosing ball , multiply by and integrate over . Integration by parts givesSymmetry of stress replaces the last derivative by , and major symmetry of the elastic stiffness tensor makes that integral the derivative of the strain energy. ThereforeThe cavity contribution is zero. On any fixed finite time interval choose beyond the causal support of the scattered difference; the outer contribution is then zero as well. This gives conservation of its nonnegative elastic energy. Positive mass density and positive strain energy imply that zero initial energy forces everywhere; the zero initial displacement field then gives . The same argument works for finite-energy outgoing solutions by taking the limit of enclosing surfaces and excluding incoming energy. Hence the causal scattered field is unique. Specifying the incident field and cavity traction alone without the initial and outgoing conditions would not establish uniqueness.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 54 3 Solution Created 2026-10-03 Updated 2026-10-14
For a homogeneous lossless elastic solid, insert the plane wave into the equations of linear elasticity. Put , , and . The resulting eigenvalue problem isThe minor and major symmetries make this acoustic tensor a real symmetric matrix. For a stable material it is positive-definite, so its three positive eigenvalues give three real positive phase velocities and therefore three slownesses . Coincident eigenvalues are possible, so there need not be three distinct speeds. For distinct eigenvalues the displacement polarization are orthogonal; in an anisotropic solid they are generally quasi-longitudinal and quasi-transverse rather than exactly longitudinal and transverse. Stability, or at least strong ellipticity in elasticity, is required for the assertion about positive real speeds.
The elastic slowness surface is the locus of the three vectors . Its equation isFor each wavefront normal there are three radial sheets, which may meet at degeneracies. To obtain the energy flux directly, multiply the elastic equation by . Forthe symmetry of stress gives . Thus the instantaneous elastic-wave energy flux is . With a real branch polarization , harmonic averaging givesNow differentiate along a regular slowness surface sheet and contract with . The terms containing cancel by symmetry and the original eigenvalue equation, leavingEvery tangent is consequently perpendicular to : the energy flux is normal to the slowness surface. At a degenerate point this statement is made on the limiting branches, rather than assuming a unique normal.
For completeness, equality of the mean kinetic and strain energies gives . Differentiating the acoustic tensor equation in the wavevector variables similarly givesThus the group velocity is the elastic energy velocity. The homogeneous elastic dispersion relation is degree one in , so differentiating at gives .
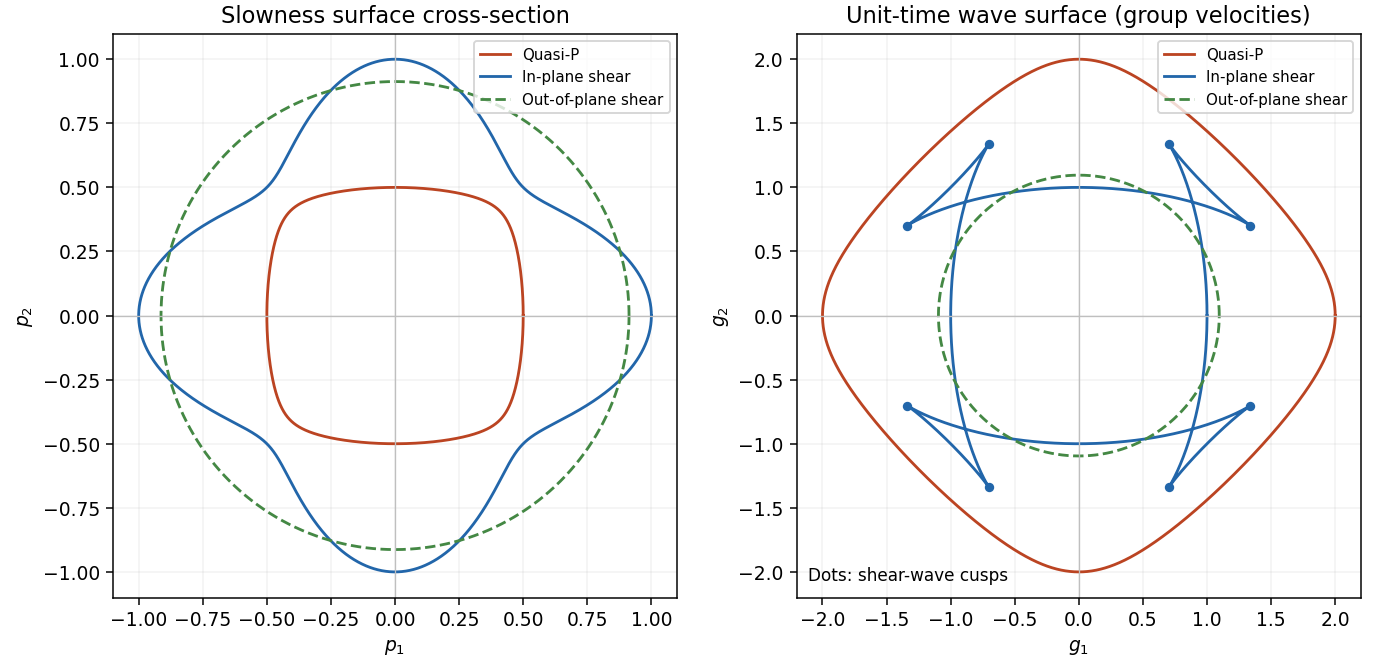
The elastic wave surface is the unit-time locus of these group velocities. From an impulsive point source, the propagating wavefronts at time are its sheets scaled to . A particular source may fail to excite a mode in some directions, and its amplitudes require the source polarization and geometrical spreading; the wave surface determines the arrival geometry. It does not specify all near-field motion between the radiative fronts. Geometrically it is the envelope of the planes : tangent variation gives , so is the appropriately normalized normal to the slowness surface.
In a symmetry-plane cross-section write , and . The two envelope conditions giveThe numerator is the signed curvature numerator of the slowness surface cross-section. At a simple inflection point, and . Then and are linearly independent. These are precisely the local conditions for an ordinary cusp. The slowness curvature and wave-surface cusps relation explains why a smooth nonconvex slowness surface can generate a cusped wavefront and multiple ray arrivals.
The example below uses a positive orthotropic stiffness in normalized units: , , , , and all normal off-diagonal stiffnesses zero. In the symmetry plane , its two in-plane acoustic tensor eigenvalues are , and its out-of-plane shear speed is . The in-plane shear sheet is nonconvex and produces the marked cusps; the construction uses an actual stable elastic tensor.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 54 2 Solution Created 2026-10-03 Updated 2026-10-14
An elastic deformation is reversible: after removal of the deforming loads the material returns to its reference state, and its instantaneous stress is determined by its current deformation rather than a plastic or viscous history. In the infinitesimal approximation the displacement field gives the infinitesimal strain tensor . The Cauchy stress tensor is defined by traction on a plane of unit normal ; absence of body couples makes .
Let be the recoverable elastic energy per unit mass. The local mechanical power per unit volume isbecause the symmetric Cauchy stress tensor annihilates the antisymmetric part of the velocity gradient. Conservation of energy during the deformation gives . Since for arbitrary symmetric strain rates,Here the derivative is the gradient on the space of symmetric tensors, with the double-contraction inner product. This convention accounts for the two occurrences of each off-diagonal entry; treating six independent coordinates without their corresponding factors would give an erroneous factor of two in shear components.
Take a stress-free reference state of mass density . The Taylor series of the elastic energy starts quadratically:Using gives , the relation of linear elasticity. If the reference state has initial stress, the first-order expansion also retains that constant stress. Symmetry of stress and strain gives the minor symmetries , while equality of the mixed second derivatives of elastic energy gives the major symmetry . Thus the elastic stiffness tensor is a symmetric map on a six-dimensional strain space: there are independent coefficients.
For twofold elastic symmetry, choose the symmetry axis as . Rotation through is , and transforms the infinitesimal strain tensor into . Components are even and are odd. Invariance of elastic energy excludes every coupling between these parity classes. In the engineering strain ordering , with corresponding stress ordering , the symmetric stiffness matrix has the formIts symmetric even block has ten independent entries and its symmetric odd block has three. Hence a twofold axis leaves independent coefficients. No invariance under other rotation angles has been assumed.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 54 1 Solution Created 2026-10-03 Updated 2026-10-14
Because is arc length, . Thus , where is the unit tangent to the elastic ray. In an isotropic medium this is also the wavefront normal. Consequently is the vector slowness, of magnitude ; locally , with the travel time and the wavevector.
For depth-dependent wave speed , the ray equation gives . The horizontal component of therefore has a fixed direction, and the elastic ray lies in the vertical plane determined by that direction and its initial point. A vertical elastic ray is the limiting case. If is the angle to the vertical, its conserved horizontal slowness givesAt a horizontal interface, matching the tangential wavevector at fixed frequency gives the same invariant on both sides: this is Snell's law.
For radial wave speed , take the cross product of position with slowness. The ray equations givesince the second vector is radial. A nonzero constant is perpendicular to every position on the elastic ray, so the ray lies in a fixed plane through the centre. Radial rays obey the same conclusion with a nonunique plane. The spherical elastic ray invariant is thereforewhere is measured from the radial direction. Across a spherical interface the radius is common and tangential slowness is continuous, so this form of Snell's law survives an interface discontinuity.
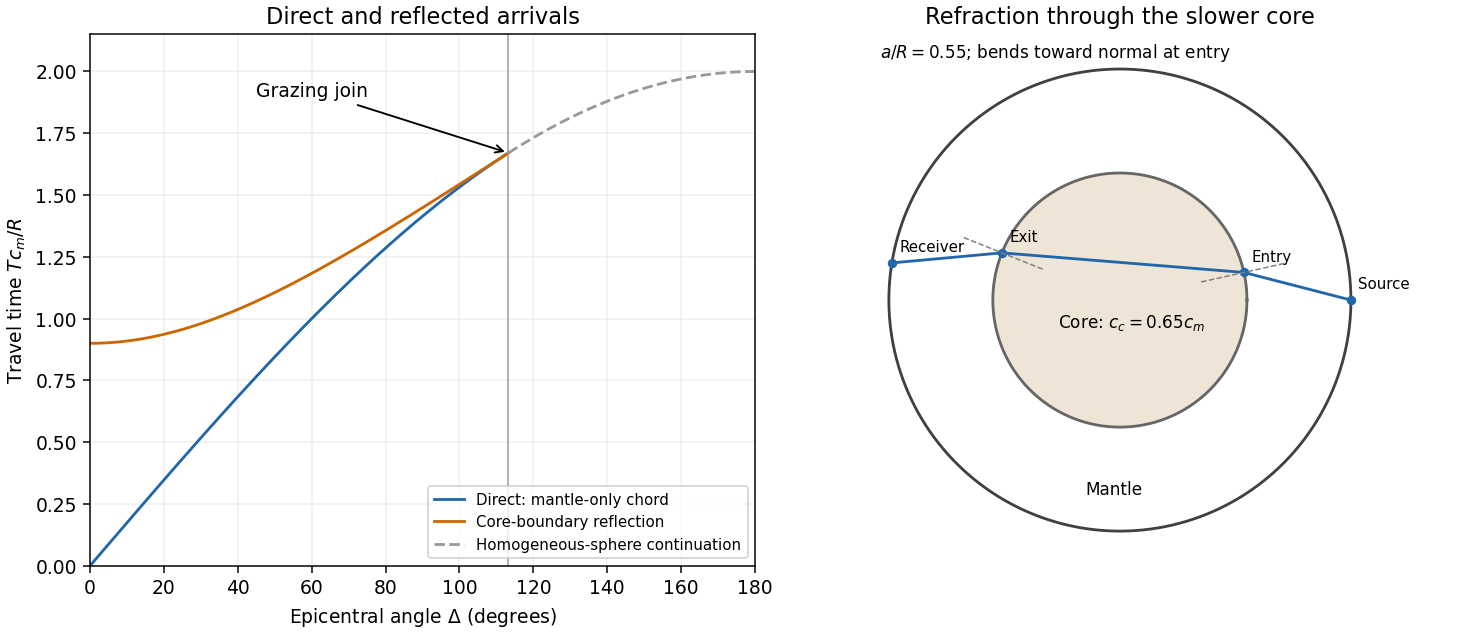
In a homogeneous sphere a P wave follows the straight chord between the two surface points. If their principal angular separation is , its length is . For constant P wave speed ,Now put and denote the mantle and core P wave speeds by . Equal incidence and reflection angles put the core-boundary reflection point on the angular bisector. Each mantle leg has length given by . Hence the core-reflected travel time isThe stated domain is essential. At the reflection point the incoming line approaches from the mantle only if . Otherwise it has already crossed the core boundary. The mantle-only direct chord also exists only for , with . In this interval,so the reflected arrival is later. Its intercept is , whereas the direct intercept is zero. At grazing incidence the branches meet at , and both have slope . A continuation of the homogeneous-sphere direct formula beyond this endpoint is not a mantle-only arrival in the modified model.
The core-transmitted elastic rays consist of three straight legs. Their impact distances in mantle and core are and , respectively. At core entry,Since , the elastic ray bends towards the normal on entry and away from it on exit. The mantle leg subtends at the centre, and the core chord subtends . Thus the total angular sweep along the transmitted path is . This sweep need not equal the principal separation if it exceeds ; the diagram uses a path with sweep below .


Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 53 2 Solution Created 2026-10-03 Updated 2026-10-14
A simple fluid reduces to a linear viscoelastic fluid when its deformation and rotation over the relevant memory interval are small enough to linearize the constitutive history about an isotropic relaxed state. Small amplitude is essential; small frequency is not. For example, arbitrarily high-frequency oscillation can still be linear if its strain amplitude is sufficiently small. The relaxation modulus is the shear-stress response to a unit small step of shear strain.
Choose the harmonic convention . If the imposed shear rate is , the corresponding shear stress is . Substitution into the constitutive convolution gives the complex viscosity:For a nondecaying elastic part this formula is understood through the limit from a positive Laplace damping parameter. The complex shear modulus is , so is the storage modulus, the loss modulus, and in this convention.
Creep is the progressive deformation produced by a held stress. For a small step of shear stress, define the creep compliance by from a relaxed state. Writing hats for Laplace transforms, the same constitutive law gives . Since , this yieldsHere is the Heaviside step function. Inversion determines the full creep response, including any instantaneous elastic strain jump. Equivalently, the causal relaxation/creep convolution includes that jump through for .
For the Maxwell fluid, . Thus the two material responses areThe creep response is an elastic jump followed by constant-rate viscous deformation. The zero-frequency shear viscosity is .
For the wall problem, take and denote the shear component of stress by . The incompressibility constraint is satisfied, and the advective part of the material derivative vanishes because no field depends on . With no imposed longitudinal pressure gradient, momentum conservation and the linear Maxwell law giveThe initial conditions are in ; the no-slip boundary condition is , with decay as . Transforming these equations givesChoose the analytic square-root branch in with , so that the spatially increasing solution is excluded. The Maxwell start-up shear layer consequently hasThe Bromwich inversion formula now givesThe vertical Bromwich contour is directed upward and lies to the right of all singularities, including the origin and the branch points at and . A cut joining these branch points is a possible continuation into the left half-plane; inversion only requires the stated right-half-plane branch.
The Newtonian limit holds fixed while , so . Then . With , the inverse Laplace transform gives the complementary error function profileThis is diffusive momentum penetration in a Newtonian fluid, with thickness of order .
The elastic limit instead holds fixed while . Write . On the chosen branch, , so the Laplace transform time-shift rule yieldsAn elastic shear front travels at speed : the material ahead is at rest, while that behind moves at the wall speed. Indeed the limiting displacement is , whose shear strain is . A nonzero pointwise velocity gradient at the front is interpreted distributionally, or by smoothing the ideal wall start.
The use of linear viscoelasticity is conditional, rather than automatically justified for arbitrary . The material derivative simplifying to a time derivative does not remove the nonlinear constitutive effects of finite shear strain. In this Maxwell problem the rapid elastic response supplies the natural strain scale , which must be small for linearization through start-up. Away from the front, the strain accumulated over an effective memory interval must likewise be small. In the late diffusive regime its characteristic size is , which decreases with time. Large absolute wall displacement alone is not a disqualification for a fluid with finite memory; it is relative deformation during that memory that matters. In the elastic limit, where memory does not decay, the explicit strain behind the front confirms the condition . Without such a small-strain restriction, the computed field is a formal linear response and need not describe an arbitrary simple fluid.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 53 1 Solution Created 2026-10-03 Updated 2026-10-14
An isotropic simple fluid has local stress determined by the deformation history of the material element. A viscometric flow is one whose relative deformation history is that of steady simple shear flow, up to rigid changes of frame. At a given element the shear rate is constant along its history, although it can differ between elements. This includes the locally simple-shear kinematics used in standard viscometric measurements.
Use the component-first velocity gradient . The first two Rivlin-Ericksen tensors areIn the axes of a steady shear , the relative deformation gradient over a lag is , since . The material history is determined by , and its tensor symmetries exclude and stress components. The remaining symmetric stress consists of an isotropic part, one shear component, and two independent normal-stress differences. The relevant matrices areThus span the allowed stress components. Material isotropy and reversal of the shear show that their scalar coefficients depend on . Define the viscometric functions bySolving for the matrix coefficients givesThis is an exact steady-viscometric representation, rather than an assumption that the fluid is everywhere a second-order fluid. The shear viscosity measures the shear resistance, while and measure the first and second normal-stress differences generated by shear. Their zero-rate values are understood as limits when these exist. An isotropic pressure changes neither normal difference.
For a flow in the lubrication approximation with gap , longitudinal scale and speed , the shear-rate scale is . The viscous shear force per unit volume scales as . Quadratic viscoelastic normal stresses scale as ; their longitudinal gradients, and the comparable mixed-component corrections, contribute forces of scale . Therefore the normal-stress smallness in lubrication criterion isEquivalently, the thin-gap aspect ratio must multiply the shear-based elastic parameter to give a small quantity: . Normal stresses need not themselves be smaller than the shear stress; it is their effect on the leading force balance that matters. If the flow changes on an additional short time scale , the term also requires for its neglect. Material coefficients should be evaluated at the characteristic shear rate.
Now take positive cylinder rotation, measure counterclockwise from the rightward horizontal, and let increase outward through the film. The tangent has upward component , so the tangential gravitational acceleration is . To leading order in , neglect inertia and higher-order hydrostatic or capillary pressure gradients, and write . Tangential force balance and the shear-free free surface givehenceThe wall shear stress is . It opposes rotation on the uphill side and assists it on the downhill side.
For a power-law fluid, . Its inversion must retain the sign:Integrating with the no-slip boundary condition yieldsThe volume flux per unit axial length is . The integrated bracket is , so the power-law coating on a rotating cylinder hasAt the gravitational term vanishes by continuity. Steady mass conservation makes independent of .
On the uphill half, put and . The local flux is , withIt has a unique maximum atA positive coating must carry the same steady flux at every angle. The tightest local bound occurs at , not on the downhill side, where the flux increases monotonically with thickness. ConsequentlyFor the thinner positive root on the uphill side connects through to the unique downhill root, giving a periodic leading-order coating profile. At the limiting flux the two uphill roots meet at ; it is the maximum flux of this lubrication model, with a possible limiting corner resolved by neglected higher-order effects. For the check is . All these conclusions require the resulting film to remain thin enough for the lubrication approximation and for the neglected normal stresses and inertia to satisfy their scaling restrictions.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 51 3 Solution Created 2026-10-03 Updated 2026-10-14
A large molecular Schmidt number separates the velocity's smallest smooth length scale from the scalar's smaller diffusive length scale. Follow a Lagrangian trajectory and measure displacement from it. Within a sufficiently small scalar packet, Taylor expansion of the smooth velocity field givesThe moving frame removes uniform sweeping, leaving a linear random velocity gradient tensor. Thus the local scalar equation is the advection-diffusion equation with velocity , and averaging over realizations of gives the corresponding ensemble average. The approximation requires the packet to lie within the velocity's locally smooth region. Its thin, diffusive direction can satisfy this condition even when its long direction eventually becomes too large for one global linearization; applications to a spatially varying flow then use local packet descriptions. The statistical conclusions below refer to the linear-flow model and the usual mixing assumptions, not to every conceivable trace-free random matrix process.
Write and assume sufficiently rapid decay to discard boundary terms. Integration by parts givesFor , integrate the advective term once and the diffusive term twice. Since and , one obtainsThese are mass conservation and the evolution of the unnormalized second moment tensor. The first moment obeys , so a centered packet stays centered.
For a positive Gaussian scalar packet in a linear incompressible flow, must be a positive-definite matrix. Diagonalizing its symmetric matrix and applying the Gaussian integral givesThe factor in the last identity matters because has not been divided by the scalar mass. Substitution into the advection-diffusion equation also givesThese identities agree with the second moment equation and prove that the Gaussian family is preserved. For an initially negative packet the same analysis applies after replacing by and taking its positive mass.
To see the roles of stretching and diffusion explicitly, let the deformation gradient solve , . Incompressibility gives . Differentiating integrates the moment equation:Without diffusion, and is constant. In a statistically stationary, mixing flow with positive Lyapunov exponent , the two stretching exponents are and . Writing the ordered eigenvalues of as , their typical initially nondiffusive evolution isThe fluctuation scale presumes the usual central limit theorem for accumulated strain; it is not implied by incompressibility alone. During this stage the packet becomes long and thin but keeps its area and peak concentration.
In the instantaneous principal-axis basis, write for the rotated velocity gradient tensor. Differentiation of an eigenvalue givesThe formulas hold through a repeated eigenvalue by continuity of their sum. The compressed physical variance is . Its contraction is arrested when it is of order , the square of the Batchelor scalar microscale . If its initial length is , the crossover occurs atThereafter has stationary fluctuations associated with the strain and the diffusive floor, while continues to grow typically at rate . Under sufficiently fast mixing, the central part of the distribution of is approximately Gaussian with mean and variance for a strain-dependent coefficient . This central approximation does not determine far tails, which control high concentration moments; those require a full large deviation principle. The two logarithmic widths need not be independent. The area now increases and decreases typically as . This is diffusion arrest of Gaussian packet compression.
For example, a constant principal strain gives the exact physical variancesThe thin variance approaches its diffusive floor, the long variance grows exponentially, and the mass-to-area relation gives the quoted typical amplitude decay. A random strain additionally makes rare histories important for concentration moments.
For a precise statistical formulation define the logarithmic area increaseThe Gaussian identities give the exact relation ; henceAssume the long-time strain statistics give a large deviation principle for on , with convex good rate function , . At exponential accuracy the probability of near is . Combining that cost with the amplitude factor and applying the Laplace principle for probability measures gives the large-deviation decay rates of a Gaussian scalar packetThe initial amplitude only changes a time-independent prefactor. One can see the minimization directly by dividing the possible area-growth rates into small intervals: each contributes its probability cost times , and the interval with least total exponential cost dominates. An interval around a minimizing gives the matching lower bound. The nonnegative area increase bounds the exponential weight by one, so unusually large positive growth cannot produce a divergent weighted tail. Using the area rather than only also avoids discarding possibly important fluctuations of the compressed direction.
Suppose is strictly convex and differentiable, with its minimum at and finite negative right derivative at zero. DefineFor the minimizing rate is positive and uniquely solvesFor , convexity puts the minimum at the endpoint , givingHigh moments are dominated by rare histories with little net area growth, in which a packet keeps a substantial concentration. Their probability cost is , independent of the moment order. A finite threshold is conditional: if , the minimizer can approach zero without reaching it at any finite .
Below the threshold, differentiation of the minimizing expression cancels the terms involving because . Thus , andStrict negativity uses a nondegenerate rate function with a unique zero at : for positive , and . For deterministic strain the ratio can instead be constant. Near the typical rate, if with , then for small . If this quadratic expression holds all the way to zero, it gives the illustrative full resultThe quadratic form is an example, not a universal law of turbulent strain.
A thin scalar packet is stretched until molecular diffusion broadens its compressed direction; conservation of its scalar mass then converts area growth into dilution. Ensemble averages sample different stretching histories, producing different decay rates for different moments and saturation when weakly stretched histories dominate. The present moment calculation is specifically for the centered Gaussian packet and averaging over the flow; signed random initial fields with overlapping packets can also have cancellations and require their initial-field statistics.
Finally, positive exponential decay is a statistical conclusion requiring the strain assumptions above, not a consequence of the local differential equation by itself. For and initially isotropic physical variance , the exact solution has and . Its moments decay algebraically as . Thus the general equations for the exponential rates are the rate-function minimization above; numerical rates and a finite saturation threshold require the long-time statistics of the flow.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 51 2 Solution Created 2026-10-03 Updated 2026-10-14
Differentiate the material derivative of the passive scalar component by component. With ,The chain rule along a Lagrangian trajectory therefore gives the covector evolution of a material scalar gradientThe transpose matters: a gradient is transported as a covector, rather than as a material separation vector. When , the third row of vanishes, andLet and setFor , the matrix exponential gives the exact horizontal solutionThe two projections are onto the eigenspaces with eigenvalues and . If , write with . ThenThe stated growing asymptotic requires this nonzero projection. An initial gradient entirely in the other eigenspace decays, and when the horizontal gradient is constant.
For constant vertical shear, write . Integrating the third component using the exact horizontal solution yieldsConsequently, if is nonzero, , andIf , exponential growth of is absent, but the ratio still tends to zero on the growing horizontal branch. Thus exponential vertical growth is generic, not unconditional. The scalar-gradient inclination in a steady planar strain is the tangent of the angle between the scalar's normal and the horizontal plane. Equivalently, it is the cotangent of the inclination of an isoconcentration surface to that plane. Large corresponds to nearly horizontal scalar surfaces; small corresponds to nearly vertical ones.
For the probability calculation, take . The independent random variables with normal distributions of variance make distributed according to the Rayleigh distribution, withThe advertised Gaussian-over-Rayleigh inclination distribution also needs to be independent of ; its Gaussian marginal alone does not imply this. Under that intended assumption, for ,The cumulative distribution function is zero for . Differentiating givesand the probability density function is zero for negative . Its integral is one because the cumulative distribution function tends to one at infinity. Independence is a real hypothesis: has exactly the stated Gaussian marginal but makes almost surely, contradicting the unbounded support of this density. A sufficient physical model is isotropic Gaussian vertical shear, independent of , whose projection in any horizontal direction has variance .
If the strain varies slowly, the horizontal gradient must align with the current growing direction, and the vertical-to-horizontal ratio must adjust before that strain changes. Both adjustment times are of order . Thus the local condition is , and the typical condition for the specified statistics isThis is an adiabatic approximation, not a uniform statement about arbitrarily weak instantaneous strains: samples with retain memory of earlier strain. The instantaneous eigenvector must likewise turn slowly compared with .
For rapidly fluctuating vertical shear, insert the large-time horizontal solution into its stochastic differential equation:The linear combination is a Brownian motion: it has independent Gaussian increments and increment variance . For the signed inclination , the Itô product rule introduces no extra cross term because the exponential factor is deterministic. It follows thatThis is an Ornstein-Uhlenbeck process, explaining why white-noise vertical shear gives an Ornstein-Uhlenbeck inclination. Its Fokker-Planck equation isIn a stationary state the Fokker-Planck probability current is constant. A nonzero constant current cannot give an integrable, nonnegative density at both ends of the real line, so . Integrating and normalizing with the Gaussian integral givesThe stationary variance is . More explicitly the explicit Ornstein-Uhlenbeck solution has mean and variance , confirming convergence to this density. Here and are needed for the stated smooth stationary density; at there is no confinement, while gives a point mass at zero.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 51 1 Solution Created 2026-10-03 Updated 2026-10-14
Put , with and . The relevant homogenization of a periodic advection-diffusion equation limit is a long horizontal wavelength observed on its diffusive time scale. Introduce and , retaining the fast variables . Since the velocity field is independent of , no fast horizontal cell variable is needed. Write the multiple-scale expansionThe cell functions are periodic in and in the period of . The kernel of on this periodic cell consists of constants: multiplying by and integrating over the cell gives , after which . Thus the leading concentration really is independent of the fast variables. At first order,There is a unique periodic : differences of two solutions are proportional to , and the periodicity condition fixes the integration constant. Equivalently,At second order the advection-diffusion equation givesIntegration over the fast cell annihilates the left side. Since the spatial average of is , its solvability condition isFor the second equality, multiply by and average over a period: . In particular the enhancement of diffusivity is nonnegative. Once this solvability condition holds, the remaining zero-mean forcing admits a periodic cell solution: its nonconstant spatial Fourier modes are damped by , while its spatially constant mode has a periodic antiderivative because its temporal average is zero. This also explains the relaxation of initial transverse inhomogeneity. The first corrector has zero spatial mean, so .
This derivation describes the large-scale, long-time limit, after times comparable to the period and to . It does not give an exact closed equation for the spatial average of arbitrary finite-time data: that average contains a correlation between the velocity field and concentration. In physical coordinates the leading long-wavelength concentration therefore obeys asymptotically. The cell expansion, its bounded periodic correctors, and the decay of transverse cell transients justify this effective diffusivity of a periodic sinusoidal shear.
For constant , the periodic cell solution is . ConsequentlyThis is Taylor dispersion: molecular diffusion moves particles between different horizontal velocities and turns their accumulated horizontal displacement into large-scale diffusion.
For the impulsive flow, jumps by at each kick and decays exponentially between kicks. If denotes its value just after a kick, periodicity requires . Thus, within one period,Using the mean-square expression, which has no ambiguous product of a Dirac delta with a discontinuous function, givesThe impulsive model can also be obtained by shrinking smooth pulses of fixed integrated strength. The passive scalar undergoes the exact horizontal shear map at a kick, while the transverse coordinate is unchanged. The cell solution above is the corresponding limit of the smooth cell solutions. Using a one-sided value in instead would miss the contribution from the jump of .
For ,Transverse Brownian motion substantially decorrelates the shear phase between successive kicks. A uniformly distributed phase has horizontal displacement variance per kick, producing an extra diffusivity .
For ,Many kicks occur before transverse diffusion changes a particle's shear phase. Their leading effect is therefore the steady shear with mean velocity amplitude , whose Taylor dispersion coefficient is precisely . The divergence as describes a very long decorrelation time; it does not imply infinite finite-time spreading. At the phase never changes and, for a uniform phase, kicks give variance . The spreading is then ballistic transport, rather than diffusion. The long-time diffusive limit must precede the zero-diffusivity limit, with .
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 50 5 Solution Created 2026-10-03 Updated 2026-10-14
Let be the actual displacement field, let be an admissible trial displacement, and set . On the displacement-prescribed part of the boundary, . With actual stress , the supporting-plane inequality for the convex strain energy density givesBoth and satisfy static elastic equilibrium with the same body force, so . On the traction-prescribed boundary their tractions agree. Since , integration by parts givesSubtracting the prescribed external-work representative proves the minimum potential energy principle in elasticity:Strict convexity gives uniqueness of the minimizing strain, although rigid displacements can remain when the boundary conditions allow them.
For the comparison bound, put and use the lower conjugate, with its infimum sign convention,Its defining inequality is , hence for every . Integrate this pointwise majorant for each compatible strain, then take the infimum over the same admissible set. This provesNo convexity of is used for this inequality. If , it yields only the extended-real upper bound . For example, and give for every finite . A useful finite bound requires a suitable comparison energy; choosing a sufficiently stiff quadratic comparison makes the usual excess energies concave. The derivative used below additionally presupposes finite differentiable duals, or an appropriate supergradient formulation.
Now normalize , take positive constant , and write . For phasewise constant elastic polarization , its lower conjugate contribution is constant within each phase. The remaining minimization isWrite the minimizing strain as , where comes from a zero-boundary displacement field. The static elastic equilibrium equation is , so the supplied elastic strain Green operator gives . Its zero mean removes the cross term with the constant . Using its reciprocity and projection property , we obtainHere the brackets in the last two terms denote the spatial integral and tensor contraction, not just a phase average.
Let . The zero output mean and reciprocity of imply that it annihilates constant elastic polarizations on either side. Thus subtracting and from the phase indicators does not change their bilinear integral. Define the fourth-order block tensorsConsequently , , andThese identities follow from reciprocity and ; no phase independence assumption is needed. The phase polarization comparison bound, valid for every polarization with finite dual terms, is thereforeIn particular, it can be optimized over the phase elastic polarizations without changing the upper-bound direction.
To derive the final displayed form, impose the stationarity equations in the question. For , put ; these are dual strains, initially distinct from the comparison solution's phase averages. Reciprocity of givesThus stationarity is exactlyThe comparison solution has phase meanso the dual strains become its phase means at stationarity. Multiplying the stationarity equations by and summing gives .
For clarity, the concave biconjugate here uses another infimum: . The lower conjugate is concave, since it is an infimum of affine functions. At a differentiable finite point, its supporting-plane inequality shows that minimizes this last expression when . HenceSubstitute both identities into to obtainThis is the requested final bound with the accompanying phase equations. It remains valid at any well-defined stationary choice; asserting existence of such a differentiable choice for arbitrary would require extra hypotheses. Without stationarity, the earlier is the correct general bound. In the concave closed excess-energy case ; for general excess energies replacing the concave biconjugate by without proof would reverse the needed majorant logic.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 50 4 Solution Created 2026-10-03 Updated 2026-10-14
Write , and . At crystal orientation , the conductivity tensor is . Because the comparison tensor is scalar, its resolvent rotates in the same way:Uniform angular averaging uses and . It therefore sends any such rotated diagonal tensor to half its trace times . In particular,Dividing these scalar coefficients in the stated Hashin-Shtrikman conductivity variational principle givesThis averaging calculation uses the uniform orientation model in the question; a nonuniform distribution need not give isotropic effective conductivity.
The lower Hashin-Shtrikman conductivity bounds use a comparison no larger than every local principal conductivity, so . The upper variational bound uses . These opposite directions come from the sign of the contrast in the polarization functional: positive contrast gives a maximizing lower principle, and negative contrast a minimizing upper principle. The endpoint values are understood as limits when a contrast eigenvalue vanishes. Sincethe strongest lower and upper values in their admissible comparison ranges are, respectively,Thus in the statistically isotropic polycrystal setting of these Hashin-Shtrikman conductivity bounds.
The self-consistent conductivity approximation chooses the comparison conductivity equal to the predicted conductivity, . Multiplication by the positive denominator cancels the terms and leaves . Only the positive root is an admissible conductivity:For a direct proof of its ordering relative to the variational bounds, set . ThenBoth quantities are nonnegative, proving , with equality throughout when . The self-consistent conductivity approximation is a closure calculation; no unrequested claim of exactness for every spatial arrangement follows just from this fixed-point computation.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 50 3 Solution Created 2026-10-03 Updated 2026-10-14
Put , , and . Assume positive bulk modulus and shear modulus. For a unit vector , direct contraction of the isotropic elastic stiffness tensor gives the acoustic tensor and its inverse:These are its transverse and longitudinal orthogonal projections. Symmetrizing the definition of the directional elastic strain Green operator consequently givesSubstitution into the spherical representation is already the isotropic specialization. We can also evaluate its angular integrals as distributions. For , direct integration with the polar axis parallel to givesThe first identity holds as a locally integrable distribution. Since the second derivative of is , taking two derivatives in the first identity and four in the second givesThus an explicit complete isotropic elastic strain Green kernel isAll derivatives here are distributional derivatives, which retain the contribution at the origin.
For the requested contraction, , or equivalently trace the complete kernel and use . ThereforeMore explicitly, its distribution form iswhere the Cauchy principal value uses spherical exclusions about the origin. The coefficient of the Dirac delta can be checked by integrating by parts over a punctured ball: has contact term . Taking the trace, the principal-value part has zero trace and , soKeeping only the ordinary kernel away from the origin would incorrectly give zero for this double trace.
Now extend the elastic polarization by zero outside . Since the shear modulus is unchanged, the stiffness contrast acts only on the spherical strain:Hence is its scalar coefficient. Relative to the same external loading, the elastic strain Green operator gives . Taking the trace and using the contact identity reduces this nonlocal equation toSolving the scalar equation gives the constant-shear bulk-modulus inclusion formulaUsing the single contraction instead of the double trace givesFinally eliminate the actual trace using the scalar formula:The reference trace in this last formula is essential and is what the original PDF prints; the converted TeX loses its superscript. The second derivatives are interpreted distributionally, or with their principal-value and contact terms explicitly included. With ordinary regularity they give the corresponding pointwise formula at regular interior points.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 50 2 Solution Created 2026-10-03 Updated 2026-10-14
At a perfectly bonded elastic interface without an interfacial force, displacement and traction are continuous:Tangential derivatives of the common displacement trace are also continuous. Thus the jump of a piecewise constant displacement gradient tensor annihilates every tangential vector, and has the form . Taking its symmetric part shows that the strain jump is , whereThe adjoint formula follows from for symmetric stress tensors. Tangential-tangential strain components are therefore common to all layers. Conversely, such gradient jumps can be realized by continuous piecewise affine displacement in the layered geometry.
Take positive elastic stiffness tensors with their usual minor and major symmetries, and a positive comparison elastic stiffness tensor . A fictitious layer can have the same tangential displacement derivatives and the same traction as the physical layers. Hence . The common traction condition giveswhere is the positive acoustic tensor, with components . Solving for givesExpanding the two occurrences of gives exactly the symmetrization over and in the directional elastic strain Green operator specified in the paper.
For any two layers, the inverse identity for their acoustic tensors proves the required resolvent relation without interchanging noncommuting tensors:With , this identity also gives . ThereforeThese finite-dimensional operators are inverses. Define . Then , and averaging strains and stresses givesEliminating the fictitious strain yieldsAll products have the displayed order; the elastic stiffness tensors need not commute.
It remains to justify the inverse and comparison independence. Consider two compatible equilibrated layer solutions with the same mean strain. Their difference has zero common tangential-tangential strain, so , with because is injective and the mean difference is zero. Their traction difference is one common vector . ThereforePositive elastic energy forces every to vanish. In particular, if , all physical layer strains vanish. Their common tangential components then force , and their zero traction gives . Hence , proving that is invertible. Finally, every positive choice of constructs the unique layer solution for the same . Its averaged stress is unique, so the displayed effective stiffness is independent of the fictitious comparison material. This is the exact layered constitutive response, rather than a claim that piecewise constant fields meet arbitrary finite-body boundary data.
There are unlisted articles, also show them or only show them.