Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Magnetic tension
The Rayleigh-Taylor instability extracts gravitational potential energy when a heavy fluid is supported above a lighter one. A small downward excursion of heavy material and upward excursion of light material can grow instead of experiencing restoring buoyancy. The Kelvin-Helmholtz instability instead extracts kinetic energy from a velocity difference across an interface or shear layer. The interface displacement and its induced flow reinforce one another by tapping the background shear; a reversed density ordering is not required.
A useful common model has two inviscid, incompressible, semi-infinite fluids separated at , with lower density/velocity , upper density/velocity , downward gravity , and surface tension . For a disturbance proportional to , with , the two-fluid interfacial gravity-shear dispersion relation isA negative right side gives exponential growth. With no shear or surface tension and , the growth rate of the Rayleigh-Taylor instability is , where is the Atwood number. With equal densities and no restoring force, the growth rate of the Kelvin-Helmholtz instability is . Heavy-over-light stratification drives Rayleigh-Taylor growth; velocity shear drives Kelvin-Helmholtz growth. A heavy lower fluid supplies gravitational stabilization, and surface tension stabilizes sufficiently short waves in this ideal interface model.
Finite shear-layer thickness, viscosity, compressibility and magnetic tension can change the growth rates and unstable wavelength range. In particular, unlimited growth with increasing is a limitation of the zero-thickness, zero-surface-tension idealization. Density-interface overturning and jet-boundary mixing are appropriate physical applications of the two mechanisms, but the nonlinear mixed state is not determined by the linear growth rate alone.
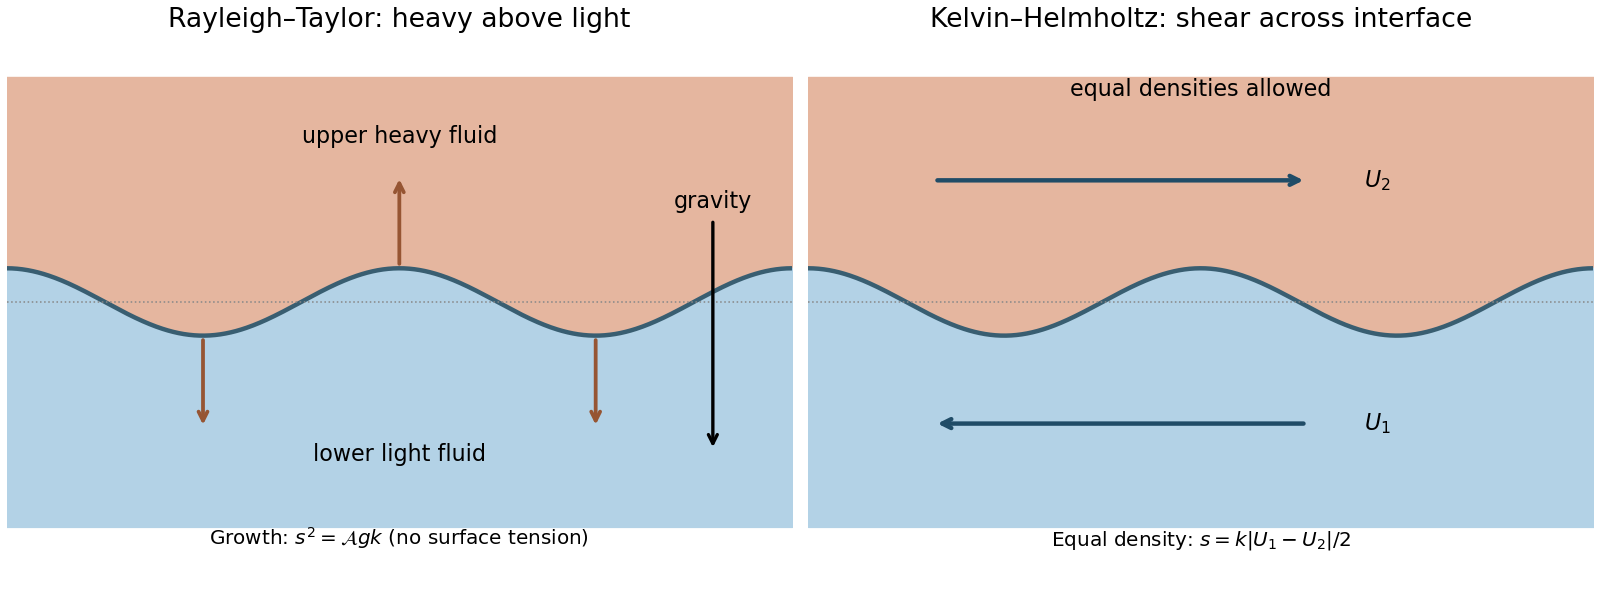
Original schematics of Rayleigh-Taylor instability and Kelvin-Helmholtz instability
. Details. A plasma contains mobile charged species whose collective electromagnetic response matters. On scales large compared with the Debye length, positive and negative charge densities nearly cancel: this is quasineutrality, not the absence of electric currents or electric fields. For electrons of temperature and number density , the characteristic plasma screening and oscillation scales areA collective plasma description requires many particles within a screening volume; long-wavelength, sufficiently slow behavior can often be described by magnetohydrodynamics with an appropriate fluid closure.
An individual particle feels the Lorentz force . In a uniform magnetic field, its transverse motion gyrates while its parallel motion remains free, giving a helical path when both components are present. The nonrelativistic cyclotron frequency and gyroradius areWhen the system scale is much larger than and the relevant time scale longer than , the field strongly organizes transport across it, provided collisions do not interrupt the gyromotion. A perpendicular electric field also gives the common guiding-centre drift .
For a conducting fluid, the macroscopic Lorentz force density has the useful decompositionThese terms are magnetic pressure and magnetic tension. Magnetic tension resists bending, while magnetic-pressure gradients resist nonuniform compression. The plasma beta compares thermal and magnetic stresses.
With uniform magnetic diffusivity , the resistive induction equation isIf the magnetic Reynolds number , ideal magnetohydrodynamics applies approximately and magnetic flux freezing links the field geometry to fluid motion. Finite diffusivity permits field slippage and magnetic reconnection. Field tension supports Alfvén waves with ; coupled magnetic and gas compression also supports magnetosonic waves. These effects allow a field to transmit forces and angular momentum between distant parts of an astrophysical plasma.
Past exam of the collisionless plasma physics course of the University of Oxford 2025 3 a Solution 2026-10-25
Use Gaussian units and the kinetic magnetohydrodynamics equationstogether with species continuity equations, quasineutrality and the drift-kinetic equation. Here sum the species pressures. Interpret the thermal speed denominator in the source as the species mass , so and the first adiabatic invariant is .
The specified Maxwell-Boltzmann distribution has zero mean motion and isotropic pressure, . All equilibrium scalars depend only on , while and . Therefore the equilibrium streaming and mirror terms of the drift-kinetic equation vanish. The remaining terms vanish because and ; the parallel electric constraint is also satisfied because the equilibrium parallel pressure gradient is zero. Species continuity equations and the induction equation are stationary, and quasineutrality holds by assumption.
It remains to check the perpendicular force balance. The radial magnetic pressure and magnetic tension giveThis is preciselyThus the Z-pinch is a steady solution of the stated kinetic magnetohydrodynamics system. Its equilibrium electric current is supplied by the small species drifts implicit in this approximation; zero leading common flow does not require zero electric current.
Past exam of the collisionless plasma physics course of the University of Oxford 2025 3 e Solution 2026-10-25
Assume the stated outward-decreasing pressure, , and setFor , the interchange instability hasAn outward-displaced flux tube carries higher pressure than its new surroundings. In the unfavorable magnetic field-line curvature of the Z-pinch, the resulting imbalance drives it farther outward. Parallel variation bends field lines, and magnetic tension supplies the stabilizing term. The fastest local interchange is at , with ; this endpoint is understood as the limit of the stated Alfvénic ordering. There is no leading dependence once .
For , the two real frequencies are : the displacement oscillates as a curvature-modified Alfvén wave. At , the leading equation is , so the marginal solutions are a constant and a term linear in time; neglected corrections determine finer behavior. For a favorable reversed pressure gradient, , this drive is stabilizing.
The leading dispersion relation is the same in ideal magnetohydrodynamics. Its adiabatic law gives ; the compressive part is smaller than the steep-gradient advection by or , giving the same leading . Relaxing those orderings introduces compression, field-strength and field-length changes, and pressure anisotropy; the drift-kinetic equation can then introduce parallel kinetic phase mixing and Landau damping. At larger plasma beta, coupling to compressive branches matters; if pressure anisotropy develops, mirror instability and firehose instability may also become relevant. These are possibilities beyond the derived leading equation, not additional roots already established here.
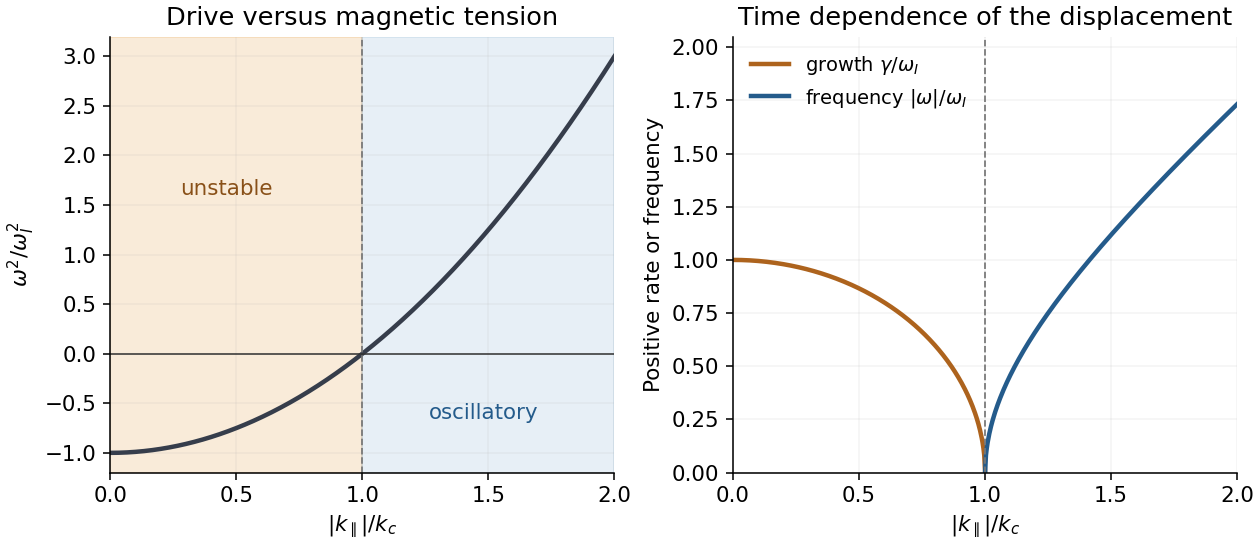
Magnetic tension stabilizes the local interchange instability above its critical parallel wavenumber
. Details. Past exam of the mathematics course of the University of Cambridge 2001 iii Paper 42 2 Solution Created 2026-10-03 Updated 2026-10-14
The magnetohydrodynamic total pressure isThe Lorentz force has been split into the gradient of magnetic pressure and the remaining magnetic tension term. An appropriate boundary model is impermeable, perfectly conducting stationary cylindrical walls with no initial normal magnetic flux: at . In an inviscid fluid this is a slip condition, not a no-slip condition on or . It also makes the tangential ideal electric field vanish at the walls. Take perturbations periodic in and periodic or Fourier-resolved in ; the wall reaction supplies the normal pressure force without an extra prescribed pressure value.
Write the steady velocity and magnetic field as and . They satisfy both divergence constraints. Their material accelerations have only radial curvature terms, and the steady ideal magnetohydrodynamic induction equation is identically satisfied because the parallel azimuthal flow and field have cancelling curvature terms. The radial momentum equation isHence the most general such equilibrium isIts gas pressure is ; on a bounded annulus the additive constant can be chosen to keep it positive. Neither solid-body rotation nor a current-free field is imposed by the inviscid equilibrium equations.
For the linear stability calculation, put , , and define . Use axisymmetric normal modes proportional to . Denote the velocity amplitudes by and the magnetic amplitudes in velocity units by . Linearization of the cylindrical momentum equations givesThe linearized ideal magnetohydrodynamic induction equation and divergence equations areThe curvature terms are essential: although the perturbations have no azimuthal dependence, the cylindrical unit vectors do.
For , . Introduce the radial Lagrangian fluid displacement by . The azimuthal amplitudes reduce toConsequently the radial and vertical equations, combined with the incompressible flow constraint, givewhere the Michael criterion for axisymmetric toroidal-field interchange coefficient isFor , the required single displacement equation is thereforeThe same differential equation holds for , which is a constant multiple of .
Set . Multiplication by and integration by parts with the wall conditions gives the global variational form of the Michael criterion:The denominator is strictly positive for a nonzero displacement, so every mode's is real. If everywhere, no exponentially growing mode exists. Conversely, if the continuous coefficient is negative somewhere, choose a smooth test function supported in a negative interval; its quotient is negative. For sufficiency, let be the positive Sturm-Liouville operator with Dirichlet boundary conditions and let multiply by . The generalized mode equation is equivalent to the compact operator and self-adjoint operator problem . The negative test quotient guarantees a negative eigenvalue and therefore a growing solution . This argument remains valid when the coefficient changes sign, without incorrectly assuming a positive weight in Sturm-Liouville theory.
Thus, for any fixed nonzero vertical wavenumber,Equality is marginal. When , the incompressible flow constraint and both rigid-wall conditions force the radial velocity to vanish, so that special case has no radial interchange mode. When the field vanishes, the coefficient reduces to , recovering the Rayleigh centrifugal stability criterion.
For a Keplerian disk, . If , the toroidal interchange field threshold in a thin Keplerian disk isFor ordinary radial gradients on the scale , the Alfvén speed must therefore be comparable to the orbital speed. A field on the gas pressure scale has in a thin disk, and cannot normally meet this condition. Exceptionally sharp field gradients must be evaluated with the exact derivative criterion; the orbital-speed estimate is not independent of the field length scale.
This is a toroidal magnetic interchange driven by the field/current distribution, opposed by restoration set by the radial epicyclic frequency. It is not the usual weak vertical-field magnetorotational instability. In the vertical-field problem, a nonzero bends magnetic field lines and couples displaced fluid elements, allowing decreasing to supply rotational kinetic energy even when . Here the axisymmetric perturbation has no scalar variation along the purely toroidal background field, and no such weak-field coupling: a sufficiently adverse toroidal-field gradient, rather than merely , is required. Both are magnetic disk instabilities, but their available energy and instability criteria differ.
Past exam of the mathematics course of the University of Cambridge 2002 iii Paper 46 3 Solution Created 2026-10-03 Updated 2026-10-14
Choose a reference circular orbit at radius , rotate the frame with , and introduce local Cartesian coordinates , and vertical coordinate . On scales small compared with , neglect curvature of the coordinate directions but retain the leading differential rotation. The background velocity relative to the rotating frame isThus for a Keplerian disk. The shearing sheet retains Coriolis acceleration and the linear tidal acceleration. The radial shearing-sheet tidal potential is , whose force balances the background Coriolis acceleration. If vertical tidal gravity is included, its equilibrium contribution is balanced by a background pressure and disappears when that equilibrium is subtracted.
Write the total velocity as . In the rotating-frame magnetohydrodynamic momentum equation, background advection is and advection of the background by the perturbation is . The uniform-viscosity diffusion of the linear background shear is zero. For a solenoidal magnetic field the Lorentz force per unit mass isAt constant density, absorb the magnetic-pressure gradient into . Subtracting the background force balance then gives the stated momentum equation, with the remaining nonlinear advection , Coriolis acceleration , magnetic tension and viscous diffusion.
For constant finite electrical conductivity , put . The resistive induction equation with uniform magnetic diffusivity is . Substituting the background shear supplies the term and the same background-advection operator as in the momentum equation. The two further conditions areThey express incompressibility and the absence of magnetic monopoles, respectively.
Now take real plane waves with common phase and real wavevector. The solenoidal conditions becomeEvery field depends on position only through . Hence for either transverse vector field and either wave field , . This proves that all the displayed quadratic advection and tension terms vanish pointwise, including products involving conjugate amplitudes. These waves are therefore exact solutions at finite amplitude, not merely a linearization.
Acting with on the phase yieldsCanceling its position-dependent part requiresThe remaining amplitude equations areDifferentiating the velocity constraint determines the pressure amplitude:The resistive induction equation preserves its constraint because cancels the corresponding shear term in . The specified magnetic field has no spatially uniform part. Thus there is no background magnetic field producing an additional linear magnetic-tension coupling. The scalar is the modified pressure; the physical pressure can include a constant and a second spatial harmonic from while retains the stipulated plane-wave form. This is an exact zero-mean magnetic shearing wave.
For decay, take the real part of the scalar product of the velocity-amplitude equation with its complex conjugate. Pressure does no work because , and the real part of Coriolis work is zero. ThereforeThe resistive induction equation similarly givesusing . Integrating these differential inequalities, defineThenA non-axisymmetric wave has . For nonzero differential shear and positive , the negative cubic terms dominate the linear upper bound on shear work. ConsequentlyThis cubic-exponent decay of a nonaxisymmetric shearing wave allows transient energy growth before the winding to short radial wavelengths makes diffusion dominant. The magnetic amplitudes can also be written explicitly aswhich confirms the damping independently. Positivity of the dissipative coefficients is necessary: with , an inviscid vertical velocity amplitude can remain constant, and an ideal vertical magnetic amplitude can remain constant when . The asserted decay applies to the viscous, finitely conducting model; taking an ideal limit before the long-time limit changes the conclusion.
Past exam of the mathematics course of the University of Cambridge 2003 iii Paper 64 2 Solution Created 2026-10-03 Updated 2026-10-14
Use the adiabatic form of ideal magnetohydrodynamics: heat conduction and external heating are absent, so . Infinite electrical conductivity and zero viscosity alone would not remove the thermal source terms on the cover page. If those terms are retained, the energy equation below must acquire on its right-hand side.
Expanding the continuity equation gives its conservative form . Using it to expand the conservative momentum derivative givesFor , the Lorentz force density is the divergence of the magnetic Maxwell stress tensor:Combining these identities with momentum balance provesThe dyadic stress contains both magnetic tension and magnetic pressure; the sign in the flux is fixed by moving the magnetic force to the left.
For the energy equation, first dot momentum balance with and add the adiabatic internal-energy equation. The continuity equation converts their material derivatives into conservative derivatives, while . The result isThe ideal magnetohydrodynamic induction equation gives the magnetic counterpart. In fact,Thus the outward Poynting vector is , and magnetic work cancels the fluid work. Finally, the continuity equation impliesAdding all three identities gives ideal magnetohydrodynamic energy conservation in the required local form:whereThe magnetic energy coefficient is , as in the original PDF. For a self-consistent, time-dependent gravitational field this local balance should not be confused with a global self-gravitating energy integral: the latter uses gravitational field energy, or the familiar one-half factor in after the field is eliminated.
Work in the shock frame of a thin planar discontinuity, with normal speed . A smooth gravitational potential has no finite jump through a vanishingly thin front; its advected contribution cancels using the common mass flux. Integrating the conservation laws gives constant normal mass, momentum and energy fluxes, together with the normal-field and tangential-electric-field conditions of the ideal magnetohydrodynamic shock conditions.
For a parallel magnetohydrodynamic shock, and . The magnetic solenoidal constraint makes the same on both sides. The normal momentum flux is ; its magnetic term is therefore identical upstream and downstream. The Poynting vector is zero because . Hence the nontrivial jumps are exactly the Rankine-Hugoniot conditions for a perfect gas:with specific enthalpy . Physically, motion along the straight field neither bends it nor compresses its transverse flux. The field consequently provides no changed stress or energy flux in this purely parallel geometry. This conclusion does not apply to a shock that develops a transverse magnetic field.
For a perpendicular magnetohydrodynamic shock, the magnetic field is tangential and the velocity normal. Steady induction makes continuous, while the continuity equation makes continuous. Dividing gives the magnetic flux freezing relationPut , so and . Constant normal momentum flux now reads . Substitution givesThe magnetic correction is negative for compression: part of the incoming ram pressure builds magnetic pressure instead of thermal pressure.
Here the Poynting vector has normal component . Divide the constant energy flux by the nonzero mass flux to obtainWith , this gives the second expression for downstream pressure:In this expression is the only downstream unknown. Equating the two pressure expressions and multiplying by yieldsup to an overall minus sign, where andThe discarded factor is the unchanged state, not a compressive shock. This derives the polynomial for the compression ratio of a perpendicular magnetohydrodynamic shock without omitting its trivial branch.
For the usual physical adiabatic index , is strictly increasing for positive , has , and has one positive root. Sincethat root is greater than one precisely when . The necessity is not limited to : for any , eliminating using givesFor , positive downstream pressure requires when . Moreover,The bracket is positive throughout , even when . The exactly cold unmagnetized limit gives the familiar strong-shock upper compression ratio directly. Thus the physical compressive branch requiresThe PDF's final denotes this same incoming speed . The right side is the squared speed of a perpendicular fast magnetosonic wave: the upstream flow must be super-fast-magnetosonic so that this compressive signal cannot run upstream against the incoming flow. At equality the shock amplitude vanishes into a characteristic disturbance.
Past exam of the mathematics course of the University of Cambridge 2003 iii Paper 64 3 Solution Created 2026-10-03 Updated 2026-10-14
Use , and primes for derivatives. Time dependence is , so exponential growth means . The constant mass density and incompressible velocity giveAll magnetic factors below use the source convention .
Linearizing the ideal magnetohydrodynamic momentum equation, the advective perturbation is . The magnetic force is , whose component vanishes. Thus the three component equations areIn particular the vertical equation has the pressure-gradient and magnetic signs printed in the PDF.
The incompressible ideal magnetohydrodynamic induction equation can be written . Linearizing it givesFor , these areThe term is essential: a perturbed vertical magnetic component is stretched by the background shear flow. Differentiating these amplitudes and using incompressibility also verifies .
For completeness, substitution into all three momentum equations giveswhere is the vertical vorticity amplitude. Multiplying the equation by and subtracting times the equation eliminates pressure:Therefore, away from ,This is the nonresonant reduction relevant to the instability calculation. Division at the Alfvén wave resonance would be invalid. For a concrete counterexample to an unrestricted reading, take constant , , , and , with all other amplitudes zero. Every smooth solves the original linear system, but need not vanish. These transverse resonant waves do not drive . A genuinely growing mode in a real background has complex and cannot satisfy either or on the real axis. This explains exactly when the requested reductions may be used.
On that nonresonant branch, multiply the horizontal equations by and and add. Incompressibility gives , soCombining incompressibility with vorticity, multiply its first equation by and subtract times the definition of . This givesConsequentlySubstitute this and the derivative of the displayed pressure relation into vertical momentum. Multiplication by givesExpanding the second derivative once gives exactly the requested vertical-velocity equation:
To take the discontinuous-layer limit without multiplying distributions, introduce . It is proportional to the normal displacement: the material kinematic condition is , so . Since , . The same equation becomes the displacement equation for a parallel magnetic shear flowThe physical interface condition is continuity of , because both fluids move the same interface. For constant on each side, away from resonance the coefficient is constant and nonzero, so . Requiring decay at infinity and matching yieldsThe exponent is , as in the actual PDF; the converted TeX's there is a transcription error.
Integrate the conservative displacement equation across a layer of thickness . Its undifferentiated term has an integral tending to zero, while the derivative givesEquivalently, the perturbed magnetohydrodynamic total pressure is and is continuous. With and , a nontrivial amplitude requiresThis is also the rigorous thin-layer integration of the original vertical equation, after combining the derivative terms before taking the limit.
Put and . Completing the square gives the dispersion relationFor both interface frequencies are real, so there is no exponentially growing interface mode. Above that threshold, the growing sign has growth rate . This is magnetic stabilization of an equal-density vortex sheet: magnetic tension from bending the field overcomes the kinetic shear driving Kelvin-Helmholtz instability. Equality is marginal and the strict stable condition avoids its double-root degeneracy. The case has no streamwise shear drive and has the neutral interface frequency ; the nonzero-frequency elimination should be interpreted by the original equations or a limiting displacement formulation in that case. The horizontal affects the exponential decay length through , but not the stated threshold.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 71 2 Solution Created 2026-10-03 Updated 2026-10-14
Linearizing the ideal magnetohydrodynamic induction equation about a static magnetic field and using gives the fluid Lagrangian displacement-generated magnetic field perturbation . The two solenoidal vector field conditions reduce the curl identity toIts divergence vanishes because it is a curl. Directly, the two products of first derivatives in cancel after exchanging their indices, while the remaining terms differentiate or , both zero. Similarly the integrated linear continuity equation gives , so .
Let be the magnetohydrodynamic total pressure. Magnetostatic equilibrium and the momentum equation in the linearized ideal magnetohydrodynamic equations areThere is no perturbed gravitational potential here because the field is fixed. Multiply by and integrate. The pressure term vanishes by the assumed boundary cancellation and . Thuswhere .
Integrate the first magnetic term along , using , then insert the expression for . This gives the positive term and two mixed derivative terms. For clarity, the troublesome term transforms asThe first term on the right cancels the other mixed term. Combining the remaining derivative with the term containing givesDifferentiating the equilibrium relation now combines the gradient of mass density and magnetostatic equilibrium terms:We obtain the incompressible magnetic displacement energy identityThe two Hessian matrices are real symmetric, making their Hermitian form evaluations real. The last term is a squared norm, and for a nonzero displacement in fluid with positive mass density. Thus . It may be negative, in which case one temporal branch has exponential growth; real squared frequency is not itself a proof of stability.
For the atmosphere with a horizontal magnetic field, has zero Hessian matrix and the equilibrium equation isConsequently the interchange stability of an incompressible magnetized atmosphere is governed by the numeratorFor , the magnetic tension term is zero: these fluid Lagrangian displacements interchange neighboring magnetic field lines without varying along them. A mass density increasing with height gives negative energy and instability; decreasing mass density gives positive energy for these vertical interchanges. If everywhere, the displayed form is nonnegative for every admitted incompressible displacement. If the gradient changes sign, suitably localized divergence-free interchange trials detect an unstable inverted layer; For example, take and , with supported in that layer. Their divergence is zero, and neither component varies along the magnetic field.
For , magnetic field lines are bent. Averaging over a full horizontal wavelength gives the trial Rayleigh quotientunder the stipulated admissible boundary/integrability conditions. It is a trial quotient, not a claim that this displacement is an exact eigenfunction for every profile. mass density decreasing upward is stable here too. For inverted mass density, magnetic tension can stabilize sufficiently short waves along the magnetic field, but does not remove the transverse interchange instability. Locally the two contributions have the familiar scale , with the Alfvén speed .
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 73 3 Solution Created 2026-10-03 Updated 2026-10-14
Consider a local shearing sheet centered at a circular orbit. Take uniform mass density, background velocity , rotation and a weak uniform vertical magnetic field . HereUse ideal magnetohydrodynamics, neglect viscosity, magnetic diffusion and vertical stratification, and take incompressible axisymmetric disturbances proportional to . They have horizontal velocity and field perturbations. Let be the magnetic perturbation in velocity units, the Alfvén speed and the Alfvén frequency. Magnetic pressure can be included in the perturbation's total pressure; the horizontal Lorentz force for this mode is the magnetic tension term .
Linearizing momentum and induction givesThe term winds a radial magnetic perturbation into an azimuthal one. Omitting it would remove the shear's magnetic energy source and give the wrong stability criterion.
A useful elimination that also covers neutral modes introduces the fluid displacement . Frozen-in flux gives , while the Eulerian perturbation velocity is , , because the displacement samples the gradient of the basic flow. The equations become the spring model of magnetorotational instability:For the stated time dependence, their determinant isThus the ideal magnetorotational dispersion relation isIt follows without dividing by , so the neutral stability boundary is included.
To analyze it, put and . ThenFor a hydrodynamically stable rotation law, , the sum of the two roots is positive. Their product is negative precisely when . One squared frequency is then negative, giving an exponentially growing mode and its decaying partner. Therefore the magnetorotational instability, or MRI, has criterionAngular velocity must decrease outwards, although specific angular momentum may increase outwards and satisfy Rayleigh's circulation criterion. This is why a Keplerian disc can be stable to the axisymmetric hydrodynamic disturbances of Question 2 yet unstable once magnetic coupling is introduced. At zero magnetic frequency the unstable root becomes neutral, while sufficiently large magnetic frequency restores stability. For increasing angular velocity, with , this ideal vertical-field instability is absent.
The growth rate isFor , differentiation with respect to sets , yielding the maximum growth rate of ideal magnetorotational instability:For Keplerian rotation, , soThus the fastest growth is on an orbital timescale. The field strength selects its wavelength, , rather than the maximum ideal growth rate. At fixed , growth does approach zero as ; retaining the finite maximum in that limit requires shorter wavelengths, which magnetic diffusion can eventually exclude. Unstable wavelengths satisfy in this local model. A finite disc must accommodate such a wavelength, so a sufficiently strong field can suppress the available vertical modes through excessive tension.
Physically, a bent field line acts like a spring joining neighboring fluid elements. The inner element rotates faster and pulls the outer element forward, transferring angular momentum outward. The inner element loses angular momentum and moves inward; the outer element gains it and moves outward. In a rotation law with outward-decreasing angular velocity, these motions increase their angular-velocity difference and the magnetic coupling produces further separation. A weak restoring spring therefore creates a feedback instability by enabling angular-momentum exchange. Without that exchange, each displaced element keeps its angular momentum and a positive epicyclic frequency restores its orbit. Strong magnetic tension instead prevents the separation. The free energy is the differential rotation, not the initial magnetic energy.
The instability provides an important route to turbulence and angular momentum transport in sufficiently conducting accretion discs. The radial flux of azimuthal momentum includes the stressThe first term is a Reynolds stress and the second is the magnetic contribution from the Maxwell stress tensor, with the sign appropriate to momentum flux. For the growing branch, take real and positive. The linear equations give and . The last sign follows from . Thus both the velocity and magnetic contributions carry angular momentum outward. The associated energy extraction is . Inward accretion can then accompany outward angular-momentum transport, and dissipation of the resulting fluctuations heats the disc. This gives a physical mechanism behind an effective turbulent-viscosity description such as an alpha disk, whereas microscopic viscosity alone is generally too weak for rapid accretion.
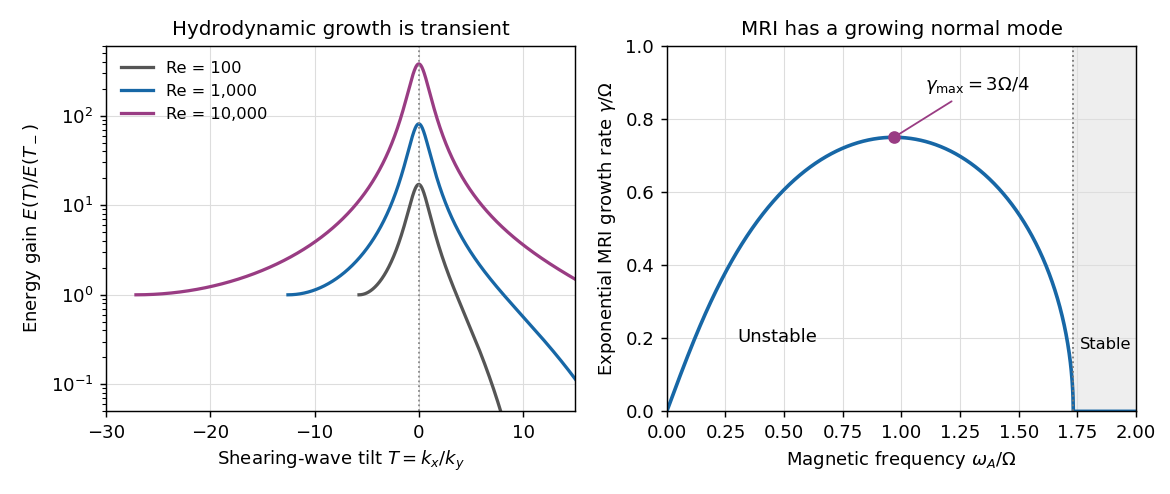
Finite hydrodynamic swing amplification compared with the growing MRI branch in a Keplerian disc
. Details. MRI is an exponentially growing magnetic instability of outward-decreasing angular velocity; hydrodynamic shearing-wave amplification is transient and does not by itself establish sustained turbulence. Nonlinear saturation, field regeneration and transport efficiency depend on field geometry, boundaries and thermodynamics. Poor conductivity or important nonideal magnetic effects can suppress or modify the ideal instability, so the local dispersion relation is a mechanism and growth criterion rather than a universal prescription for the saturated stress.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 75 1 1 Solution Created 2026-10-03 Updated 2026-10-20
Use Gaussian units, uniform number density , and ion mass density . Here is the magnitude of the elementary charge, as fixed by the printed current relation. Neglect electron inertia and displacement current. ThenFreezing the magnetic flux into this electron velocity, while retaining the ion momentum equation, gives the closed Hall magnetohydrodynamics systemThe pressure enforces the incompressible flow constraint; taking the divergence of momentum determines it up to the usual boundary-dependent constant. The induction equation preserves the solenoidal magnetic-field constraint. One can absorb into magnetohydrodynamic total pressure, replacing the Lorentz term by magnetic tension. Keeping ion inertia here is important: electron magnetohydrodynamics with fixed ions will be a later limit, not the complete two-field system.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 76 1 iii Solution Created 2026-10-03 Updated 2026-10-14
Let be the characteristic radius over which the differential rotation changes, with angular velocity of order . The winding source has magnitude . For times too short for appreciable magnetic diffusion, the zero initial toroidal magnetic field therefore grows as . In the steady balance, is opposed by , giving . Comparing these amplitudes gives the diffusive establishment time of a wound toroidal field:With , this is rotation times and the steady toroidal amplitude is of order . Thus high electrical conductivity makes establishment very slow even though winding begins immediately.
More precisely, if on regular toroidal magnetic fields, the solution with zero initial value satisfies . The residual relaxes diffusively. In the unbounded domain, estimates equilibration of the rotating region; exact establishment at every radius is only an asymptotic statement, with diffusion on scale taking order . As , the time diverges and the prescribed-flow ideal solution continues its secular winding. In a real fluid, magnetic tension and Lorentz force feedback can modify the differential rotation before the very large kinematic steady amplitude is attained.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 74 3 iii Solution Created 2026-10-03 Updated 2026-10-14
Set in the horizontal-field magnetoconvection dispersion relation. With positive and nonzero , cancellation gives the stationary neutral curveAt fixed , the Chandrasekhar number contributes a nonnegative penalty proportional to . It can be eliminated by choosing . It remains to minimize for :The function diverges at both endpoints and has its unique minimum at . Thus the magnetic-field-aligned rolls evade steady magnetic inhibition:independently of . If higher vertical sine modes are included, replacing by gives minimum , so the displayed first vertical mode also gives the smallest steady threshold.
Physically, these convection rolls have axes along the imposed magnetic field. Their perturbations are independent of , so in the resistive induction equation and no growing magnetic perturbation is generated. The flow does not bend the field; consequently magnetic tension cannot inhibit these rolls, however large the field strength. This conclusion concerns the requested steady disturbances.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 74 3 ii Solution Created 2026-10-03 Updated 2026-10-14
Put and . The plane-layer poloidal-toroidal decomposition supplies the assumed poloidal fields asSince and , potentials proportional to have the required vertical components. Their horizontal components are proportional to , satisfying the stress-free boundary conditions and the horizontal-field boundary conditions. The double-curl representation automatically enforces incompressibility and the solenoidal magnetic-field constraint.
Let be the amplitudes of . The temperature and resistive induction equations immediately giveEliminate the total-pressure perturbation by applying to the vertical momentum equation and subtracting times its divergence. The resulting vertical equation isIn particular, shows explicitly that magnetic tension opposes the displacement.
Taking the determinant of these three amplitude equations gives the horizontal-field magnetoconvection dispersion relation:This cubic polynomial includes all roots of the assumed poloidal coupled system; using its determinant form avoids discarding possible roots by dividing by or . As a check, factors off magnetic diffusion and leaves the standard stress-free Rayleigh-Bénard convection growth equation.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 74 3 i Solution Created 2026-10-03 Updated 2026-10-14
Let be the reference mass density, the kinematic viscosity, the thermal diffusivity, the magnetic diffusivity, and the coefficient of thermal expansion. The conductive state of Rayleigh-Bénard convection is . For the Boussinesq approximation, density variation is retained only in buoyancy. Linearizing about this state and the imposed magnetic field givesHere and is the perturbation of magnetohydrodynamic total pressure. The gradient part of the Lorentz force has been absorbed into ; the remaining term is magnetic tension. The sign in the temperature equation follows from .
Use the thermal-diffusion scaling of a convection layer: length , time , velocity , temperature perturbation , field perturbation , and total-pressure perturbation . Dropping dimensionless-variable decorations giveswithThese are respectively the Rayleigh number, Chandrasekhar number, Prandtl number, and magnetic-to-thermal diffusivity ratio. In particular, the magnetic coefficient is , not alone, in these thermal-time units. At , the boundary conditions are , , and .
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 74 4 Solution Created 2026-10-03 Updated 2026-10-14
Write for the squared isothermal sound speed, distinguishing the gas constant from a Rayleigh number, and put . A uniform magnetic field has no bulk Lorentz force, so hydrostatic equilibrium and the ideal gas equation giveAt the interface, it is magnetohydrodynamic total pressure, not gas pressure alone, that is continuous:Define . The magnetic pressure discontinuity in an isothermal atmosphere therefore producesIn particular, the upper gas is denser at the interface. Both halves have the same scale height , despite their different pressure normalizations.
For the disturbance calculation, write , , where , and . Work to leading order in the prescribed short-vertical-scale approximation: the bulk motion is locally incompressible potential flow, while the isothermal equation determines the equilibrium density jump. Its scale separation and small compressive correction will be checked at the maximizing mode.
Let the interface displacement be and . Using displacement rather than velocity potentials, write and . Incompressibility and irrotational flow give . Decay away from the interface and continuity of its normal displacement fixwith the common horizontal and temporal exponential understood. Both satisfy . Thus the disturbance has vertical extent of order .
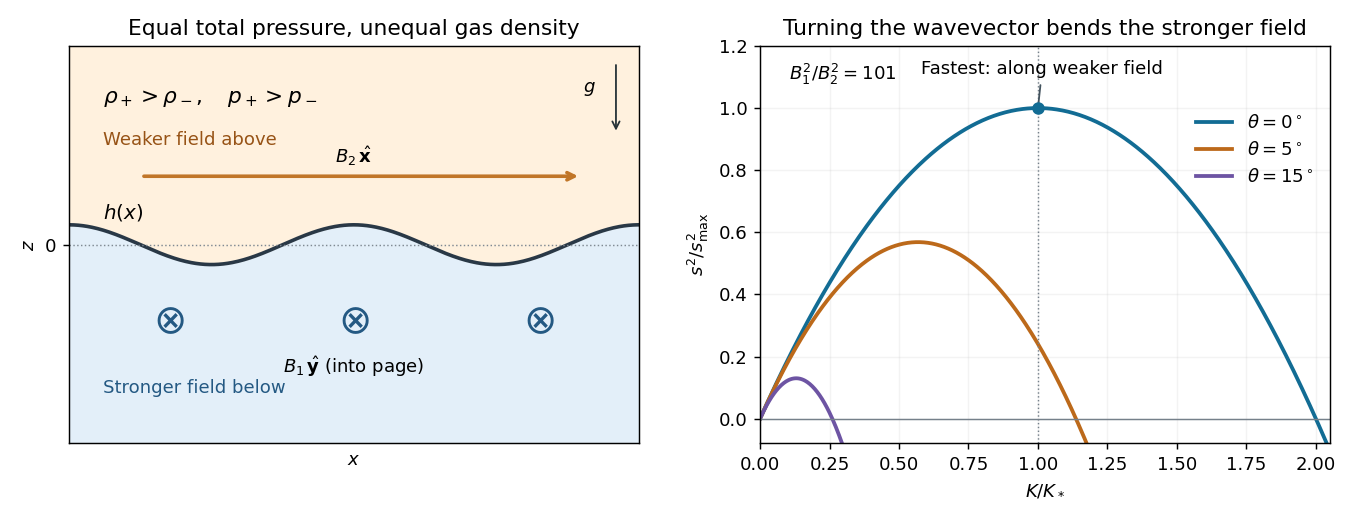
In ideal magnetohydrodynamics, magnetic flux freezing gives for these locally incompressible displacements. If is the total-pressure perturbation, linear momentum isSince on the mode, integration in each half-space yieldsAt the displaced interface, continuity of Lagrangian magnetohydrodynamic total pressure requires . Inserting the two potentials gives the orthogonal-field magnetic Rayleigh-Taylor dispersion relation:The first term is the destabilizing Rayleigh-Taylor instability of the heavier upper gas; the second is stabilizing magnetic tension. A negative right-hand side gives an oscillatory mode rather than growth.
For fixed , the magnetic penalty isIt is minimized by : the wavevector is along the weaker upper magnetic field and perpendicular to the stronger lower field. If , define and . The growth law for this orientation is , a concave quadratic with maximum at . HenceFor this orientation the unstable interval is ; the maximum lies halfway along it.
The localization condition for the fastest orthogonal-field interface mode follows directly from the vertical decay length:This is the condition for on both sides. It also controls the locally incompressible approximation, sinceAcoustic adjustment is then fast compared with growth, so bulk density perturbations are higher-order corrections. If this localization condition fails, the constant-background approximation cannot be used to identify the physical fastest mode.
Finally, the printed assumptions allow . In that case eliminates magnetic tension on both sides and gives . There is no finite maximum growth rate or maximizing wavenumber in the ideal sharp-interface model: growth is unbounded as . The finite maximum and localization formula above therefore require .
In the growth curves, is the angle of the horizontal wavevector from the -axis. The illustrated ratio gives , and shows how even a small rotation toward the stronger magnetic field lowers the maximum growth.
Past exam of the mathematics course of the University of Cambridge 2007 iii Paper 65 2 b Solution Created 2026-10-03 Updated 2026-10-14
Set . Expanding the square root in part (a) givesHence, to first absolute order in ,The high-pressure limit of magnetosonic waves can also be expressed as nonnegative speeds. Retaining the next squared-speed term gives the first relative correction for the slow mode:The exact Alfvén speed along the propagation direction remains .
The fast magnetosonic wave is predominantly an acoustic wave, with velocity almost parallel to and appreciable mass density and gas pressure variations. Its magnetic pressure correction is weak. The Alfvén wave is exactly incompressible, polarized perpendicular to the - plane and restored by magnetic tension.
The slow magnetosonic wave is polarized inside that plane and almost perpendicular to . Indeed, the leading sound speed part of the matrix in (a) annihilates a vector perpendicular to , so only the smaller magnetic restoring force acts on that MHD wave polarization. Its compression is smaller by order , with gas pressure changes almost cancelling magnetic pressure changes. It is often called the pseudo-Alfvén wave MHD wave polarization in this high pressure limit. Thus two distinct almost-incompressible magnetic MHD wave polarizations have the same leading speed, while the third is predominantly sound. For exactly perpendicular propagation the Alfvén wave and slow magnetosonic wave frequencies vanish; for parallel propagation the two transverse magnetic MHD wave polarizations are degenerate.
Past exam of the mathematics course of the University of Cambridge 2007 iii Paper 68 2 ii Solution Created 2026-10-03 Updated 2026-10-14
Keep the background magnetic field, thermal gradient and wavevector fixed as . In particular, is nonzero and of order one. Put and . Multiplying the nonzero-frequency dispersion relation by givesthat is,The sum and product of its two roots areFor large rotation, the sum is of order while the product is independent of . The quadratic therefore has one large root and one small root. More explicitly,The fast frequencies are consequentlywhich are inertial waves at leading order. For nonzero away from the zero-frequency boundary, the rapid-rotation slow magneto-Coriolis branch hasIts frequency is of order , much smaller than the fast inertial wave frequency. Coriolis force balances most of the magnetic and buoyant forces in this slow motion, with inertia supplying only a small correction.
For , the slow wave has real nonzero frequency whenStable thermal stratification has and automatically satisfies this condition. With adverse stratification, , sufficiently strong magnetic tension along the wavevector is needed. If the inequality is reversed, and the slow branch has imaginary frequencies, including an exponentially growing mode. Equality gives a stationary limit, rather than a nonzero oscillation. If , the proposed slow wave degenerates into zero-frequency disturbances: there is no magnetic restoring coupling. The remaining nonzero branch has . These qualifications also explain why zero roots introduced by clearing denominators must not be interpreted as ordinary propagating waves.
Past exam of the mathematics course of the University of Cambridge 2007 iii Paper 68 4 Solution Created 2026-10-03 Updated 2026-10-14
Magnetoconvection is the competition between thermally driven convection and the force and transport of a conducting fluid's magnetic field. An imposed magnetic field resists motions that bend its field lines through magnetic tension, while magnetic diffusion permits slippage. The competition changes the onset threshold, preferred spatial scale, temporal behaviour and finite-amplitude organization. The geometry matters: a disturbance nearly invariant along a horizontal imposed magnetic field can avoid much of its tension, whereas an impermeable layer with a vertical imposed magnetic field cannot generally avoid bending it.
A useful quantitative example is a nonrotating Boussinesq layer of depth , heated from below with temperature drop and threaded by a vertical magnetic field . Let , , denote kinematic viscosity, thermal diffusivity and magnetic diffusivity. In thermal-diffusion units define the Rayleigh number, Prandtl number, magnetic-to-thermal diffusivity ratio and Chandrasekhar number byUse stress-free impermeable boundaries, fixed temperature perturbation zero, and magnetic boundary conditions keeping the field vertical. More explicitly, the normal modes below satisfy at . For a horizontal wavenumber , take , , and put . The linear temperature and resistive induction equation give and . Applying the solenoidal projection to the magnetohydrodynamic momentum equation removes pressure; the magnetic coupling is , and the vertical projected buoyancy has coefficient . Substituting the temperature and magnetic responses gives the vertical-field magnetoconvection dispersion relationThese stated boundary conditions make the single vertical mode exact in this model; other boundaries change numerical thresholds.
For steady marginal convection, set . The threshold curve isThe imposed magnetic field adds a positive penalty. Differentiating with respect to shows that the minimizing wavenumber obeysAt this gives and . With increasing , the root moves to larger because the left-hand side is strictly increasing for . The strong-field wavenumber selection in magnetoconvection limit isThus a strong vertical imposed field raises the steady threshold and selects narrower convection cells. At small horizontal wavenumber the incompressibility constraint makes a given vertical motion require large horizontal displacement and magnetic bending. Increasing horizontal wavenumber reduces this magnetic penalty, but increases viscous and thermal diffusion. Their balance selects the narrow cells. This statement is specific to the vertical-field geometry: wavenumber selection in oblique-field magnetoconvection can instead favour nearly field-invariant motions.
Oscillatory marginality in vertical-field magnetoconvection occurs because magnetic and temperature perturbations need not relax at the same rate. To exhibit the phase balance, substitute with and write the neutral condition asThe imaginary part must vanish because is real. Dividing that imaginary part by givessoA nonzero oscillation consequently requires and a sufficiently strong imposed magnetic field. In this regime thermal diffusion can erase the temperature anomaly faster than magnetic diffusion relaxes bent field lines. The magnetic restoring force can outlast the buoyant anomaly, reverse the motion, and maintain the phase lag needed for oscillatory instability. The real part gives the oscillatory neutral curveOnly its portions with are physical. The first onset is the lower of the minimized steady and admissible oscillatory thresholds; the existence of an oscillatory neutral solution at a given wavenumber alone does not establish that it is first. For example, at fixed and , both minimizing wavenumbers grow like for large , while and with . At those oscillatory minima, the positive order- contribution to dominates its order- negative contribution, so the oscillatory branch is genuinely admissible and becomes the lower threshold. An overstability therefore precedes steady onset in this limit. More generally nonlinear convection can oscillate even when linear onset is steady; the linear calculation is not a classification of every time-dependent state.
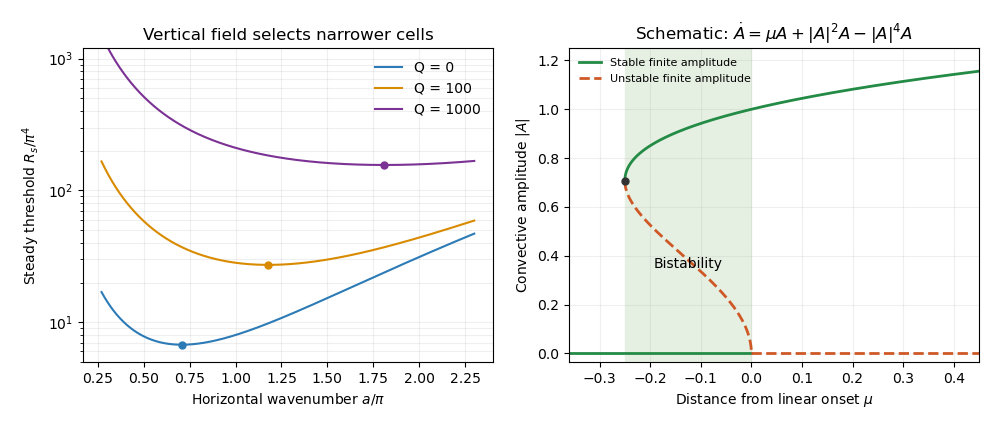


The nonlinear regime introduces a different feedback. The magnetic Reynolds number measures induction relative to diffusion for a finite convective velocity . At large but finite , persistent convection rolls can redistribute magnetic flux. In a two-dimensional incompressible roll, a flux function obeysCirculation repeatedly stretches the flux pattern, building gradients on which even small magnetic diffusivity acts efficiently. Over the flux-rearrangement time this permits flux expulsion: the interior of a vigorous roll becomes weakly magnetized, while magnetic flux is concentrated near its edges. The weak-field interior then suffers less magnetic inhibition and can support broader, stronger convection than the linear narrow-cell prediction for the original uniform magnetic field. Exact zero resistivity would preserve material flux and cannot by itself justify the relaxed flux-expelled state.
The weak interior field also follows from a steady leading-order balance for a coherent two-dimensional roll. Let be its streamfunction and suppose its interior streamlines are nested closed curves with . In the small-diffusivity interior, implies . Integrate the full steady flux equation over the region enclosed by one streamline. Because there, the advection integral vanishes; the divergence theorem then gives . In a regular interior expansion this requires . The normal derivative of has one nonzero sign around a regular nested streamline, so . Hence the leading interior flux function is constant, and its spatial gradient, which gives the two-dimensional magnetic field, vanishes. The mismatch with external flux is accommodated by magnetic boundary layers. This argument assumes the coherent steady roll and a regular interior; it does not prove that every turbulent flow expels flux.
The mean imposed vertical magnetic flux is conserved for horizontally periodic boundaries. In a schematic two-region picture, let a fraction have weak field in vigorous convection and the remainder have field . ThenThe intensified field outside the active cells inhibits surrounding convection. This gives magnetic flux separation: vigorous weak-field patches coexist with strong-field regions whose motion is small or occurs on a finer scale. The redistribution is a consequence of nonlinear induction and back reaction, rather than disappearance of the net imposed flux.
This feedback can permit subcritical magnetoconvection. Infinitesimal perturbations decay below the conductive state's linear threshold because they encounter the full imposed field. A finite-amplitude roll can nevertheless persist by first expelling enough flux to reduce its own magnetic restraint. A sufficient finite disturbance can then switch between the stable conductive state and a convective state, producing hysteresis. A schematic amplitude equation makes the distinction between local linear stability and finite-amplitude persistence explicit:Here measures distance from linear onset; this is an illustrative normal form, not a claim that these coefficients have been derived for every magnetic layer. Writing , the nonzero equilibria satisfyThey appear at a saddle-node bifurcation at . For , the zero state is stable, the lower radial-amplitude branch is unstable, and the upper branch is stable because its radial derivative has sign . Thus finite-amplitude convection can coexist with a linearly stable conductive state below the onset threshold. Large facilitates the flux-expulsion mechanism but is not a universal sufficient condition: geometry, the imposed magnetic field, the capacity to form coherent recirculating cells, and magnetic back reaction all matter. The broad nonlinear cells in weak-field regions can coexist with much narrower cells in magnetically dominated regions, linking the nonlinear flux distribution back to scale selection.
Past exam of the mathematics course of the University of Cambridge 2007 iii Paper 75 1 a Solution Created 2026-10-03 Updated 2026-10-14
Let and . Use normal modes proportional to , so means damping. The linear displacements satisfyFor a nonzero-frequency perturbation, linearizing the ideal magnetohydrodynamic induction equation givesProject both momentum equations with . This removes the pressure gradients. The magnetic tension is already transverse to , and, with , the projected equations areHere uses the ion density, as stipulated. For either of the two independent transverse polarizations, the equal-density ion-neutral Alfvén dispersion relation follows fromIts determinant is . Removing the static neutral-displacement factor givesThe removed factor is a time-independent neutral displacement with no velocity or magnetic perturbation, a relabeling of the homogeneous neutral fluid rather than a fourth physical wave. Direct elimination in the first-order system for gives exactly the same cubic. This also handles the zero-frequency limits without introducing a displacement-label mode.