Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Normal force
Apparent weight 2026-10-14
Apparent weight measures support rather than the gravitational force itself. In an ideal scale model, it is the magnitude of the normal force exerted on the body. A scale calibrated to display mass divides that support force by its calibration value of .
Take upward as positive in a constant downward gravitational acceleration of magnitude . If a body stays in contact with a horizontal scale and accelerates upward at , Newton's second law gives , hence . At rest, . In common free fall, , so despite the nonzero gravitational weight . If the formula would require , ordinary supporting contact cannot realize it: the body loses contact instead.
Bell-clapper loss of contact Created 2026-10-20 Updated 2026-10-25
Let a bell have axial moment of inertia and centre of mass h from its axle. A clapper of point mass m at radius l touches the bell at fixed relative angle . While they remain in contact, the clapper angle from the upward vertical obeys . The contact force opposing increasing angle is . Eliminating the acceleration givesThe first zero on the physical trajectory marks detachment, because a nonadhesive contact cannot support negative normal force. Selecting the correct trigonometric branch is part of the contact problem.
Center of pressure 2026-11-05
The center of pressure summarizes where a distributed normal pressure acts. On a planar contact region in , take a nonnegative pressure field and positive total normal force . Its center of pressure is the pressure-weighted positionIt is a continuous weighted mean, rather than necessarily the point of largest pressure. For discrete normal forces at , replace the integrals by sums. The resulting convex combination places the center of pressure inside the contacts' convex hull, or support polygon.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure (CoP) and Zero-moment point (ZMP), The special case of flat terrain
This definition preserves the torque as well as the resultant normal force. About the origin in the contact plane,A single vertical force applied at gives the same torque. Thus its line of action passes through the center of pressure. Conversely, force-and-torque measurements reconstruct the point throughThe origin and sign convention are part of these equations; moving the moment reference above the contact plane requires the corresponding torque translation.
For an original discrete example, four vertical reactions of , , and act at the successive corners , , and in metres. Their total normal force is , with and . Hence the center of pressure is . A rigid plate on four load cells provides a simple force platform implementation: calibrate the force channels and positions, then test known vertical loads at known locations. Subtracting the unloaded plate's own force and moment removes its contribution when reconstructing the added load. This is a proposed measurement test, not experimental data.
A continuous example shows the inverse problem hidden by this useful compression. On a rectangle of length and width , put and choose profiles independent of :Both profiles are positive on . The added polynomial has zero integral and zero first weighted integral:Thus both profiles give and the same center of pressure , while their peak pressures are and . These are pressure distributions with identical resultant force and center of pressure. For , and , both give despite different local loads. A force platform alone therefore does not identify every local pressure.
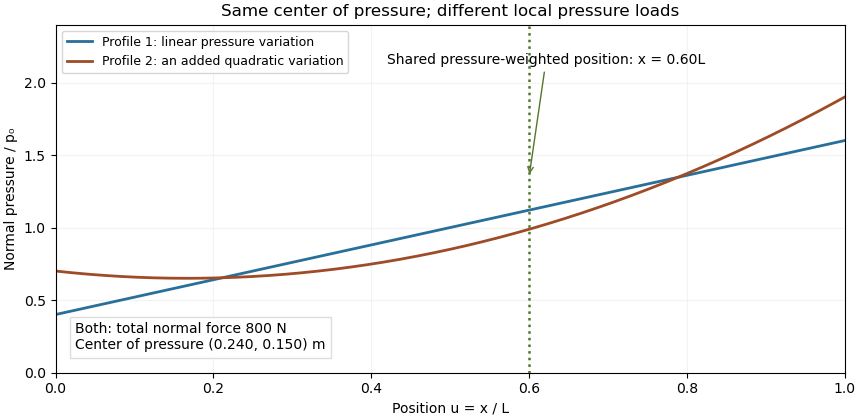

Two limits matter. If , the normal-pressure center of pressure is undefined. At fixed , an absolute moment error changes the reconstructed by , so fixed absolute measurement uncertainty is amplified as a contact unloads. Also, tangential contact forces can leave a residual contact torque at the center of pressure: with full resultant ,Selecting the normal-pressure centroid does not force this yaw torque to vanish.
Under the gravity-only, resting assumptions of support polygon, the center of pressure coincides with the horizontal center of mass projection. During motion it need not. For a planar model driven only by gravity and ground contact forces, at fixed center of mass height and with constant angular momentum about that centre, force and torque balance give . The acceleration term explains why the center of pressure is a contact-force measurement rather than a general substitute for center of mass position.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, equations cop and zmp and their stated constant-height/angular-momentum assumptions
Center of pressure (terrestrial locomotion) 2026-11-05
In terrestrial robot locomotion, the center of pressure is the ground point summarizing the normal load shared by the active contacts. With contact positions and nonnegative normal reactions , its coordinates are the weighted averages and , provided the total normal force is positive. It lies in the current support polygon, but is a contact-force quantity rather than the robot's center of mass position.[ref]
Underactuated Robotics by Russ Tedrake. Highly-articulated Legged Robots, Center of pressure (CoP) and Zero-moment point (ZMP), flat-terrain definition
Force-sensor coordinates matter when reconstructing this point. Suppose a sensor origin lies height above a horizontal contact plane, with parallel coordinate axes. If it reports force and moment , the plane point is located at relative to that origin. Moment translation givesThe ground-plane transformation of a measured contact wrench must therefore precede interpreting moment/force ratios as a contact location.
For an original sensor example, take , force , and measured roll/pitch moments . The reconstructed point is . Ignoring the origin height would instead give . Those millimetre differences are coordinate effects, not a change in the physical pressure distribution.
During motion, the contact point need not equal the horizontal projection of the center of mass. The source's constant-height, negligible-angular-momentum-rate model relates their difference to horizontal acceleration; those assumptions must be established before using that simplified relation.[ref] A robot-foot experiment can compare known applied loads with the sensor's translated force/moment measurements. When approaches zero, reconstruction becomes sensitive to moment error; at zero normal load the normal-pressure point is undefined. A residual yaw couple may remain, as explained in residual contact torque at the center of pressure.
Centripetal acceleration Created 2026-10-06 Updated 2026-10-18
For uniform circular motion of radius and angular speed , the acceleration is directed toward the centre and has magnitude . Writing for the position relative to the centre gives . The required resultant force is ; it may be supplied by a normal force, gravity, or another physical interaction.
Coefficient of kinetic friction Created 2026-10-14 Updated 2026-10-20
The coefficient of kinetic friction is the dimensionless quantity for sliding contact with positive normal force in the ideal kinetic friction model. It characterizes the pair of contacting surfaces and their condition. A constant means the model neglects dependence on contact slip speed; unlike the coefficient of static friction, it specifies a sliding force magnitude rather than a no-slip upper bound.
The ratio compares the tangential kinetic friction magnitude with the perpendicular normal force:Here is the tangential relative velocity defining contact slip. Both numerator and denominator have the same physical dimension, so the coefficient of kinetic friction has no units. It belongs to a contact pair under specified conditions, rather than to one material alone. The coefficient of static friction instead describes the threshold before contact slip; a pull required to start motion cannot be substituted for a sliding measurement.[ref]
University Physics Volume 1 by William Moebs and others. §6.2, “Magnitude of Static Friction” and “Magnitude of Kinetic Friction”, equations 6.1–6.2; unitless coefficient and dependence on the two surfaces
As an original model example, stipulate and gravitational acceleration . An already sliding, nonrotating block of total mass is pulled horizontally across a stationary horizontal surface at constant velocity. With no other vertical force, Newton's second law gives . Zero horizontal acceleration then requires a pulling force . Doubling the total mass to gives and . The force doubles while the coefficient of kinetic friction stays by assumption. These numbers are model predictions, not observations or a calibration for a particular material pair.
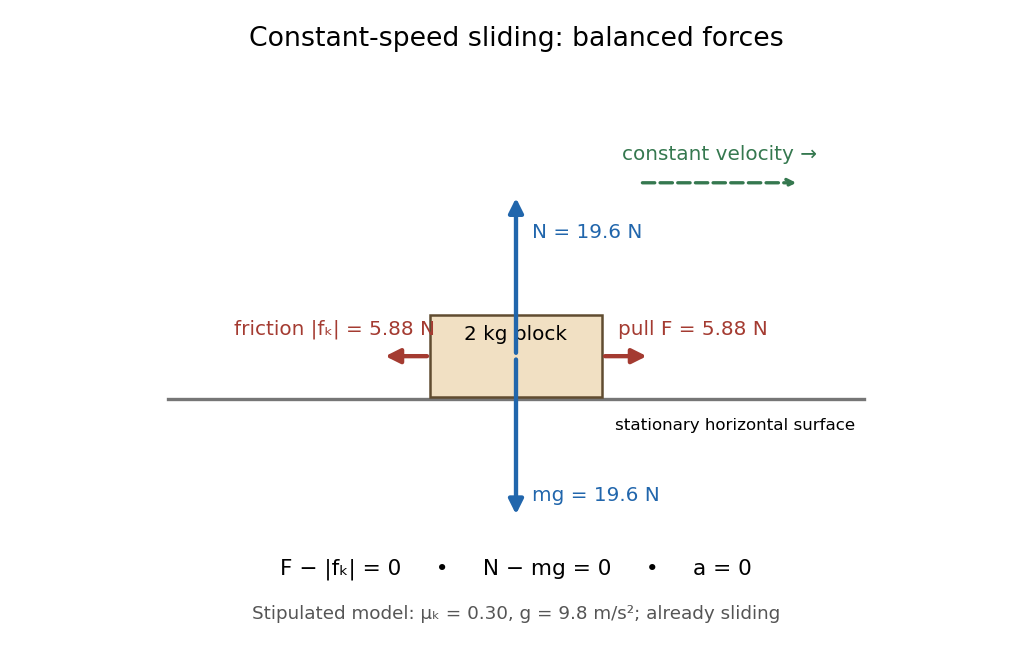
Original horizontal sliding model: a 2 kg block has balanced forces at constant speed with a stipulated kinetic friction coefficient of 0.30
. Details. 
A constant coefficient of kinetic friction is useful because one ratio can summarize many loads, as tested by load dependence of kinetic friction. It is an empirical approximation over a stated range of normal forces, speeds and surface conditions. It implies no universal independence from speed or apparent contact area: a change of face or sliding regime can change the result. Temperature, wear and lubrication are further conditions to report. Newton's second law still applies when the constant-coefficient approximation fails.[ref]
University Physics Volume 1 by William Moebs and others. §6.2, approximate empirical model; small nonzero speeds; exceptions for lubricated surfaces and high speeds; “Atomic-Scale Explanations of Friction”, apparent versus actual contact area
A force gauge reads the pulling force. For horizontal straight-line sliding at constant velocity, its reading equals the opposing kinetic friction magnitude, provided these are the only horizontal forces. For total supported mass , including added loads, , so a mean sliding reading gives . The important readout is the sustained sliding force after the starting peak; the peak belongs to the static friction threshold.
The University of Mississippi's Experiment 6 uses a wooden block on a wooden plane, a triple-beam balance, added masses, and a dual-range 50 N force probe connected through LabPro to Logger Pro. Its procedure calibrates the probe with a load on a hanger, entering the corresponding force in newtons, and measures the block's mass separately. With the plane horizontal, it starts with on the block and pulls horizontally at constant speed. The recorded force trace has a starting peak; the procedure selects the subsequent constant-force interval and takes its mean. It repeats with increments up to added, then plots sliding force against normal force to estimate the coefficient of kinetic friction from the slope.[ref]
Experiment 6: The Coefficient of Friction (University of Mississippi teaching laboratory). Experiment 6, The Coefficient of Friction, PDF pp. 1–2: Equipment, Objectives, Procedure steps 1–7
For a replication, check the gauge's zero with the string slack and its response to known gravitational weights; zeroing alone does not check its scale. Keep the plane level, the pull parallel to it, and the block face and track region consistent. Specify the contacting materials and whether the surfaces are dry, cleaned or lubricated; repeat runs to see whether debris or wear changes the sliding force. Verify constant velocity independently from position versus time, rather than assuming that a flat force trace proves zero acceleration. These are proposed measurement controls, not additional observations from the laboratory writeup. Record the selected interval, variation between runs and gauge resolution as sources of measurement error.
Constraint power 2026-11-05
Constraint power is the rate of actual work done by constraint forces. For particles with Cartesian velocities and constraint forces , the total isIt enters the balance of kinetic energy and, after accounting for conservative applied forces, mechanical energy. An ideal mechanical constraint instead imposes zero total virtual work, , for allowed virtual displacements at fixed time. Those displacements need not be parallel to actual velocities when the permitted geometry moves.[ref]
For a smooth ideal restriction on one particle, write . Differentiation along its motion gives , henceA fixed smooth surface has and zero constraint power. A time-dependent holonomic constraint can have nonzero constraint power even without friction. For example, a bead carried upwards at constant speed on a horizontal smooth wire receives normal force and power , increasing its gravitational potential energy. The drive moving the wire supplies that energy.
Zero total constraint power also does not require zero power on every body. Consider two hanging masses connected by a taut, massless, inextensible string over an ideal massless, frictionless pulley. The shared tension is , and the two endpoint speed magnitudes are . If one mass rises while the other falls, the string supplies powers and : it transfers energy between the bodies while supplying zero net energy to the pair.
With , and , Newton's second law givesAt , the two tension powers are and . Their cancellation leaves gravity's net power, , equal to . This constraint power transfer distinguishes an ideal connection that redistributes energy from an externally driven moving support that adds energy to the chosen system.
Contact slip displacement 2026-11-05
The contact slip displacement is signed relative tangential displacement at a specified contact. For small motions in a fixed local frame, let be a tangential unit vector and let describe the two contacting surfaces. ThenThis scalar product extracts relative motion along the contact. The corresponding relative normal displacement is a separate quantity controlling opening or closure. This local distinction matters for inter-fibre sliding: an entire bundle can move without adjacent material fibres slipping against one another.
As an original local example, take , and . The contact slip displacement is and the relative normal displacement is 0. Adding the same translation to both surfaces changes neither result. Reversing the orientation of reverses the sign of while preserving its magnitude. If the contact frame rotates substantially or different material points enter contact, relative tangential velocity must be evaluated in the current contact frame and integrated consistently; projecting one final global displacement difference onto a final tangent vector is not a general finite-motion formula.
Under the ideal dry-friction model, static friction can transmit tangential force while the local slip rate is 0. Sliding introduces kinetic friction; with constant normal force , its magnitude is , where is the coefficient of friction.[ref]
University Physics Volume 1 by William Moebs and others. §6.2, static-friction bound and kinetic-friction model, equations 6.1–6.2
The accumulated contact slip and the frictional dissipation from contact slip are therefore different from net signed displacement:The second expression follows from integrating the opposing frictional force over each increment of relative sliding; it assumes constant and . For a prescribed out-and-back slip from 0 to and back to 0, the final is 0 but . With stipulated and , the dissipated energy is . Zero net slip does not imply zero frictional dissipation.A simple measurement marks both surfaces close to a maintained contact, images their relative positions while tangential loading is varied, and resolves motion along the local contact direction. Measurement calibration converts image distances to lengths. Marks far from the contact can also move because the strands stretch or the fixtures deform; a grip-travel readout alone does not isolate contact slip displacement. Record both the signed motion and accumulated contact slip when comparing repeated bending cycles of an unbonded material-fibre bundle.
For a block sliding right on a stationary horizontal plane, take rightward acceleration as positive. A gauge reading for a pull at angle above horizontal has horizontal component and upward component . With no vertical acceleration or other forces, Newton's second law givesand thereforeThis inference requires continued contact with and rightward contact slip, so its numerator must be nonnegative. An upward pull reduces normal force; a downward pull, represented by , increases it. The horizontal constant-velocity formula is the special case , .
For the original , model, an upward pull at maintaining constant velocity needsDividing this gauge reading by would give about , rather than : the gauge reads the full inclined force, and the pull has changed the normal force.
Even with a horizontal pull, an accelerating measurement needs the correction: . In the same model, a horizontal pull produces while the block slides right; subtracting recovers the kinetic friction. Dividing the uncorrected reading by instead gives about . Measure acceleration in an inertial frame, along the sliding direction, over the same interval as the gauge reading. These corrections follow from the force balance, independently of whether the resulting coefficient of kinetic friction is constant across runs.
// Target: classical-mechanics.bigb
The effective mass in a normal-contact penalty mode is the inertia seen by one specified relative normal displacement, rather than automatically the total mass of either body. A contact away from a center of mass can excite rotation as well as translation, changing that inertia and the normal contact penalty time scale.
Use independent generalized velocities , a positive-definite mass matrix , and a normal gap whose local velocity is . A scalar normal force produces generalized force . The primary multibody formulation gives this contact-Jacobian velocity/force pairing explicitly.[ref]
Underactuated Robotics by Russ Tedrake. Multi-Body Dynamics, Contact modeling: contact Jacobian and equation with generalized force J-transpose times lambda
At a frozen configuration, the part of gap acceleration caused by that force isIf the scalar is positive, defineThe definition uses a physical normal gap measured in metres and a matching normal force measured in newtons. Arbitrarily rescaling the gap coordinate changes the associated inertia. Constraints must first be accounted for by independent coordinates or the appropriate constrained response.A short normal impulse gives , hence . This supplies a direct interpretation: less effective mass means a larger relative normal-velocity change for the same impulse. At a fixed local configuration, a compressed linear penalty spring of stiffness gives the small-motion estimateIt omits changing contact geometry, other driving forces and damping; the source separately explains why stiff compliant contact challenges numerical integration.[ref]
For two freely translating particles, the relative gap sees , so . This is the reduced mass. Equal particles give ; replacing one by a fixed wall gives instead.
For a planar rigid body above a fixed plane, let its mass be , rotational moment of inertia about its center be , and the contact normal be vertical. A contact a horizontal distance from the center hasFor , and , . At the center it is . With , the off-center angular frequency is , compared with at the center. Using the full mass in both cases misses this rotational response.
Several simultaneous contacts require more than separate scalar replacements. Their matrix generally has off-diagonal terms: a force at one contact changes another contact’s acceleration. With frozen geometry and positive diagonal stiffness matrix , compressed gap perturbations satisfy ; its nonzero modal squared frequencies are those of the symmetric matrix . Coupled normal-contact penalty modes can therefore be faster than estimates treating each contact independently. A proposed verification applies a small known impulse or displacement perturbation at a stated configuration and checks relative contact motion, followed by a timestep convergence study.
At the limiting release height for a solid cylinder, the loop normal force is and the required static-friction magnitude is . Thus diverges near the top, even though both forces vanish there. A finite friction coefficient therefore requires a height above the ideal contact threshold to maintain no-slip rolling throughout. A question imposing rolling but giving no coefficient determines the ideal limiting bound, not a realistic friction-dependent minimum.
Free fall Created 2026-10-05 Updated 2026-10-20
Free fall is motion under gravity alone: there is no supporting normal force, engine thrust or appreciable drag force. In the Newtonian mechanics model, a test particle of mass obeys , hence . The mass cancels. Bodies released at the same position with the same velocity follow the same path in this model, even if their gravitational weights differ. [ref]
https://www1.grc.nasa.gov/beginners-guide-to-aeronautics/free-falling-objects/. NASA Glenn: free-falling objects and the cancellation of mass
A dropped stone is one example; a coasting satellite is another. Free fall does not require motion straight down or decreasing distance to the attracting body. An ideal circular orbit has constant radius while its velocity continually turns under centripetal acceleration. The circular orbit as continuous free fall connects the familiar drop with orbital motion.
Near a surface, treating the gravitational acceleration as constant gives a useful first prediction. Over larger heights, the inverse-square law changes the acceleration during the fall. Radial free fall from rest uses conservation of mechanical energy to account for that change exactly, within the specified Newtonian gravitational field. The contrast matters: the simplest formula is an approximation to a physical model, rather than a law with the same numerical everywhere.
History also makes the idealization tangible. Galileo's Two New Sciences (1638), Third Day, Theorem II, derives distance proportional to the square of time for uniformly accelerated motion from rest; its first corollary gives successive distances in the ratios over equal time intervals. This is a kinematic statement, predating the gravitational inverse-square law. [ref]
https://galileoandeinstein.phys.virginia.edu/tns_draft/tns_160to243.html. Galileo, Two New Sciences, Third Day, Theorem II and Corollary I; Crew and de Salvio's 1914 translation, pp. 174–176
On Apollo 15's final lunar surface excursion, David Scott released a hammer and a feather together. The near-vacuum removed the large difference in drag force familiar on Earth. NASA's report describes their arrival together within the accuracy of the release; this demonstration illustrates the free fall prediction without establishing infinite experimental precision. [ref]
Friction 2026-10-14
Friction is a contact force tangent to the surfaces. Kinetic friction opposes contact slip; static friction maintains contact without contact slip, including rolling without slipping. The perpendicular contact component is the normal force. These two components answer different questions: how strongly the surfaces press together, and how strongly they resist sliding past one another.
The ideal Coulomb dry-contact model combines a bound on static friction with a sliding law for kinetic friction. Its parameters are the coefficient of static friction and the coefficient of kinetic friction; constant coefficients are an empirical approximation, rather than a consequence of Newton's laws of motion. Surface condition matters, and the static coefficient need not universally exceed the kinetic coefficient. [ref]
The model's historical setting was practical machinery: Coulomb's Théorie des machines simples investigated friction and the stiffness of ropes. The Académie's bibliography records its 1781 prize and its appearance in volume 10, pages 161–332, of the Recueil des savants étrangers. [ref]
https://www.academie-sciences.fr/pdf/dossiers/Coulomb/Coulomb_pubd1.htm. Académie des sciences: Coulomb's published works
Frictional dissipation from contact slip 2026-11-05
Frictional dissipation from contact slip is the irreversible loss of mechanical energy associated with relative sliding at a contact. In the ideal kinetic friction model, friction opposes the local slip velocity and has magnitude , with nonnegative coefficient and normal force . Its dissipated energy isThe work calculation and the distinction between signed and accumulated motion are developed in contact slip displacement. The kinetic-friction force law is an ideal physical model, rather than a universal description of every interface.[ref]
An original two-stage example keeps the loading history explicit. Let . Slide forward while , then backward while . The final signed slip is , the accumulated contact slip is , andThe two stages contribute and . Using the unweighted mean of the two normal loads would instead give ; the correct weighting follows sliding distance.
A physical measurement records relative motion close to the contact together with tangential force and normal loading. Integrating the opposing tangential force over the resolved sliding increments estimates the lost mechanical energy under the stated model. Force transmitted during ideal sticking, where local slip rate is zero, contributes no slip dissipation in that model, even if other parts of the apparatus deform. Grip travel and fixture mechanical compliance therefore must be distinguished from local sliding.
Friction angle 2026-10-20
The limiting angle between a contact resultant and the compressive normal force when static friction obeys . Resolving the resultant gives , so admissible contact forces lie within a cone of half-angle about the inward normal. A contact-force magnitude is generally , distinct from N.
Frictionless sliding ladder 2026-10-24
For a uniform slender ladder of length sliding while touching a smooth wall and floor, use its angle from the vertical. Its centre of mass is and its central moment of inertia is . Hence the Lagrangian is , and its Euler-Lagrange equation is . The contacts are physically possible only while their normal forces are nonnegative. If released from rest at , energy conservation gives , and the wall force becomes . Contact is lost at , after which the constrained equation no longer describes the motion.
Gear mesh active-contact set 2026-11-05
The gear mesh active-contact set identifies the tooth pairs that carry positive compressive normal force in a specified contact model. It is not simply the set of geometrically overlapping teeth from the gear contact ratio. A pair touching at zero force is excluded under the positive-force convention used here.
For unilateral linear contacts,Here is the initial gap, the pair stiffness, and the common approach. For a proposed nonempty set , force balance givesA gear contact-set consistency check then verifies for included pairs and for excluded ones. Solving the linear equation without this check can retain a negative force or omit a contact that should engage.
An original three-pair example uses stiffnesses and gaps . At total load , the set gives approach and forces . This set is consistent.
At , keeping only those two contacts would give approach , beyond the third gap. Including all three instead givesand forces approximately , which sum to . The third gear tooth engagement threshold occurs at total load .
Within a fixed active set, gear mesh tangent stiffness is the sum of its pair stiffnesses. At a transition, force can remain continuous while that derivative changes. For positive total load the scalar force law is strictly increasing after the first contact, giving a unique approach in this model; the unloaded state need not specify one unique separation.
Real deformation, local contact nonlinearity and dynamics can require more than one common-approach coordinate. A primary NASA analysis coupled tooth stiffness with dynamic-load calculations over contact position and speed.[ref]
Predicted Effect of Dynamic Load on Pitting Fatigue Life for Low-Contact-Ratio Spur Gears by David G. Lewicki. Summary and Introduction, printed p. 1, stiffness–load iteration and contact-position dependence
The active-set calculation is an explicit quasistatic model, not a substitute for that fuller mechanical description. Gravity components on an inclined plane 2026-10-18
Choose a unit vector pointing downhill and a perpendicular unit vector pointing outward from the inclined plane. The gravitational weight points vertically downward. Its scalar projections onto these directions giveThe angle between the downward vertical and the inward normal is : the inward component uses cosine, and the downhill component uses sine. These are two components of one force. They replace its vertical arrow in a component calculation; adding them to that same arrow would count gravitational weight twice.
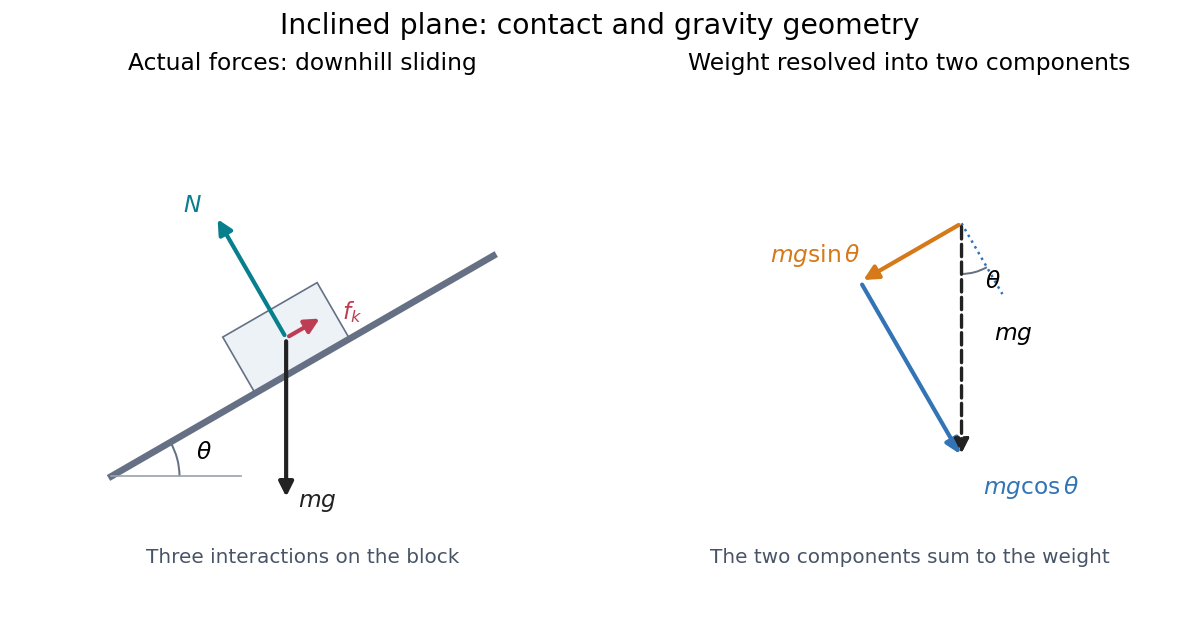

Continued contact with a stationary straight inclined plane gives zero perpendicular acceleration. The perpendicular component of Newton's second law therefore givesThis is why the normal force generally differs from : it balances the inward component, rather than the whole gravitational weight. An extra lifting force, a curved surface, or motion of the support would require a new perpendicular balance.[ref]
6.2 Friction. University Physics Volume 1 by William Moebs and others; “Friction and the Inclined Plane”, Example 6.11 strategy and Figure 6.14; perpendicular balance and
The same geometry explains the ramp's usefulness. A frictionless block pulled uphill at constant velocity needs a parallel force . Travelling a distance raises it through height , so the pulling work is , its gain in gravitational potential energy. The smaller force costs a larger displacement; the work-energy theorem keeps the accounting consistent.
Inclined plane Created 2026-10-14 Updated 2026-10-18
An inclined plane is a flat surface tilted through an angle above horizontal. A ramp exchanges a smaller lifting force for a longer travel distance; for a released body, it reduces the downhill component of gravitational weight and makes the resulting acceleration easier to measure. Its simplest dynamical model is a nonrotating block on a stationary, rigid surface, with constant mass , uniform gravitational acceleration of magnitude , and . Assume continued contact, negligible drag force, no tipping, and no applied pull. The only forces are gravitational weight, the normal force, and any tangential friction.
The central distinction is between a block resting on the inclined plane and one already sliding. Static friction supplies the force needed to maintain rest, up to its bound; kinetic friction has a prescribed magnitude in the ideal constant-coefficient model. These laws are empirical approximations whose range depends on the contacting surfaces.[ref]
6.2 Friction. University Physics Volume 1 by William Moebs and others; “Magnitude of Static Friction” and “Magnitude of Kinetic Friction”, equations 6.1–6.2; empirical-law limitations before Example 6.10