Original solutions to the released 2015 paper. [ref]
https://www.whatdotheyknow.com/request/natural_science_tripos_physics_e_2/response/2340776/attach/2/FOI%202023%20399%20Zahid%20materials.pdf?cookie_passthrough=1#page=34. Original public PDF, physical pages 34–46; the blank second side is retained in this physical numbering
Measure displacement from each arrangement's gravitational equilibrium. The series and parallel spring stiffness follows by adding forces or extensions. In the parallel arrangement the two spring forces change by each, giving equivalent stiffness . In series the common force extends each spring by , so total extension is and the equivalent stiffness is . HenceThe corresponding angular frequencies are . gravity shifts the equilibrium extensions but does not alter the small-oscillation stiffness of these ideal linear, massless springs.
For a circular orbit, . The relation for circular orbital speed from surface gravity eliminates the planet's gravitational parameter: . The orbital radius is m, soThis is about 7.4 km/s, under the circular-orbit and spherical-Earth approximation. Using surface unchanged at orbital height would overestimate the centripetal acceleration; its role here is to determine .
In the stipulated constant-speed model, the Earth-frame speed is m/s. The Earth and Moon are stationary endpoints in this model, so their Earth-frame separation is the proper length. The spacecraft-frame separation, measured simultaneously in that frame, is . ThusThe spacecraft-frame distance is shorter by about 4.2 mm. This compares simultaneous endpoint measurements in two frames, not the coordinate difference between a launch event and an arrival event. The small-speed length contraction estimate also avoids numerical cancellation when evaluating the tiny contraction.
Adjacent slit contributions have phase difference . The six-slit amplitude is a geometric sum . The first zero away from the central maximum occurs at , where the denominator is nonzero. ThereforeThere is a matching zero at the negative angle. This is the first minimum of a finite slit array, rather than the much larger principal-order angle or a single-slit envelope minimum. The slits are stipulated sufficiently narrow for that envelope not to set the first zero.
Using metres and SI viscosity, the pressure difference is Pa and the central flow estimate isIf the quoted uncertainties are independent standard uncertainties, the pressure-difference uncertainty is Pa. First-order propagation givesHenceThe radius sensitivity of Poiseuille-flow uncertainty comes from the fourth-power dependence on radius. If the quoted errors instead mean independent worst-case bounds, the first-order absolute fractional bound is , giving approximately m³/s. That conservative bound and the standard uncertainty result are different conventions, not interchangeable errors. The supplied flow model presumes a Newtonian fluid and laminar flow that is fully developed; no density is given for an independent Reynolds-number check.
The dimensions are , and . Equating exponents in yieldsThus the model has . Its common dimensionless factor cancels in the ratio:They are nearly equal within this capillary-wave model. The assumed power law omits gravitational restoring forces and finite-depth effects; dimensional analysis cannot establish those omissions for an arbitrary real surface wave.
An impulse is , giving . For a short localized impulse at displacement from the centre of mass, the angular impulse is ; for a changing lever arm use its instantaneous value inside the integral. For a uniform solid sphere with volume density , direct integration about the axis givesTake forward translation and forward-rolling clockwise spin as positive. Neglect the table's tangential impulse during the much shorter cue impact. Immediately afterwards,The bottom contact point has slip velocity . The cue height for immediate rolling is therefore .
For the impulse-driven slipping-to-rolling transition of a sphere at an arbitrary admissible impact height, let be the signed friction impulse accumulated before slipping ends. Translation and spin then obey and . Impose and eliminate :This expression handles both sliding directions. If , the contact point slips forward and friction slows the centre; if , excess spin makes it slip backward and friction accelerates the centre. friction still dissipates total mechanical energy. For , , so the slipping time is . Its duration depends on friction, while the final speed does not. With zero friction no slipping-to-rolling transition occurs unless rolling was present from the outset.
Newton's first law identifies inertial frames in which a force-free body maintains constant velocity. The second is for a closed system; for fixed mass it becomes . The third gives equal and opposite pair forces. Summing the second law over a closed collection cancels internal force pairs, so total momentum is conserved when the resultant external force vanishes. A rocket alone is an open variable-mass subsystem, so one must include the momentum carried by exhaust before applying this reasoning.
Choose downward velocity as positive and write . During , exhaust mass leaves downward with speed in the surface frame. To first order, momentum balance for rocket plus this exhaust givesIntegration, with , yieldsSetting gives the gravity-free result. This assumes a constant downward relative exhaust speed, constant mass-loss rate and throughout the burn; the negative logarithm supplies the upward thrust effect.
Height satisfies . Put . Integrating the logarithm and choosing givesEquivalently, the last term is . Differentiating either form recovers and checks the sign.
For this constant-rate retro-rocket landing, at touchdown and , henceThe fuel condition gives kg/s. Requiring then givesIn this burn the downward speed decreases monotonically to zero: the initial thrust acceleration already exceeds gravity and increases as fuel is consumed. The result is the idealized vertical landing, without atmospheric drag, changing gravity or a separate terminal burn phase.
For a particle of rest mass , and , with . The low-speed expansion is , separating invariant rest energy from the nonrelativistic kinetic energy term.
Conserve the total laboratory energy and momentum at coalescence: and . Since , the combined particle moves at . Its rest mass is . The incident particle is not of mass : its stated energy and momentum imply . ThusThe extra is internal rest energy retained by the composite after a perfectly inelastic collision; total energy and four-momentum are conserved, while the sum of individual rest masses need not be.
The composite's Lorentz factor is . For a rest-frame lifetime , the corresponding laboratory time is and its travel distance isIf denotes a mean radioactive lifetime, this is the mean flight distance, not a fixed distance for every decay. The separate frame diagrams below use the common positive collision axis.
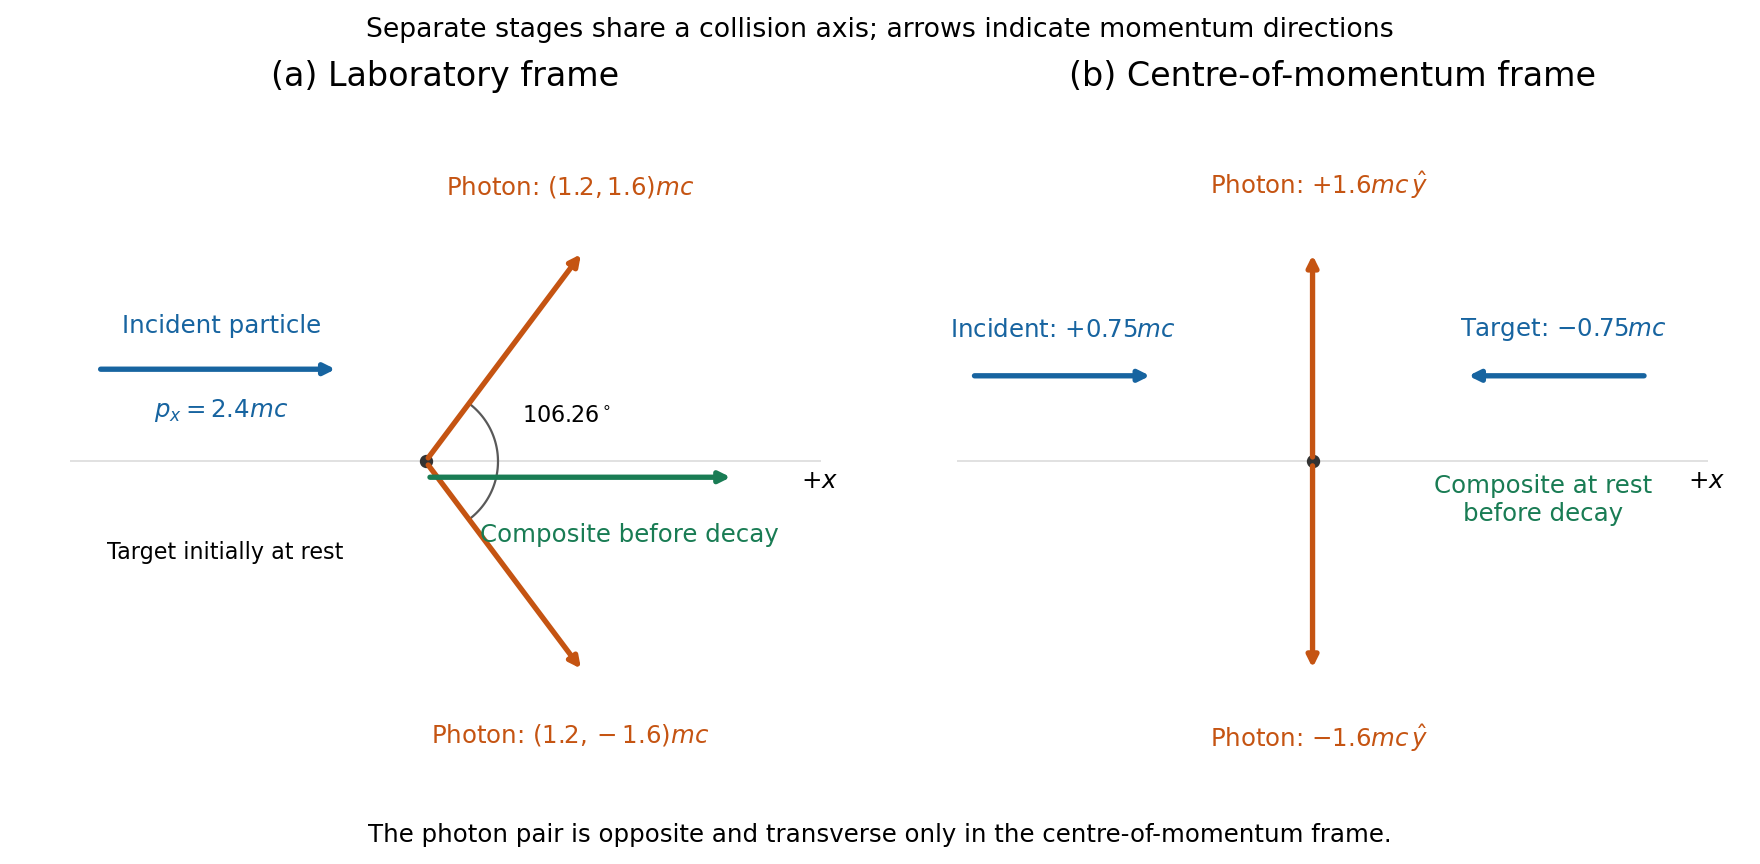
Original momentum-direction diagrams for the laboratory and centre-of-momentum frames, with equal-energy photons and the composite at rest in its own frame
. Details. In the laboratory frame the incoming particle and the composite move along , while the target is initially at rest. In the equal-energy two-photon decay of a moving particle, zero total transverse momentum makes the two photon directions symmetric about . Each photon has energy and momentum magnitude , so longitudinal momentum conservation gives . ThereforeTheir momenta can be written . The opening angle is not in this frame, because the parent carried nonzero total momentum.
Boost along at into the centre-of-momentum frame. The composite is stationary. The incoming particle has , while the target has . After decay the two photons have energies and opposite momenta.
Equal laboratory photon energies require the rest-frame photons to have zero momentum component along the boost: must be equal for two opposite photons. Their directions are therefore and in the centre-of-momentum diagram, perpendicular to the incoming collision axis. Boosting those transverse photons gives exactly the laboratory momenta in part (a). A stationary composite has no direction-of-travel arrow in this frame.
For the supplied linear meter model let and . If the applied step is , the settled deflection is . An underdamped response overshoots and rings about that value; a critically damped response reaches it monotonically without ringing; an overdamped response is also monotone from these initial conditions but has a slower final approach. The original plot uses the common final value and natural-frequency time scale.
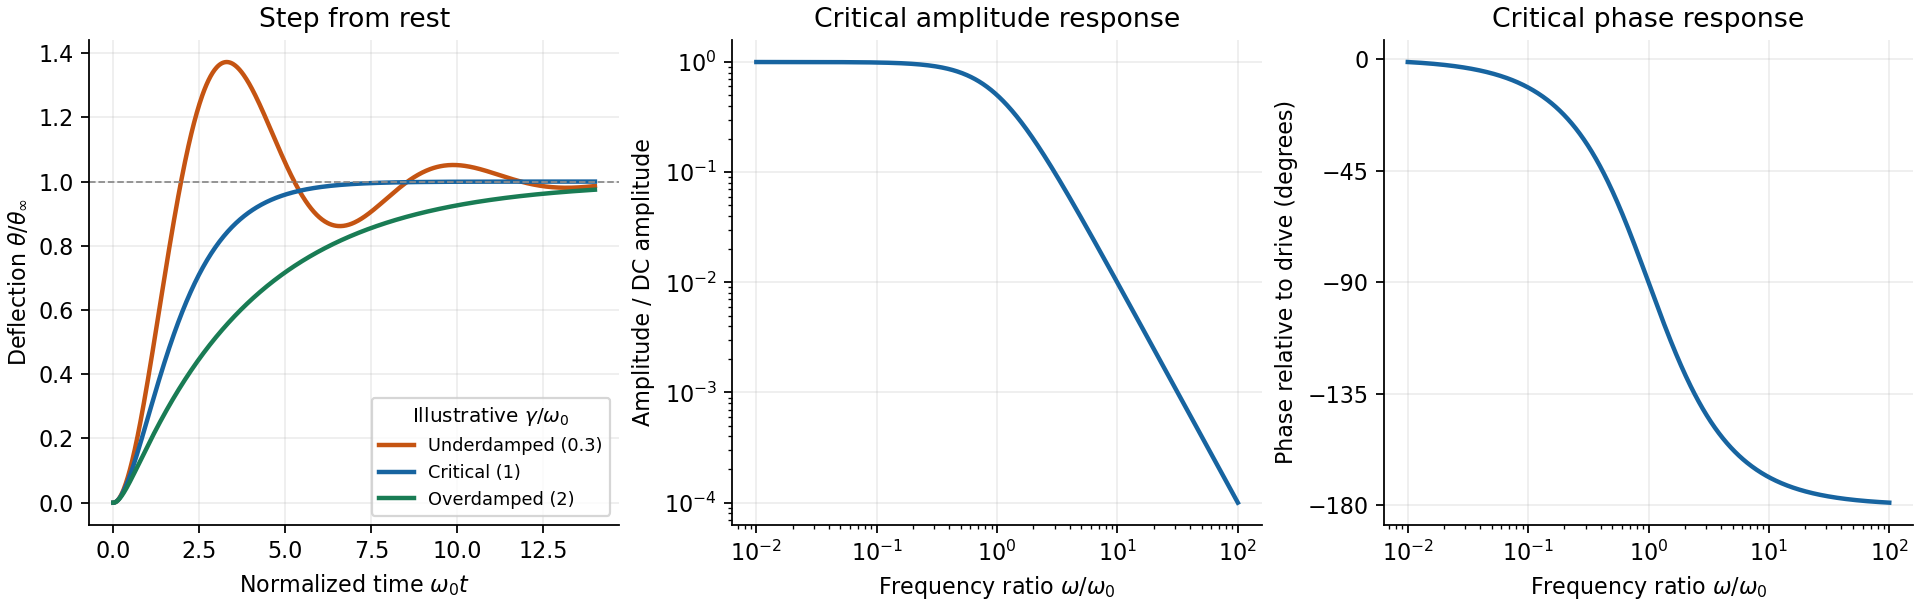


The critical step response of a galvanometer has and repeated homogeneous root . Apply to the general constant-force solution to obtainIts derivative is , with the sign of the step. It is the fastest nonoscillatory response within this second-order family at fixed , avoiding a needle that repeatedly crosses the reading or an unnecessarily slow overdamped settling.
For sinusoidal drive choose phasors. Writing , the response amplitude isFor positive , choose the continuous lag branch from zero to as frequency increases; an ordinary single-argument arctangent without the quadrant would give the wrong high-frequency phase.
For the critical galvanometer transfer function, the denominator factors as . ThusFor , the meter follows the quasi-static deflection with a small lag . For , its amplitude is and its lag approaches .
The stated components give s⁻¹ and, if critical, rad/s, or Hz. At 50 Hz, rad/s andThe needle barely responds compared with its DC sensitivity and its mean deflection for a pure sinusoid is zero in this linear model. It is unsuitable for directly measuring 50-Hz amplitude or RMS current without an additional rectifier or another readout method. The calculation treats as the stipulated torque/back-emf coefficient of the given equation; it does not infer an unprovided winding geometry.
Use phasors. The relation gives . The three branches form a parallel RLC circuit and share the source voltage. The source-current phasor and its real time dependence areConsequently its amplitude is and its phase relative to the voltage is . At low frequency it is inductive and lags toward ; at high frequency it is capacitive and leads toward . The ideal amplitude diverges at either extreme and has a finite minimum between them; real component losses and source electrical impedance limit those asymptotes.
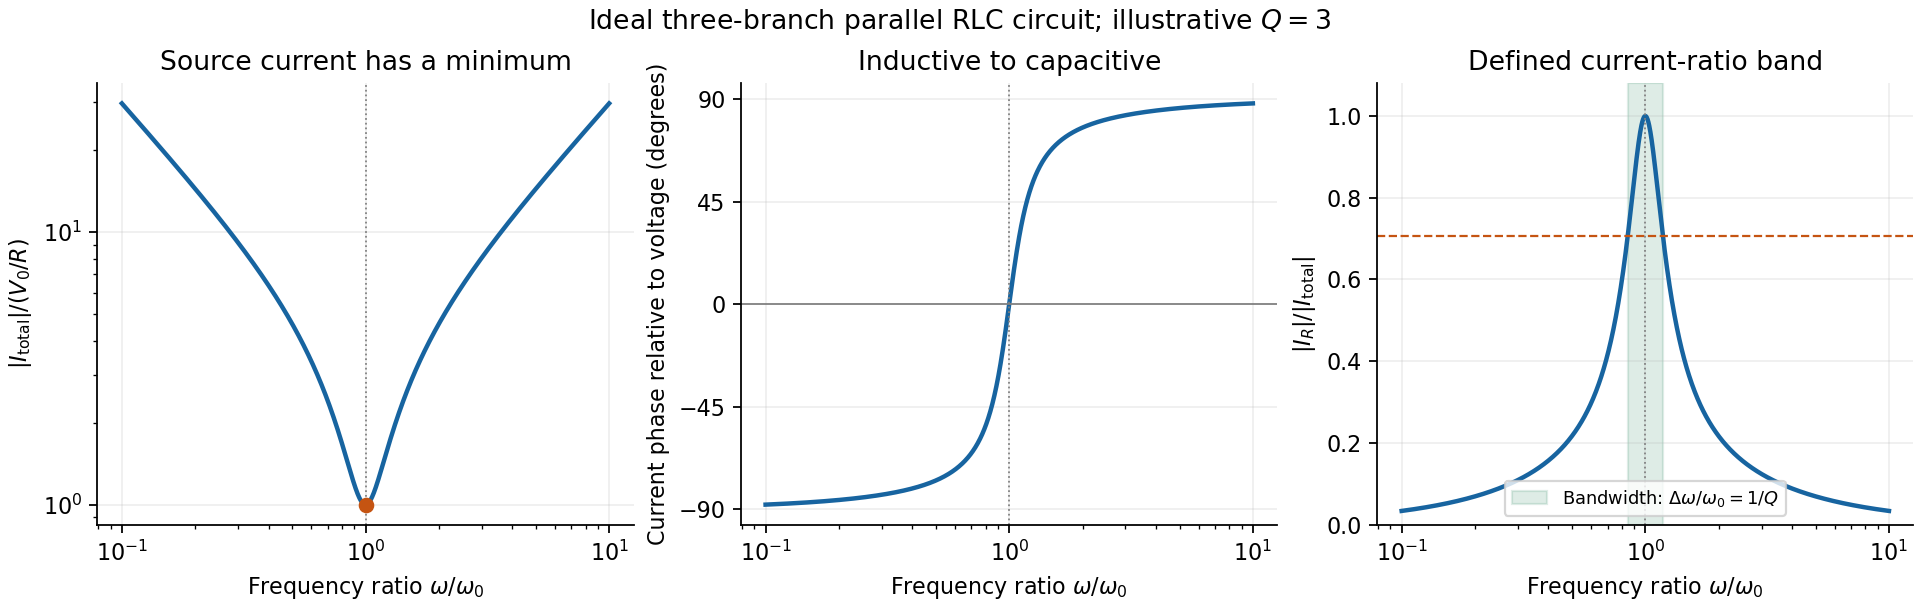
Original normalized source-current amplitude, phase and resistor-to-source-current ratio for an illustrative ideal parallel RLC circuit
. Details. 
Zero phase requires cancellation of electrical susceptances:The inductor and capacitor currents are nonzero, equal in magnitude and opposite in phase, while the resistor supplies the in-phase source current. energy oscillates between the reactive elements; dissipation occurs in the shunt resistor. A source-current maximum would describe a different, series-resonant circuit.
The specified ratio isIt exceeds when . Define and . The two positive endpoints are , soThe endpoints have geometric mean . Increasing the parallel resistance reduces dissipative loading and narrows this band, in contrast with increasing the resistance of a series RLC circuit. Equivalently, , with and . The parallel RLC bandwidth here belongs to the explicitly defined current ratio, not a half-maximum rule applied to a source-current peak that does not exist.
Here is potential energy, is the stationary state's total energy, and is its spatial probability amplitude. The wave function has time factor ; is a position probability density for a normalized state. Stationary plane-wave scattering solutions are idealizations described by probability-current ratios, or components of a normalizable wave packet.
Above an upward step, a classical particle is fully transmitted with reduced speed. Quantum mechanically the abrupt wavelength change generally produces both reflected and transmitted amplitudes even though both regions are classically allowed. With unit incident amplitude and no wave arriving from the right,The reflected component has signed wavevector and the same wavenumber magnitude as the incident component. A finite potential jump with constant mass and no delta interaction requires continuity of and :The probability current gives probability reflection and transmission and , with . The amplitude may exceed one without violating conservation of total probability, because the transmitted group speed is smaller.
For , let . The bounded right-hand solution is , an evanescent wave tail with amplitude penetration scale . It carries no outgoing probability current in an infinitely long forbidden half-space, so reflection is total. This differs from transmission through a finite potential barrier, where a second boundary can support quantum tunnelling.
For a downward step, replace by . The same boundary conditions give a nonzero negative , corresponding to a reflected amplitude with phase reversal. If reflection were forbidden, would require both and , impossible for a nonzero step. Reflection therefore does not require a classical potential barrier; the discontinuity of wavenumber mismatch is enough.
For the specified electron energies, , so the requested amplitude coefficients areThe corresponding probability coefficients are approximately and . electron mass cancels from these ratios; there is no need to invent an additional material effective mass.
For a flexible uniform string with linear mass density and tension , dimensional analysis gives and hence . The small-slope force balance fixes the factor to one:Here has units kg/m, not the volume-density units used for a bulk fluid. The phase moves along the string at , while a material point moves transversely with . Its maximum speed is , which is not the phase velocity. Small slope makes in this model.
The kinetic energy and extra elastic energy of a segment areThe second expression follows from extra length against the pre-existing constant tension. Time averaging a harmonic wave gives and . Therefore
At the driven endpoint the string pulls along its local tangent into , with vertical component for small slope. The point exerts the opposite force on the string, so the driven-string endpoint power isFor the outgoing wave , at the derivatives are and . Thus andThe energy flux of a transverse string wave follows by combining the energy density and flux , which satisfy . For a pure right-going nondispersive wave, even instantaneously. energy is transported with the wave; a material string element merely oscillates about its unperturbed position.
In the Lorentz law, is signed electric charge, and are the electric and magnetic fields at the bead, and the velocity in is its full laboratory velocity. Here . Since and ,The tangential component integrated around an instantaneous circle of nearly fixed radius givesThis is the stated tangential circulation work expression in the limit. It is tangential circulation work. The tangential circulation work versus particle work distinction matters because the bead actually follows an expanding spiral. The radial displacement may be small, but its force is proportional to , so its power is of the same order as the tangential power. In factThe cancellation expresses the fact that magnetic forces do no work. Ignoring radial work while retaining the first-order tangential effect would incorrectly conclude that a magnetic field supplies net particle energy.
The electric field giving the same tangential force would be . This is a force-equivalent field for the moving guide, not evidence that a real circulating electric field has appeared in the laboratory merely because the loop expands in a static magnetic field. An electromotive force is the tangential driving-force circulation per unit charge, with units of energy per charge. For a material circuit moving with local velocity ,Orient the ring counterclockwise with positive normal . Its flux is , so . The tangential circulation therefore givesIt is the motional term that matters here. For a fixed loop, the circulation of the actual electric field instead follows the partial time derivative of the magnetic field. The distinction between moving-wire magnetic forces and induction in a stationary loop is essential to the flux rule.[ref]
For the magnetic power balance on an expanding circular guide, the guide must supply an additional inward reaction opposing the radial magnetic force. With radial guide speed , this contribution to its power on the bead is , equal to the tangential magnetic power. The radial magnetic power is positive by the same amount, so the total magnetic power still vanishes; the mechanical exchange is associated with the moving mechanical constraint.
If “the ring's work” is meant as its full work on a finite-mass bead, the source statement needs a further qualification. For a frictionless bead of mass with constant imposed radial speed, its radial acceleration is , so the complete radial guide reaction and power areThe first term is present even when and describes the familiar change of tangential kinetic energy on an expanding guide. The requested is exactly the additional magnetic-field-dependent term, not that full reaction power. No bead mass or extra agency fixing is supplied, so it would be unjustified to assign a numerical total mechanical power or silently discard its centripetal contribution.
An inverse-square point-source field has constant flux through enclosing spheres because their area grows as . In electrostatics, Gauss's law is , or . For a spherical charge distribution, rotational symmetry makes the exterior field radial and constant in magnitude on a concentric sphere, giving . Symmetry is needed to take the field outside the surface integral; Gauss's law alone does not make an arbitrary charge distribution spherical.
For gravity the corresponding relations are and . A spherical mass has exterior field . Inside a uniform sphere, , so . Inside an empty spherical shell the enclosed mass is zero and symmetry gives zero field. These examples distinguish an inverse-square exterior field from a field inside distributed matter.
The law also treats other symmetries, but their field-distance dependence differs: an infinitely long line charge has cylindrical rather than spherical spreading and a field. Flux conservation and geometry must both be used, rather than assuming every Gaussian surface leads to an inverse-square answer.
A time-independent conservative force defines a conservative vector field on a domain when the work between two points is independent of path, equivalently when every closed-path work integral vanishes. Define a potential energy by and . The additive constant is arbitrary; only differences affect work. A vanishing curl is necessary, and is sufficient on a simply connected domain under the usual smoothness assumptions. Local zero curl by itself need not guarantee a single-valued global potential on a domain with holes.
For a test mass outside a point or spherical mass, with zero at infinity reproduces the inward gravitational force. Near a surface with approximately uniform downward gravity, when increases upward. A linear spring has . In electrostatics the electric potential is energy per unit charge, so and ; potential and potential energy have different units and roles.
For motion under a time-independent conservative force, . nonconservative forces change the mechanical energy by their work, and an explicitly time-dependent potential can exchange energy with the external agency changing it. A time-varying magnetic field can give a circulating electric field, so not every electric field is electrostatic or conservative. Conversely, zero magnetic work on a charge does not turn a velocity-dependent magnetic force into an ordinary position-potential force.
For a test particle outside a spherical central mass, the gravitational force is central, so angular momentum is conserved and the orbit is planar. With specific angular momentum and specific orbital energy , the radial effective potential combines attraction with the centrifugal barrier. Its nonradial solutions are conic sections:For nonzero , negative energy gives an ellipse with , zero energy a parabolic Kepler orbit and positive energy a hyperbolic Kepler orbit. The circle is the special case . Exactly radial motion is a separate zero-angular-momentum case and may hit the central body; a mathematical point-mass trajectory is not automatically a physically noncolliding orbit.
Conservation of gives constant areal velocity , so equal areas are swept in equal times. For a bound ellipse of semimajor axis , and . A circular orbit has speed , while the minimum local escape speed is , obtained by setting the total energy to zero. These are the test-mass two-body results: a comparable second mass requires the relative-coordinate gravitational parameter , and nonspherical structure or drag can perturb the conic and its conserved quantities.
In SI units, with microscopic charge density and current density , Maxwell's equations can be writtenThe first relates electric flux to charge. The second states that the net magnetic flux through a closed surface is zero. Faraday's law relates electric circulation to changing magnetic flux. The Ampère-Maxwell equation includes both conduction current and displacement current; the latter is essential to time-dependent fields and local charge conservation.
For fixed contours and spanning surfaces, the integral curl equations are and . For a moving material contour the first must include the motional force term; its total emf is . This prevents confusing a changing circuit area with a partial time derivative of a static magnetic field.
Taking the divergence of the Ampère-Maxwell equation and using electric Gauss's law gives . In a source-free vacuum, combining the two curl equations gives , and similarly for , predicting electromagnetic waves of speed . The Lorentz force law then specifies how these fields act on a charge. Macroscopic matter descriptions may instead use and with free sources and constitutive relations; those should not be silently mixed with the microscopic-source equations above.
Articles by others on the same topic
There are currently no matching articles.