A test particle is an idealized body whose own fields and effect on its environment are negligible. Its motion probes an externally prescribed field. A gravitational test particle follows a timelike geodesic when nongravitational forces are absent; appreciable self-gravity requires a more complete treatment.
Treating a moving body as a test particle neglects its effect on the externally prescribed field. For a small meteorite moving near a planet, permits neglect of the planet's recoil and replacement of the relative two-body gravitational parameter by . This is separate from neglecting drag or assuming a Newtonian gravitational field.
A trajectory approaching a nondegenerate unstable maximum of its potential energy has a logarithmically divergent period.
Simple harmonic motion is motion in which the acceleration is proportional to the displacement from equilibrium and points back towards it:Here is measured from equilibrium, and is the constant angular frequency. For a point mass attached to an ideal spring, Hooke's law gives the restoring force , with stiffness , and Newton's second law yields . The minus sign matters: for the force is negative, and for it is positive. A restoring force need not oppose velocity; on the return towards equilibrium it increases speed.
The general solution isThe amplitude and oscillation phase encode the initial conditions. We use for the oscillation period to distinguish it from kinetic energy . For , the oscillation period is independent of amplitude, the property of isochronous harmonic motion. At the body remains at equilibrium. [ref]
https://ocw.mit.edu/courses/8-01sc-classical-mechanics-fall-2016/mit8_01scs22_chapter23.pdf. MIT mechanics, Chapter 23, sections 23.2 and 23.3
Choose , , and release the mass from rest at displacement . Then , , and . Writing time in seconds,At the velocity vanishes, but the acceleration is : a turning point is not a state of rest that persists. At , the body crosses equilibrium with velocity and zero acceleration. At it reaches the opposite turning point, .
Taking potential energy zero at equilibrium, the same solution givesAt each turning point all mechanical energy is potential energy; at each equilibrium crossing it is kinetic energy. Both repeat twice during one complete position cycle because squaring removes the sign. At , for example, each contributes .
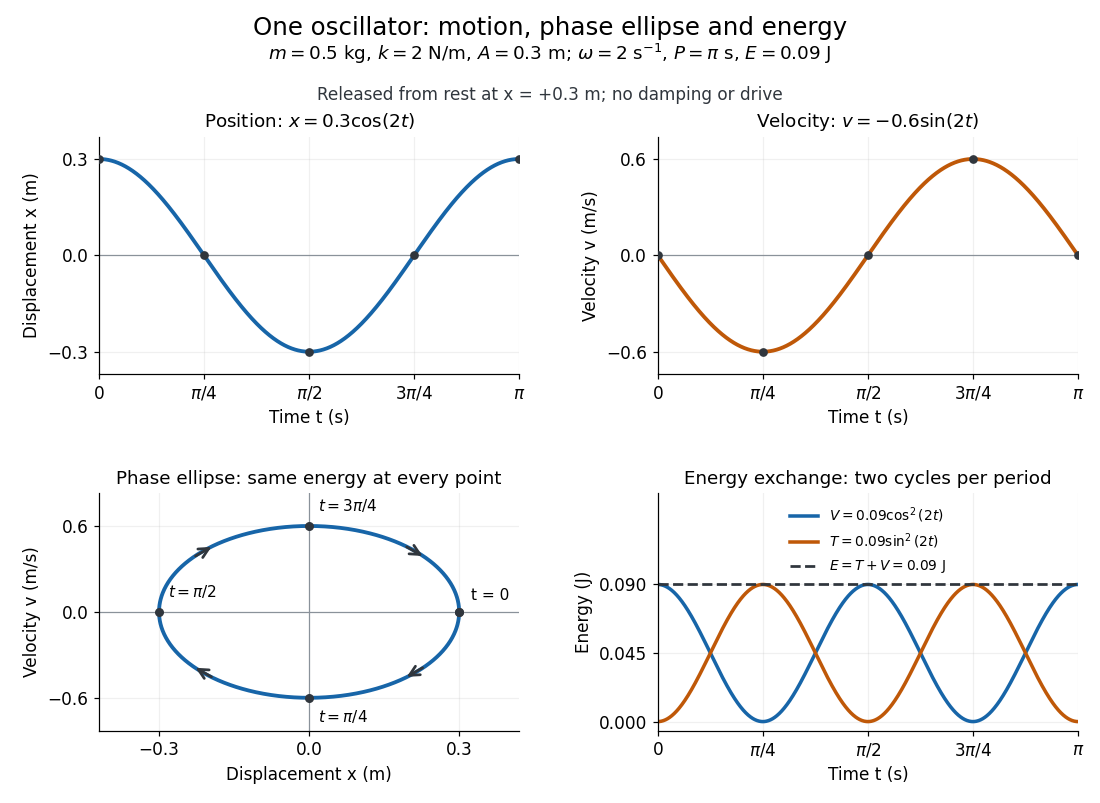
Position, velocity, phase ellipse and energy exchange for a mass of 0.5 kg on a spring of stiffness 2 N/m
. Details. The physical position trace covers a line segment, in metres. In the phase plane, the paired position and velocity instead trace the ellipseThis is precisely , rewritten: the single conserved mechanical energy fixes the amplitude and the whole ellipse. It does not fix the starting oscillation phase. At both and lie on it; position alone cannot distinguish them. Replacing by momentum gives the equivalent phase-space trajectory. The arrows show increasing time, clockwise in coordinates.
This closed ellipse assumes a time-independent spring and no damping or applied drive. Adding a resisting force , , gives and . An underdamped damped harmonic oscillator spirals inward in the phase plane, crossing successively smaller energy contours. The ideal harmonic oscillator is also useful beyond springs: near a smooth potential energy minimum with , its Taylor expansion begins with . For sufficiently small displacements, this gives the same restoring force to leading order, explaining why small oscillations share one solvable pattern.
Two fixed outer wires at attract a middle wire carrying the same electric current . If the middle wire is displaced in the perpendicular direction , the net magnetic force per unit length is . For , the wire's linear mass density gives the displayed simple harmonic motion frequency. Motion towards either outer wire in the original plane is unstable. Gravity must be absent from or balanced in the oscillation direction.
The classical isotropic harmonic oscillator has the same angular frequency in every Cartesian direction. Its equation of motion is , with solution . The trajectory lies in the span of and is an ellipse centred on the force centre, degenerating to a line for dependent vectors. For nonzero angular momentum, oscillates at unless the trajectory is exactly circular. This distinguishes radial and Cartesian frequencies.
In a uniform U-tube containing incompressible liquid of density , cross section and total moving length , let one surface fall by while the other rises by . The height difference is , and potential energy relative to equilibrium is . The whole moving mass is , so . Newton's second law or energy conservation gives and . This assumes small excursions that keep the free surfaces in the uniform vertical limbs.
If resisting force per unit moving length is , the total resistance is and , where . For , an initial velocity from zero displacement gives , with . Its quality parameter is , and the amplitude envelope decays at half the energy-decay exponent. The effective damping model is an assumption, not a derivation of detailed viscous flow near the wall.
A uniform harmonic chain couples neighbouring displacements by quadratic spring energies. With periodic boundaries and spacing , a Fourier transform gives . Quantization makes each nonzero normal mode a phonon. The zero-frequency uniform displacement is a free centre-of-mass coordinate unless pinned, not an ordinary oscillator.[ref]
Applications of Quantum Mechanics by David Tong. §§4.1.1 and4.1.4, monatomic chain and quantized vibrations
A quantum harmonic chain has quadratic couplings between canonical coordinates and momenta. A normal mode transformation turns it into independent quantum harmonic oscillators. A continuum elastic action with time coefficient and spatial stiffness has long-wave frequency , the structure of a smooth condensate phase action.
The discrete Fourier transform of real displacement operators produces complex coordinates obeying . They are not independent real oscillators. The canonical expansion and has independent occupation operators for all nonzero wavevectors, with the uniform free coordinate handled separately. At self-inverse zone-boundary wavevectors the same formulas reduce to one ordinary real oscillator.
The uniform displacement and total momentum satisfy . The nonzero-frequency phonon expansion alone yields the site commutator ; including restores the missing uniform part. The thermal free-coordinate factor requires a specified volume, pinning or a fixed centre of mass. Substituting zero frequency into an oscillator partition function instead produces a spurious divergence without defining the physical zero mode.
At wavelengths much longer than the lattice spacing, gives . The field obeys a wave equation with sound speed . Its conjugate momentum density is and canonical quantization gives . The lattice remains the ultraviolet cutoff of this long-wave theory.
A system's natural frequency describes a free oscillation in the absence of external driving. Distinguish the undamped angular frequency from a damped oscillation frequency and from the driving frequency that maximizes a particular measured response.
For during and zero force afterwards, with zero initial displacement and velocity, the causal Green function gives during the pulse. For it gives . For , both outgoing displacement and velocity vanish precisely when is an integer number of full natural periods. Cancellation requires both initial data for the subsequent homogeneous equation, not only zero displacement at switch-off.
A point mass constrained to a straight guide through the axis of a uniformly rotating reference frame, with signed central displacement and Hooke's law force , satisfies . The transverse Coriolis force is balanced by the guide. The central equilibrium is stable for , neutral at equality and unstable above it. The angular frequency is the positive square root in the title.
For and fixed endpoint values , the Euler-Lagrange equation is . When , solve the endpoint equations for the unique trajectory and use on that trajectory to obtain the displayed action. For , at a solution exists only if ; then there is a family of solutions and their action is zero. At the nonresonant formula has the limit .
Harmonic trajectories are isochronous: all nonconstant oscillations with a fixed frequency have the same period, regardless of amplitude.
Collision mechanics uses impulse together with conservation of momentum and, for elastic collisions, kinetic energy.
An ideal one-dimensional stream is emitted at a constant rate , with every projectile moving at the same ground-frame speed v. A target at x(t), moving in the same direction with speed , intercepts projectiles emitted at retarded time . Differentiating the count gives the displayed rate, after the stream's leading edge has arrived. Thus constant emission rate does not imply constant impact rate. Combining this flux with the momentum transferred in each impact gives the mean force on the target.
When a particle of mass and initial speed strikes a stationary mass , the centre-of-momentum frame moves at . If the relative speed retention in an oblique collision is , its possible outgoing velocity vectors lie on the displayed circle in a scattering plane. Intersect a ray of fixed laboratory direction with that circle to obtain the quadratic formula for outgoing speed. A negative root is inadmissible, and the origin has no defined scattering angle. Tangency gives the maximum laboratory angle when the circle excludes the origin.
A rough contact may transmit both normal and tangential impulses. Conservation of linear and angular momentum fixes totals but does not specify their division between translation and rotation. Predicting outgoing states requires constitutive data such as normal restitution and a friction or tangential restitution law. Rough contact is not synonymous with adhesive contact.
The restitution law applies to velocities of the actual contact points, including any rotational velocities of rigid bodies. A perfectly elastic collision has ; gives zero immediate normal separation speed, but does not by itself require all parts of colliding bodies to share the same velocity.
// Target: classical-mechanics.bigb
For a two-particle collision conserving total momentum, the outgoing speeds in the centre-of-momentum frame are multiplied by the same . The relative kinetic energy is multiplied by . For a smooth oblique collision with normal coefficient of restitution and incident relative velocity inclined by to the contact normal, unchanged tangential relative motion gives . Thus is not a general oblique-impact identity: and give . Sticking requires all relative motion to vanish, not merely its normal component.
For repeated vertical collisions with a fixed plate and constant coefficient of restitution , each collision multiplies the upward speed by , so successive peak heights form the displayed geometric sequence. The initial fall plus both legs of every rebound have total distance . The idealized impact times accumulate in finite time when ; real contact mechanics replaces the limiting sequence by rest.
A collision is an interaction between approaching bodies or particles that changes their motion. Momentum conservation and conservation of energy constrain the outcomes; inelastic collisions can transfer mechanical energy into internal degrees of freedom.
An encounter of charged particle beams at an impact parameter large enough to suppress direct overlap of the atomic nuclei, while their electromagnetic fields still interact.
A collision cross-section is the effective area that converts a target number density and incident particle speed into a collision rate. It can depend on particle species, relative speed, and long-range forces, and need not equal a purely geometric collision cross-section.
The impact parameter is the perpendicular distance between an incoming particle's asymptotic straight-line trajectory and the centre of a scattering potential. In central-force scattering it determines the deflection angle whenever the scattering map is single-valued.
Two spheres of diameters collide geometrically when their projected centre separation is at most , giving cross-section .
For an equal-density sphere of diameter , the ratio of geometric cross-section to mass isBreaking a fixed mass into smaller pieces therefore increases its total cross-section in inverse proportion to fragment size.
Gravitational focusing increases a physical collision cross-section because mutual gravity bends initially non-colliding trajectories toward one another.
Conservation of orbital energy and angular momentum in a two-body encounter gives . At fixed density and encounter speed in the strong-focusing limit, and . This yields runaway fractional growth until stirring or supply changes the assumptions.
For a point projectile approaching an absorbing spherical body of radius in a prescribed exterior inverse-square force, conservation of energy and angular momentum give . This is increasing in the periapsis radius , so gives the collision threshold displayed above. The gravitational scattering angle obeys . On the grazing family its deflection approaches zero at high asymptotic speed and as . Strict noncollision requires ; the equality is the tangency limit.
An elastic collision preserves total kinetic energy between the incoming and outgoing states. For isolated colliding bodies, momentum conservation also holds. The kinetic energy condition supplies information beyond momentum conservation alone. [ref]
Consider a stipulated one-dimensional example with rightward positive: , , incoming velocities and . The total momentum is and total kinetic energy is . In SI numerical values, outgoing velocities satisfySubstituting gives . The root , repeats the incoming state; the outgoing separating state is , . Its momenta add to and its kinetic energies add to . The incoming and outgoing relative velocities both have magnitude , consistent with coefficient of restitution .
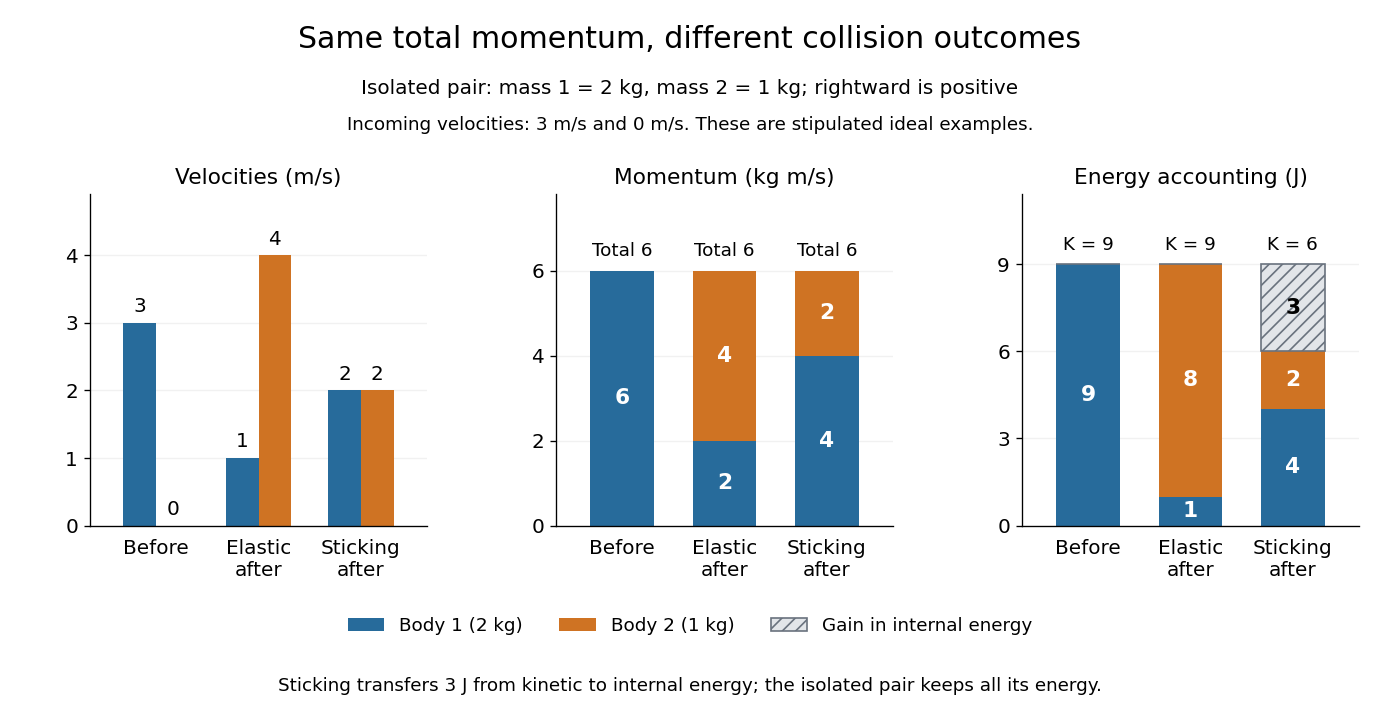
The inelastic collision example below uses exactly these incoming data. Both outcomes preserve total momentum, while only the elastic collision preserves total kinetic energy. These are ideal numerical examples, not experimental measurements.
In units with , a particle of rest mass and total energy strikes a stationary target of rest mass . For the nontrivial one-dimensional elastic collision, reverse the incident momentum in the centre-of-mass frame and transform back to obtain the displayed outgoing projectile energy. The invariant squared total four-momentum is . If and , then . If , retaining arbitrary gives ; only the further fixed-, infinite-target-mass limit gives .
A particle of total incident energy and rest energy strikes an identical stationary particle. If the two outgoing paths make equal and opposite nonzero angles to the incoming direction in the laboratory frame, transverse conservation of momentum makes their outgoing energies equal to . Longitudinal conservation of momentum and the mass shell relation imply . The nonrelativistic limit is ; at large incident energy both paths become forward directed.
In the separated-impact approximation, an upper ball of mass falling at speed meets a lower ball of mass after the latter rebounds elastically from a fixed floor. Their outgoing upward velocities are and . These follow from conservation of momentum and reversal of relative velocity. The upper ball receives a fraction of the initial kinetic energy, where ; subtracting this fraction from unity gives . Hence complete transfer occurs at , whereas a very light upper ball rebounds to nine times the common drop height.
In a nonrelativistic elastic collision of incident mass at speed with initially stationary mass , the centre-of-momentum frame moves at . The projectile's outgoing velocity in that frame has fixed magnitude . Its laboratory velocity tips lie on a circle of radius centred at . For , a tangent from the origin gives the largest laboratory scattering angle, . This geometrical result follows from Galilean velocity addition and conservation of energy.
For fixed particle masses, a Galilean boost by changes total kinetic energy to . An isolated collision conserves total momentum and total nonrelativistic mass , so its final-minus-initial kinetic energy change is independent of the inertial frame. An elastic collision in one such frame is elastic in all of them. Conservation of momentum, rather than invariance of the numerical value of K, is essential to the argument.
Equal laboratory recoil angles constrain outgoing momenta, not equality of masses. In units , take an incoming mass with energy striking a stationary mass . The final momenta and conserve four-momentum and have mass shells and . Both trajectories make angle with the incident axis. This is a concrete counterexample to inferring equal masses from equal outgoing angles alone.
For two identical particles of rest mass , one initially stationary and the other with kinetic energy , symmetric final paths at force equal final energies . The relativistic energy-momentum relation and longitudinal momentum conservation give the title formula. The angle between the paths is , tending to at low kinetic energy and to zero at high kinetic energy.
For a nonrelativistic elastic collision with the target initially at rest, let be the outgoing projectile angle in the centre-of-mass frame. The laboratory target velocity is proportional to . Its unsigned recoil angle is therefore , independent of the mass ratio. At zero deflection the target is stationary and its direction is undefined; the right-angle value is a limit.
A point mass strikes a free rod of equal mass, initially at rest, perpendicularly at distance from its center of mass. Assume a smooth elastic collision and rod moment of inertia about its centre. The final translational speeds are equal precisely when . Indeed, momentum conservation then fixes both final velocities to ; angular impulse gives , and conservation of kinetic energy gives . Eliminating proves the formula. A uniform rod has , hence , which lies within the rod.
Let a nonrotating disc initially move downwards at speed and strike a stationary point support offset from its centre. If the impulse is vertical and the normal coefficient of restitution is one, its upward impulse satisfies . The signed upward centre velocity is therefore the title formula, where is the moment of inertia about the horizontal diameter perpendicular to the impact lever arm. At for a thin circular disc, , so its centre instantaneously stops and all initial kinetic energy becomes rotation. A fixed support can absorb momentum without doing work.
Let one equal-mass disc arrive with velocity while the other is stationary, and let be the unit line of centres at contact. A smooth central elastic impulse exchanges their normal velocity components and leaves tangential components unchanged: and . The final translational velocities are orthogonal when both are nonzero, and no rotation about a disc centre is generated by the normal impulse. This result concerns nonrelativistic smooth discs; roughness introduces tangential contact dynamics.
A massive piston at velocity reverses a particle's normal velocity in its own frame. Transforming back gives , with transverse components unchanged. The particle energy gain is .
A particle of kinetic energy hitting an equal mass at rest, with equal and opposite outgoing angles , obeys . Conservation of total energy gives equal final energies, and longitudinal momentum conservation fixes the angle.
A projectile of mass elastically scattering from a stationary target of mass has the displayed maximum laboratory angle. In units, let its incident energy be and . Boosting the outgoing four-momentum from the center-of-momentum frame gives , with and . The maximum at has . Equality is allowed; a strict upper bound would exclude a realizable outgoing direction. The angular cap is independent of incident energy.
An inelastic collision changes total kinetic energy. In the dissipative case it decreases, transferring energy to internal energy, including deformation and microscopic motion. Isolated colliding bodies still obey momentum conservation; conservation of energy requires accounting for the transferred energy. Bodies need not stick in every inelastic collision. The decrease in translational kinetic energy drives dissipative spreading of a planetary ring.
For the incoming masses and velocities in the elastic collision example, stipulate that the bodies stick. This perfectly inelastic collision has a shared outgoing velocityThe outgoing momenta are and , totaling . The outgoing kinetic energies are and , totaling . Thus of kinetic energy becomes internal energy within the isolated pair. Nothing in momentum conservation requires this to remain as kinetic energy. [ref]
https://openstax.org/books/university-physics-volume-1/pages/9-4-types-of-collisions. OpenStax University Physics Volume 1, section 9.4: elastic and perfectly inelastic outcomes
Two uniform discs of mass m and radius a stick at first edge contact. One initially translates at speed v and the other rests, with neither initially spinning. If the incoming velocity makes angle to the line of centres, the composite axial moment of inertia about its centre of mass is . Conserved angular-momentum magnitude is , so the angular velocity magnitude is . The centre-of-mass speed is v/2. Splitting kinetic energy into translation and rotation gives . The difference from is dissipated internally; it cannot be removed from angular-momentum conservation.
A perfectly inelastic collision is an inelastic collision in which the bodies stick and share one outgoing velocity. For two isolated point masses, momentum conservation gives . At fixed total momentum, common velocity minimizes the outgoing translational kinetic energy, so sticking gives the greatest loss of that kinetic energy for the specified incoming state.
In a frictionless oblique collision, impulse acts along the common normal and tangential velocity components remain unchanged.
In a smooth oblique collision, the impulse is parallel to the contact normal , while tangential velocity components remain unchanged. Incoming velocities, masses, and a coefficient of restitution do not determine the outgoing velocities until that contact normal, or equivalent scattering data, is specified. For an elastic collision of masses , incoming velocities and , and outgoing first velocity , conservation of momentum and conservation of kinetic energy give . Thus specifying only the first outgoing component leaves a family: gives , while gives .
The impulse of a force over a time interval is its vector integral:Its International System of Units unit is . The impulse-momentum theorem equates the net impulse to the change in momentum. For one fixed-mass point mass, integrate its net force; for a closed collection obeying Newton's third law, integrate the sum of external forces. In one dimension, the signed area under the force versus time graph gives the impulse; negative force contributes negative area. [ref]
Three stipulated rightward net force pulses illustrate the same : constant for , a triangle rising from zero to at and falling to zero at , and constant for . Their areas areApplied separately to the same fixed mass , each gives . Their peak forces differ: , , and . Thus impulse fixes the final momentum change, while the force history determines how abruptly it occurs.
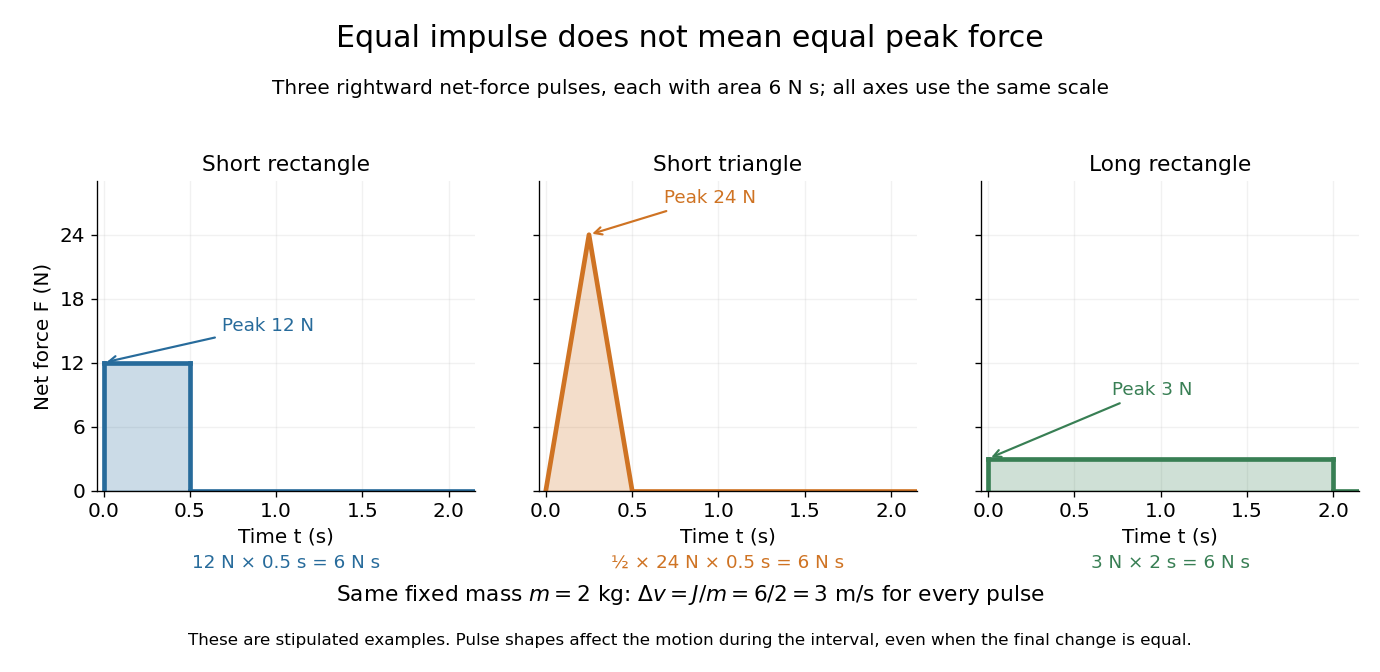


The mean net force over the chosen interval is . Extending the interval for a fixed impulse reduces this mean force. A lower peak force additionally depends on the pulse shape: the two short pulses above have the same mean but different peaks. This explains why controlling the duration and shape of a stopping impulse matters in cushioning a collision.
An impulse directed along the position vector relative to a specified origin. Its angular impulse vanishes because . It can nevertheless change kinetic energy; if an initially circular Kepler orbit receives radial velocity , the added specific orbital energy is .
A radial impulse that multiplies the initial circular kinetic energy by adds radial velocity and leaves specific angular momentum . The new specific orbital energy is , yielding orbital eccentricity and semilatus rectum . For , the apsidal radii are ; for there is no finite apocentre. A nonzero radial kick occurs away from an apsis, so the old circular radius is not automatically the new periapsis.
Integrating the closed-collection balance in momentum conservation and applying the fundamental theorem of calculus givesFor one fixed-mass point mass, this becomes . Zero external impulse implies equal initial and final total momenta; momentum conservation throughout the interval requires zero net external force throughout it.
Particles initially on a circle of radius with common tangential speed move freely on tangent lines. They remain on a circle of radiusrotated through , while total angular momentum remains .
Articles by others on the same topic
There are currently no matching articles.