The initial table of content was limited to the first level because it is larger than 1000 articles. There are 2101 articles in total. Expand a branch to load its children.
For a finite group acting on a set , write for the stabilizer subgroup and for the orbit of . The orbit-stabilizer theorem givesIndeed, is a bijection from the left cosets of onto : two images agree precisely when . Each coset has elements, proving the formula.
Place the cube vertices at . The four vertices whose coordinate product is form ; those with product form . Within either set, two distinct vertices differ in exactly two coordinates, so every edge has length and each set is a regular tetrahedron.
A member of the cube rotation group is a signed permutation matrix of determinant one. There are permutations of the coordinate axes and four choices of signs for each permutation that give determinant one, so . Such a matrix maps a coordinate-product class to a coordinate-product class. Moreover, the rotation through a quarter-turn interchanges the classes. Thus the orbit of consists of exactly . By the orbit-stabilizer theorem, the tetrahedron stabilizer in the cube rotation group has order
The fundamental theorem of algebra says that every nonconstant polynomial with complex number coefficients has a root in the complex numbers. Repeated polynomial division by a factor of degree one therefore factors a degree-three polynomial with complex number coefficients into three factors of degree one, with algebraic multiplicities included.
For a matrix with complex number entries of size three, its characteristic polynomial is , and its characteristic equation is . A complex number is an eigenvalue exactly when is singular, equivalently when its null space contains a nonzero vector. Thus the three roots of the characteristic polynomial are the three eigenvalues counted with algebraic multiplicity.
For the specified matrix, expansion along the first row givesHence the eigenvalues are . Corresponding eigenvectors areThe matrix with these three columns has determinant , so these eigenvectors are linearly independent. A repeated eigenvalue does not in general guarantee two independent eigenvectors; here they have been exhibited directly.
The limit of a sequence of real numbers is if, for every , there is an integer such that implies . It tends to positive infinity if, for every real , there is an integer such that implies .
If , choose the latter threshold with . Then eventually, so . Thus . The converse is false: has reciprocal tending to zero and tends to negative infinity. The precise sign-free statement is given by reciprocal limits and escape in absolute value: is equivalent to .
If , eventually , and the triangle inequality gives . ConsequentlyGiven , take large enough that for all . This proves directly from the definition of the limit of a sequence.
Here is a nested-interval proof of the Bolzano-Weierstrass theorem. Put every term of the bounded real sequence in a closed interval , with . Bisect this interval and choose a closed half containing infinitely many terms. Repeating gives nested closed intervals , each containing infinitely many sequence terms, with length .
By the least-upper-bound property, exists. For each , every lower endpoint lies at most , while ; hence . Choose increasing indices with , possible because each interval contains infinitely many terms. ThenThus every bounded real sequence has a convergent subsequence.
For a sequence with no convergent subsequence, take : any subsequence has , so its terms tend to positive infinity rather than to a finite limit of a sequence. For an unbounded sequence with a convergent subsequence, take and . Its odd terms are unbounded, while its even subsequence converges to zero.
Take the scalene triangle vertex set . Its edge lengths are . Each vertex has a different unordered pair of incident edge lengths. A Euclidean isometry preserving the set must preserve these pairs, and therefore fixes every vertex.
To justify rigidity of a scalene triangle fully, Euclidean distances from an arbitrary plane point to these three fixed points determine that point uniquely: subtracting its squared Euclidean distance to the origin from the other two squared Euclidean distances determines its two coordinates. Thus an isometry fixing the three vertices fixes every plane point. Only the identity preserves .
For the general union of group translates, let . Left multiplication by permutes , soTherefore . This containment uses only the group action; the absence of symmetries of is not needed for the containment itself.
Use the same triangle and let consist of translations for . All its vertices have integer coordinates, and one vertex is the origin, soThe rotation through a quarter-turn preserves this integer lattice, and hence belongs to . It fixes the origin and is not the identity, whereas the only translation fixing the origin is the identity. It is therefore outside , proving . This is symmetry enlargement under group translates even though itself has trivial stabilizer subgroup.
Write a Möbius transformation as , with , on the Riemann sphere. If , infinity is not fixed, and its finite fixed points solveThe pole cannot solve this equation, since substitution gives . The quadratic has one or two distinct complex roots, so these give exactly one or two fixed points.
If , then and infinity is fixed. If , there is one additional finite fixed point, namely . If and , the transformation is a nonzero translation, with no finite fixed point. If and , it is the identity and fixes the entire sphere.
Thus a nonidentity Möbius transformation has one or two fixed points; the identity has infinitely many. The examples , , and realize the three possibilities respectively.
Complex conjugation fixes , but sends to , so it is not the identity. The preceding classification of fixed points of a Möbius transformation says that a nonidentity Möbius transformation has at most two fixed points. Since complex conjugation has at least three, it cannot be a Möbius transformation.
Take positive angles counterclockwise. The rotation sends the standard basis vectors to and . These images form the columns of its matrix, soThe columns are an orthonormal basis and the determinant is one, as required for a plane rotation.
Orient the axis towards and measure positive angles by the right-hand rule about . The vectors , and form a positively oriented orthonormal basis, since . Its change-of-basis matrix isRelative to this basis, the rotation fixes the first coordinate and rotates the last two. Writing and , its matrix in the standard basis is thereforeIn particular , , and , verifying the axis and the direction of rotation. Reversing the chosen orientation of the axis replaces by .
A vector space over the real numbers is a set with an addition making it an abelian group and a scalar multiplication by satisfying, for scalars and vectors , the identities , , and . A vector subspace is a nonempty subset closed under addition and scalar multiplication; a proper vector subspace is one unequal to . A spanning set is a set whose finite linear combinations give every vector of . A basis is a linearly independent spanning set. The dimension is the number of vectors in a basis, or its cardinality when the basis is infinite.
The sum of vector subspaces and their intersection of vector subspaces areBoth are vector subspaces: addition and scalar multiplication preserve the displayed forms or simultaneous membership. The intersection of vector subspaces is never empty because .
For the two given hyperplanes, adding and subtracting their defining equations gives and . HenceThese two nonzero vectors are orthogonal, and consequently form an orthogonal basis of the intersection of vector subspaces. Put and . Direct substitution gives , . Their dot products with vanish, and . Each defining equation of or is one nonzero linear constraint in four variables, so each vector subspace has dimension three. Thus each space has the indicated orthogonal basis:The last four vectors are nonzero and mutually orthogonal, so they are a basis of . They lie in , proving . The dimension identity is therefore verified numerically:
Use the least-upper-bound property as the least upper bound axiom: every nonempty set of real numbers bounded above has a least upper bound in . It implies convergence of a bounded increasing sequence: if is the supremum of its terms, then for every some term exceeds , and all subsequent terms lie between that term and . A bounded decreasing sequence converges by applying this argument to its negative.
The alternating series test states that if , , and , then converges. To prove it, let denote its partial sums. The even partial sums are increasing because . The odd partial sums are decreasing because . Moreover,Completeness of the real numbers therefore gives a limit of a sequence for each subsequence, denoted respectively for the even and odd subsequences. Their difference is , so . Every sufficiently late partial sum belongs to one of these two subsequences, proving convergence of the full sequence of partial sums. Multiplying the terms by leaves convergence unchanged.
The positive terms decrease to zero. The alternating series test just proved therefore gives convergence of the signed series. It is conditional convergence: , so , and the absolute-value series dominates the divergent harmonic series.
The comparison test for series used here says that if , convergence of implies convergence of , while divergence of implies divergence of . This follows by comparing increasing partial sums. For completeness, the harmonic series diverges because every block from to has sum at least .
The absolute-value series can be grouped in pairs of nonnegative terms:Indeed, for , so these positive partial sums are bounded by two. Completeness of the real numbers proves their convergence. The triangle inequality bounds every late signed sum by the corresponding late absolute-value sum, so absolute convergence implies convergence. Thus the series converges absolutely.
Group three consecutive terms. Their block sum isSince and for , we have . The comparison test for series and the preceding proof of convergence of show that converges absolutely.
This establishes convergence of the original partial sums at indices . Each intermediate partial sum differs from one of these by at most two of the original terms; those terms tend to zero. Thus all partial sums have the same limit of a sequence, which is the mechanism of convergence from fixed-length series blocks. The original series is not absolutely convergent, since its absolute-value series contains . Therefore the original series converges conditionally.
Let , with . The indices in the th dyadic block have one sign, soA convergent sequence of partial sums must be a Cauchy sequence: for every , all sufficiently late pairs of partial sums differ by less than . The displayed differences violate this necessary condition with , at arbitrarily late endpoints. Thus the series diverges, even though its individual terms tend to zero. This dyadic-block alternation of reciprocal terms has growing block lengths; the fixed-length block argument of the previous part does not apply.
Let be continuous on a closed bounded interval . First prove that is a bounded function. If it failed, we could choose with . The Bolzano-Weierstrass theorem gives a subsequence . Because the interval is closed, . Continuity gives , contradicting .
Now let , which exists by completeness of the real numbers and the bound just proved. Choose with . A convergent subsequence has limit of a sequence , and continuity gives . Applying the same argument to gives attainment of the infimum. This proves the extreme value theorem: the maximum and minimum both exist and are attained. The argument also covers a one-point interval, where the conclusions are immediate.
Take . It is continuous and bounded on , with infimum zero and supremum one, neither attained on this open interval.
Use the reduced-denominator function unbounded on every interval:Every value is a finite real number. In any nondegenerate interval , its interior contains infinitely many rational numbers, whereas there are only finitely many reduced fractions in with denominator at most any fixed . Some rational number in therefore has denominator exceeding . Hence the function is unbounded on every such interval. It reverses the positive values of the Thomae function rather than requiring an infinite value at any point.
The mean value theorem states that, if is continuous on and differentiable on , with , there is such thatTo deduce it from Rolle's theorem, subtract the secant line: . This function has the same continuity and differentiability properties and satisfies . Rolle's theorem gives an interior point with , which is precisely the required equality.
For the differential equation, the product rule givesThe preceding result makes this product constant. Thus all solutions are , and differentiation verifies every such solution.
For the integral assertion, continuity ensures that is Riemann integrable on every finite closed interval. Use the usual orientation for an integral with negative upper endpoint. For , additivity of the integral givesThe absolute value of this expression is at most the supremum of on the segment joining and . Continuity at makes this bound tend to zero for either sign of . Consequently , proving this form of the fundamental theorem of calculus.
Finally, a differentiable solution of the integral equation is continuous, so the fundamental theorem of calculus yields ; setting gives . The differential-equation calculation above now forcesConversely, , so this function satisfies the original integral equation. It is unique because every differentiable solution has already been forced to this form and this initial condition.
For a function with continuous derivatives through order on the interval between and , the Taylor formula with integral remainder isThis is Taylor's theorem about zero; translation gives the formula about any other point. To prove it, the case is the fundamental theorem of calculus. For , integration by parts givesSubstitution into the formula at order proves the formula at order by induction. The integral estimate, valid also for negative , isFor the smooth function satisfying , each fixed derivative is continuous on and hence is bounded there by the extreme value theorem. Thus a bound exists for every . Differentiating the differential equation repeatedly gives . Only the three functions are needed: take to be the maximum of their absolute-value bounds on . Then simultaneously for every and .
At zero the derivatives consequently repeat the values . Taylor's theorem therefore givesThe last limit of a sequence follows because the ratio of consecutive majorants is , eventually less than . Since is arbitrary, Taylor expansion from a periodic derivative equation provesThis proves convergence to the function using a remainder bound; it does not assume beforehand that a smooth function equals its Taylor series.
The characteristic equation of the homogeneous linear differential equation is , giving the homogeneous solution . For the first forcing, a particular solution of the form gives , soThe initial conditions impose and , whence , . Thus the first solution isFor the second forcing, is already a homogeneous solution, so the usual exponential trial must be multiplied by . Substitution of the particular solution gives , hence . Now , and the initial conditions give , . Therefore the resonant solution isThe additional factor reflects resonance in a differential equation.
This is a separable differential equation. On the solution with , integration from the initial condition givesThe right side lies in , so taking its sine stays on the required branch. The solution isNear the origin, , so and the tangent line is horizontal. At the other end, , whileThus the curve has a vertical limiting tangent line as , even though is excluded from the domain.
For the direction field, the slope is nonnegative everywhere in the square. The segments are horizontal on and on , become steeper as increases at fixed , and become flatter as increases at fixed . Near they are almost vertical unless is correspondingly close to one. The excluded corner has no single limiting slope: the ratio depends on the path of approach.
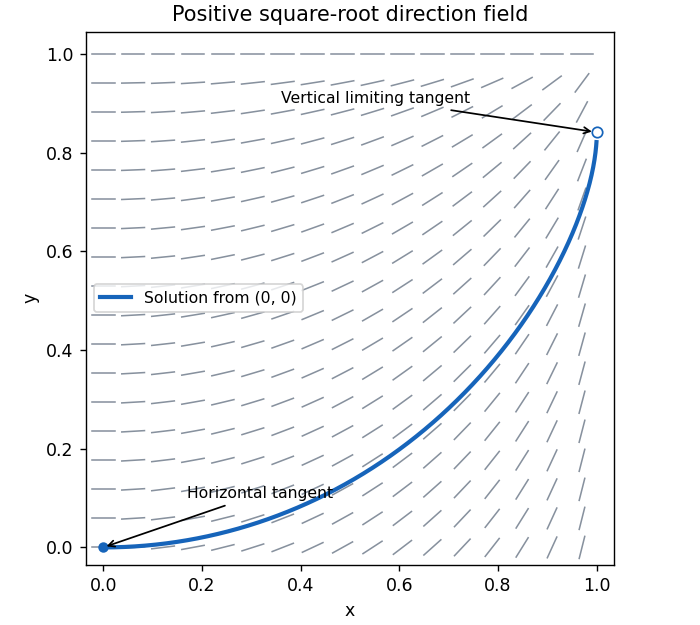
Positive slope field and the solution from the origin, with its horizontal and vertical limiting tangents
. Details. The indicator function equals one when the event occurs and zero otherwise. Its expected value is . By linearity of expectation, no independence assumption is needed to obtainSince , including , the variance isIn particular, correlations between the events cannot simply be discarded.
Write . If , then implies . Applying Chebyshev's inequality therefore givesEquivalently, the contribution of to is . A positive mean is necessary for the displayed ratio to be defined. If , nonnegativity instead gives almost surely, and the printed ratio would be .
After independent tosses, an even count arises in exactly two disjoint ways: an even count after tosses followed by a tail, or an odd count followed by a head. Independence of the last toss from the preceding ones therefore givesSubtracting the fixed point turns this into the linear recurrenceAs zero is even, , so the probability isFor this is for every ; for it is always one; for it alternates between one and zero according to the parity of .
An integrating factor for a differential one-form is a nonzero function for which is an exact differential, say . Then solutions lie on level sets . Locally, the compatibility condition is .
Here multiplication by , which is nonzero for , producesThe initial condition makes this first integral equal to . Taking the positive branch yields the solutionon the connected interval containing zero where the radicand is positive. This domain restriction matters because the original differential equation is singular at .
Completing the square gives . As , the differential equation consequently impliesAt , . Thus, moving a little to the left from , the curve rises above . Throughout every segment of the direction field points downwards as increases, by the inequality above. Tracing backwards therefore makes rise further, so it cannot return to . This graphical barrier argument proves and for every on the solution. The explicit first integral also shows this branch extends throughout : writing , the minimum of is , so for . Including the initial point, for all .
For the curve is on , where the strictly increasing function has the unique positive root at . The curve decreases through with slope and reaches only as a limiting endpoint. Its derivative isAs , and . As , the numerator tends to and the denominator to zero from above, so again . More precisely, at the endpoint. Both ends have the requested unbounded negative slope.
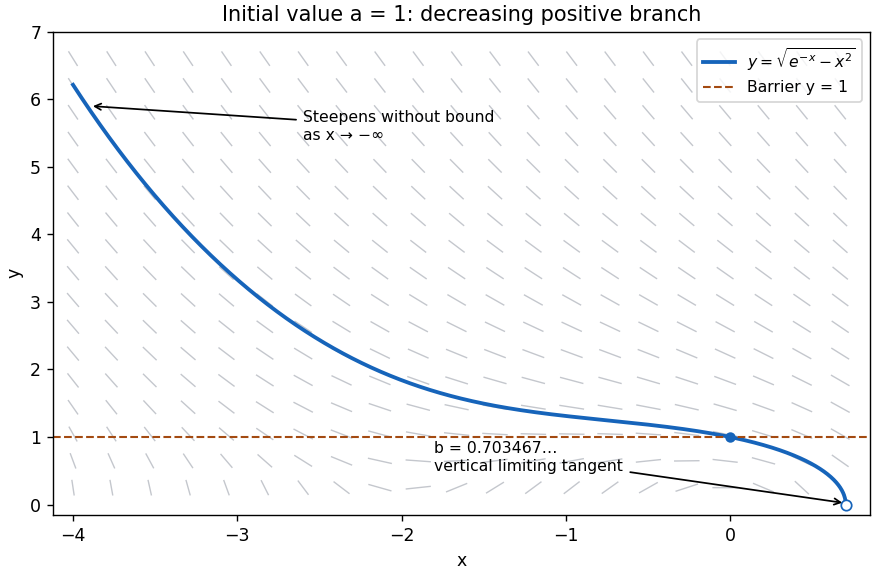
The positive solution for initial value one, with the horizontal barrier and the steep limiting endpoint
. Details. For the logistic differential equation, separate variables to obtain away from the constant solutions. Applying the positive initial condition givesThe formula also includes the constant solution . Below positive solutions increase; above they decrease. They approach as . Equivalently, linearizing gives and . Thus zero is unstable and is asymptotically stable.
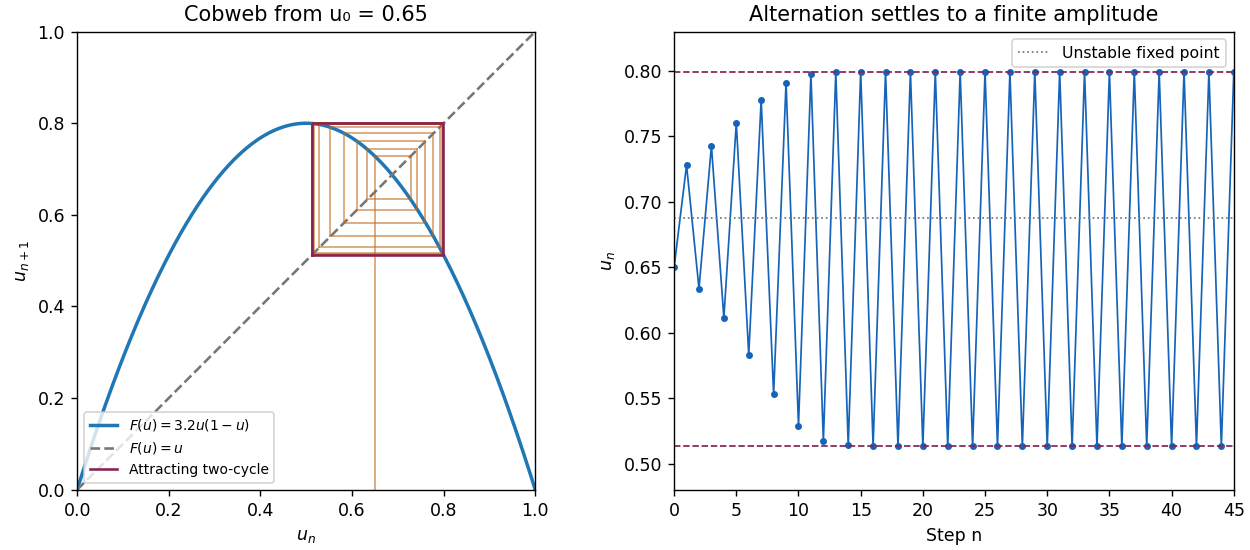
The forward Euler method gives . Set and ; multiplying the recurrence by this scaling factor gives the logistic mapIts fixed points are and . The fixed-point multipliers are and . Since , zero is always unstable. The positive fixed point is stable for and unstable for . For , a small displacement obeys : its sign alternates and its amplitude grows, giving an oscillatory instability whose period is .
This is an artifact of Euler discretization of logistic growth. Exact small perturbations decay by the positive factor per time step; a one-dimensional autonomous differential equation cannot have a nonconstant periodic orbit, since its solutions move monotonically between equilibrium points. The artificial instability occurs when , beyond the stable step range of this discretization.
For , remove the fixed point factors from to obtain . The resulting logistic map two-cycle isThese points map to each other. Their periodic-orbit multiplier is , so the two-cycle attracts nearby iterates. The cobweb shows a small initial departure from growing with alternating sign and then settling into the finite rectangle between and . The time trace shows the corresponding finite-amplitude oscillation.


Two functions are linearly dependent if constants , not both zero, satisfy identically. Differentiating also gives . Since the determinant of these two equations is the nonzero Wronskian , both constants must vanish. Hence the two solutions are linearly independent.
Differentiating the Wronskian and substituting the homogeneous linear differential equation givesIntegrating proves Abel's identity:For variation of parameters, impose on the proposed particular solution. Then , and substitution into the inhomogeneous differential equation leaves . Solving this two-by-two linear system givesArbitrary constants of integration merely add a homogeneous solution.
For the constant positive coefficient , take . Direct differentiation verifies that and solve the homogeneous linear differential equation; their Wronskian is . The requested integrands areTaking yieldsThus grows with power one, whereas is bounded. Their combination simplifies to ; the final sine term is itself a homogeneous solution. The secular term is the response to resonance in a differential equation.
Introduce . Along a solution,At , is a first integral. The identity shows its level sets are bounded: neither nor can escape to infinity on a fixed level. Consequently trajectories remain bounded as , including those starting far from the origin. This bound also prevents finite-time escape; no explicit solution is needed.
The equilibrium points are and . The Jacobian matrix at isAt the origin its eigenvalues are , with opposite signs, so the origin is a saddle point in all three cases. An eigenvector for lies on ; the stable direction has positive slope and the unstable direction negative slope. At the eigenvalues are .
When , these latter eigenvalues are . The nonlinear classification follows from the strict minima of at the two points: nearby level sets are closed curves without other equilibria, and the nonvanishing vector field makes them periodic orbits. Thus the two points are center equilibria. For , there are two separate closed ovals, one around each center equilibrium. The level consists of the saddle point and two homoclinic orbits forming a figure eight, explicitlyFor , a single outer closed orbit encloses all three equilibrium points. Motion is clockwise, as the vector points downwards wherever . The upper homoclinic orbit leaves the origin into and returns through ; the lower one has the reflected orientation.
When , the two nonzero equilibrium points have eigenvalues and are unstable foci. Nearby paths spiral outward clockwise. The first integral becomes a strictly increasing energy along every nonconstant trajectory: although can momentarily vanish when , it cannot vanish on an interval unless the solution is an equilibrium. Thus there are no periodic orbits or homoclinic orbits. The two stable separatrices of the saddle point, traced backwards, spiral towards the corresponding unstable foci. Its unstable separatrices move onto positive energy and escape outwards. All other nonequilibrium trajectories outside the stable manifold are unbounded forwards: a bounded forward limit set would have to lie in , whose only invariant points are the three equilibria; the two unstable foci cannot attract a nonconstant trajectory, and convergence to the saddle occurs only on its stable manifold. Escape is not finite-time blow-up, since bounds the energy on every finite interval.
When , the eigenvalues at the nonzero points are , so they are stable foci. The energy decreases, keeping all forward trajectories in compact sublevel sets. A bounded limit set must lie in the invariant part of , so trajectories converge to equilibria: generically to one of the two stable foci, exceptionally to the saddle along its stable manifold. The saddle's unstable separatrices spiral into the two stable foci; its stable manifold separates their attraction basins. Again, energy monotonicity excludes periodic orbits and homoclinic orbits. These three cases give the quartic double-well phase portrait with linear damping below.
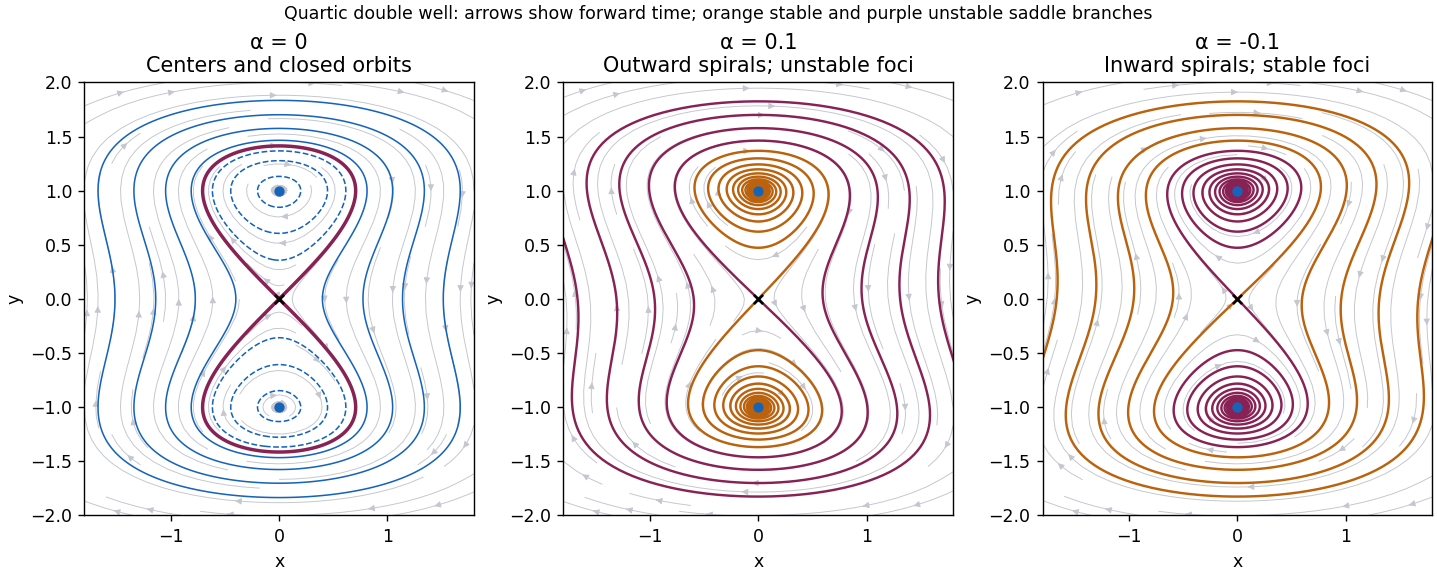
Conservative double-well closed orbits and the outward or inward spirals produced by positive or negative alpha
. Details. 
For , the conditional probability is . Since the events partition the sample space, their intersections with are disjoint and exhaust . The law of total probability therefore gives . Substituting this and into the definition proves Bayes' theorem:The denominator is positive by the given hypothesis on .
Every urn contains balls. Let be its number of blue balls; choosing an urn uniformly makes uniform on . Conditional on that urn, the probability of a blue first draw is , so the law of total probability givesDrawing twice without replacement requires . Given , the probability that both draws are blue is , and henceTaking the ratio defining conditional probability gives the second requested probabilityAlthough a blue first draw removes a blue ball from its urn, it also makes an urn rich in blue balls more likely. Averaging with this changed conditional distribution is essential.
Two independent events satisfy . If , this is equivalent to : learning that occurred does not change the probability of . The product definition also covers zero-probability events without dividing by zero.
The 36 ordered outcomes are equiprobable. For , let count outcomes with sum . Then and for . Their joint probability is if , and zero otherwise.
If the joint probability is zero, independence is impossible in these ranges because both marginal probabilities are positive. If it is , the independent events condition requires , or . This happens only for , and then all six values of allow the partner . Therefore within the possible sums and facesIf arbitrary integer labels outside these ranges are included, an impossible sum or face defines an empty event, which is trivially independent of every event.
Conditional on , the type indicators are independent random variables with the Bernoulli distribution of parameter . Thus has the binomial distribution and its probability generating function is . The general rule used here is that for a nonnegative integer-valued random variable , ; for a sum of independent such variables, their probability generating functions multiply, since the expected value of the product factors. The law of total expectation then averages the conditional result:This calculation uses the given independent labeling of objects, including conditional on their number.
A Poisson distribution with parameter has probability generating function . The preceding part gives , the probability generating function of a Poisson distribution with parameter . To prove independence, retain both counts:Consequently the joint probability generating function factors asComparing the coefficients of proves that the joint probabilities are the products of the marginal probabilities. Hence and are independent, with distributions and . This is Poisson thinning, including the degenerate counts when or .
With equal type probabilities, and have the same marginal probability generating function, namely . Their assumed independence, together with , givesSet for . The identity becomes and, after iterations,The finite expected value gives as . To justify this without any analyticity assumption at the endpoint, note that and is bounded above by ; dominated convergence gives the derivative . Substituting the expansion into the iterated identity yieldsThe left side is independent of , so it equals the limit. Thus on and uniqueness of the power-series coefficients proves . Only finite expected value was needed; the given finite variance is stronger. This proves the Poisson characterization by independent binomial splitting rather than assuming the original count distribution.
For independent random variables, the probability density function of a sum is the convolution of probability densities. Since each density is one on and zero elsewhere,This is the length of . Therefore the density isThe two triangular areas sum to one, as a probability density function must.
Conditioning on , independence of gives for and zero for . Using the preceding probability density function,
Three positive lengths form a nondegenerate triangle precisely when each is less than the sum of the other two. Necessity is the triangle inequality. For sufficiency, two circles centered at the ends of one side intersect off that side whenever the remaining lengths satisfy these strict inequalities, giving the third vertex.
Failure thus occurs when , , or . Two such inequalities cannot hold together for strictly positive lengths. Zero lengths and equality cases have probability zero because the variables have continuous probability density functions. By symmetry each failure event has the probability just calculated. Hence the probability of forming a triangle is
Another convolution of probability densities gives, for ,Only this part of the density is needed because the fourth length is at most one.
Four positive lengths can form a nondegenerate quadrilateral if and only if every length is less than the sum of the other three. Necessity follows by following the other three sides between the endpoints of the longest side and applying the triangle inequality. For sufficiency, select a diagonal length in the intersectionBoth intervals are nonempty, and their intersection is nonempty exactly when and . These are precisely the four strict length inequalities. Construct triangles with sides and on opposite sides of their common diagonal. Their union has the required simple, nondegenerate quadrilateral as boundary.
The failure events, in which one length is at least the sum of the others, are disjoint except on sets of probability zero. For the specified length , independence and the density above giveThere are four symmetric choices of the overly long side, so the probability isThis is the four-sided case of the polygon probability for independent uniform rods.
Articles were limited to the first 100 out of 2101 total.
Articles by others on the same topic
There are currently no matching articles.