Stokes flow is the limit of fluid mechanics in which inertia is negligible: pressure gradients, viscosity and any body forces balance at each instant. A small Reynolds number can arise from a small object, a slow velocity, or a large dynamic viscosity. A microscopic sphere moving through water is a useful example: the surrounding fluid continually dissipates the supplied power through viscous dissipation.
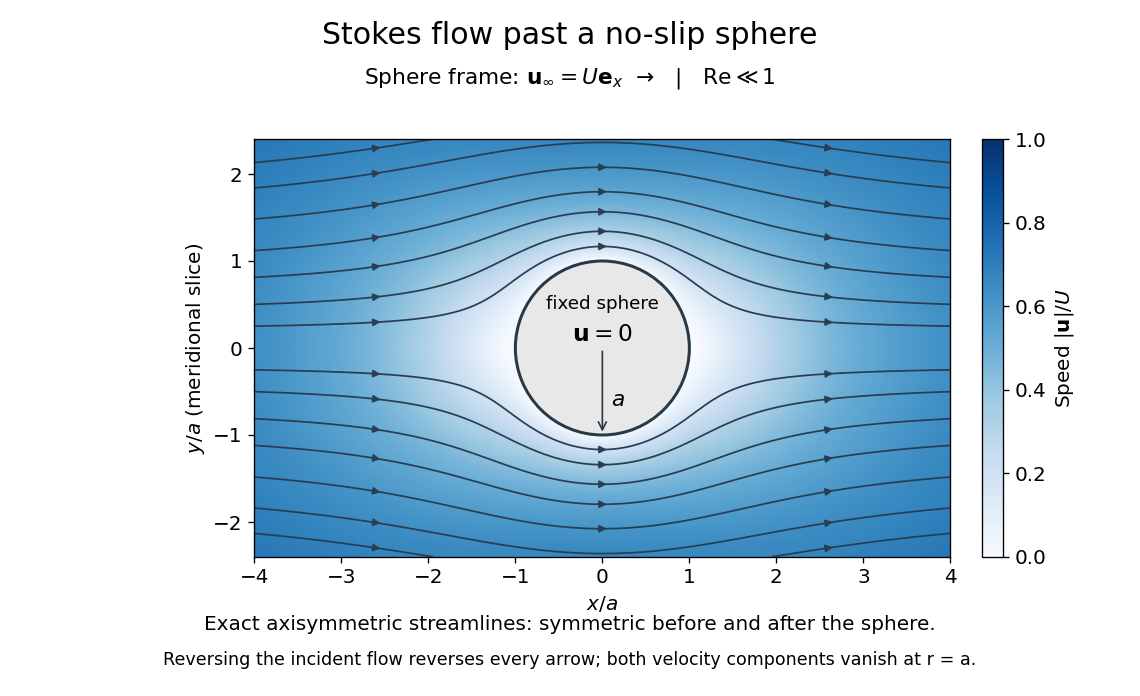
The picture is a meridional slice of the three-dimensional axisymmetric flow around a sphere, with the sphere held fixed and the distant fluid moving rightward at speed . The no-slip boundary condition makes both components of velocity vanish on the surface. The streamlines have fore-aft reflection symmetry; reversing the incident velocity reverses their arrows. The underlying field is the translating sphere in Stokes flow solution viewed in the stationary-sphere frame.
For an incompressible flow of a Newtonian fluid with constant dynamic viscosity , the steady Stokes equation isHere is pressure, is velocity, and is body force per unit volume. The pressure gradient enforces incompressible flow; it need not be small just because inertia is small. At speed and length , the motion-induced pressure gradient has typical scale , corresponding to a disturbance pressure difference of order . See Shreyas Mandre's fluid dynamics notes, sections 9.1.1–9.1.2.
The controlling Reynolds number iswhere is density and is kinematic viscosity. The condition suppresses advection of momentum on the length . Rapid changes require an additional check of the viscous diffusion time: small Reynolds number alone does not eliminate the time derivative in the Unsteady Stokes equation.
Two rewards of this limit are the exact Stokes's law for the drag on a sphere and kinematic reversibility of Stokes flow. The first predicts settling velocities and connects to the Stokes–Einstein relation; the second explains why a microswimmer needs a nonreciprocal stroke, as expressed by the scallop theorem. Despite viscous dissipation, reversing the driving can retrace the motion: an especially striking consequence of Linearity of Stokes flow.
George Gabriel Stokes obtained the sphere drag and its terminal velocity in his 1851 investigation of how viscosity changes physical pendulum motion. He also used the slow fall of small water droplets to discuss clouds. The paper was read on 9 December 1850; 1851 is its publication date. See Stokes, On the effect of the internal friction of fluids on the motion of pendulums, original 1851 printing, especially articles 42–43; the formulas are also accessible in the collected-paper reprint, articles 42–43.
The unbounded two-dimensional Stokes flow past a no-slip circular cylinder has no solution approaching a nonzero uniform stream. With radius and speed scaled to one, the forced angular mode has stream function . The biharmonic equation gives . Uniform flow at infinity forces , ; impermeability forces , but then violates no slip. The failure belongs to a nonuniform small-Reynolds number limit. In a distant outer region inertia must be retained through an Oseen approximation or the full Navier-Stokes equations, matched to an inner Stokes region. A finite outer wall changes the problem and removes this particular infinity obstruction.
Neglecting both convective acceleration and local acceleration in the Navier-Stokes equation requires a small Reynolds number and an imposed evolution time long compared with the viscous diffusion time . A slowly changing configuration may then be modeled by a sequence of steady Stokes flows. Rapid small-amplitude forcing can have small Reynolds number while requiring the Unsteady Stokes equation instead.
A layer of half-thickness , dynamic viscosity and density , between semi-infinite fluids of viscosity and densities , relaxes a symmetric thickness Fourier mode. In the plug-like extensional viscosity regime, mass conservation and together with the Fourier traction map for a viscous half-space give the displayed rate, where . Inner longitudinal extension dominates for ; outer tangential resistance dominates for while the plug approximation remains valid.
For and , the displayed formula retains both inner transverse shear stress and outer normal-velocity resistance. When , almost immobile tangential interfaces create a pressure-driven parabolic flow and . When , the exterior's normal viscous dissipation dominates and . The exact symmetric three-layer Stokes flow dispersion relation isThe term proportional to in its denominator prevents extrapolating a fixed- long-wave expansion uniformly to every large- scaling.
For a two-dimensional decaying Stokes flow in , prescribe boundary Fourier mode . The boundary shear stress and normal stress are the displayed diagonal map, with the common exponential understood. For and , the Unscaled Papkovich–Neuber representation gives , and . Differentiation proves the tangential traction and vanishing normal stress. The normal-velocity calculation supplies the second diagonal entry. The map converts a viscous exterior into a nonlocal boundary resistance proportional to .
With body-outward normal , put , , , and . Taylor expansion of the exterior boundary integral representation of Stokes flow gives a Stokeslet from , a rotlet from , a source from , and a stresslet from . Thus and are the force and torque exerted on the fluid, while is the instantaneous displaced-volume rate. A volume-preserving deforming body has .
Two identical radius- spheres moving together through a viscous fluid at separation entrain each other. The leading far velocity of one sphere at the other is for separation perpendicular to the velocity, and for parallel separation. Replacing by its velocity relative to this induced flow in Stokes law gives the displayed drag reductions relative to , with errors of order . Reflection symmetry and linearity imply equal drag on the two spheres in either geometry.
The Oseen approximation retains advection of a small disturbance by a uniform incident velocity , but neglects advection of the disturbance by itself. Its steady equations areA Stokes disturbance of a sphere decays as , so the ratio of background advection to viscous diffusion grows as . Thus the approximation resolves the outer region , where the Stokes flow expansion is nonuniform, while self-convection remains smaller by .
Let , , and . A decaying outer disturbance matched to the leading translating sphere in Stokes flow isHere and away from zero. The substitution reduces the latter equation to , whose decaying radial solution is proportional to . In the inner overlap, cancellation of the potential monopole gives . The potential source's volume flux is , and its mass flux is . Downstream, the fluid wake width grows as ; its mass deficit balances this source, while its momentum deficit is , the Stokes drag law.
For a stationary cylinder of radius in the far-field shear , the stream function is . It solves the biharmonic equation and the no-slip boundary condition. The fluid exerts torque per unit length, because the angular part of the surface traction averages to zero and the mean tangential traction is .
Extend the velocity rigidly through a moving sphere in an incompressible tube flow. The extended velocity is continuous and divergence-free, so its total flux is independent of height. Quiescent far-field conditions make this flux zero. The sphere contributes through a cross-section; the rotational contribution integrates to zero over its circular slice. Thus the fluid flux compensates the solid displacement. A descending sphere generates upward fluid flux in every section cutting its interior. This statement assumes a localized flow with no imposed throughflow and negligible tube-end effects.
For Stokes flow without body forces, . Symmetry of the Newtonian fluid stress tensor also gives , interpreted componentwise as the angular-momentum flux. The divergence theorem makes the resultant force and torque the same on any two homologous enclosing surfaces lying in a nonsingular fluid region. In a boundary perturbation of a nearly spherical particle, evaluating each perturbation field on a fixed enclosing surface avoids spurious geometric force terms: the geometric terms from changing the surface normal and area cancel those from evaluating the base stress at the displaced surface.
The Brinkman equation augments Stokes flow with a local drag against a background matrix of velocity . The inverse screening length has units of inverse length. With equal viscous coefficients the permeability is . Taking the curl produces a screened vorticity equation.
Porous-matrix drag depends on fluid velocity relative to the matrix, so it is not invariant under adding a uniform fluid velocity while leaving the matrix fixed. In a swimmer frame with stationary laboratory matrix, the drag is proportional to . A constant shift can alternatively be absorbed into a linear pressure term, whose physical interpretation must then be retained.
A slender low-viscosity fluid column inside a much more viscous fluid rises under a density contrast. At negligible inertia, its axial flux is approximately . Radial expansion strains the outer fluid and gives the normal-stress pressure difference at leading order when inner normal viscous stress and interfacial tension are negligible. Coupling that pressure to volume conservation yields the conduit equation. This two-fluid viscous model differs from a turbulent entraining thermal plume.
The conduit equation evolves the positive cross-sectional area of a viscous buoyant conduit. Its scaling uses axial length and velocity , where . Linearization at gives : phase velocity is upward but group velocity changes sign at . Nonlinear elevation waves obey the solitary-wave amplitude-speed relation for the conduit equation.
A positive travelling wave on a uniform background has first integral , with . Equating the crest and background potentials gives the displayed speed relation for crest ratio . The elevation-wave speed exceeds and approaches that long-wave speed as . The formula requires the positive-area branch, rather than continuation through .
Bodies immersed in one fluid affect each other through the flow that each produces. At large separation, a force-driven sphere generates a Stokeslet that modifies the other sphere's velocity. These interactions produce off-diagonal entries in the hydrodynamic mobility matrix.
In the free-draining approximation, each separated component of a body experiences its isolated viscous drag, and hydrodynamic interactions between components are neglected. For widely separated spheres of radii in an unbounded Newtonian fluid of dynamic viscosity , Stokes law gives , with . This is a leading approximation in sphere size divided by separation. Any connecting rod must also have negligible drag; a small diameter alone does not guarantee this for an arbitrarily long rod.
Consider two widely separated rigid spheres of equal radius , with separation , in Stokes flow. Apply a force to the first sphere and let the second be force-free and torque-free. The second sphere samples the rate-of-strain tensor of the first sphere's Stokeslet, . Its leading disturbance is the stresslet of a sphere in a uniform straining Stokes flow. Evaluating that disturbance back at the first sphere givesThe hydrodynamic mobility matrix decreases at fixed force, consistently with the increase of resistance caused by an additional rigid inclusion.
If the otherwise force-free second sphere is held against rotation, its angular velocity relative to the incident fluid is . The rotlet reflected back to the first sphere addsThis follows by evaluating the rotating sphere in Stokes flow at displacement and using the vector triple-product identity. The holding couple does no work because the held sphere's angular velocity is zero.
Two spheres whose prescribed translations have a phase lag can exert a nonzero mean force on the fluid while each returns to its starting position. Their changing separation correlates the interaction strength with the other sphere's velocity. This pump is externally driven, so it is distinct from force-free swimming governed by the scallop theorem.
The centre separation for equal-amplitude oscillations has minimum . A bound alone cannot guarantee nonoverlap. An asymptotic mobility calculation needs this minimum much larger than the sphere radii.
For equal oscillation amplitudes , frequency , mean separation and phase lag , the leading mean total force on the fluid is . Each sphere supplies half. The large-separation calculation expands the Stokeslet interaction; reciprocal in-phase and antiphase motions have zero mean force.
For well-separated spheres moving along their line of centres, the leading mobility matrix has diagonal entries and off-diagonal entries . This is the axial Stokeslet interaction. Finite-size and repeated-reflection corrections enter at higher order.
The symmetric first moment of the traction exerted by a rigid inclusion, with the surface normal pointing into the inclusion. Its contraction with the background rate-of-strain tensor is the strain-related contribution to extra dissipation due to a rigid inclusion. A trace-free version is equivalent for an incompressible flow. This tensor is distinct from the axisymmetric force-dipole flow used as a far-field singularity.
Let the ambient velocity be , with symmetric and trace free, and centre a rigid sphere of radius at the origin. It is force-free and torque-free, with zero translation and rotation. Its disturbance isThe total velocity vanishes at , and the leading disturbance is a stresslet. Harmonic dipole and quadrupole potentials in the Papkovich–Neuber representation give the complete field.
With symmetric traceless strain , these harmonic potentials solve the decaying disturbance around a stationary sphere in the convention and . The vector potential supplies the leading stresslet; the scalar degree-two potential corrects no slip at finite radius. Matching the independent and structures fixes both coefficients.
For a steady incompressible flow of a Newtonian fluid with constant density and constant dynamic viscosity , neglecting inertia in the Navier-Stokes equation givesThe first equation is local force balance; the second is mass conservation. The term is the divergence of the viscous part of the Newtonian fluid stress tensor. The body force has units of force per unit volume, , and equals for uniform gravity. Appropriate boundary data for velocity or traction, together with suitable distant conditions for an exterior flow, complete the problem; a rigid surface normally imposes the no-slip boundary condition.
With uniform gravity, write where the hydrostatic pressure satisfies . Then the disturbance equation is . This removes gravity from the fluid disturbance equation, while the hydrostatic pressure still supplies buoyancy on an immersed body. Omitting it from the total force balance would give the wrong Stokes settling velocity.
For variations on a time scale , the ratio of local inertia to viscous resistance is . Steady Stokes flow at each instant requires both and . If only the first is small, retain local acceleration:For an oscillating sphere with angular frequency , the second condition becomes on the radius scale . The Unsteady Stokes equation is still linear, but needs initial data and has memory; its velocity field is not determined by instantaneous boundary velocities alone. See E. J. Hinch, Slow Viscous Flow, example sheet 1, question 1 for the distinction between steady and unsteady limits of an oscillating sphere.
The Stokes equation is linear in velocity, pressure, body force, and boundary data. Solutions may therefore be superposed, and rigid-body velocities depend linearly on applied forces and torques.
With prescribed velocity on the boundary and suitable decay or far-field data, a Stokes flow is unique up to an additive pressure constant. Applying the viscous dissipation identity to the difference of two solutions makes its rate-of-strain tensor vanish; the homogeneous boundary data then eliminate the remaining rigid motion.
Let a viscous layer occupy , with no slip at , zero tangential traction at , and exterior pressure . The Cartesian streamfunction ansatz reduces the Stokes equations to . The resulting surface velocity isso the positive thinning rate is .
A Stokeslet is the velocity field produced by a point force in an unbounded three-dimensional Stokes fluid:
In a three-dimensional exterior Stokes flow with no body force, . The divergence theorem on the fluid between a rigid body and a large sphere gives the displayed force on the body, where points outward from the sphere. The body's outward normal points oppositely to the inner normal of this fluid domain. A nonzero resultant force produces a leading Stokeslet, so velocity is , gauge-fixed pressure is and rate-of-strain tensor is . The finite force is therefore compatible with pointwise decay of the stress tensor. Force-free bodies may have faster decay.
The Oseen tensor is the unbounded three-dimensional incompressible Stokes flow Green tensor relating a point force to the velocity it produces: . At separation , its longitudinal mobility is twice its transverse mobility. It generates the leading far-field hydrodynamic interaction between externally forced particles. The singular value at is not a particle's self mobility; a no-slip sphere instead has self mobility . Walls and near-contact lubrication require different or corrected tensors.
A normal point force at height above a plane with a no-slip boundary condition is balanced by an image Stokeslet , a stresslet of tensor strength , and a source dipole of moment at the reflected point. Here the stresslet convention is , with the free-space Stokes tensor. Substitution on the plane cancels both normal and tangential velocity. The original and image forces cancel their terms, while the image stresslet cancels the remaining force-dipole term; the generic fixed-angle far field is .
Place a normal Stokeslet below a plane and an equal, oppositely directed image at the reflected point above it. The normal velocity of their sum is odd across the plane and the tangential velocity is even. The plane therefore has zero normal velocity and zero normal derivative of tangential velocity, giving zero tangential stress. For a sphere of radius translating towards that plane at speed from distance , the leading radial surface flow is , directed outward. The image's incident flow at the sphere changes its required force by relative order , so the first correction to surface velocity at fixed is ; the isolated sphere's potential-dipole correction occurs only at third order.
Differentiating the Stokeslet gives its rate-of-strain tensor and vorticity, displayed above for . The pressure is . Integrating the Newtonian fluid stress tensor over a sphere enclosing the origin gives traction resultant , fixing the point-force normalization.
An impermeable stress-free plane is enforced for a normally oriented Stokeslet by an oppositely directed image Stokeslet at the reflected point. Two equal normal point forces at the same depth then attract laterally through their image flows.
Slender-body theory approximates the hydrodynamic force on a long thin body by a force density determined primarily by its local tangent and velocity, with logarithmic dependence on the aspect ratio.
For a straight rod , , leading slender-body theory uses . Integration gives and . Axial spin is outside this centreline approximation.
The orientation of a force-free, torque-free infinitely slender straight rod follows background rotation plus the transverse component of strain. The last term preserves . Finite aspect ratio changes the strain coefficient and permits periodic tumbling in a simple shear flow.
A force-free, torque-free straight rod contributes a particle stresslet tensor . Its extra viscous dissipation is . In a simple shear flow, ; the dissipation is greatest along the extensional or compressional axes and vanishes at flow and gradient alignment.
At leading logarithmic order, a straight slender rod with unit tangent and local velocity exerts force per unit lengthwhere depends logarithmically on the rod aspect ratio.
For two perpendicular rods of length joined at one endpoint, the slender-body force density gives translation resistance , rotation resistance , and translation–rotation block . The opposite block is its transpose. Here is the torque about the joint and the force on the fluid. Integrating along each rod proves the entries and makes the symmetry and positivity of a rigid-body resistance matrix explicit.
Attach weights at the joint and at each outer endpoint of the right-angle two-rod resistance matrix geometry. With the first rod initially horizontal and the second vertically upwards, quasistatic Stokes flow gives . For the orientation tends to ; for it tends to . Eliminating time gives and the same rightward net displacement in both cases. For the initial drift is leftwards before reversing. At there is no rotation or lateral drift, illustrating noncommuting infinite-time and parameter limits.
For radius , arc length , tangent angle to the horizontal plane, and local drag coefficient , resistive-force theory givesThe sign of selects the handedness convention. With the force exerted on the fluid taken positive, . Translation-rotation coupling supplies propulsion for a rotating helical microswimmer with a spherical head.
For a slender centreline , , let and use local force density , , . Rotation with angular speed gives , henceAxial translation with speed gives exactly the same coefficient for the torque: . Indeed . Both forces and torques here are exerted on the fluid. In the circular case , this reduces to . The equality is also a consequence of the Lorentz reciprocal theorem, since the local resistance tensor is symmetric.
Local resistive-force theory for a helix gives . Positive local drag therefore guarantees a positive-definite axial resistance matrix and positive viscous power loss. The identity also keeps the denominator in counterrotating two-helix balances positive.
Mirroring the handedness of a helix reverses its axial translation-rotation coupling coefficients while preserving its pure translation and rotation resistances. With for a left-handed helix and the force-on-body convention, .
At fixed orientation, linearity of Stokes flow relates a rigid body's translational velocity to the hydrodynamic force byThe Lorentz reciprocal theorem makes symmetric, and positive viscous dissipation makes it positive definite.
Two widely separated spheres rigidly joined by a hydrodynamically negligible connector obey the free-draining approximation. Their translational hydrodynamic resistance matrix is . The displayed point is the centre about which every pure translation has zero hydrodynamic torque: . A pure rotation about that point gives no resultant force at this order. This is an exact cancellation within the approximation, rather than an exact formula at arbitrary finite separation. It does not assert that every chiral rigid body has an origin eliminating its translation-rotation coupling.
With a consistent force convention, the mobility matrix maps applied generalized forces to rigid-body velocities; it is the inverse of the hydrodynamic resistance matrix. For a sphere with force on the fluid , its isolated mobility is . Coupling between bodies represents hydrodynamic interactions.
Here are forces and torques exerted by the body on the fluid, or the external force and torque needed to maintain its motion. The Lorentz reciprocal theorem for Stokes flow makes the six-dimensional hydrodynamic resistance matrix symmetric. The power identity makes it a positive-definite matrix for a body moving in otherwise stationary unbounded fluid.
For a fixed rigid-body shape and origin in an unbounded stationary Stokes flow, the Lorentz reciprocal theorem makes the off-diagonal blocks of the six-dimensional hydrodynamic resistance matrix transposes. Here are the fluid's force and torque on the body. If every pure translation has zero torque about the chosen origin, then , hence : every pure rotation about that origin has zero resultant force. This conditional statement does not require such an origin to exist for every body.
For two Stokes velocity-stress fields in the same domain,It follows by integrating the divergence of the corresponding cross-work flux and using symmetry of the Newtonian stress.
For two incompressible Stokes flows with the same dynamic viscosity, . The divergence of equals . The cross-strain-rate tensor products cancel by reciprocity. Integrating gives equality of the two surface cross-work terms after adding the corresponding volume body-force work. The outward domain normal must be used consistently, especially at an exterior domain's inner surface.
Use a rotlet as the auxiliary Stokes flow, with a rigid sphere at its center. Its exterior-domain boundary torque is the imposed auxiliary couple. In the Lorentz reciprocal theorem, the actual sphere's zero torque removes the other surface term, while the volume term is the rotlet dotted with the body force. Varying the auxiliary couple gives the displayed angular velocity, assuming the integrals and the far boundary limit converge.
For homogeneous Stokes flow in a smooth bounded volume, use and . The Lorentz reciprocal theorem with a point-force Stokeslet gives the displayed representation, with inside, outside and on a smooth boundary. The double-layer integral at the boundary has its limiting principal-value meaning. In an exterior problem the body's outward normal is opposite to the fluid-domain normal, reversing both boundary terms; a nonzero ambient flow adds its far-boundary contribution.
For a drop with internal viscosity , exterior viscosity , continuous velocity and a decaying exterior Stokes flow, use the drop-outward normal and curvature , twice the mean curvature. Constant surface tension gives . Multiply the interior boundary representation by and add it to the exterior one: the traction difference yields the single-layer term shown, while the viscosity-independent stress kernel yields . Here denote the kernels in boundary integral representation of Stokes flow. For equal viscosities the double layer vanishes.
For an incompressible Newtonian fluid, the nonnegative rate at which viscosity converts mechanical energy into heat is
The positive rate per unit mass at which molecular viscosity removes turbulent kinetic energy, with the fluctuating symmetric velocity-gradient tensor. Its dimensions are velocity squared per time. The integral-scale estimate is , expressing transfer over turnover time ; numerical constants depend on the convention for the turbulent velocity and length scales.
Among all incompressible velocity fields with the same prescribed boundary velocity and far-field behavior, the Stokes flow minimizes viscous dissipation. If , where is the Stokes solution and has homogeneous boundary data, integration by parts and the Stokes equation eliminate the cross term, leaving
At fixed outer boundary velocity, extending the inclusion velocity rigidly through its interior makes the particle flow an admissible competitor for the particle-free Minimum-dissipation theorem for Stokes flow. Its interior rate-of-strain tensor vanishes. For a linear background, the increase in viscous dissipation is force times relative translation, torque times relative rotation, plus the contraction of the particle stresslet tensor with background strain.
At fixed sphere rotation in an annular Stokes flow, add rigid particles with zero net force and torque. Extend their actual rigid velocities through their interiors. The extension is an admissible incompressible competitor in the particle-free annulus, with zero interior rate-of-strain tensor. The Minimum-dissipation theorem for Stokes flow gives . The boundary-work identity gives , because the stationary outer wall and the freely moving particles contribute no power. Equality would require the extension to equal the unique particle-free flow, whose strain cannot vanish on a finite particle volume when . Thus the resistance component along the imposed rotation strictly increases.
A dilute suspension of identical rigid spheres raises the dynamic viscosity by a fraction , where is the particle volume fraction. At imposed trace-free rate-of-strain tensor , a sphere of radius adds viscous dissipation . Multiplication by the number density gives , which added to proves the formula. This is the leading noninteracting-sphere term; hydrodynamic interactions enter at higher concentration.
The Minimum-dissipation theorem for Stokes flow compares fields with fixed boundary velocities. Introducing a freely moving rigid inclusion can reduce velocity and total power at fixed applied force while increasing the resistance at fixed velocity. Extending the inclusion's rigid velocity through its interior adds zero viscous dissipation and gives a trial field in the domain without that inclusion, proving the fixed-velocity comparison.
Take the original sphere on the tube axis, with diagonal positive hydrodynamic resistance matrix and axial force . Add a freely moving neutral sphere and extend its rigid velocity through its interior. The resulting field is admissible in the original domain, so its dissipation obeys for any finite nonoverlapping placement of the extra sphere. Since only the first sphere does external work, , giving the displayed bound without assuming zero transverse velocity or rotation. Strictness follows because equality would require the original nontrivial analytic flow to have zero strain throughout the added ball.
Taking the curl of the planar Stokes equation makes vorticity harmonic. Since vorticity is minus the Laplacian of the stream function,
For a fixed wall at and a wall rotating at at , the quasi-steady Stokes approximation with the no-slip boundary condition givesIndeed the biharmonic equation for is ; the angular basis is . The four wall conditions are , . The outward radial volume flux per unit width is , precisely the negative rate of increase of wedge area. The associated local pressure is . Its logarithmic singularity is integrable, although the ideal hinge requires a microscopic regularization.
Incompressibility and periodicity imply that the spatial mean of the normal velocity is constant with height. Zero normal flow at infinity therefore requires zero mean normal boundary velocity. In the bounded biharmonic stream function for planar Stokes flow solution, the mean streamfunction is a constant plus a term linear in height.
For , biharmonicity gives
. In the wedge , no slip at the lower wall and no penetration plus tangential stress at the upper surface giveThe resulting surface speed is
. In the wedge , no slip at the lower wall and no penetration plus tangential stress at the upper surface giveThe resulting surface speed is
An inner cylinder of radius centered at and an outer cylinder of radius centered at have polar boundaries and . If their angular velocities are and , respectively, the no-slip Stokes flow between them has streamfunctionIts unique interior stagnation point is , and its nonzero streamlines are closed curves around that point.
For a stationary disk of radius in the far-field shear , using and , the exterior solution isIt satisfies no slip at and approaches the imposed shear in velocity.
The surface shear stress isThe torque exerted by the fluid on the disk per unit axial length is therefore
For the classical translating-sphere solution, .
On the sphere, pressure and the normal part of the viscous stress cancel, leaving uniform traction .
For an isolated rigid sphere of radius moving at velocity relative to a distant uniform Newtonian fluid, the drag force exerted by the fluid isThe assumptions are steady incompressible flow, constant dynamic viscosity , an unbounded surrounding fluid, the no-slip boundary condition, and a small diameter-based particle Reynolds number, . Integrating the surface traction in translating-sphere Stokes flow gives the factor : the disturbance pressure contributes to the drag magnitude and the viscous shear stress contributes . See Richard Fitzpatrick, Axisymmetric Stokes Flow Around a Solid Sphere, equations 10.120–10.129.
The result is linear drag: doubling doubles the drag force, and doubling at fixed also doubles it. The required power is , all supplied to viscous dissipation. Density enters the check of the particle Reynolds number, although it does not appear in the leading drag formula.
Nearby walls or other particles change the hydrodynamic resistance matrix and invalidate the isolated-sphere coefficient, even at very small Reynolds number. Finite Reynolds number introduces inertia corrections; the Oseen approximation resolves the distant region where the leading Stokes flow approximation ceases to be uniform. A clean gas bubble has tangential slip and instead obeys clean-bubble Stokes drag, with coefficient in its spherical, negligible-internal-viscosity limit. See H. K. Moffatt, Six Lectures on General Fluid Dynamics, section 3.4 for the sphere solution and its small-Reynolds number limitation. The continuum mechanics and boundary assumptions must also remain valid as the particle becomes very small.
Balancing this Stokes drag law against gravity and buoyancy gives the Stokes settling velocity of an isolated rigid sphere.
Drag on a small particle when the gas mean free path is not negligible relative to its size. Continuum no-slip Stokes friction then needs a slip or kinetic correction depending on pressure and gas-surface interactions.
The exponential inertial relaxation time for linear drag. A no-slip sphere has ; particle density enters this time, whereas fluid density enters the fluid Reynolds number.
The dimensionless factor compares a corrected linear drag resistance with the continuum Stokes's law: dividing by reduces the resistance. The oil drop charge readout and calibration article explains why this matters for electric charge inference.
A spherical clean bubble with negligible internal dynamic viscosity has zero tangential traction and permits tangential slip. In the creeping-flow, negligible-deformation limit its drag is , versus for a no-slip rigid sphere.
A spherical clean bubble with constant gas mass density and prescribed dissolution law obeys . With negligible gas dynamic viscosity, instantaneous terminal velocity is . Eliminating time yields the displayed radius-height relation and maximum rise . This uses an instantaneous force balance; a literally constant speed during shrinkage instead gives linear in height. The Reynolds number must remain small for the Stokes flow drag model to apply.
For a clean inviscid bubble a distance below a gravity-restored approximately flat free surface, the surface displacement scales as . Zero normal velocity and zero tangential traction are imposed to leading order by an opposite normal image Stokeslet at distance from the bubble. Its incident velocity is , which gives the displayed correction at fixed buoyancy. The image can be represented by a same-radius inviscid drop of density in liquid of density . Its deformation-producing strain is , so the leading fractional capillary deformation is ; small Bond number is the conventional stronger sufficient criterion.
A buoyantly rising inviscid bubble in otherwise quiescent unbounded liquid has an exterior Stokeslet with . Its tangential traction vanishes on the sphere. The dynamic normal traction is , while the hydrostatic normal-traction variation is . Their dipoles cancel at the terminal velocity, leaving a constant total normal stress compatible with uniform gas pressure even when surface tension is zero. This is an exact spherical solution in the stated Stokes model, not a proof of shape stability under arbitrary perturbations.
The Stokes–Einstein relation connects translational diffusion and linear drag through . For an unbounded spherical particle, and .
For independent three-dimensional displacements of identical no-slip spheres over lag , the Gaussian Brownian motion likelihood gives the displayed maximum-likelihood diffusion coefficient and inverse-drag radius estimate. The Stokes–Einstein relation assumes an unbounded Newtonian solvent, equilibrium and negligible interparticle coupling. Use squared distances, rather than squaring the mean distance. The endpoint magnitudes contain enough information for this isotropic zero-drift estimate, but not enough to diagnose an unknown directional drift.
Each Cartesian Brownian increment has variance . Summing their normalized squares gives a chi-squared distribution with degrees of freedom. Hence is unbiased and has relative standard deviation . Its inverse is not unbiased: for , . Thus the direct inverse-diffusivity radius estimate has appreciable finite-sample bias when only a few trajectories are observed. Measurement noise or drift adds separate systematic error.
For dilute isolated spheres in a Newtonian solvent, . An experimental check independently measures temperature, viscosity and particle size, then obtains diffusion from a displacement variance or a scattering decay. Drift, walls, concentration effects, aggregation and a hydrodynamic radius different from a structural radius can defeat an unqualified comparison.
For a fixed geometry, the steady Stokes equation maps to when all imposed boundary velocities and disturbance forces are reversed; is pressure relative to any unchanged hydrostatic pressure. Linearity of Stokes flow and Uniqueness of Stokes flow therefore reverse the entire velocity field. If the driving schedule and evolving geometry are retraced, fluid elements retrace their paths too. Reversing just one drive while leaving another applied force unchanged does not meet these conditions.
This reversal concerns the paths, while viscous dissipation remains positive: for a sphere, the required power is unchanged by . A reversed experiment must supply fresh energy. Inertia, Brownian motion and irreversible contact can prevent perfect retracing. Edward M. Purcell illustrated the mechanism with a viscous fluid flow demonstration in Life at low Reynolds number, American Journal of Physics 45, 3–11 (1977).
In a uniform vertical tube, take two spherical particles driven by fixed axial forces, including a force-free particle as a special case. At a side-by-side passage time , their centres lie in one horizontal reflection plane . Reflection reverses the applied axial forces, and time reversal reverses them again. Uniqueness of the particle-velocity initial-value problem therefore identifies the reflected reverse trajectory with the original forward one. Their transverse positions before and after passage are equal at matching axial separations. The argument requires passage without contact and neglects inertia or other nonreversible effects.
Reflection of a uniform tube in a horizontal plane preserves an off-axis sphere's transverse position but reverses the axial force. By linearity, reversing the force reverses every translational velocity. By reflection symmetry, it preserves the transverse velocity. Thus the transverse velocity is zero. The Minimum-dissipation theorem for Stokes flow does not predict motion between different particle positions: it compares velocity fields in one fixed geometry with prescribed boundary velocities. Inertia, deformability or broken geometric symmetry can invalidate this no-migration conclusion.
For a smooth passing encounter of a force-driven sphere with a fixed sphere, isotropy and reflection symmetry imply . Along a force axis , is even and the transverse velocity is odd in . Uniqueness then makes the trajectory fore-aft symmetric and restores the incoming impact parameter downstream. This consequence of kinematic reversibility of Stokes flow remains valid with lubrication resistance, provided the particles remain smooth, noncontacting and subject only to the stated forces. Surface roughness and contact can invalidate these assumptions.
A force-free, torque-free microswimmer in a stationary Newtonian fluid, with negligible fluid and body inertia and steady Stokes flow at each instant, gains no net displacement from a reciprocal stroke: one whose sequence of shapes is exactly retraced in reverse. The environment and boundary conditions must also be unchanged during that retracing. Opening a two-shell swimmer and then closing it follows the same sequence backwards; doing the closure faster does not help, because Linearity of Stokes flow changes the instantaneous velocity by the same factor as the stroke rate.
A single real shape coordinate that travels out and back along an interval gives this cancellation, as computed in the force-free two-sphere stroke. Two independently controlled shape coordinates can instead execute a loop that is not retraced, avoiding this obstruction. Continuous rotation also need not retrace an interval: the helical microswimmer with a spherical head provides another route to propulsion. The scallop theorem is a restriction on a stroke under stated conditions, not a claim that small organisms cannot swim. Purcell presented the opening-and-closing scallop and a swimmer with two hinges in Life at low Reynolds number (1977), figures 6–7.
For spheres linked by a length , axial mobility and imply for their midpoint. The displacement over a periodic stroke is . Unequal radii permit instantaneous midpoint motion but not net translation. This is an explicit one-shape-coordinate example of the scallop theorem.
Articles were limited to the first 100 out of 174 total.
Articles by others on the same topic


Stokes flow refers to the flow of an incompressible viscous fluid at low Reynolds numbers, where inertial forces can be neglected in comparison to viscous forces. This type of flow is governed by the Stokes equations, which are simplified forms of the Navier-Stokes equations. These equations assume that the fluid is Newtonian, meaning its viscosity is constant and the stress is linearly proportional to the rate of strain.