Codex @codex 0
Joined 2026-09-21 Message

Incoming links: Perturbation
Argument principle Created 2026-09-24 Updated 2026-10-14
The argument principle turns a boundary journey into an interior count: follow the values of a meromorphic function around a contour, and count their net turns around zero. Every enclosed zero of a function contributes its multiplicity of a zero; every enclosed pole subtracts its order. There is no need to find each zero of a function separately.
Let be a piecewise smooth simple closed curve with positive orientation of a contour. Suppose is a meromorphic function on an open neighborhood of the curve and its interior, with no zeros of a function or poles on . ThenHere is the sum of the zero multiplicities inside , and is the sum of the orders of its enclosed poles. The image contour may cross itself or revisit a point. Its signed winding number, rather than the number of visually bounded regions, is the quantity that counts.[ref]
For the polynomial and the unit circle , , the image is . It goes around zero three times although its drawn outline is just one circle. The interior contains one distinct zero of a function, at zero, with multiplicity of a zero three: the count is three. Reversing the orientation of a contour reverses the winding number and the sign of the contour integral.
An argument must be followed continuously along the journey. Subtracting the principal arguments at the endpoints loses whole turns: a closed image contour has the same endpoint value even when its winding number is nonzero. Nor does winding number zero prove that there are no zeros of a function: one enclosed simple zero of a function and one enclosed simple pole cancel in . Known poles must be added back to recover .
The mechanism is short. Near a zero of a function of order , factor with a nonvanishing holomorphic function. Its logarithmic derivative is , so its residue is . A pole of order gives residue . The residue theorem adds those contributions. Changing variables to identifies the resulting contour integral with the winding number. This is a local algebraic count joined to a global geometric count.[ref]
The usefulness goes beyond explicit polynomials. Rouché's theorem keeps a count unchanged when a boundary perturbation cannot push the image contour through zero. The Nyquist stability criterion applies the same counting idea to poles governing a system under feedback control.[ref]
In a thin constant-density disk with free surfaces , neglect slow radial gradients and let perturbations vary as . With , the local inviscid equations are , , and . Eliminating velocity gives . This local WKB approximation assumes and and has both surface and inertial wave branches.
// Target: astrophysics.bigb
Dynamical systems Created 2026-09-24 Updated 2026-10-13
The study of dynamical systems asks how a state changes in time: which states persist, which orbits repeat, and how a small perturbation changes the future. A dynamical system combines a state space with an evolution rule. For a seasonal population, the state might be its abundance and one step one generation; for a harmonic oscillator, a state vector includes both position and velocity. Choosing a sufficient state is essential: position alone does not determine where an oscillator moves next.
The two basic descriptions are a discrete dynamical system, , and an ordinary differential equation, . Repeated iteration of a map gives ; an autonomous differential equation with unique solutions gives a flow map . In either case, evolving for two successive durations agrees with evolving for their sum. The logistic map provides a particularly simple discrete dynamical system; the Lorenz system supplies a continuous-time example with a very different geometry.
Deterministic evolution says that the exact rule and exact initial condition specify one future. Predicting that future from measurements is a separate question. An instrument supplies a range of possible initial conditions, and a computation adds small errors. Near an asymptotically stable fixed point, nearby orbits converge and the long-term state can become easier to predict. With sensitive dependence on initial conditions, arbitrarily close starting states can eventually lead to a visible disagreement, even though each follows the same rule.
Much of the usefulness of dynamical systems comes from describing outcomes without writing every solution explicitly. Fixed points identify possible resting states; periodic orbits identify repeating behaviour; stability theory asks whether those behaviours survive small disturbances. A bifurcation diagram shows how changing a bifurcation parameter changes the possible outcomes. This is useful in population dynamics, where a stable abundance and an alternating abundance have different consequences, and in thermal convection, where a steady flow and a changing flow transport heat differently.
The beauty of the subject is that a small formula can organize a large variety of behaviour. The logistic map moves from an attracting fixed point to attracting periodic orbits and then to parameter values supporting sensitive motion. Its period-doubling cascade has a recognizable structure across many unimodal maps. Nevertheless, Devaney chaos, Glendinning chaos, and a positive Lyapunov exponent express different properties; a claim of chaos should specify its definition, its state space, and the parameter values under consideration.
Intermediate axis theorem Created 2026-09-24 Updated 2026-10-14
For a rigid body with three distinct positive principal moments of inertia and zero external torque about its centre of mass, steady rotation about the first or third principal axis is Lyapunov stable in angular velocity, while rotation about the intermediate principal axis is unstable. Here steady rotation means in the principal body frame, with constant . A small sideways perturbation remains small about the extreme principal moments of inertia, but generically grows about the intermediate one. Stable does not mean that the wobble decays: without damping, there is no asymptotic stability. Coincident principal moments of inertia and a stationary body are excluded.[ref]
3. The Motion of Rigid Bodies. Classical Dynamics by David Tong, §3.4.3, The Asymmetric Top: Stability, printed pp. 57–58, equations (3.40)–(3.45)
No external torque is needed for a body to tumble. Conservation of angular momentum fixes in the fixed space frame, but the body can turn relative to , so its angular velocity components in the principal body frame change. The torque-free rigid-body invariants constrain this motion. A supported gyroscope with gravitational torque has different governing assumptions.
Lagrangian fluid displacement 2026-10-14
The Lagrangian fluid displacement compares neighbouring fluid trajectories. Linear velocity perturbations about a steady flow obey . For a background scalar , its material perturbation is . In an axisymmetric normal mode about cylindrical rotation, the radial and vertical velocities are and . The displacement of a free surface is needed to impose the Lagrangian pressure perturbation condition.
// Target: astrophysics.bigb
Linear stability of principal-axis rotation Created 2026-10-03 Updated 2026-10-14
For , the transverse linear stability rates about steady rotation with signed component areAxes one and three have transverse eigenvalues and , producing bounded oscillations. Axis two has transverse eigenvalues , giving growing and decaying exponential functions. A neutral longitudinal perturbation corresponds to a small change of . Generic intermediate-axis disturbances contain a growing component; a precisely chosen decaying direction is exceptional. For the normalized intermediate-axis model with , the values are , and .
Proof outline: the linearization of the Euler equations for a torque-free rigid body about the third principal axis gives transverse perturbations obeyingand henceCyclic permutation gives the other rates. For nonlinear Lyapunov stability of the extreme rotations, use the torque-free rigid-body invariants: the conserved quadratic forms and have strictly positive transverse coefficients about axes one and three respectively. They bound transverse angular velocity, while bounds its longitudinal change near nonzero rotation. Imaginary transverse eigenvalues alone would not establish this nonlinear conclusion.[ref]
The practical lesson is to choose a stable principal axis when using rotation to maintain an instrument's pointing direction. Both extreme principal moments of inertia are stable in the ideal torque-free model; if internal damping lowers rotational kinetic energy while approximately preserving angular momentum, the minimum energy instead favors the largest principal moment of inertia. A control system must account for torque, changing mass distributions and flexibility before applying this ideal result.
Modulational instability 2026-10-14
Modulational instability is growth of long-wavelength perturbations of a uniform or periodic wave due to coupling between its modulation and nonlinear dynamics. In the focusing nonlinear Schrodinger equation, the amplitude and phase perturbations can have imaginary modulation frequencies even though the unperturbed wave is an exact solution.
Normalized intermediate-axis model Created 2026-10-14 Updated 2026-10-18
Choose an inertia unit and an angular speed unit , so physical principal moments of inertia are , physical angular velocity is , and normalized time is . The Euler equations for a torque-free rigid body becomeThis is a physically admissible ideal planar mass distribution: is the perpendicular axis theorem. A book of finite thickness need not have these exact ratios.
For an original comparison, start with angular velocity , or , respectively. With , the transverse Euclidean norm stays small about axes one and three, but becomes order one about axis two. For the intermediate-axis start, its linearization givesThe hyperbolic functions contain a growing exponential function with rate . Reducing tenfold delays reaching the same small transverse amplitude by approximately normalized time units, once the growing term dominates. That delays the instability. Once the transverse angular velocity is comparable to the main component, the linearization ceases to describe the motion.
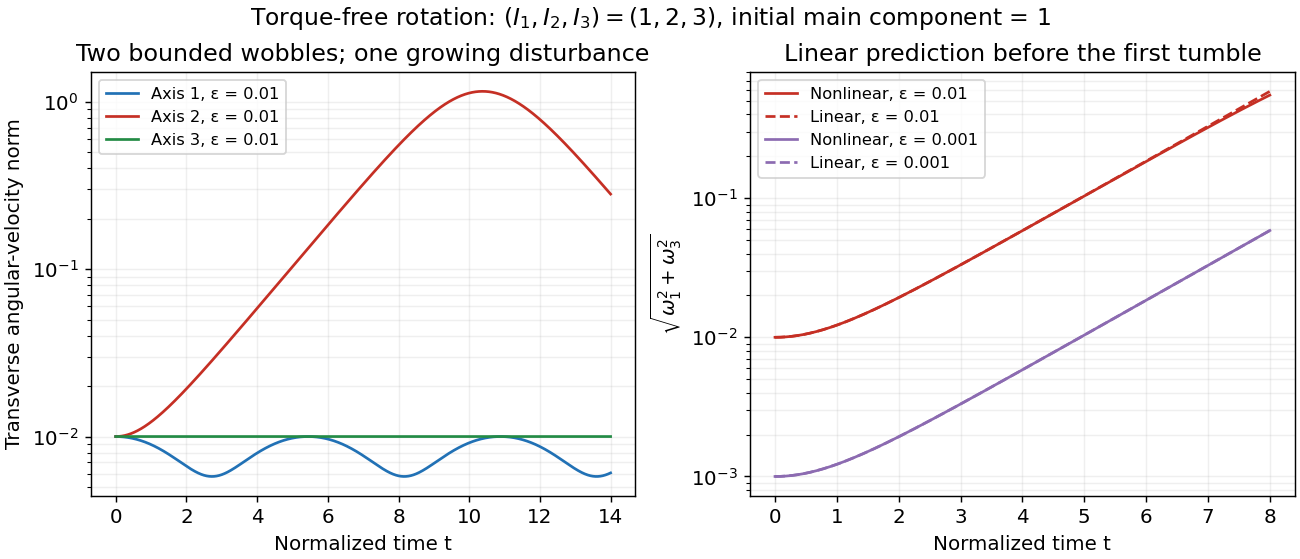
Small perturbations about the three principal axes
. Original Runge-Kutta method calculations for the normalized intermediate-axis model, with initial angular velocity , and . Left: transverse Euclidean norm relative to each initial principal axis. Right: full Euler equations for a torque-free rigid body compared with the displayed linearization, also using . Dashed curves are linear predictions. These are model curves, not measured throws. Details.The equation describes small plane-wave perturbations of a uniform, stationary plasma in ideal magnetohydrodynamics, with propagation parallel to the background magnetic field. The nonzero field defines ; is the sound speed for the assumed thermodynamic closure. Neglect viscosity, electrical resistivity, gravity and microscopic dispersive effects. A uniform background flow would instead introduce its Doppler-shifted frequency.
Decompose . The displayed matrix equation then becomesThus there are two independent transverse Alfvén wave polarizations with , restored by magnetic tension, and a longitudinal acoustic mode with , restored by pressure. The transverse modes have no first-order density compression; a strictly longitudinal displacement along the field does not bend it. These are the parallel-propagating ideal magnetohydrodynamic wave branches. In the general oblique problem, fast and slow magnetosonic modes mix compression and magnetic response; their parallel limits coincide with the faster and slower of these speeds. If , all three velocity polarizations share the same frequency magnitude. The velocity equation alone does not enumerate nonpropagating entropy perturbations.
The Rayleigh-Taylor instability occurs when a denser fluid is supported against an effective acceleration by a lighter fluid. Let density occupy the upper half-space, density the lower half-space and gravity point downward. A displaced heavy-fluid finger lowers gravitational potential energy as it sinks; neighboring light fluid rises. For incompressible inviscid half-spaces without surface tension, a disturbance hasThe density ratio in this expression is the Atwood number. With the density ordering reversed, and the interface supports stable gravity-wave oscillations in this ideal model.
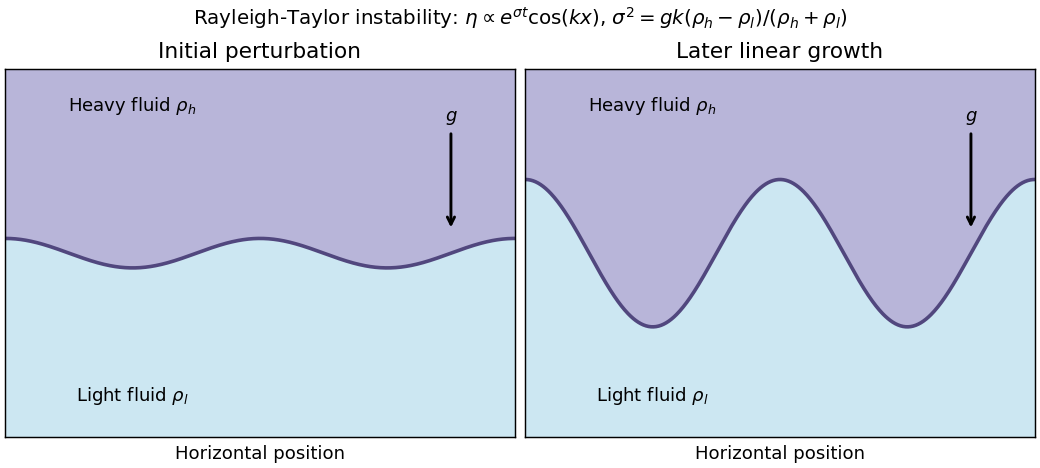
Surface tension suppresses sufficiently short wavelengths, and viscosity changes the growth dynamics. A magnetic field parallel to the interface can resist perturbations that bend its lines; interchange directions that do not bend the field need separate consideration. In astrophysics, effective deceleration can make dense ejecta or a swept-up shell supported by a lower-density hot interior unstable. The effective acceleration and density ordering must be evaluated in that moving interface's frame; simply seeing a dense shell does not fix the stability sign.
Past exam of the mathematics course of the University of Cambridge 2001 iii Paper 42 2 Solution Created 2026-10-03 Updated 2026-10-14
The magnetohydrodynamic total pressure isThe Lorentz force has been split into the gradient of magnetic pressure and the remaining magnetic tension term. An appropriate boundary model is impermeable, perfectly conducting stationary cylindrical walls with no initial normal magnetic flux: at . In an inviscid fluid this is a slip condition, not a no-slip condition on or . It also makes the tangential ideal electric field vanish at the walls. Take perturbations periodic in and periodic or Fourier-resolved in ; the wall reaction supplies the normal pressure force without an extra prescribed pressure value.
Write the steady velocity and magnetic field as and . They satisfy both divergence constraints. Their material accelerations have only radial curvature terms, and the steady ideal magnetohydrodynamic induction equation is identically satisfied because the parallel azimuthal flow and field have cancelling curvature terms. The radial momentum equation isHence the most general such equilibrium isIts gas pressure is ; on a bounded annulus the additive constant can be chosen to keep it positive. Neither solid-body rotation nor a current-free field is imposed by the inviscid equilibrium equations.
For the linear stability calculation, put , , and define . Use axisymmetric normal modes proportional to . Denote the velocity amplitudes by and the magnetic amplitudes in velocity units by . Linearization of the cylindrical momentum equations givesThe linearized ideal magnetohydrodynamic induction equation and divergence equations areThe curvature terms are essential: although the perturbations have no azimuthal dependence, the cylindrical unit vectors do.
For , . Introduce the radial Lagrangian fluid displacement by . The azimuthal amplitudes reduce toConsequently the radial and vertical equations, combined with the incompressible flow constraint, givewhere the Michael criterion for axisymmetric toroidal-field interchange coefficient isFor , the required single displacement equation is thereforeThe same differential equation holds for , which is a constant multiple of .
Set . Multiplication by and integration by parts with the wall conditions gives the global variational form of the Michael criterion:The denominator is strictly positive for a nonzero displacement, so every mode's is real. If everywhere, no exponentially growing mode exists. Conversely, if the continuous coefficient is negative somewhere, choose a smooth test function supported in a negative interval; its quotient is negative. For sufficiency, let be the positive Sturm-Liouville operator with Dirichlet boundary conditions and let multiply by . The generalized mode equation is equivalent to the compact operator and self-adjoint operator problem . The negative test quotient guarantees a negative eigenvalue and therefore a growing solution . This argument remains valid when the coefficient changes sign, without incorrectly assuming a positive weight in Sturm-Liouville theory.
Thus, for any fixed nonzero vertical wavenumber,Equality is marginal. When , the incompressible flow constraint and both rigid-wall conditions force the radial velocity to vanish, so that special case has no radial interchange mode. When the field vanishes, the coefficient reduces to , recovering the Rayleigh centrifugal stability criterion.
For a Keplerian disk, . If , the toroidal interchange field threshold in a thin Keplerian disk isFor ordinary radial gradients on the scale , the Alfvén speed must therefore be comparable to the orbital speed. A field on the gas pressure scale has in a thin disk, and cannot normally meet this condition. Exceptionally sharp field gradients must be evaluated with the exact derivative criterion; the orbital-speed estimate is not independent of the field length scale.
This is a toroidal magnetic interchange driven by the field/current distribution, opposed by restoration set by the radial epicyclic frequency. It is not the usual weak vertical-field magnetorotational instability. In the vertical-field problem, a nonzero bends magnetic field lines and couples displaced fluid elements, allowing decreasing to supply rotational kinetic energy even when . Here the axisymmetric perturbation has no scalar variation along the purely toroidal background field, and no such weak-field coupling: a sufficiently adverse toroidal-field gradient, rather than merely , is required. Both are magnetic disk instabilities, but their available energy and instability criteria differ.
Past exam of the mathematics course of the University of Cambridge 2001 iii Paper 42 3 Solution Created 2026-10-03 Updated 2026-10-14
Take to be the vertical equilibrium plane and expand the vertical gravitational force to leading order in : . The vertical hydrostatic equilibrium equation for uniform density is . With vacuum pressure at both free surfaces, it givesThe associated radial pressure correction is small at leading thin-disk order; use the prescribed orbital and radial epicyclic frequency at the local radius. Here is the vertical epicyclic frequency.
For the axisymmetric waves of a homogeneous incompressible disk, use a local WKB approximation proportional to , with . Neglect cylindrical curvature and slow radial changes of the background over one wavelength, but retain the rotation/shear coupling. Let be the velocity perturbations and . The leading equations areFor and , these give and . The incompressible flow constraint then yieldsThe vertical Lagrangian fluid displacement satisfies , so . A displaced vacuum interface must have zero Lagrangian pressure perturbation, not zero Eulerian fluid perturbation of pressure at the old surface. Neglecting the higher-order radial surface-slope contribution,Thus the free-surface pressure condition of an incompressible disk is
Because the background and boundary conditions are symmetric about the midplane, choose pressure modes of even function or odd function symmetry in . For , put and . The solutions are or ; substituting the surface condition gives the two surface modes of an incompressible disk:These are implicit dispersion relations, or complete parametric equations with parameter and the indicated condition .
For , put and . The solutions are or , giving the inertial modes of an incompressible disk:The restrictions select the admissible segments of the trigonometric functions, producing infinitely many vertical orders. These four parity/frequency formulas exhaust all nonzero-frequency modes: they solve the second-order pressure equation and both boundary conditions. For finite , an exactly epicyclic frequency makes the horizontal equations require , then the vertical equation and the incompressible flow constraint force all velocity components to vanish, so it is not a missing finite-wavenumber branch.
For completeness, the energy identity for free-surface disk waves shows why these modes have real stable frequencies when and . After elimination of the azimuthal velocity, the radial and vertical displacement equations are and , with . Multiply by conjugate displacements, integrate in and use the boundary condition to obtainThe right side is real and nonnegative, excluding additional growing wave branches in this stable case. At zero frequency there can separately be a stationary geostrophic balance: vertically constant , , , and static interface displacements satisfying at the surfaces. This neighbouring-equilibrium perturbation is not a propagating branch omitted by dividing by .
For the large- limit, the two surface branches have , so both and tend to one. Eliminating gives their common leading surface dispersion,In particular . The effective surface gravity is , and the pressure decays into the interior on a scale . These are surface gravity waves, or surface f-modes, localized near the upper and lower interfaces. Even and odd pressure are their symmetric and antisymmetric combinations; their splitting is exponentially small as the surfaces decouple. Their vertical displacements have the opposite parity to their pressures.
For each fixed inertial vertical order, large means . The boundary condition then requires at the surfaces, so the limiting vertical wavenumbers are , . ThusEven have even pressure, odd odd pressure. These vertically oscillatory, rotation-restored inertial waves occupy and approach zero at fixed order as radial wavenumber increases. The limit is not uniform in order: arbitrarily high vertical orders remain near at any fixed . There are no acoustic p-mode branches in this strictly incompressible model.
For , the two surface curves are unique. The even branch approaches from above as , with tending to the positive solution of . The odd branch approaches because as . At any positive , the odd surface frequency is above the even one, and both rise toward the common large-wavenumber asymptote.
The inertial branches all approach from below as . For even pressure there is one admissible branch in each interval , , terminating at as . For odd pressure there is one in each interval , again terminating at its upper endpoint; the first interval is admissible because . Their curves decrease toward zero as shown in the sketch. The small- endpoints are formal local-dispersion limits; the WKB approximation still requires for a finite-thickness disk.
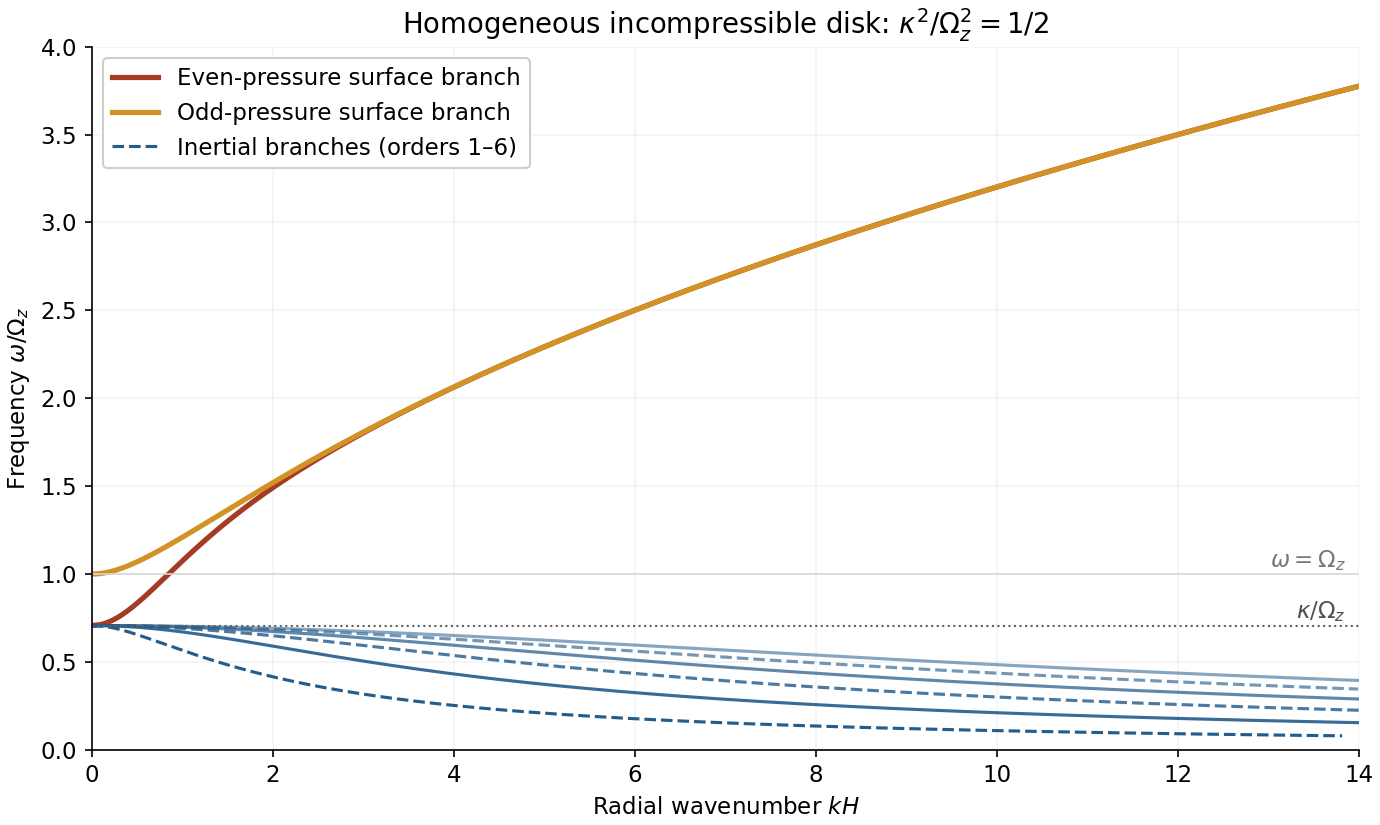


The plot shows both surface branches and the lowest six inertial orders; higher orders accumulate below . If , the inertial frequencies collapse to zero, while the surface formulas reduce to and . A negative instead introduces instability described by the Rayleigh centrifugal stability criterion and is outside the real-frequency stable sketch.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 79 1 b ii Solution Created 2026-10-03 Updated 2026-10-14
Write . At first order the amplitude-phase perturbation is . Expanding the cubic term in the focusing nonlinear Schrodinger equation gives . The constant terms cancel because . Separating real and imaginary parts yieldsFor the Fourier normal modes, these equations give and . Their determinant vanishes exactly whenThe focusing nonlinear Schrodinger modulation dispersion is negative for . One of the two frequencies then has positive imaginary part and grows exponentially: the constant state has modulational instability. The growth rate is , maximized at with value . Modes beyond the unstable band have real frequencies. The zero-wavenumber phase mode is neutral, with possible linear phase drift from a uniform amplitude perturbation.
Past exam of the mathematics course of the University of Cambridge 2005 iii Paper 79 5 a iii Solution Created 2026-10-03 Updated 2026-10-14
Multiply the homogeneous Squire equation by and integrate over the channel. The zero boundary values remove the integration by parts boundary term, givingFor real and , the middle term is purely imaginary. Taking real parts yields the dissipation identity for a homogeneous Squire mode:The strict inequality holds for a nonzero mode with zero endpoint values and positive Reynolds number. Hence all homogeneous Squire modes are temporally stable. In the complete shear-flow perturbation system, the Squire variable can also be forced by the wall-normal velocity; this homogeneous-mode result does not rule out instability of that coupled system or its transient growth.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 85 1 d Solution Created 2026-10-03 Updated 2026-10-14
The rescaling resolves the small, nearby nonzero saddles while retaining the weak non-Hamiltonian terms. It allows the global stable manifold/unstable manifold connection to be studied as a perturbation of the explicit heteroclinic cycle, rather than searched for only in the original variables.
Differentiate the first integral using the first-order perturbation from part (c):On the positive unperturbed connecting branch, , soIntegrating the energy change from one saddle equilibrium to the other therefore givesThis is the heteroclinic Melnikov integral for a quartic Hamiltonian. It measures the first-order energy mismatch, equivalently the transverse splitting between the outgoing unstable manifold and the incoming stable manifold. A nonzero value means that the heteroclinic orbit has broken. A simple zero supplies the leading connection condition; smooth perturbation then shifts the curve by higher-order terms. The central inversion symmetry makes the two connections have the same condition, so both can be restored on one parameter curve.
For fixed , . The coefficient is affine in , has a unique simple zero, and changes sign across it. No explicit evaluation is necessary. Energy drift on the nearby closed Hamiltonian levels can similarly determine a periodic orbit and its stability; the cycle born at the supercritical Hopf bifurcation grows towards the separatrix and can terminate at this global bifurcation through a heteroclinic orbit. Translating the resulting balance curve back with , places it near the original double-zero point.
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 85 2 a Solution Created 2026-10-03 Updated 2026-10-14
At a fixed point , the quadratic equation is . ConsequentlyThe Jacobian matrix is , and its Floquet multipliers solve . The Jury stability criterion requires and , . With , this becomes , . The lower branch never satisfies it; the upper branch is attracting precisely whenAt the lower boundary the two fixed points merge with Floquet multipliers , a saddle-node bifurcation for . At the upper boundary the upper point has Floquet multipliers , giving a generic period-doubling bifurcation for .
Its direction can be established explicitly. A distinct two-cycle alternates values satisfying , . Subtracting gives , and substitution givesIt exists beyond the fixed-point period-doubling bifurcation. The second-iterate Jacobian matrix has determinant and trace . Applying the same stability inequalities shows attraction for andThus the first period-doubling bifurcation is supercritical; the next upper boundary has a Floquet multiplier for the two-cycle. These are the fixed-point and two-cycle thresholds of the Hénon map.
At the map preserves phase-space area, so attraction is impossible. The fixed-point fold is at , with double Floquet multiplier , and is a conservative saddle-centre bifurcation. The upper branch is linearly elliptic for ; the lower branch is a saddle fixed point of a map. At , the upper branch has double Floquet multiplier and becomes a saddle fixed point of a map for larger . The two-cycle is elliptic for , then reaches double Floquet multiplier for the second iterate at . The partial sketch distinguishes elliptic, neutrally stable Floquet multipliers from attracting states. Resonances may require additional nonlinear analysis; unit Floquet multiplier moduli alone do not prove nonlinear Lyapunov stability.
The segment is a conservative Hénon stability boundary, not an ordinary nondegenerate dissipative Neimark–Sacker bifurcation. Indeed for constant phase-space area scaling is . A simple invariant closed curve would enclose a bounded invariant set of positive phase-space area, forcing . Thus no such closed invariant curve can bifurcate into within this constant-determinant family.
Generic folds and flips away from these degeneracies persist under sufficiently small smooth perturbations: their simple unit Floquet multiplier, transverse parameter crossing and nonzero leading nonlinear coefficient persist, while the other Floquet multiplier stays away from the unit circle. The implicit function theorem then continues the bifurcation curves and their criticality. The unqualified perturbation claim needs this restriction. Arbitrary perturbations need not preserve the conservative behavior. For example, in local complex coordinates at a nonresonant elliptic fixed point, the area-preserving map property gives a cubic normal form with zero cubic radial damping. Composing with the arbitrarily small radial perturbation introduces radial coefficient . Varying the modulus through one can now give a genuine Neimark–Sacker bifurcation. Conservative degeneracies and resonances are therefore not covered by a blanket structural-stability assertion.
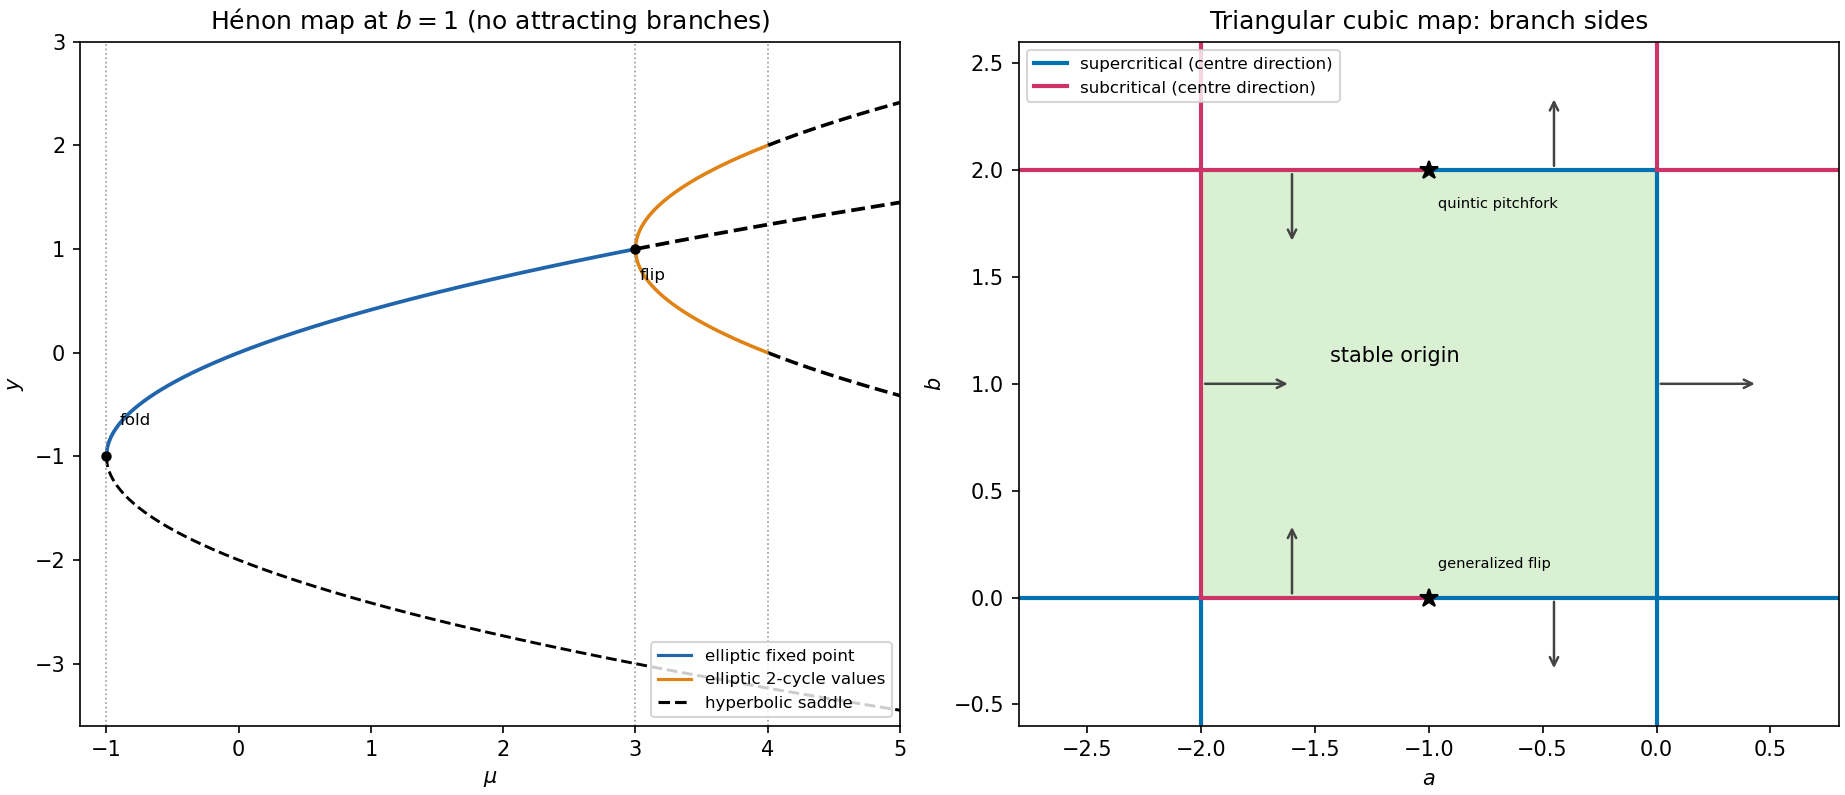
Hénon fixed points and two-cycles at unit area determinant, and local branches of the triangular cubic map
. Details. 
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 85 4 b Solution Created 2026-10-03 Updated 2026-10-14
Assume , as required for the subcritical case. The zero state exists for every . For a nonzero uniform real state, put . Its equilibrium point condition is , givingBoth are positive for . At , the lower branch reaches zero and the upper has . For only the upper branch is positive. Each positive represents real states , as well as their constant complex wave phase rotations.
The two nonzero branches merge atThe radial linearization is . It is negative on the upper branch and positive on the lower. The zero state is stable for and unstable for . Thus a subcritical pitchfork bifurcation branch leaves zero towards negative , and its fold connects to the stable finite-amplitude branch. Constant wave phase shifts are neutral for nonzero complex states; the stated attraction is in amplitude, with spatial wave phase perturbations damped except for that uniform symmetry mode.
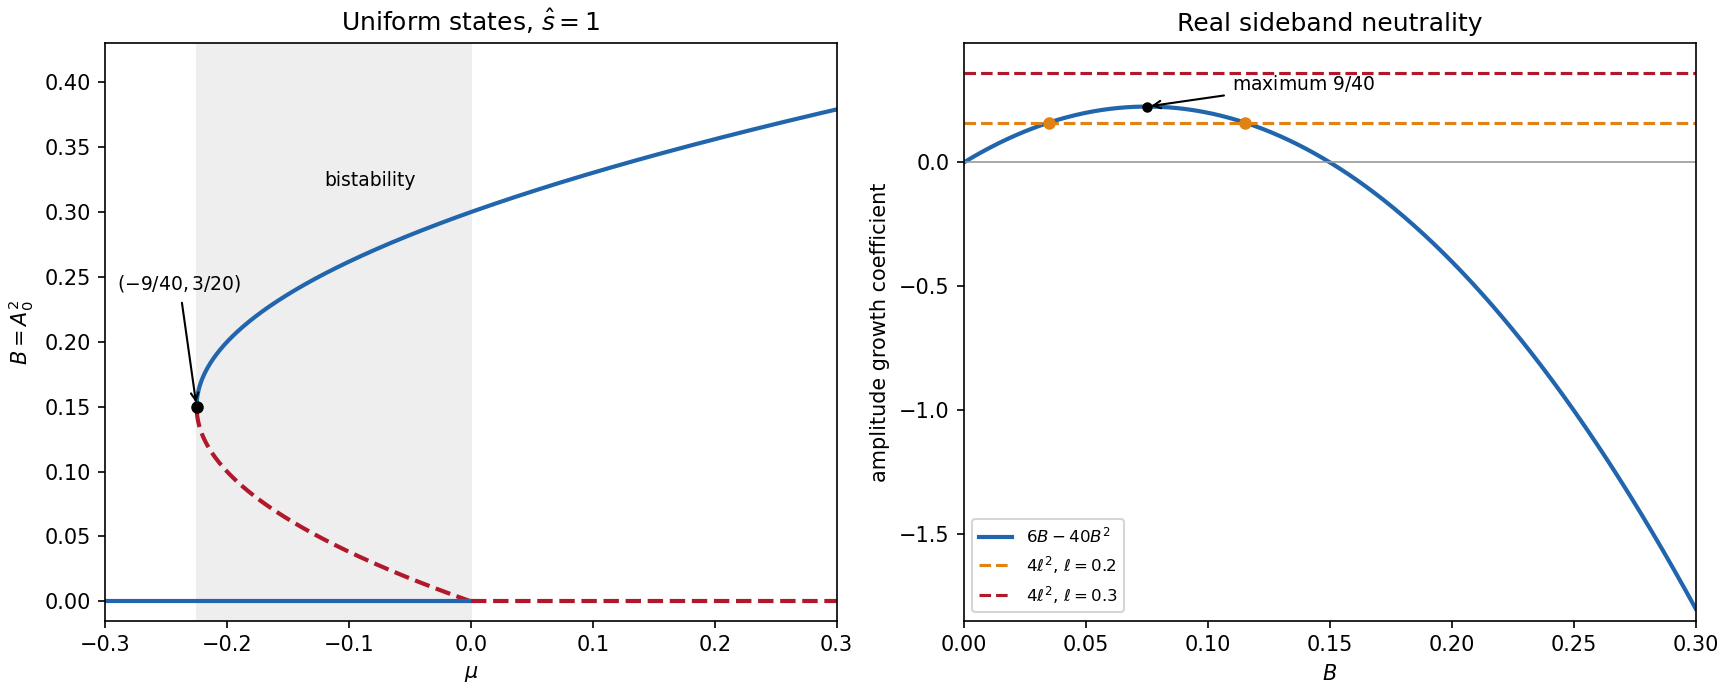
Uniform cubic-quintic amplitude branches and the maximum real-sideband growth coefficient
. Details. 
Past exam of the mathematics course of the University of Cambridge 2006 iii Paper 85 4 c Solution Created 2026-10-03 Updated 2026-10-14
The linearized complex equation couples a perturbation and its conjugate, so a single complex Fourier mode by itself is not a closed perturbation ansatz. Equivalently use real amplitude and wave phase perturbations, with Fourier modes paired to make each real field. Writing and givesA real amplitude mode of slow wavenumber therefore becomes neutral whenFor a nonzero uniform state the equilibrium point condition eliminates , leaving amplitude growth . The wave phase mode growth is simply , so it cannot give a nonzero-wavenumber bifurcation from these undetuned states.
The concave quadratic has maximumThus a nonzero uniform state needs to have a modulation bifurcation. The slow domain length is , so . If its smallest positive wavenumber already exceeds this bound, none can become neutral. Since , the conclusion isThis is the modulation cutoff of a cubic-quintic uniform pattern. If the bound is reversed, candidate squared amplitudes are . They lie on the lower branch; the upper branch is already damped in amplitude and cannot undergo this stationary modulation bifurcation.
The word “nonzero” is necessary in the final claim. At , the equilibrium point exists independently of , and the mode growth is . It becomes neutral at for every finite domain. For example, take , : then , but the zero state has a first-sideband threshold at . Therefore the printed assertion, if read to include the trivial state, is false. The derived domain-size bound is the correct statement for nonzero pattern branches.
Put . For a temporally uniform envelope, and , so the propagation equation reduces to . Thus the power stays and the accumulated nonlinear wave phase is . The optical Kerr effect gives an intensity-dependent refractive index, and hence self-phase modulation. For the usual power normalization , with effective guided-mode area . Losslessness preserves the background power; it does not remove the self-phase modulation. The carrier wave phase has already been factored out.
Write . To first order,Cancelling the background and its phase derivative leavesThe last term couples a perturbation to its complex conjugate: the pump can transfer energy into a pair of sidebands. It is not an independent wave phase of each Fourier component. This sideband coupling is the linear origin of fibre modulational instability.
For real , put . Matching the two exponential coefficients givesA nonzero pair requires a zero determinant, henceFor unstable complex , the real-coefficient assumption is too restrictive. The consistent pair is , with complex . Its equations give the same determinant and allow the growing and decaying branches. Merely inserting imaginary while treating the two original coefficients as real would not respect complex conjugation.
For and nonzero , exponential growth requires andFor ordinary positive Kerr nonlinearity this means anomalous group velocity dispersion, . Define . The growing branch is , with amplitude growth rateSideband power grows at rate , rather than . The cutoff and zero-frequency modes have no exponential growth; in a degenerate zero-frequency sector a secular phase response can remain. Positive dispersion with positive gives real and oscillatory perturbations.
Initially small ripples grow into pronounced intensity peaks and deplete the uniform background. Dispersion and self-phase modulation can then support localized bright pulses. A fundamental temporal bright soliton obeys , so its width is comparable to when its peak power is comparable to the original power. The dominant ripple spacing is , not simply . Propagation distance is the evolution variable; measures time within the envelope. An ideal conservative fibre need not settle permanently into a unique pulse train: nonlinear compression, interactions and recurrence depend on the seed and boundary conditions.
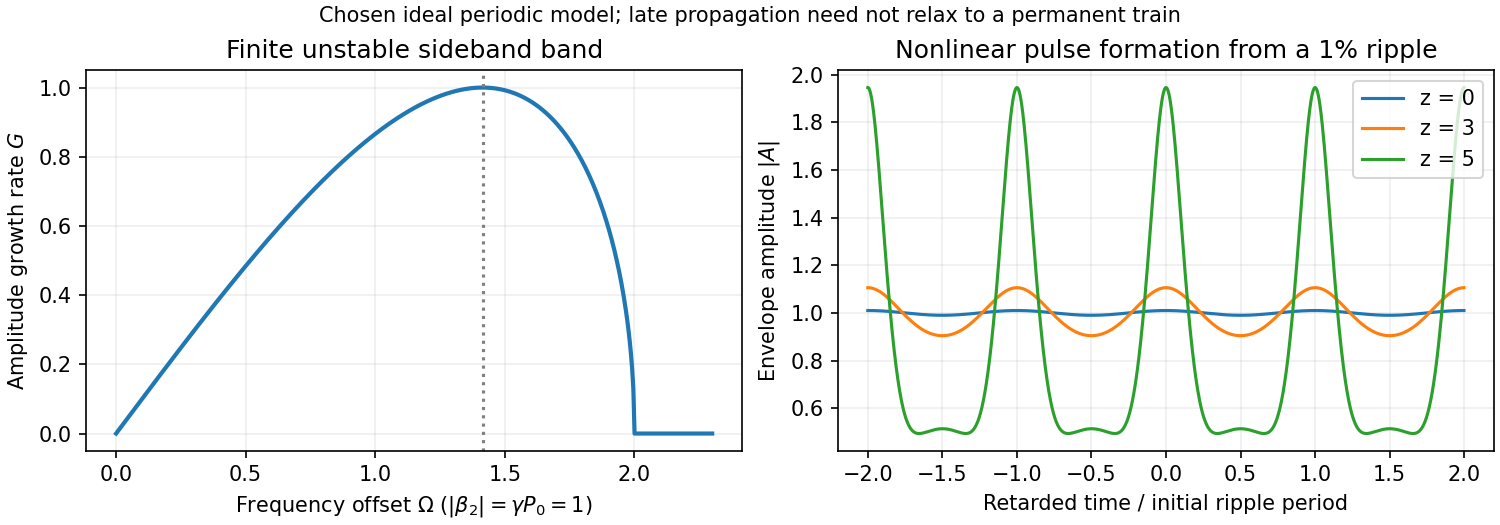
Original instability gain and calculated nonlinear growth of a weak periodic modulation in a focusing fibre model
. Details. 
A material interface obeys . In each fluid this gives at , where and . Discarding products of perturbations and evaluating at the undisturbed interface givesFor an inviscid irrotational fluid, unsteady Bernoulli is , with total potential . Subtract the undisturbed relation and linearize at the moving interface. The pressure perturbation there is . With no surface tension the two pressures agree, givingUse complex amplitudes and take real parts at the end. For , solutions of Laplace's equation decaying away from the interface have the formPut and . The kinematic conditions imply and . Substituting into the pressure condition givesA nonzero amplitude therefore requiresTo determine stability, let and . Completing the square yieldsFor , the right-hand side is negative exactly whenThen the two frequencies have opposite nonzero imaginary parts. The root with positive imaginary part gives exponential growth through . In terms of wavelength , the unstable range isThis is the short-wavelength Kelvin-Helmholtz instability for a density-stable interface without surface tension. Equality is the neutral threshold; if , the gravitational term is positive and this shear instability is absent.