Riemannian geometry studies smooth manifolds equipped with a Riemannian metric: an inner product at each tangent space, varying smoothly with position. This local measuring rule determines angles, arc length, Riemannian distance and geodesics. An inhabitant of a surface can discover its geometry by measuring within it, without knowing how it sits in a larger Euclidean space.
A circular cylinder is a particularly useful example. Its surface bends in space, yet unrolling it preserves the induced metric: a small patch has the geometry of a flat sheet. By contrast, a round sphere has positive Gaussian curvature. The distinction between intrinsic flatness of a circular cylinder and extrinsic curvature separates the geometry an inhabitant measures from the way an outside observer sees the surface bend.
Geodesics supply the analogue of straight lines. On a round sphere they follow great circles; on a circular cylinder they become straight lines when lifted to an unrolled sheet. Their arc length lets us compare candidate routes, as in great-circle distance and Riemannian distance on a circular cylinder. The same measuring rule also defines differential operators such as the Laplace-Beltrami operator, connecting geometry with diffusion and spectral geometry.
Bernhard Riemann's 1854 inaugural lecture proposed studying spaces of arbitrary dimension through their infinitesimal measuring rules, including a positive quadratic expression for the squared line element. This moved the subject beyond a particular surrounding space: the measuring rule itself became part of the geometry. [ref]
https://www.maths.tcd.ie/pub/HistMath/People/Riemann/Geom/. Riemann's original lecture and Clifford's English translation, collected by Trinity College Dublin
.A minimal submanifold has vanishing mean curvature vector, equivalently zero first variation of volume for compactly supported normal variations. A minimal surface is its two-dimensional case. A calibrated submanifold satisfies the stronger property of minimizing volume in its relative homology class.
// Target: general-relativity.bigb
A Riemannian metric satisfying the displayed equation for a vector field and constant . A gradient Ricci soliton has ; it is steady when .
For , the contracted Bianchi identity and the commutation identity imply . Meanwhile , so their sum is constant on every connected component.
The symmetric covariant two-tensor defined using the Levi-Civita connection by . Its negative metric trace is the positive Laplace-Beltrami operator applied to . Along a geodesic it gives the second derivative of .
Spectral geometry studies which properties of a Riemannian manifold can be recovered from the spectrum of geometric differential operators, especially the Laplace-Beltrami operator. Explicit spherical harmonics, Fourier series on a flat torus, and isospectral manifolds illustrate three different aspects of the problem.
For the positive Laplace-Beltrami operator on a closed manifold, the wave trace is the distribution , counting multiplicities. The series is interpreted after testing against smooth compactly supported functions, rather than as an ordinarily convergent sum. Its singularities relate the spectrum to the length spectrum of closed geodesics, through the Duistermaat-Guillemin trace formula.
For the positive Laplace-Beltrami operator on a closed manifold, the singular support of the wave trace lies in zero together with signed lengths of closed geodesics. Under the clean fixed-set hypotheses, its singularity at a periodic-geodesic length has an expansion determined by the geodesic flow and its linearized return map. In particular, when the relevant leading coefficient does not vanish through cancellation, that length is determined by the spectrum. The inclusion of singular supports alone does not justify an unconditional recovery of every geodesic length.
For the positive scalar Laplace-Beltrami operator on a closed -dimensional Riemannian manifold, the number of eigenvalues at most , counted with multiplicity, has the displayed leading asymptotic. The exponent determines the dimension and the coefficient determines the total volume of the Riemannian metric. There is an analogous result with fixed Dirichlet boundary conditions or Neumann boundary conditions on a compact smooth domain.
For a nonnegative elliptic operator on a closed manifold, sum its positive eigenvalues with multiplicity. The defining series converges in a right half-plane. If and is the heat trace, thenSubtracting finitely many terms of the short-time heat kernel expansion gives a meromorphic continuation. Zero eigenvalues must be excluded: assigning them a nonexistent inverse power does not define the spectral zeta function.
For a Laplace-type operator on a closed manifold, let be the constant coefficient of its full heat trace expansion. In the Mellin transform defining the spectral zeta function, the reduced trace has constant coefficient . Its contribution is , and proves the identity. For the scalar positive Laplace-Beltrami operator on a closed surface, and is the number of connected components. In particular, a connected sphere has value and a connected flat torus has value .
For the positive Laplace-Beltrami operator on a closed compact Riemannian manifold, the heat trace is . It records every eigenvalue with multiplicity. In a finite free isometric quotient it equals . The orbital integrals form a class function of the ambient finite isometry group, so Gassmann equivalence gives equal quotient heat traces and hence Sunada theorem.
For a compact smooth Riemannian surface with smooth boundary and a pure Dirichlet boundary condition or pure Neumann boundary condition, the constant coefficient in the heat trace isThe equality is the Gauss-Bonnet theorem. Thus such isospectral manifolds have the same Euler characteristic. A simply connected compact connected bordered surface is a disk with , whereas a nonorientable surface with crosscaps and boundary components has . These cannot be isospectral in this setting. Corners and mixed boundary conditions contribute additional heat coefficients, so the smooth pure-boundary-condition hypothesis is essential.
For the unit and the nonnegative Laplace-Beltrami operator, the eigenvalues are , with multiplicities for . The eigenfunctions are restrictions of degree- harmonic polynomials. The harmonic decomposition of homogeneous polynomials and the Stone-Weierstrass theorem prove completeness.
For a smooth ambient function near the unit sphere, the chain rule along the great circles gives . Sum over an orthonormal basis of the tangent space and supplement it by the radial vector . The geodesic trace formula for the Laplace-Beltrami operator then gives the displayed formula, evaluated at radius one. In particular a degree- harmonic polynomial restricts to a spherical harmonic with positive eigenvalue .
Two Riemannian manifolds are isospectral for a specified differential operator if their eigenvalues, counted with multiplicities and with the same boundary conditions, agree. Riemannian isometries preserve the Laplace-Beltrami operator spectrum, but the converse can fail. The transplantation theorem and the Sunada theorem give systematic constructions.
For a fixed closed orientable Riemannian surface, the smooth metrics with a specified scalar Laplace-Beltrami operator spectrum form a compact set modulo diffeomorphisms, in the smooth topology. This is a compactness assertion, not uniqueness or finiteness of the number of Riemannian isometry classes. It restricts geometric degeneration within an isospectral set and uses more information than the leading heat invariants alone. The theorem was established in the 1988 compactness paper.
A pair of closed orientable flat three-manifolds with equal scalar Laplace-Beltrami operator spectra but different first Betti numbers, respectively one and zero. Consequently they are not homeomorphic. They cannot be isospectral for the Hodge Laplacian on one-forms, whose zero-eigenvalue multiplicity is the first Betti number. This shows why the spectrum on functions must not be silently replaced by the spectra on all differential forms.
For a fixed closed hyperbolic surface, there are only finitely many isometry classes with its Laplacian spectrum. The Selberg trace formula gives a common discrete length spectrum and common positive hyperbolic systole. Mumford's compactness theorem confines this family to a compact subset of moduli space. If distinct members accumulated, choose nearby markings at an accumulation point and use finite length coordinates for hyperbolic surfaces. Each of these finitely many lengths converges while remaining in one discrete spectrum, so it is eventually constant. The length coordinates then force eventual equality, a contradiction. This finiteness theorem is weaker than the Wolpert generic spectral rigidity theorem.
Suppose a finite group acts by Riemannian isometries on a compact Riemannian manifold , and Gassmann equivalent subgroups act freely. The quotient manifolds have equal Laplace-Beltrami operator spectra. For an eigenfunction space , the quotient multiplicity is , and the equality follows by summing its character of a representation over conjugacy classes. Nonconjugacy inside alone does not guarantee that the quotients are nonisometric.
For a finite subgroup of a group of Riemannian isometries of a closed manifold , assume acts freely and define . Invariance of the Riemannian heat kernel and change of variables show that is a class function on . For , the heat kernel on a finite isometric quotient and integration over a fundamental domain give the displayed heat trace formula. Grouping by conjugacy classes proves equality for Gassmann equivalent subgroups. More generally the same argument allows fixed points of outside the freely acting subgroups; only the quotient under consideration must be smooth.
A finite isometry group decomposes into its irreducible representation factors and multiplicity Hilbert spaces . The Laplacian commutes with the group, so it acts as the identity on each representation factor. The averaging projection gives . For Gassmann equivalent subgroups these dimensions agree. Choosing unitary identifications of the invariant finite-dimensional factors therefore intertwines the quotient Laplacians, even when a noncompact covering manifold has no finite heat trace.
Let two finite locally isometric covers carry uniquely length-identified primitive closed geodesics . If their geometric intersection numbers differ, the covering surfaces are not isometric, because an isometry preserves both lengths and intersections. For base simple curves intersecting once, lift components correspond to cycles of their monodromy permutations. Their intersection number is the number of sheets common to the two cycles. This distinguishes covers even when every individual permutation has the same cycle type in both actions, as in Gassmann equivalence.
In a finite hyperbolic covering, primitive lifts of a primitive closed geodesic correspond to cycles of its monodromy permutation; an -cycle gives length . In a real-analytic family of compact hyperbolic surfaces or hyperbolic cone orbifolds, a prescribed multiple of a simple curve's length can be isolated generically from unrelated lifted lengths. To exclude an identity of length functions, pinch the simple curve: only its peripheral powers can have length tending to zero, while intersecting curves are long by the collar lemma. The countably many remaining length equalities have empty interior, so the Baire category theorem supplies a parameter avoiding them. Only finitely many closed geodesics lie below a fixed local length bound; thus the isolation persists in an open parameter neighbourhood. This makes cycle-intersection information an intrinsic obstruction to an isometry, rather than an invariant of a chosen covering map alone.
If two simple base geodesics meet once, their lift components correspond to the cycles of their monodromy permutations. A lifted crossing belongs to the sheet labels common to both cycles, giving the displayed geometric intersection count. When their relevant lifted lengths identify these components independently of the covering map, different multisets of intersection counts obstruct an isometry between the covering surfaces.
Take a hyperbolic torus with a single cone point of angle . Its orbifold fundamental group is . An epimorphism to whose commutator has exact order has torsion-free kernel. The point and line stabilizers have index and order , hence avoid all nontrivial cone stabilizers. Their quotient covers are smooth surfaces with Euler characteristic , so have genus . Their equal coset permutation characters give equal heat traces by the Sunada theorem. Nonisometry still requires a geometric distinction, such as the intersection test for nonisometric finite covers.
A Lambert quadrilateral with acute angle and sides incident to the opposite right-angle vertex satisfies the displayed relation. Reflect four copies around that vertex to make a symmetric hyperbolic quadrilateral whose four corner angles are . Identifying opposite sides yields a torus with one cone angle . The two central axis loops have lengths and meet once at right angles. Cutting along one loop gives a pair of pants with two equal geodesic boundaries and the cone point; reglue the boundaries with a Fenchel–Nielsen twist to obtain the two-parameter cone-torus family. Its seven-sheeted torsion-free covers have genus four.
Let a finite group be generated by elements of exact orders whose product has exact order , with . The epimorphism from the hyperbolic triangle group sending its generators to these elements has torsion-free kernel. Its quotient of the hyperbolic plane is a closed surface with a action. A subgroup acts freely precisely when it meets no conjugate of a nonidentity power of the three elliptic generators. Free almost conjugate subgroups give isospectral manifolds by the Sunada theorem.
Write triangle-group generators as products , of adjacent side reflections. Conjugation by sends both to their inverses. A sheet relabelling satisfying the displayed two permutation identities therefore lifts this base reflection to an orientation-reversing isometry between the two hyperbolic covers. Thus nonconjugate subgroups in the orientation-preserving finite group can still give isometric covers.
For a finite isometric group action on a closed Riemannian surface, choose a disk in the free locus whose translates are disjoint. Modify the Riemannian metric there, and identically on its translates, by small supported changes with three distinguished high Gaussian curvature maxima. Give their heights distinct values occurring nowhere else, arrange them as a tight noncollinear cluster, and keep separate clusters far apart. Such markers can be made by local conformal bump functions controlling curvature and its derivatives. Every quotient isometry must send an entire labelled cluster to another. After identifying the marked disks with the original one, an isometry fixes its three noncollinear points and is therefore the identity locally. If are free finite quotients, any quotient isometry consequently makes on an open disk for some element of the original group. Two local isometries agreeing on an open set agree on the connected surface, by propagation along geodesics. The equality therefore holds globally and implies , hence equality for equal subgroup orders. Nonconjugate equal-order subgroups thus have nonisometric quotients for this marked invariant metric; constant curvature is not required.
Suppose a fixed pair of Gassmann equivalent finite covers of a compact two-dimensional orbifold has isometric limiting hyperbolic metrics. Choose nearby orbifold-smooth nowhere locally homogeneous metrics and rescale them to the displayed distinct areas. Scaling by a positive constant multiplies area by that constant in dimension two, preserves local rigidity, and preserves convergence when the constants tend to one. Sunada theorem supplies equal spectra within each pair. Local rigidity forces any quotient isometry to descend to the identity on the base; nonconjugate covering subgroups therefore exclude within-pair isometry. Distinct areas exclude all cross-pair isometries and spectra, because the leading heat trace coefficient is area divided by . Fixed markings of the two isometric limiting covers give convergence to the same metric. The existence of those isometric limits is an additional geometric input, not a consequence of Gassmann equivalence alone.
Choose distinct odd primes and take products of the nonisomorphic Gassmann equivalent regular subgroups, selecting one of the two groups at each prime. Product conjugacy-class counts give Gassmann equivalent subgroups of the same finite product of symmetric groups. Their fundamental groups are distinguished by whether the unique Sylow subgroup at each chosen prime is abelian. The closed-manifold realization of a finitely presented fundamental group and Sunada theorem therefore produce pairwise nonhomeomorphic, and hence nonisometric, isospectral closed four-manifolds. Gassmann equivalence alone, without a topology distinction, does not imply nonhomeomorphism.
For two assemblies of congruent Euclidean tiles, let encode the gluing or boundary reflection at each labelled face. An invertible constant matrix satisfying carries tile restrictions of Laplacian eigenfunctions bijectively to those on the second assembly. Boundary values satisfy and outward normal derivatives satisfy , so the intertwining identities preserve matching and boundary conditions. Use diagonal for a Dirichlet boundary condition and for a Neumann boundary condition.
Suppose an invertible real matrix intertwines symmetric orthogonal tile-reflection matrices: . Then commutes with every , so its positive inverse square root does too. The polar decomposition of an invertible real matrix therefore gives an orthogonal matrix satisfying . On a disjoint union of congruent tiles, preserves both the inner product and Dirichlet energy. The intertwining identities preserve the face trace conditions defining the assembled Sobolev space, so gives a unitary equivalence of the assembled Laplacians.
Take seven copies of a scalene triangle, with sides labelled opposite its three vertices, and reflect adjacent copies across their glued side. For the first planar domain, the glued pairs are , , ; for the second they are , , . Both coloured trees have central tile . For triangles sufficiently close to equilateral the interiors do not overlap. If its three angles are distinct and between and , the only reentrant vertices are the original central vertices, with angles four times the corresponding triangle angles. They force any proposed isometry to preserve the labelled central triangle, which is incompatible with the different attachments on its arms.
For the spectral proof index the nonzero vectors and covectors of by , using binary coordinates. The Fano plane incidence matrix is . It satisfies , so is invertible, and intertwines the point and line permutations of each of the three elementary transvections. Put . The signed reflection matrices for the Dirichlet boundary condition are and , hence intertwines them. Its polar orthogonal factor gives a unitary equivalence of the Dirichlet Laplacians, preserving both the inner product and the Dirichlet energy of the piecewise functions. This produces a three-parameter family of noncongruent isospectral planar domains.
Take four congruent octagonal regular polygons with four alternate sides labelled . The intervening sides have Neumann boundary conditions. Pair equal face parameters in the positive reference boundary direction. The complete gluing data areAll unpaired labelled faces not in a Dirichlet column also have Neumann boundary conditions. Encode these rules by signed permutation matrices, using a positive swap for a paired interface and diagonal or for an unpaired Dirichlet boundary condition or Neumann boundary condition. The four-by-four Hadamard matrix above satisfies for every label. Explicitly, if its columns are , applying gives respectively , , , and , which are exactly the columns of the corresponding . On every intervening face the face matrix is the identity.
Since , the orthogonal matrix preserves the inner product and the sum of Dirichlet energies. Its intertwining relations map matching Sobolev traces and zero Dirichlet traces bijectively to those of the other assembly. It therefore preserves the quadratic form domains and the forms themselves. The associated self-adjoint operators are unitarily equivalent, proving equality of all eigenvalues with their multiplicities for the specified mixed boundary conditions.
The topology of disk tiles glued along disjoint boundary arcs shows that , whose gluing graph is in a path, is a closed disc and is simply connected and orientable. The gluing graph of has edges ; it is connected with two independent cycles, so and . Its odd cycle makes it a nonorientable surface. Each assembled surface has nonempty polygonal boundary. This explicitly realizes isospectrality between a simply-connected orientable bordered surface and a nonorientable, non-simply-connected one. The boundary corners and mixed boundary conditions are essential qualifications; it does not contradict the Euler characteristic from the heat trace of a bordered surface for smooth boundaries and pure boundary conditions.
Take eight congruent hexagonal tiles with three pairwise nonadjacent distinguished faces. On tile indices modulo eight let , , and use for one assembly and for the other. Pair faces by reflection and leave fixed faces, and the three remaining faces, with Neumann boundary conditions. If , the displayed matrix intertwines all three face actions: its circulant coefficients satisfy . Its eigenvalues are , which are nonzero for . The transplantation theorem gives equal spectra. The second gluing graph is bipartite, with parts and , so it is orientable. The first has the odd cycle and is nonorientable. Both graphs are connected with eight vertices and ten edges, and their bordered surfaces retract up to homotopy to the graphs. Both have Euler characteristic and fundamental groups free of rank three. Neither is simply connected.
Consider assemblies of congruent polygonal tiles with same-labelled faces paired by reflection and pure Neumann boundary conditions on unpaired faces. An invertible intertwiner for all face permutation matrices preserves the Euler characteristic. The number of tiles is the dimension of the representation. For each face label the number of edge classes is . For each vertex label the number of vertex classes is the number of orbits of the subgroup generated by incident-face involutions, hence the dimension of its invariant vectors. Intertwining preserves all these numbers. Summing the vertex and edge counts proves equal , including boundary corners. This argument uses genuine permutation matrices; signed matrices encoding mixed boundary conditions do not give the same topological count.
Reflection across a cut splits Laplacian eigenfunctions into odd and even parts. The odd restriction has a Dirichlet boundary condition on the cut; the even restriction has a Neumann boundary condition there. The displayed matrix intertwines the two-tile swap with . A connected uniform-Dirichlet rectangle of width is therefore isospectral to the disjoint union of width- rectangles with all-Dirichlet and three-Dirichlet/one-Neumann conditions. This illustrates why changing boundary conditions can conceal connectedness in the spectrum.
A propeller domain consists of seven congruent reflected triangles: one central triangle and three arms of two triangles each. There are different coloured gluing patterns whose Dirichlet Laplacian and Neumann Laplacian spectra agree by the transplantation theorem. Varying the three side lengths of a scalene triangle in a suitable open region gives three parameters; the central triangle is identifiable from the three reflex corners, allowing a direct nonisometry proof.
A class of metrics is spectrally rigid if equality of their specified spectra forces the metrics to be isometric, or, in a deformation version, if continuous isospectral deformations are trivial. The spectrum of a flat torus determines every two-dimensional flat torus up to isometry. The Wolpert generic spectral rigidity theorem is a generic, rather than universal, uniqueness statement.
For closed hyperbolic surfaces of genus , there is a closed proper real-analytic exceptional subset of Teichmüller space such that a surface outside it is determined up to isometry by its unmarked length spectrum, equivalently its Laplace-Beltrami operator spectrum. The analytic part of the proof controls possible spectral matchings using finite determining length data; the geometric part recognizes persistent matchings as changes of marking, using the collar lemma and variations of Fenchel–Nielsen coordinates. Orientation reversal remains invisible to the spectrum.
A Riemannian manifold is a pair consisting of a smooth manifold and a Riemannian metric . For each point , the positive-definite inner product on its tangent space tells us the size and angle of possible instantaneous movements. The smooth manifold describes which local coordinates are possible; the Riemannian metric adds a choice of measurement.
For example, the plane can carry or . In the second Riemannian metric, a horizontal displacement costs twice as much length as the same coordinate displacement in the first. The underlying smooth manifold is unchanged. The coordinate transformation identifies the second geometry with an ordinary Euclidean plane, illustrating why coordinate appearance alone does not determine curvature.
A round sphere with its induced metric is another Riemannian manifold. Its tangent spaces each have an ordinary Euclidean inner product, although its global geometry is different from a plane's. This is the useful tension: measurements are Euclidean to first order at a point, while how those measurements fit together produces curvature and global restrictions on geodesics.
A linear isometry between tangent spaces of complete simply connected Riemannian manifolds extends to a global isometry when parallel transport along corresponding broken geodesics identifies their Riemann curvature tensors. In particular, complete simply connected manifolds of the same dimension and constant sectional curvature are isometric: their curvature tensors are determined by that common constant and their Riemannian metrics. This is the constant-curvature form often called Cartan's theorem.
For a connected complete Riemannian manifold of dimension and constant sectional curvature , its complete simply connected universal cover is the round sphere of radius . This is the constant-curvature case of Cartan-Ambrose-Hicks theorem. Thus the manifold is a quotient by a finite group of isometries acting freely. In even dimension, the determinant embeds this group in : every determinant-one orthogonal transformation in odd ambient dimension has eigenvalue one and therefore a fixed point. The only possible nonidentity element is the antipodal involution, giving Real projective space. In odd dimensions, free cyclic scalar actions on complex unit spheres instead produce lens spaces.
A Riemannian manifold is locally symmetric when its Riemann curvature tensor is parallel for the Levi-Civita connection. Along a geodesic, parallel transport then conjugates the Jacobi curvature operator at the initial point to the operator at every later point. Thus its eigenvalues stay constant. The condition is local and does not assert that global point reflections extend to isometries of the whole manifold.
Diagonalize the self-adjoint Jacobi curvature operator at the initial point and transport its orthonormal eigenbasis parallel along the geodesic. The Jacobi field equation reduces to . For zero initial position and initial derivative , the solution is when , when , and when . Only positive eigenvalues contribute conjugate points, at . At a common zero the multiplicity is the sum of the contributing eigenspace dimensions. The displayed convention uses the curvature operator positive on a positively curved plane; reversing the tensor convention also reverses its tensor formula.
The map gives a collar in which the metric has this form. Two metrics with the same induced boundary metric can be identified by their normal collars, fixing the boundary and matching full tangent-space metrics there. To extend the local identification globally, interpolate the metrics, form their smoothly varying collars, and extend the resulting collar isotopy velocity by a cutoff. The time-dependent vector field vanishes on the boundary and agrees with that velocity near it, so its global flow gives the desired boundary-fixing diffeomorphism.
A compact manifold with boundary is simple when the boundary is strictly convex and any two points are joined by a unique geodesic depending smoothly on the endpoints, without conjugate points. Geodesics exit in finite time. These properties make off-diagonal boundary distance derivatives and the geodesic scattering relation well behaved.
For an inward unit boundary vector, the geodesic scattering relation returns the next boundary point and its outgoing unit velocity. On outward vectors it can be extended using the first backward exit, giving an involution on the full boundary unit bundle, with tangential vectors fixed. Exit time is separate lens data; on a simple manifold it equals boundary distance between the endpoint pair.
With the full boundary metric fixed, first variation gives and for tangential endpoint variations. These covectors recover the tangential parts of both unit velocities. Their normal components follow from unit length and the inward/outward sign, so equal boundary distances give equal scattering relations. Without a fixed boundary metric, the bundle identification must first be gauged by a boundary-fixing diffeomorphism.
The boundary distance is the intrinsic distance between boundary points. Its infinitesimal limit along boundary curves recovers the induced metric on the boundary tangent bundle. It does not directly fix the normal and mixed metric components, which can be changed by boundary-fixing diffeomorphisms.
A Riemannian manifold is homogeneous when its isometry group acts transitively on points. For example, a Lie group with a left-invariant metric is homogeneous under left translations. Homogeneity gives the same local metric-ball geometry at every point, which yields the completeness of homogeneous Riemannian manifolds. It does not imply two-point homogeneity: that stronger property also controls directions and pairs at equal distance.
A connected Riemannian manifold is two-point homogeneous if its isometry group is transitive on ordered pairs at each fixed Riemannian distance. The equal-distance condition is necessary because isometries preserve distance. Round spheres and Euclidean spaces are examples. The unit tangent transitivity characterizes two-point homogeneity lemma shows that this pair condition is equivalent to transitivity on the unit tangent bundle.
For a connected Riemannian manifold, two-point homogeneity is equivalent to the isometry group being transitive on the unit tangent bundle. One direction follows by taking short equal-length radial geodesic segments: the Gauss lemma identifies their distance, and injectivity of the exponential map identifies the initial directions after the endpoints are matched. Conversely, unit tangent transitivity implies point homogeneity, hence completeness. The Hopf-Rinow theorem supplies minimizing geodesics for arbitrary equal-distance pairs. Matching their initial unit tangent vectors and using uniqueness of the geodesic equation matches their other endpoints.
In a homogeneous Riemannian manifold, choose so that one closed metric ball is compact. Such a ball exists from local compactness and the metric topology. Every radius- ball is isometric to it. A Cauchy sequence eventually lies in one such compact ball, has a convergent subsequence, and therefore converges. This proves metric completeness; the Hopf-Rinow theorem gives geodesic completeness and minimizing geodesics between points.
A conical singularity is a failure of smoothness at the apex of a metric cone. If has period , small circles have circumference-to-radius ratio . The two-dimensional apex is smooth precisely when this equals . Euclidean black-hole regularity condition applies this test to the imaginary-time and radial plane.
A Killing-Yano tensor is a differential form satisfying the displayed equation for the Levi-Civita connection. Its covariant derivative is totally antisymmetric. Contraction with the velocity of an affinely parametrized geodesic gives a form that is carried by parallel transport along that geodesic. This differs from a Killing tensor, which is symmetric.
For a Killing-Yano two-form, is a differential three-form. Along a geodesic with velocity , the covector is carried by parallel transport, since .
The square is a rank-two Killing tensor. It is symmetric because it pairs the covectors and using the metric. Along every affinely parametrized geodesic, its contraction is the squared norm of the carried by parallel transport covector . Metric compatibility makes that norm constant, proving the Killing tensor equation. On a Riemannian manifold this tensor is positive semidefinite.
A Killing tensor is a symmetric covariant tensor satisfying the displayed equation for the Levi-Civita connection. Its contraction with copies of a geodesic velocity is constant along every affinely parametrized geodesic. The converse follows because the resulting symmetric derivative is determined by its homogeneous polynomial on tangent vectors. Rank one recovers the Killing vector field after metric duality.
A symmetric two-tensor satisfying this equation gives a quadratic geodesic first integral. Examples include the Riemannian metric, symmetric products of metric-dual Killing vector fields, and the square of a Killing-Yano two-form.
A quadratic homogeneous polynomial in the fibre variables of the cotangent bundle is a first integral of the geodesic Hamiltonian exactly when its symmetric lowered coefficients form a rank-two Killing tensor. For , the Poisson bracket is , so the equivalence follows by comparing cubic coefficients at every point.
A spin manifold is an oriented Riemannian manifold whose orthonormal frame bundle lifts from to its double cover . Such a lift defines a spinor bundle.
A chosen spin structure on a spin manifold defines the complex spinor bundle associated to the spin representation. In dimension its vector bundle rank is . Its chirality matrix is in the negative Clifford multiplication convention. It satisfies and anticommutes with each , giving and an odd Dirac operator. In odd dimension there is no such canonical chiral splitting of the irreducible spinor bundle.
A spin structure is a consistent choice of lifting oriented orthonormal frame changes to their spin double cover, permitting globally defined spinor fields. For a spatial circle in a worldsheet, the two choices give periodic and antiperiodic fermions, hence the Ramond sector and Neveu–Schwarz sector. Local field equations do not choose the global spin structure.
A Spin-c structure on an oriented rank- real vector bundle is a lift of its oriented frame bundle to . Its determinant line bundle is associated with ; its First Chern class reduces modulo two to the second Stiefel–Whitney class. When such structures exist, their isomorphism classes form an affine space over ; tensoring by a complex line bundle of first Chern class changes the determinant class by . On a closed oriented three-manifold they always exist. On a four-manifold, the determinant class is characteristic: .
A spinor field is a section of a spinor bundle. Clifford multiplication by tangent vectors acts fiberwise on spinor fields.
The Dirac operator is the first-order elliptic operator obtained by composing the spin connection with Clifford multiplication. On an even-dimensional compact spin manifold it exchanges positive and negative chirality spinors.
For the oriented round unit two-sphere, positive and negative spinor bundles have degrees . Its Dirac operator has on their homogeneous sections, where is the angular-momentum Casimir operator; the eigenvalues of are the nonzero integers. Therefore the chiral phase is a unitary between the two L2 chiral spaces, commuting with . For a smooth function , is bounded. The sign-operator resolvent integral expresses its phase commutator as a norm-convergent integral of compact resolvent products bounded by a constant times . Thus it intertwines multiplication by every continuous function modulo compacts. Its full graded phase is self-adjoint; the chiral phase is the component relevant to nonzero compressed indices.
Let project onto a degree-one equivariant line bundle on the complex-oriented round two-sphere, and let be its positive-to-negative chiral Dirac operator phase. The compressed map has parametrix modulo compacts. Its domain bundle has degree zero and its target degree two. Their homogeneous line-bundle representations on the two-sphere are respectively and , so the equivariant Fredholm index is the trivial representation and the ordinary index is one. Reversing chirality negates the index. Compressing the full self-adjoint phase instead gives ordinary index zero.
For a Twisted Dirac operator on a closed even-dimensional spin manifold, the theorem identifies its analytic Fredholm index with the integral of the top-degree part of the A-hat form times the Chern character. This is one geometric specialization of the general theorem for elliptic differential operators, which expresses the analytic index in terms of the topological class of the principal symbol. The heat proof pairs all positive eigenvalues by the odd Dirac operator, leaving only the index in the supertrace; Getzler rescaling computes its local limit from curvature.
Getzler rescaling combines the change in geodesic normal coordinates with the Clifford algebra filtration, assigning degree one to a derivative and to a Clifford generator and degree minus one to a coordinate. The associated graded Clifford algebra is the exterior algebra. This is useful because the spinor supertrace annihilates every Clifford monomial except the top-degree one. Applied to the Lichnerowicz formula for a twisted Dirac operator, it retains a quadratic curvature model, whose heat kernel is computed by a Gaussian ansatz; all terms of smaller rescaling degree disappear from the local index limit. Thus the cancellations in a supersymmetric heat trace can be computed before solving the complete curved heat equation.
On a spin manifold, tensor the spinor bundle with a Hermitian vector bundle carrying a unitary connection. Composing the induced tensor-product connection on a vector bundle with Clifford multiplication defines the twisted Dirac operator. In even dimension it maps to and conversely. On a closed manifold its chiral restriction is a Fredholm operator.
At the centre of geodesic normal coordinates, expand the square of the Twisted Dirac operator. The diagonal terms give the rough Laplacian; the off-diagonal terms are . The tensor-product vector-bundle curvature is the sum of spin curvature and . Substituting spin curvature and using the Clifford algebra relations yields the scalar term : the four-generator contribution vanishes by the algebraic Bianchi identity and the contracted terms are the scalar curvature. This proves the displayed identity at every point.
An equivariant index theorem expresses the supertrace of a symmetry on the kernel and cokernel of an elliptic operator as an integral of local characteristic data over the symmetry's fixed-point set.
An immersion into a Riemannian manifold inherits the Riemannian metric : measure two tangent vectors after mapping them into the surrounding tangent space. This is a pullback of a Riemannian metric, withThe injective derivative of an immersion makes this inner product positive-definite. For a parametrized surface in Euclidean space, its coefficients are simply the scalar products of the coordinate tangent vectors: the first fundamental form.
For the circular cylinder , the tangent vectors and are orthogonal, with squared norms and . ConsequentlyThe unrolled coordinate gives . This calculation explains intrinsic flatness of a circular cylinder and makes Riemannian distance on a circular cylinder a planar problem with repeated endpoint lifts.
Preserving a Riemannian metric locally preserves the arc length of every mapped curve, but it need not preserve distances measured by unrestricted paths in the surrounding space. The great-circle distance between two sphere points, for example, exceeds their straight chord length unless they coincide. [ref]
https://www.math.ucla.edu/~petersen/RG.pdf. Peter Petersen, Riemannian Geometry, §1.1: induced metrics and Riemannian immersions
.A Riemannian surface is a two-dimensional smooth manifold equipped with a smoothly varying inner product on each tangent plane.
A surface metric has a cone singularity of total angle if a punctured neighbourhood has the metric obtained by joining the radial boundaries of a sector of angle . For constant Gaussian curvature away from the vertex, its polar expression is , where has period . A circle of small radius has length asymptotic to . A smooth Riemannian surface instead has circumference asymptotic to , so the metric extends smoothly at the vertex exactly when .
The arc length of a piecewise smooth curve on a Riemannian manifold is the integral of its speed:An odometer measures this accumulated travel rather than displacement between the endpoints. In Euclidean space, the Riemannian metric is the ordinary inner product, so the formula becomes .
For a circle of radius traversed through an angle , use , . Its speed is , hence its arc length is . Traversing a full circle twice gives , even though the starting and ending points coincide. The same formula measures the two great circle arcs pictured in geodesic.
The curve parameter controls how fast the journey happens, not its arc length. A regular increasing or decreasing reparametrization preserves the integral by change of variables; reversing direction leaves the speed norm unchanged. Retracing part of a route does add length, because it changes the actual journey.
For a piecewise differentiable curve given in polar coordinates by , differentiate and . The cross terms cancel in , leaving . Therefore the arc length on an increasing parameter interval isThis formula remains valid through an isolated zero of the speed when the parametrization is piecewise smooth. A square root of a square must retain its absolute value.
The length of a piecewise smooth curve is its arc length: , using either the Euclidean space norm or the norm from a specified Riemannian metric. A straight segment from to in Euclidean space has length , while a route that bends or retraces can be longer. On a Riemannian manifold, comparing these lengths over all routes defines Riemannian distance.
The distance on a connected Riemannian manifold is the infimum of the arc lengths of piecewise smooth curves joining the endpoints:It answers “how far must I travel while staying in this geometry?” The Riemannian metric measures an instantaneous tangent vector, whereas Riemannian distance is the global result of comparing complete routes.
In Euclidean space the straight segment achieves this infimum, giving . On a round sphere it gives great-circle distance, for positions with unit vectors . For and a central angle , the surface distance is , while the chord length is . On a circular cylinder, routes with different winding lead to the minimum in Riemannian distance on a circular cylinder.
The word infimum matters: a shortest route need not exist. In the Euclidean plane with the origin removed, the points and still have Riemannian distance , approached by paths detouring around an arbitrarily small circle. Every allowed route has length strictly greater than , since the only Euclidean straight segment passes through the missing point. The Hopf-Rinow theorem guarantees a minimizing geodesic between any two points when a connected Riemannian manifold is complete.
On the lateral surface of an infinite circular cylinder of radius , the induced metric is . Lifting a curve to the unrolled plane preserves its arc length. If the endpoints differ by angular coordinate and height , the possible lifted endpoint displacements are for integers . Each straight segment gives a geodesic, and the shortest of their lengths isChoose the representative of with smallest absolute value modulo ; if its absolute value is , the two angular directions tie. This minimum is attained because the candidate lengths tend to infinity as . The formula concerns travel on the lateral surface; it does not allow a shortcut through the cylinder's interior or across end caps.
For , take and in surrounding Euclidean space. The angular difference is and height difference is . The route has length . The route goes the other way around and has length . Both are among the geodesics on a circular cylinder, but only the first is a minimizing geodesic between these endpoints.
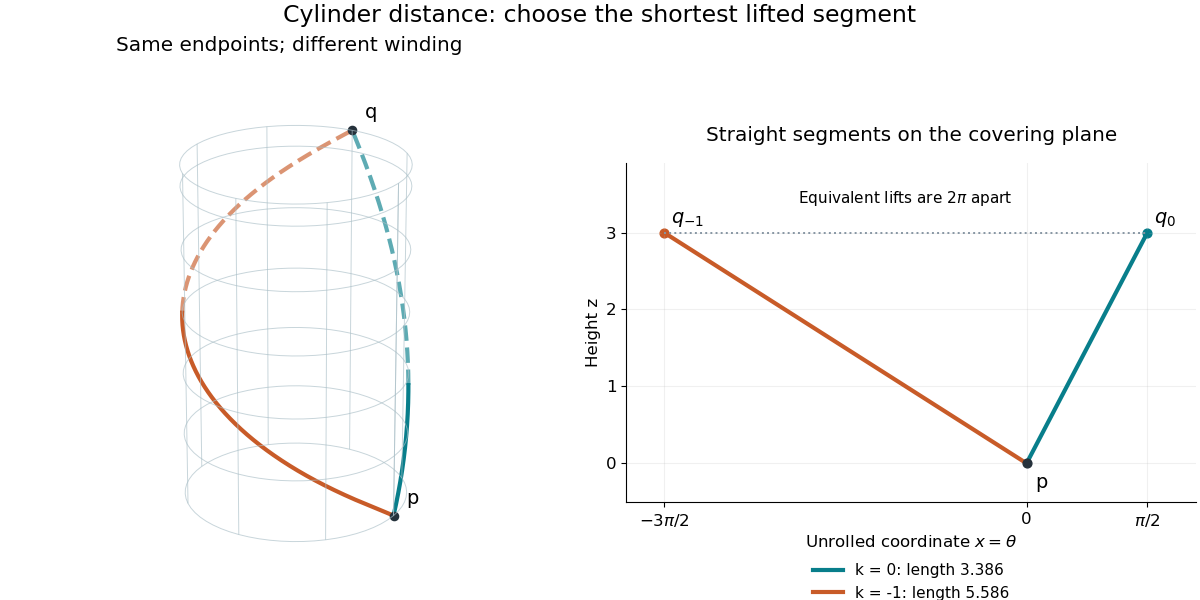
This is a global consequence of intrinsic flatness of a circular cylinder: locally everything is Euclidean, yet the periodic angular coordinate leaves several competing routes. A shortest-route problem on the curved surface becomes a family of ordinary planar distance calculations.
In a relatively compact coordinate ball the Riemannian metric norm is bounded above and below by positive multiples of the Euclidean norm. A coordinate segment gives the upper distance bound. A path leaving the ball has a positive lower length bound before its first exit; paths staying in it have the Euclidean displacement lower bound. Consequently distinct points have positive Riemannian distance, and the resulting metric topology equals the manifold topology. Connectedness makes the distance finite because smooth manifolds are locally path connected.
In a connected Riemannian manifold, choose a small compact geodesic sphere around with . Minimize on this sphere. Every path from to crosses it, so an almost-minimizing path has length at least . The triangle inequality gives the reverse bound, yielding the displayed equality. No global completeness is needed.
A minimizing geodesic realizes the Riemannian distance between its endpoints. A geodesic segment is locally minimizing, but need not remain globally minimizing beyond a cut point.
At an interior junction of two unit-speed geodesic segments, let be the incoming and the outgoing tangent. Choose points close to the junction in a common convex normal neighbourhood. Moving the junction with velocity changes the sum of the two segment lengths by , using the first variation of geodesic energy or the Gauss lemma. If , choose to reduce length. Hence a length-minimizing broken geodesic has matching tangents and is one smooth geodesic.
// Target: riemannian-geometry.bigb
On a complete connected Riemannian manifold, let for a unit tangent vector be the supremum of times for which minimizes Riemannian distance from . The cut locus consists of the endpoints with . Radial minimization fails beyond this first cut time; distance spheres can cease to be smooth there.
For a unit-speed geodesic , a finite cut time is the last time to which its segment from minimizes Riemannian distance. Its endpoint is the Riemannian cut point along that geodesic. It lies in the cut locus; it need not be a cut point in the topological sense. The segment up to the cut time still minimizes by continuity of distance.
In unit-curvature Real projective space of dimension at least two, Riemannian distance is for unit lifts. A unit-speed geodesic has lift , with unit and perpendicular to , and therefore ceases to minimize after . Its normal Jacobi fields with zero initial value are times parallel vector fields along a curve, giving first conjugate point at time . The two times differ in every direction.
A Riemannian cut point along a geodesic in a complete Riemannian manifold is either its first conjugate point or the endpoint of another minimizing geodesic from the initial point. To prove this, approach the cut time from above and choose minimizing geodesics to the later endpoints using the Hopf-Rinow theorem. A subsequence of their initial unit vectors converges. If its limit is the original initial vector and the cut endpoint is not conjugate, the inverse function theorem for the Riemannian exponential map identifies the two geodesics locally and contradicts the shorter length of the chosen minimizers. A conjugate point earlier than the cut time is excluded by the negative Riemannian index form direction obtained by extending an endpoint-vanishing Jacobi field by zero and perturbing its endpoint corner.
For Riemannian manifolds and , the product metric on is . Its Levi-Civita connection and curvature split by factors, so its Ricci and scalar curvatures are the corresponding sums.
For closed manifolds with the product Riemannian metric, the positive Laplace-Beltrami operator is the sum of the two factor operators. Products of their orthonormal eigenbases form a complete basis, and eigenvalues add. Hence the product eigenspace at is the displayed finite orthogonal sum of tensor products. The discrete assertion requires a discrete spectral setting.
Two isospectral manifolds remain isospectral after taking a Riemannian product with the same closed factor: eigenvalues add, with multiplicities given by the product Laplacian eigenspace decomposition. For nonisometric closed connected factors , choose . Every closed product geodesic of length less than has constant projection to , since a nonconstant closed geodesic shorter than the injectivity radius is impossible. The short coordinate geodesics of the small flat torus span exactly its tangent factor at every point. Any product Riemannian isometry must preserve that intrinsically defined smooth distribution and its orthogonal complement, hence restrict to an isometry of the original factors. Thus these products are still nonisometric. Taking to be four-dimensional tori proves the higher-dimensional stabilization statement without assuming a cancellation theorem for arbitrary products.
An isometry between metric spaces preserves every distance. A Riemannian isometry preserves the Riemannian metric and therefore distances, angles, geodesics, and intrinsic curvature.
A transformation preserving a spacetime metric tensor. For Minkowski spacetime, the affine transformations with this property form the Poincaré group. A spacetime isometry is a symmetry of particular dynamical equations only if their other fixed structures and couplings are preserved as well.
The isometry group of a metric space consists of its bijective isometries, with composition as the group operation. For a Riemannian metric, these are the diffeomorphisms preserving the metric tensor. Right translations of a right-invariant Riemannian metric supply a faithful subgroup isomorphic to the underlying Lie group.
A finite group of orientation-preserving isometries of the Euclidean plane or hyperbolic plane is a cyclic group. Take one orbit and its unique minimum-radius enclosing disc. Every group element preserves the orbit and therefore the disc's centre. The orientation-preserving stabilizer of a point acts as planar rotations, so the group embeds in the circle group. In a nontrivial finite subgroup, the least positive rotation angle generates all angles by division with remainder, proving cyclicity. Orientation reversal changes the conclusion: reflection groups need not be cyclic.
For a connected three-dimensional Riemannian manifold, the Myers-Steenrod theorem bounds the dimension of its isometry group by six. Dimension five cannot occur: isotropy embeds in , whose Lie subalgebras have dimensions zero, one or three. A five-dimensional action would require three-dimensional isotropy and a two-dimensional orbit; full rotational isotropy has no invariant tangent two-plane. The maximal dimension six forces transitivity and isotropy, hence constant sectional curvature. Each of the six listed dimensions is attained by a suitable metric.
For a complete simply connected Riemannian manifold and a free properly discontinuous deck group , each isometry of lifts to an isometry of normalizing . Conversely such a normalizing isometry descends; two lifts differ by a deck transformation. This proves the formula, including orientation-reversing isometries if the full normalizer is used.
Articles were limited to the first 100 out of 225 total.
Articles by others on the same topic


Riemannian geometry is a branch of differential geometry that studies smooth manifolds equipped with a Riemannian metric. This metric allows for the measurement of geometric properties such as distances, angles, areas, and volumes within the manifold. ### Key Concepts: 1. **Manifolds**: A manifold is a topological space that locally resembles Euclidean space. Riemannian geometry focuses on differentiable manifolds, which have a smooth structure.