The released examiner commentary gives performance observations rather than complete worked solutions. Questions 6 and 7 contain several unlettered tasks.[ref]
https://www.whatdotheyknow.com/request/natural_science_tripos_physics_e/response/2127325/attach/3/FOI%202022%20639%20Sullivan%20materials.pdf?cookie_passthrough=1#page=50. Examiner commentary for the 2021 IA Physics paper, released PDF pages 50–52
For a simple pendulum in the small-angle approximation, the oscillation period is , soInterpret the quoted random timing error and length error as standard uncertainties, with independent errors and no additional systematic error. For independent measurements, the standard error of the sample mean of the period is . The length has relative standard uncertainty . By propagation of uncertainty,Requiring a relative standard uncertainty no greater than givesFor , the combined relative standard uncertainty is , or ; gives and just fails. Repeating the timing does not reduce the fixed length measurement uncertainty. The stated “accuracy” is consequently a statistical uncertainty target, not a guarantee for every experimental outcome. This is an example of repeated-timing uncertainty in a pendulum gravity measurement.
The original diagram shows two equal balls, each of mass , attached to the fixed upper pivot and light sliding collar by four equal rods. Each ball describes a horizontal circle of radius . The pivot-to-collar distance is , so the upward collar displacement compresses the spring byThus Hooke's law gives a downward spring force on the collar. Let be the tensions in the upper and lower rods attached to one ball. Vertical force balance on the light collar and then on either ball givesThe radial force on one ball supplies its centripetal acceleration:For , adding the vertical-balance results and eliminating the rod tensions givesFor the given centrifugal governor, andHenceThe factor of two in the collar balance matters: both lower rods support the same light collar. The spring force is not an extra downward force of this full magnitude on each ball; its effect on each ball is transmitted through its own lower rod. The formula is the steady spring-loaded centrifugal governor balance.
Let the cylinder length be , cross-sectional area , and the fluid mass density . At floating equilibrium, Archimedes' principle givesFor a small downward displacement from this equilibrium, the displaced fluid volume increases by . The additional upward buoyant force is , and Newton's second law becomesThis is simple harmonic motion, with angular frequency and oscillation periodThe result for vertical oscillations of a floating cylinder is independent of its cross-sectional area and fluid mass density because those quantities cancel using the known immersion fraction. It neglects drag, surface effects and the extra fluid inertia from the motion; the cylinder must remain partly immersed throughout the small motion.
For a diffraction grating with illuminated lines in order , its ideal spectral resolving power isThe two spectral lines have separation and mean wavelength . In first order, , so the Rayleigh criterion requiresWith line density , the ideal continuous estimate for the illuminated width isRounding the required number of illuminated grating lines upward gives lines, conventionally an illuminated width . Using the longer wavelength rather than the mean also gives the same integer requirement. This is the ideal limit set by the resolving power of a diffraction grating; additional broadening from the illumination or observing apparatus could require a larger width.
The tunnel is taken thin enough that removal of its material does not significantly disturb spherical symmetry. For , the enclosed mass isBy the spherical shell theorem, the inward gravitational acceleration has magnitudeThe released gravitational potential energy is the positive work done by gravity while the mass falls from radius to :By conservation of mechanical energy,Inside the cavity, the spherical shell theorem gives zero gravitational field, so the velocity stays constant. The original figure places B and C at opposite ends of a cavity diameter, a distance apart. ThereforeThe quantity has units , so this is a time. There are no numerical values for or in the paper. The transit time is independent of and the falling mass . The cavity's gravitational potential is constant, not necessarily zero; only its gradient vanishes. The calculation is a hollow-sphere gravitational transit.
Translation and rotation. For particles constituting a rigid body, the total linear momentum isThus the total external force governs the motion of the centre of mass. About that centre of mass, the angular momentum and applied torque arewhere primes denote relative positions and velocities. The derivative of the vector is taken relative to nonrotating axes. The inertia tensor relates angular momentum to angular velocity, . For rotation about a fixed unit direction , the moment of inertia is ; it measures the resistance to changing that rotation and gives rotational kinetic energy . The simpler vector relation applies when the rotation axis is a principal axis, not for every orientation of an arbitrary rigid body. These translational and rotational balances must be applied together; a nonzero torque does not replace the net-force equation.
Gyroscope precession. A rapidly spinning gyroscope has a large angular momentum approximately along its spin axis. The torque component parallel to this vector changes its magnitude, while the perpendicular component turns its direction. If the vector undergoes precession with angular velocity , then over its change is the infinitesimal rotation . HenceThis describes direction-changing precession at constant ; any spin-up contribution must be added separately. For perpendicular torque and angular momentum, the precessional component perpendicular to is . The familiar tendency of a supported gyroscope to turn sideways is this vector balance, not the absence of gravitational force.
Wheel-lift threshold without the flywheel. Let be the centre of mass height, half the wheel separation, and the bend radius. The required inward force is , provided by static friction. Let be the summed outer and inner wheel normal forces. Vertical balance gives . Moment balance about the centre of mass givesThe inner wheels lift when . Thus the vehicle rollover threshold isThe stated mass cancels. This assumes the rigid geometry and sufficient static friction specified in the paper; the threshold is set by loss of contact, not by sliding.
Engine flywheel. The moment of inertia of a uniform disc givesIts spin angular speed, spin angular momentum, and turn angular speed at areThe transverse flywheel axis is perpendicular to the vertical turn axis, soTo specify its direction, use right-handed axes forward, to the car's left, and upward, and consider a left turn. Then . Choose the flywheel angular momentum to the car's right, . The car must applyto obtain the required precession. This gyroscopic roll torque in a turning vehicle opposes the outward roll tendency in a left turn. By the right-hand rule, the flywheel must turn counterclockwise viewed from the car's right side toward its centre, opposite to the rotation of wheels rolling forward. Reversing flywheel spin would aggravate the outward roll. Reversing the turn reverses both roll and gyroscopic torques, so the same flywheel spin remains helpful.
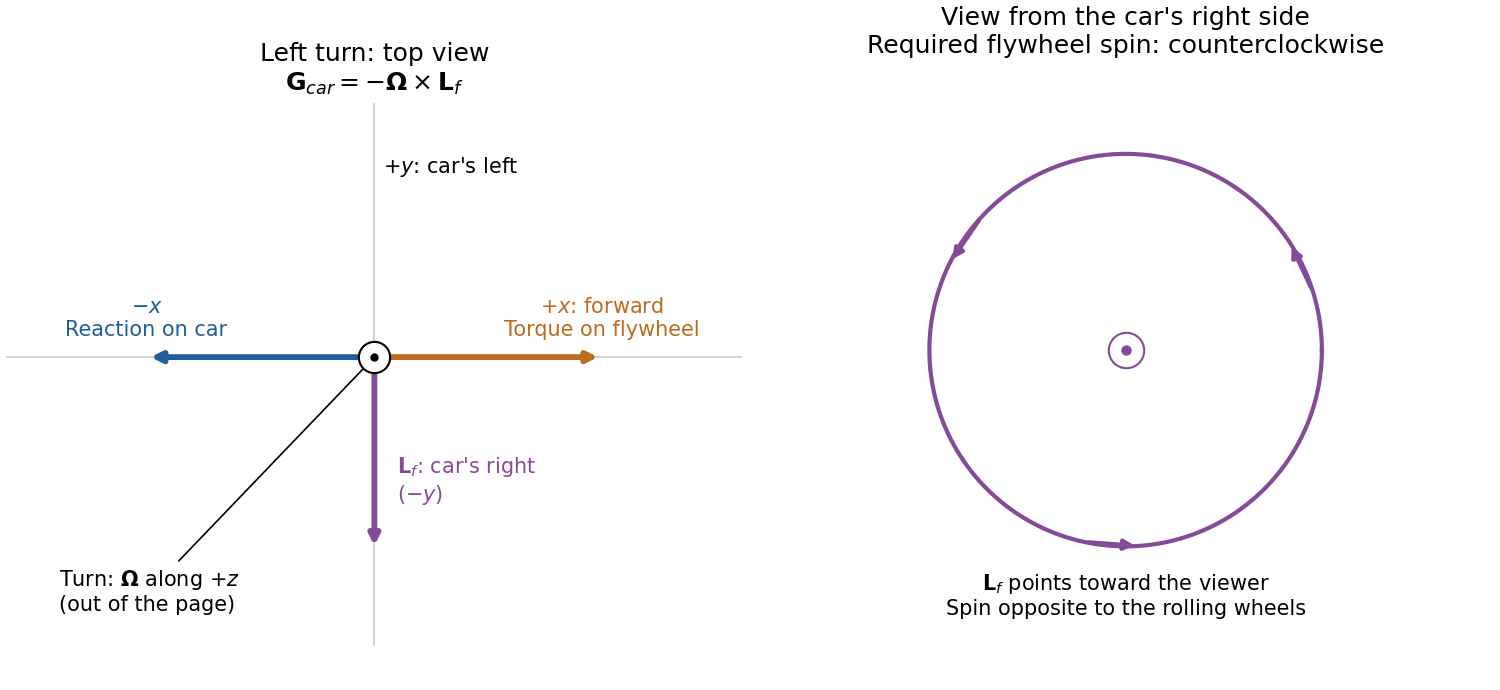
Gyroscope vector directions for a left-turning car and the flywheel spin needed to oppose outward roll
. Details. For comparison, the outward inertial roll moment at the stated speed is , and the limiting gravitational restoring moment is . The gyroscopic reaction is about of the former and of the latter, so it is appreciable for this large flywheel. If this ideal model is extended to include the favorable gyroscopic reaction in the wheel-lift condition, it gives , or about rather than . This quantifies a useful but finite increase in the rollover threshold.
Frame definitions and relativistic effects. Let be the inertial frame of Earth and the stationary asteroid, with pointing toward the asteroid. Bob's inertial frame moves at relative to . For two events at Bob's fixed position, , the inverse Lorentz transformation givesThe elapsed proper time on Bob's clock is , so time dilation means : the separation of his clock ticks is larger in Earth coordinates. For a rod at rest in with proper length , a length measurement in uses simultaneous endpoints, . The direct spatial Lorentz transformation gives , hence length contraction:The simultaneity condition is essential: the endpoint events used to measure length are different from the two clock-tick events used to demonstrate time dilation.
Bob's speed. Food consumption measures Bob's own proper time, . The Earth-frame distance is and the Earth travel time is . ConsequentlyPutting , , soThe Earth travel time is months. Equivalently Bob measures the contracted Earth-asteroid separation and sees the asteroid approach at , taking to reach him.
Events A and B. Set both coordinate origins at Event A. Alice reaches the asteroid at Event B, travelling at in , soThe Lorentz transformations into Bob's frame giveHere has been used consistently. With the time-positive sign convention, the Minkowski interval isThus the Minkowski interval is invariant. It is timelike, as expected for two events on Alice's subluminal worldline. Using the opposite metric sign convention would change both signs together, without changing invariance.
Relative velocity and spacetime diagram. Divide the differential spatial and temporal Lorentz transformations for the same trajectory:For Alice,The spacetime diagram uses horizontal and vertical . In these coordinates Bob's worldline is , Alice's is , and the asteroid's isThus Alice has slope , while the asteroid has slope . Their intersection is exactly B, . The asteroid later reaches Bob at . These intercepts and gradients show the relativistic velocity addition geometrically.
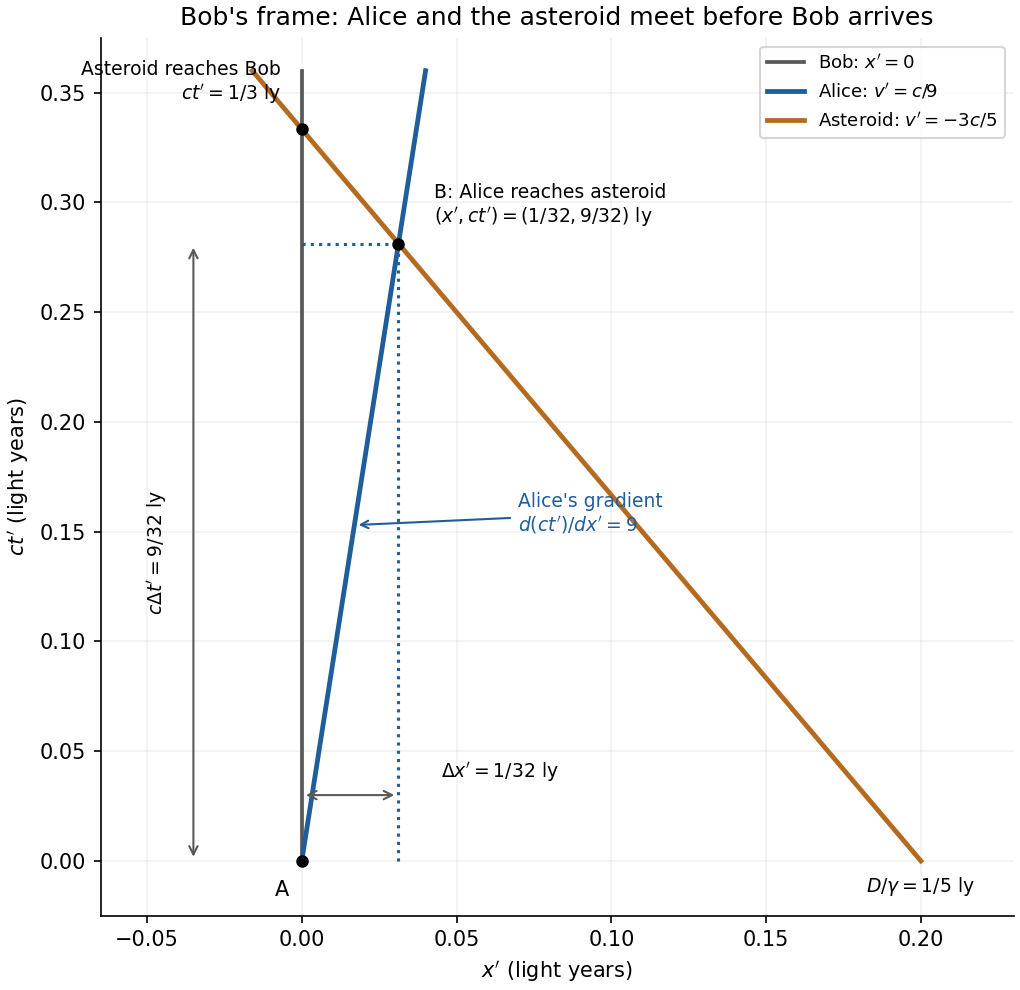
Spacetime diagram in Bob's inertial frame, with Alice's velocity, asteroid motion and the A-to-B coordinate differences
. Details. The force law separates into two identical harmonic oscillator equations:For positive , the general real solution isSince by Euler's formula, these are exactly the stated real parts of complex exponentials. The amplitudes and phases are fixed by the four initial position and velocity components. This is two-dimensional isotropic harmonic oscillator flow: the same angular frequency acts in every direction.
Put . If both coordinate amplitudes are nonzero, eliminate the common phase to obtainFor , this is an ellipse centred at the origin. The following special cases exhaust the possible nontrivial shapes:
- or gives straight-line simple harmonic motion, including an axis-aligned line if one coordinate amplitude vanishes.
- gives an axis-aligned ellipse; if additionally , it is a circle traversed in one of the two orientations.
- Other phase differences give tilted ellipses.
The degenerate zero-amplitude solution is the stationary origin. There are no general multi-loop patterns here because the two angular frequencies are equal. Another useful description is , the image of a circle under a linear map.
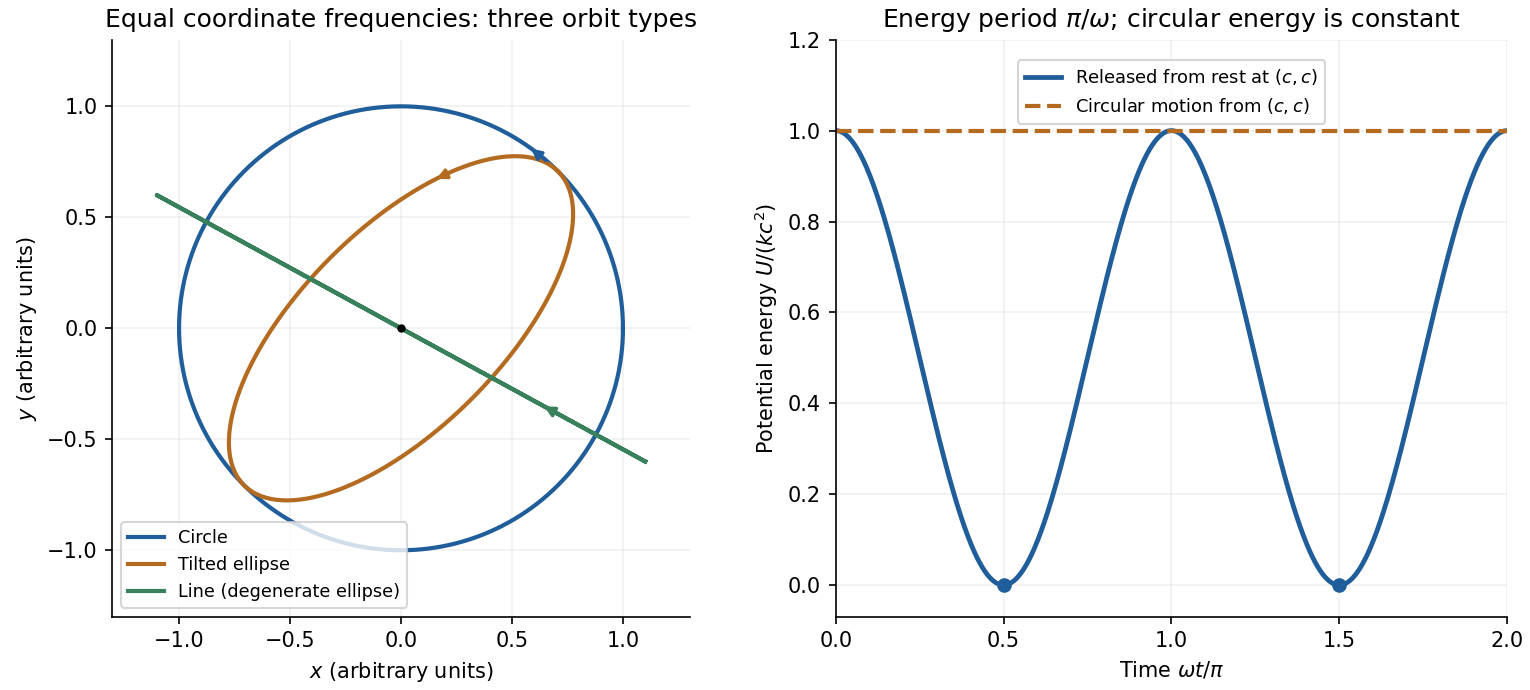
Undamped planar harmonic oscillator trajectories and potential energy for the two specified initial conditions
. Details. The force is conservative, with and potential energy zero at the origin:Released from rest at , the trajectory has , givingThe right panel of the figure shows this nonnegative oscillation: it starts at a maximum , reaches zero at , and repeats after . Its frequency is twice the coordinate frequency. Conservation of mechanical energy gives , so the missing potential energy is kinetic energy, not an energy loss.
The starting radius is . In uniform circular motion, the required centripetal acceleration has magnitude . The initial velocity must be tangent to the starting radius, with the orientation chosen anticlockwise:The resulting trajectory isIt has constant , soThis is the horizontal line in the right panel of the figure. The kinetic energy also equals , giving total mechanical energy , twice that for release from rest at the same point.
Write and , where is the undamped angular frequency. The linear drag gives the vector damped harmonic oscillator equationFor the original circular initial conditions, and , the exact underdamped solution isUsing , and givesThis exact potential energy is useful because it satisfies the prescribed initial conditions, including . In the stated weak-damping limit , and the square bracket differs from one by a small oscillatory term. The leading approximation is thereforeThe radius is approximately , so the trajectory is approximately a shrinking logarithmic spiral. The exactly exponential result would require slightly adjusted initial velocity; with the specified undamped circular velocity, the small modulation above is real. This is the initially circular damped planar oscillator.
The parameters giveThe coordinate expressions for the initially circular damped planar oscillator areThe damped oscillation period gives almost four anticlockwise turns in four seconds. The radius envelope falls by . Substitution into the exact coordinates givesThe left panel annotates the initial tangent, time marks and endpoint. Because is an unspecified starting coordinate, the axes are normalized by rather than assigned numerical lengths.
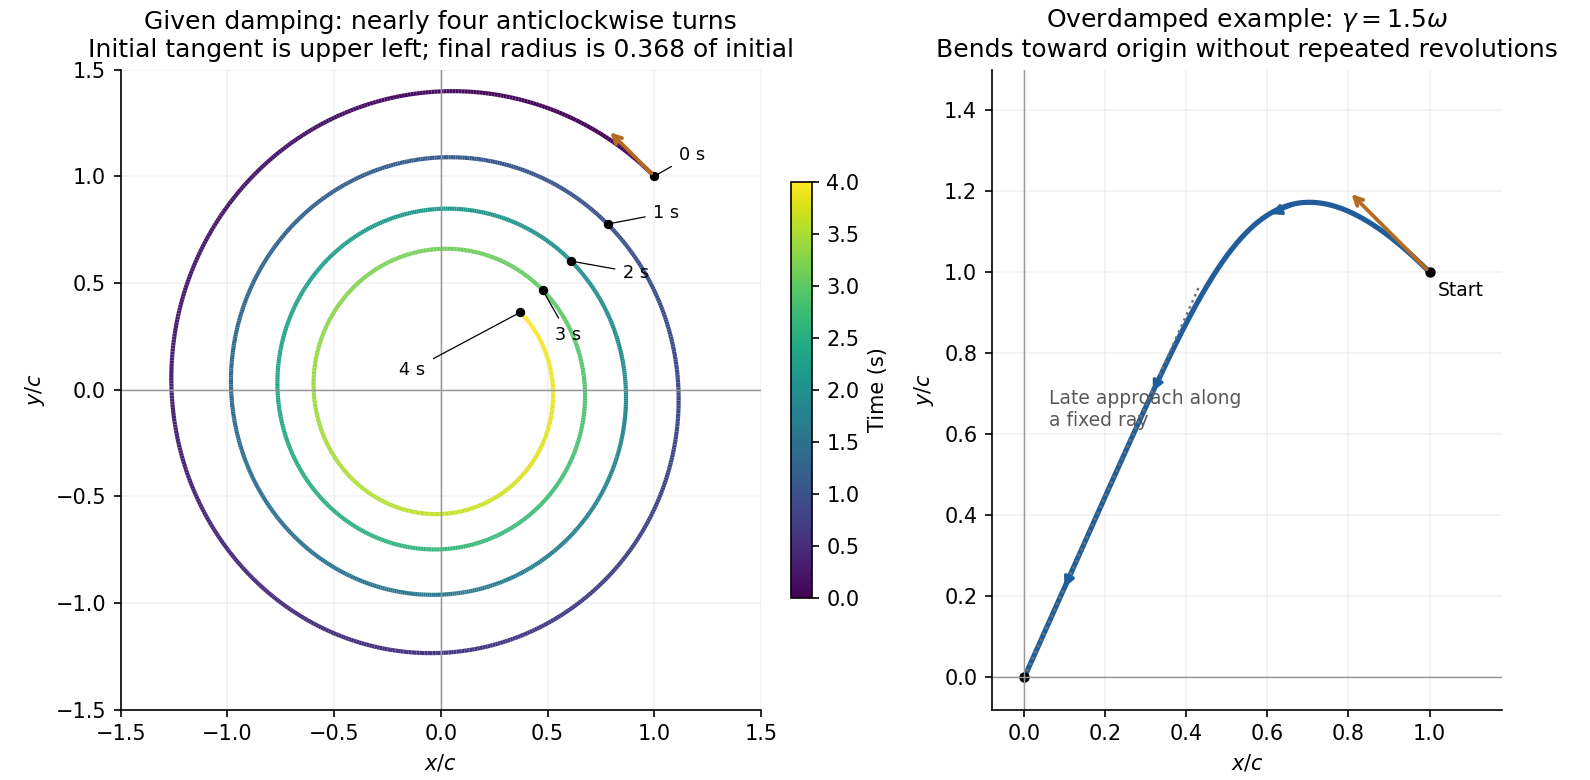
Exact underdamped trajectory over four seconds and a representative overdamped trajectory for the same initial circular velocity
. Details. For overdamping, . Put . Both characteristic roots are negative real numbers. Replacing trigonometric functions by hyperbolic functions gives the exact trajectoryIt starts from with tangent , bends anticlockwise toward the origin, and approaches it without repeated revolutions. The right panel gives a representative choice ; the paper does not specify one particular value of in this regime.
One can make the qualitative shape precise. In radial and tangential directions relative to the initial radius, the angle turned from the starting direction obeysFor , both coordinates stay positive, and the approach is along the fixed ray with . The initial velocity is tangential, so an immediately straight radial return would be incorrect. The absence of oscillatory characteristic roots prevents repeated revolutions. This is a non-spiralling overdamped central oscillator trajectory.
Use the original diagram's positive distances: from the object to the vertex, from the vertex to the image, and from the vertex toward the centre of curvature on the outgoing side. Let a paraxial light ray strike at height . Its incoming inclination is above the optical axis, its outgoing inclination is below it, and the inward surface normal is inclined by below it. Thus the incidence and refraction angles relative to that normal are respectively and .
The local tangent-plane form of Snell's law, using the small-angle approximation, givesSubstitute the three height-to-distance ratios and cancel :This refraction at a spherical surface result keeps only first-order ray angles. The surface sag shifts the height's axial reference only at higher order. Distances for other object, image or curvature orientations must be signed consistently; the displayed positive-distance form follows the particular orientation in the paper.
Keep the paper's as magnitudes for the two convex faces. With the standard signed-curvature convention measured to the right, the first surface has signed radius and the second . This explains why the requested formula contains a sum of the two reciprocal magnitudes.
Let the axial lens thickness be , and let be the distance from the first vertex to the intermediate focus that its refracted rays would reach without the second surface. The first refraction at a spherical surface givesAt the second face those rays are still converging toward that intermediate focus, so its object distance is negative, , with . Applying the signed spherical-surface equation again givesIn the thin lens limit, . Adding cancels the intermediate-focus terms:The focal length is the image distance for parallel incident light rays, , hence the lensmaker's equation isThe same surrounding refractive index is assumed on both sides. For this biconvex thin lens has positive focal length. With signed radii , , the equivalent familiar expression is .
Use positive object distance and focal length . The thin lens equation givesThe transverse magnification is , so the signed height isThe real image lies beyond the lens, is inverted, and has positive height magnitude .
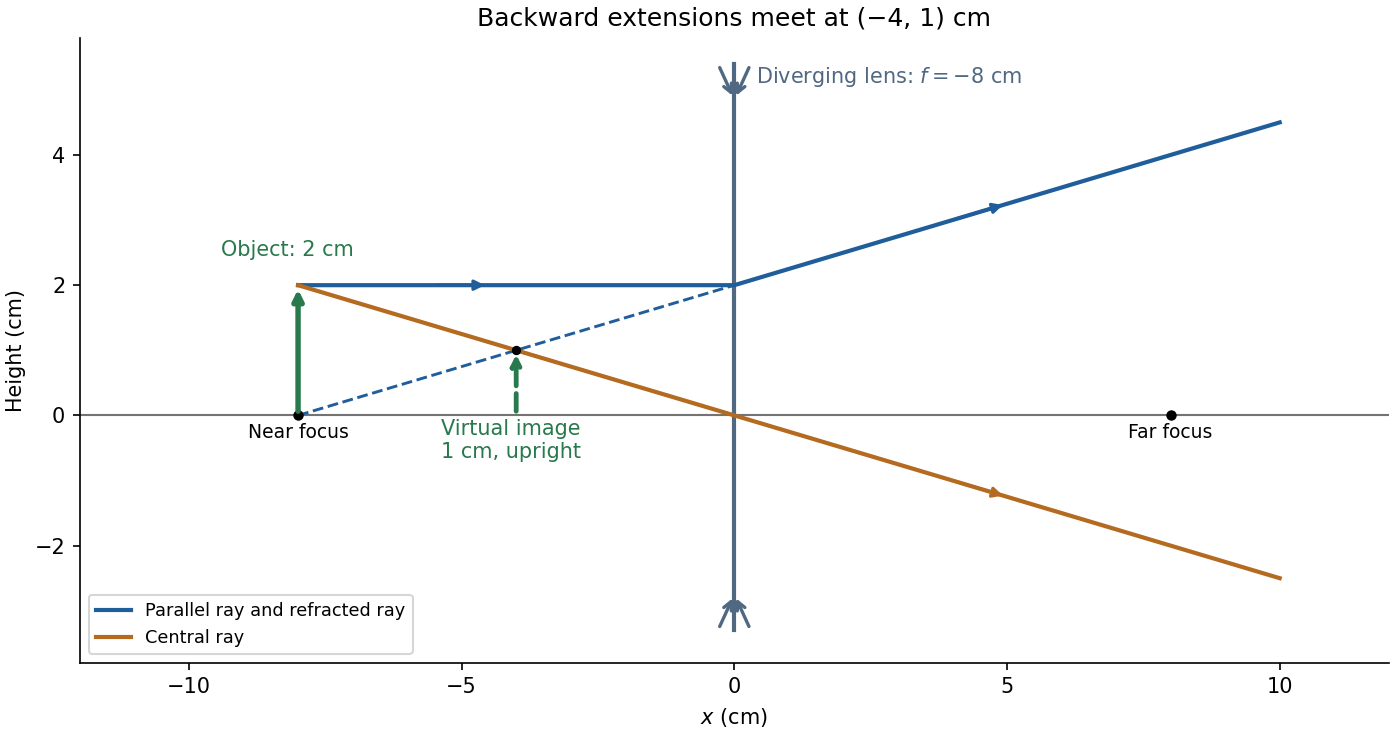
For and negative focal length ,The transverse magnification is , soThus the virtual image is upright, half the object's height, and from the lens on the object's side. A parallel incident light ray diverges after the lens as though it originated at the near optical focus; the central light ray continues undeviated in the ideal thin lens model. Their backward extensions meet at the image tip, .


For steady electric currents in vacuum, Ampère's circuital law isChoose an oriented closed contour and a spanning surface; the positive enclosed electric current crosses that surface according to the right-hand rule for the contour. First use the source symmetry to establish the direction of and which positions have the same magnitude. Then choose the contour so its useful segments are parallel to with constant magnitude, and the remaining segments are perpendicular to or have vanishing field contribution. The line integral reduces to the unknown magnitude times a known length or sum of lengths.
For example, cylindrical symmetry around an infinite wire allows a circular contour, giving . A uniform current sheet instead calls for a rectangle straddling it. The law is always valid in this magnetostatic setting, but by itself does not determine the local magnetic field from an arbitrary enclosed current without these extra symmetry arguments. Here is the vacuum permeability.
Choose along the electric current, upward normal to the sheet, and to complete a right-handed frame. In the interior region far from its edges, treat the sheet as infinite in its plane. Its surface current density isReflection and translational symmetry make the magnetic field parallel to the sheet, perpendicular to its current, and equal in magnitude with opposite direction above and below. Choose an Ampère's circuital law rectangle with length along , straddling the full thickness. The two long sides each contribute with the same sign; on the vertical sides since is horizontal. The enclosed electric current is . ThusThe right-hand rule fixes the directions:The current density inside the finite-thickness conductor is , so integrating through thickness gives the same . These are exterior fields in the broad-sheet approximation, not exact finite-width edge fields.
Keep along the upper-sheet current and upward, putting the lower sheet at and upper sheet at . Between them, the upper sheet's lower-side magnetic field is . The lower sheet carries current in , so its upper-side magnetic field is also . The superposition principle therefore givesEach perfect conductor is an equipotential. The circuit's resistor carries current from upper to lower, so Ohm's law fixes their electric potential difference:The broad parallel faces and their constant potentials make the electric field perpendicular to them and independent of the coordinates along them, away from edges. There is no volume electric charge in the gap. Apply Gauss's law to a small pillbox wholly within the gap, with equal face areas at heights . Its side flux is zero, soThus is independent of height as well. Since ,It points from the higher-potential upper sheet to the lower sheet. Gauss's law requires the planar symmetry argument: zero enclosed charge alone would not prove a uniform electric field in a general geometry. These combined fields characterize parallel current sheets with a resistive termination.
For injected velocity , the Lorentz force isFor nonzero electric charge and nonzero operating current, the velocity selector condition isThe requested nonrelativistic kinetic energy is consequentlyBoth electric current and electric charge cancel. Reversing the sign of reverses both component forces and preserves their cancellation. The dimensions are consistent because has units of speed, while is dimensionless. The assumed nonrelativistic particle regime requires ; the problem supplies no values with which to evaluate a numerical energy.
Articles by others on the same topic
There are currently no matching articles.