The Brouwer fixed-point theorem says that every continuous map has a fixed point when is a nonempty compact set and a convex set in a finite-dimensional vector space over the real numbers. Equivalently, take for a finite , with the usual Euclidean space structure: there is some such that . The conclusion guarantees at least one fixed point, without asserting uniqueness or telling us how quickly to find one. [ref]
https://courses.csail.mit.edu/6.5440/fall23/lectures/L23_images.pdf. MIT lecture slides on Brouwer's theorem
The standard pictures are a closed ball, including a closed unit ball, and a simplex. A filled disk qualifies; its bounding circle alone does not. A probability simplex also qualifies even though its dimension is smaller than that of its ambient Euclidean space. The hypotheses have concrete meanings: being a convex set keeps every line segment between allowed points inside , and compactness prevents escape or loss of a limiting point. In Euclidean space, the Heine-Borel theorem identifies compact sets with closed sets that are bounded sets. Crucially, every output must belong to the same as the input.
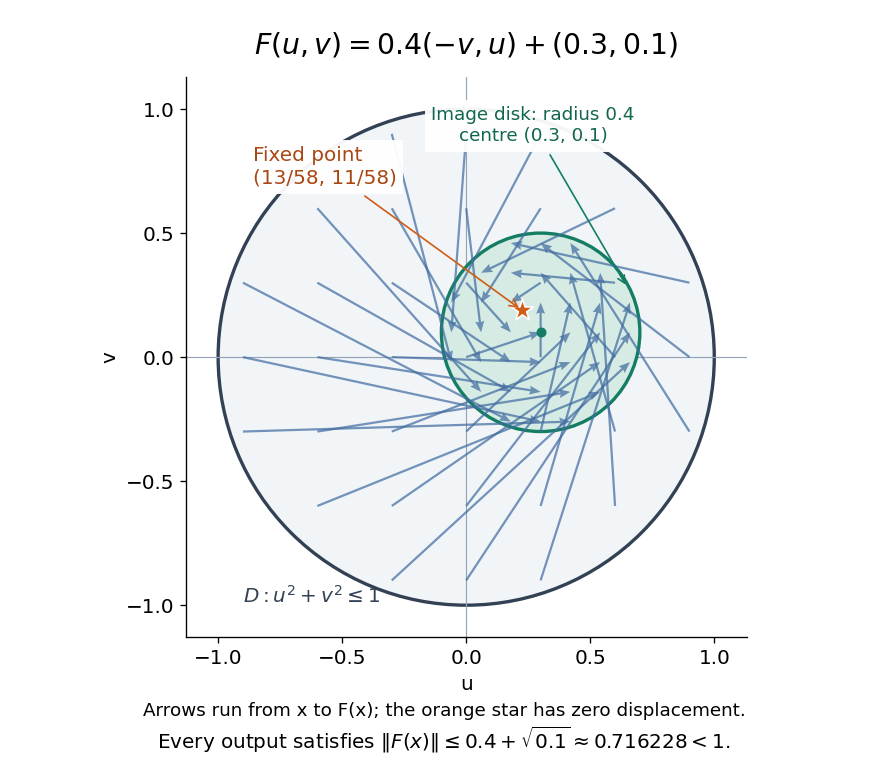
For a fully computable example, let be the filled unit disk. Apply a counterclockwise quarter-turn rotation, shrink by , and add a translation:This affine map is a continuous map. Because the rotation preserves the Euclidean norm, the triangle inequality gives, for every ,Thus the whole image lies strictly inside . More precisely, it is a disk of radius centred at . This containment check is what makes the Brouwer fixed-point theorem applicable; a formula being a continuous map by itself would not suffice.
The fixed point can now be found by a system of linear equations:Indeed, substitution gives . Its Euclidean norm is , safely inside . The figure shows arrows from sample inputs to their outputs; an arrow disappears at the fixed point because the displacement vanishes there.
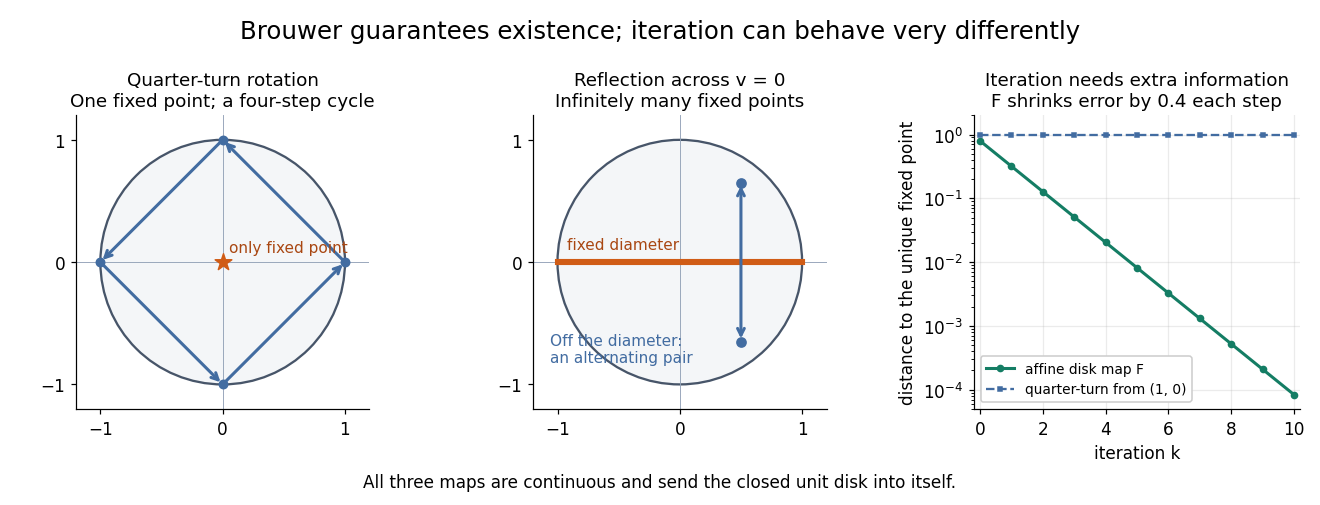
Repeated iterations of a map happen to succeed for this example. Starting at and setting gives , , and . Subtracting the fixed point equation yields , so the Euclidean distance to shrinks by exactly each step. This extra fact follows from the contraction mapping property and the Banach fixed-point theorem. It is additional information beyond the Brouwer fixed-point theorem.
The distinction becomes visible with two simpler continuous maps of the same disk. The pure rotation has exactly one fixed point, , since and force both to vanish. Yet iterations of a map starting at here cycle through , , and forever. Their Euclidean distance from stays one, so there is no convergence in a metric space. The reflection has an entire line segment of fixed points, namely . Starting off that line segment produces an alternating pair. Existence, uniqueness, and convergence of iterations of a map are separate questions.
Removing hypotheses changes the answer. Restrict the same quarter-turn rotation to the circle . It remains a continuous map into that compact set, but its only possible fixed point, , has been removed. The circle is not a convex set. Conversely, on the unbounded convex set , the translation has no fixed point; on the open interval , also has none. Neither domain is a compact set. The finite-dimensional closed ball statement should likewise not be extended to arbitrary infinite-dimensional vector spaces, where a closed ball need not be a compact set.
The one-dimensional version explains the connection to the intermediate value theorem. For a continuous map , put . Then and , so the intermediate value theorem gives for some . In higher dimensions, the Brouwer fixed-point theorem supplies a corresponding existence principle when this scalar sign argument is unavailable. Its practical value is ensuring that a proposed equation has a solution once a suitable domain is found; it supplies no general promise of a fast algorithm.
A useful application is positive matrix eigenvector from simplex normalization: rescale the output of a strictly positive matrix to make its entries sum to one. For example, takeOn this probability simplex, has entry sum , so the normalized continuous map is . Both entries are positive and sum to one, keeping the image inside the probability simplex. Its fixed point equation is , hence . Consequently satisfies : a strictly positive eigenvector with eigenvalue . In larger dimensions, the Brouwer fixed-point theorem guarantees the corresponding positive eigenvector without requiring us to solve a system of linear equations in advance. The fixed point expresses preservation of relative weights, rather than preservation of their unnormalized size.
Proofs can be approached through the no-retraction theorem or Sperner's lemma. In the latter approach, increasingly fine triangulations locate approximate fixed points; compactness supplies a convergent subsequence, and continuous maps turn its limit into an exact fixed point. [ref]
https://www.mit.edu/~6.7980/brouwer.html. Daskalakis and Farina, Brouwer and Sperner
A primary historical reference is L. E. J. Brouwer's 1911 paper Über Abbildung von Mannigfaltigkeiten, whose digitized original is hosted by Zenodo under DOI 10.1007/BF01456812. This gives a direct route to the early literature behind the Brouwer fixed-point theorem. [ref]
https://zenodo.org/records/1428286. Brouwer, Über Abbildung von Mannigfaltigkeiten, 1911
A continuous Euclidean self-map with this growth has a fixed point. Choose and . Then whenever , so the closed radius- ball is invariant and Brouwer applies. Existence does not imply convergence of iterating the original map: on the unit interval has a fixed point but a two-cycle from either endpoint.
A continuous vector field on a closed Euclidean ball whose boundary values have nonnegative outward component has a zero in the ball. Otherwise is a continuous self-map of the ball. Its fixed point, supplied by the Brouwer fixed-point theorem, lies on the boundary and satisfies , a contradiction. The argument turns a zero-finding problem into a fixed point problem without any differentiability assumption.
For a strictly positive real matrix , the map is a continuous self-map of the probability simplex. A Brouwer fixed-point theorem fixed point satisfies with . The image lies in the interior of the simplex, so every entry of this eigenvector is strictly positive. Nonnegative entries and nonzero columns alone do not imply this strict conclusion.
If a continuous map has , then it is onto. For a target , choose , , and map the unit ball to itself by . A fixed point gives .
Let be a finite-dimensional real inner-product space and let be continuous. If on the sphere , then has a zero in the open ball. Otherwise the radial projection of gives a map of the ball that contradicts the Brouwer fixed-point theorem.
If a polynomial equation can be rearranged as with a continuous mapping a closed disk into itself, Brouwer's theorem guarantees a root in that disk.
If each component of a continuous map on a box has opposite weak signs on the corresponding pair of faces, the map has a zero.
Projecting a sign-corrected displacement map back to a square turns Brouwer's fixed point into a zero of the displacement, proving that paths joining opposite side pairs intersect.
Triangulate a triangle and label every vertex by , , or , forbidding label on the side opposite vertex . Then the number of small triangles carrying all three labels is odd, and in particular at least one such triangle exists. Counting edges whose endpoint labels are and proves the parity statement: boundary incidences are odd, while a small triangle has odd incidence exactly when it has all three labels.
No closed disc retracts continuously onto its boundary. This is equivalent to Brouwer fixed-point theorem by the standard ray construction and the antipodal map.
A metric space is a set together with a metric measuring how far apart its elements are. The elements can be positions, functions, or other objects: what matters is that the metric obeys the same basic rules. This lets one discuss convergence in a metric space, continuous maps, and Cauchy sequences without first assigning Cartesian coordinates. The useful abstraction is that many arguments require only comparisons of distances, rather than the particular objects being compared.
Even the same set can support several informative metrics. On the plane with Cartesian coordinates, write and . Three standard choices are Manhattan distance, Euclidean distance, and Chebyshev distance:They come from the L1 norm, Euclidean norm, and maximum norm, respectively, through . For and , Manhattan distance is , Euclidean distance is , and Chebyshev distance is . All three answers are correct for their respective metrics.
The choice encodes the question being asked. Manhattan distance models travel along a rectangular street grid. Euclidean distance measures unrestricted travel along a line segment. Chebyshev distance measures the time needed when two Cartesian coordinates can change simultaneously, each at speed at most one. Thus choosing a metric is part of modelling, rather than a consequence of knowing the endpoints. These examples have the same metric topology, but different metric path lengths and different collections of metric geodesics.
A historical reference for the general study of metric spaces is Maurice Fréchet's 1906 paper Sur quelques points du calcul fonctionnel, published in volume 22 of the Rendiconti del Circolo Matematico di Palermo. [ref]
https://link.springer.com/article/10.1007/BF03018603. Fréchet, Sur quelques points du calcul fonctionnel, 1906
Given a metric space and , define a new metric by and for distinct points. It is the distance obtained by joining every point to a central vertex with its original distance to as edge length. Symmetry and positive definiteness are immediate. With three distinct points the triangle inequality follows from the extra nonnegative term in the route through an intermediate point; repeated-point cases are immediate.
Every is isolated, since . At the centre, however, . Thus a map out of this space is continuous exactly when it is continuous at in the original metric. The closure of is together with if and ; otherwise it is simply . This construction isolates every point except the centre while preserving exactly its original neighbourhood filter.
Let be a nonempty compact metric space and let satisfy whenever . Then has exactly one fixed point. The distance condition implies continuity, and attains a minimum by compactness. If a minimizer were not a fixed point, then would contradict minimality. Two distinct fixed points would contradict the same strict distance inequality directly. A uniform Lipschitz constant below is unnecessary; compactness replaces the quantitative hypothesis of the contraction mapping theorem.
For metric spaces and , the sum metric on is the displayed formula. Nonnegativity, symmetry and the triangle inequality follow by adding the respective inequalities in the two factors, and zero distance forces equality in both coordinates. It induces the finite product topology, as does the maximum product metric, since their distances satisfy . A sequence converges for this metric exactly when both coordinate sequences converge. Two successive extractions of a convergent subsequence therefore show that the product of two sequentially compact spaces is sequentially compact.
The displayed metric on a countable Cartesian product of metric spaces combines the bounded metric transform with summable positive weights. It is finite even when individual factor metrics are unbounded. The triangle inequality follows from subadditivity of and summation. Zero distance forces equality in each coordinate.
Convergence in this metric is exactly coordinatewise convergence. One term is bounded by the sum, so implies each . Conversely, choose a finite head whose omitted weight sum is small; convergence in those finitely many coordinates controls the head uniformly, while boundedness of the transformed distances controls the entire tail. Thus it induces the countable product topology. Arbitrary positive summable weights work by the same proof.
If every factor is a complete metric space, the countable product metric is complete. For a product-Cauchy sequence, the inequality , with , makes each coordinate sequence Cauchy. Its coordinate limits define a product point. Coordinatewise convergence and the uniformly small summable tail imply convergence to that point in . It matters that the original distances are bounded before they are summed: summing arbitrary unbounded metrics directly need not be finite.
Distortion measures how a mapping changes distances or geometric quantities relative to their original values. For an injective map between metric spaces, one multiplicative measure is the product of its Lipschitz constant and the Lipschitz constant of its inverse on the image. Subgroup distortion instead compares intrinsic and ambient word metrics through a growth function.
In a metric space , an open ball of radius about is . A closed ball instead uses . The strict inequality matters: a point at distance exactly belongs to the closed ball and is excluded from the open ball. In particular, is excluded from all three open unit balls above, and included in all three closed unit balls.
The three closed unit balls centred at zero are , , and . Their shapes are a diamond (a rotated square), a disk with a circle as its boundary, and an axis-aligned square. A ball need not look round! The corresponding open balls are the interiors of these shapes. At , Manhattan distance from zero is and Euclidean distance is , whereas Chebyshev distance is : only the square's open unit ball contains this point.
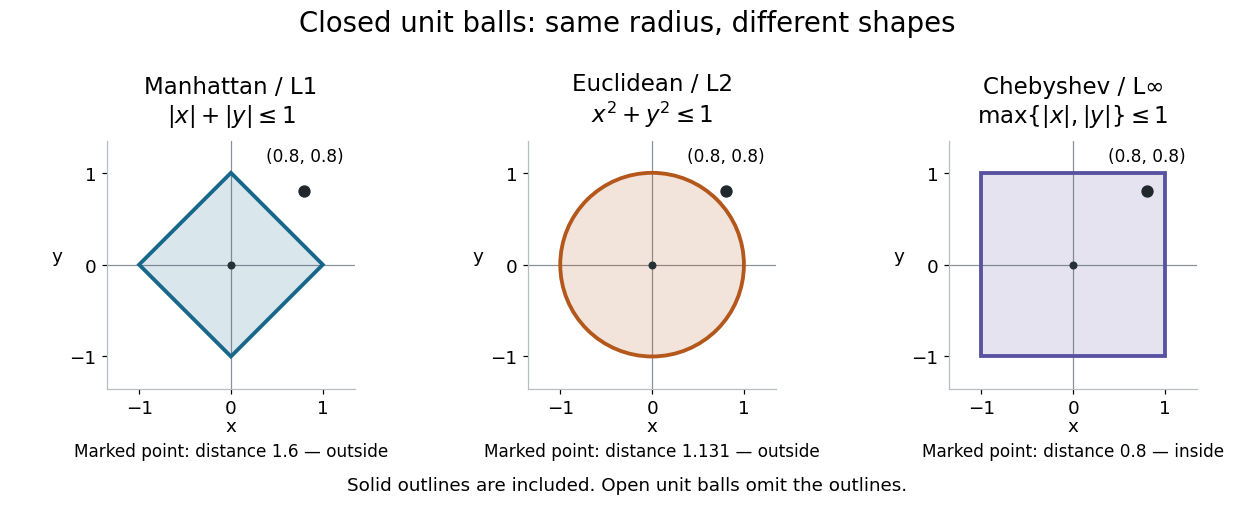
Three closed unit balls on the same coordinate scale
. Details. These shapes illustrate , with either the open ball or closed ball convention used consistently. Their outlines are included in the displayed closed balls. In an arbitrary metric space, however, points at distance exactly need not form the topological boundary; the discrete metric below shows why this distinction matters.
The displayed metric on a product of two metric spaces satisfies its triangle inequality because for nonnegative coordinates. Its open balls are products of equal-radius balls, so it induces the product topology.
For a metric space with the same metric on both factors, the diagonal is a closed subset of its product. At an off-diagonal point let . A maximum-metric ball of radius misses the diagonal, since a common coordinate would give . Equality of underlying sets without equality or compatibility of the metrics is a different assertion.
An epsilon-net in a metric space is a set within distance of every point. A maximal -separated set is an epsilon-net: any uncovered point could be added. On the unit sphere of , disjoint Euclidean balls of radius around separated points lie in the ball of radius . Comparing Lebesgue measures gives a net of cardinality at most .
The supremum of pointwise distances defines a metric on maps when it is finite, for example if the target metric space is bounded. Convergence in this metric is uniform convergence. If the target is complete, Cauchy sequences have pointwise limits and the Cauchy estimate makes convergence uniform.
A Cauchy sequence in the uniform metric has a pointwise limit in the complete target, and the common Cauchy bound makes convergence uniform. The triangle inequality with one fixed continuous approximant shows that the limit is continuous. Thus the space of all continuous maps into a bounded complete metric space is complete, with no compactness assumption on the domain.
A subset is -separated if distinct points have distance at least . Such a subset is a packing by points; small balls around them have disjoint interiors at suitable radius. A large separated set supplies many distinguishable alternatives in statistical lower-bound arguments.
An inclusion-maximal separated set is one to which no further point of the ambient metric space can be added while keeping the same separation. It need not have the largest possible cardinality. In a finite space it can be obtained by repeatedly adding an admissible point.
If an inclusion-maximal separated set has separation at least , every point of the ambient metric space is at distance strictly less than from a selected point. Otherwise that point could be added. Thus upper bounds on the sizes or measures of radius- balls give lower bounds on the size of the separated set.
In a metric space , the closed ball centred at of radius is . It is a closed set, since the distance to is a continuous function. Its boundary need not be the whole corresponding distance sphere in an arbitrary metric space.
For in a normed vector space, define and use the displayed formula elsewhere. This continuous map fixes the closed ball of radius and maps every point outside it to the boundary along its radial line. If a continuous map is defined only on that closed ball, is a continuous extension to the whole space. This extension is useful when applying a theorem whose hypotheses concern a globally defined vector field.
An -net of a metric space is a subset such that every has for some . Its least possible finite size is the metric covering number with closed balls. A maximal set with pairwise distances greater than is an -net.
A cover of the unit ball by balls of radius gives a radius- metric net on the unit sphere: discard balls missing the sphere and choose a sphere point in each remaining ball. Every sphere point lies within of the selected point in its ball. The argument keeps the number of balls and ensures that the selected points have unit length, regardless of the initial covering centers.
For a symmetric matrix and an -metric net of the unit sphere, with , approximate a maximizing unit vector by . Expanding bounds its absolute value by . Rearrangement proves the bound. The volumetric bound for Euclidean metric nets limits the number of needed directions, allowing a union bound to control a random matrix.
A subset of the radius- Euclidean ball admits an -metric net of size at most . Take a maximal separated set: its disjoint radius- Euclidean balls lie in the radius- ball. Comparing Lebesgue measures gives the estimate. In particular, the unit sphere admits a net of radius one with at most points.
For a metric space or pseudometric space , this is the minimum number of balls of radius , with centers in , needed to cover . The displayed grid bound uses closed balls. For open balls, replacing the radius by a fixed constant factor gives the same entropy estimates. For and , a uniform grid gives . These polynomial growth bounds make the Dudley entropy integral finite.
For a subset of a metric space, its metric entropy at resolution is the logarithm of the least number of radius- balls covering , with value infinity when no finite cover exists. It quantifies how many choices are needed to approximate an element at that resolution. If points are pairwise more than apart, each covering ball contains at most one, giving a lower bound by their logarithmic cardinality. The logarithm base changes only a constant factor. This approximation entropy differs from Kolmogorov-Sinai entropy of a dynamical system.
Suppose outer functions in a family obey , and compose them with inner functions drawn from . Approximate the outer function within and each inner function within . The triangle inequality bounds the composed error by . Multiplying the numbers of possible net choices and taking logarithms gives the stated inequality. A uniform bound on first partial derivatives supplies for the unit ball, so the exponent of a common entropy bound for the outer and inner classes is retained under function composition.
For the unit ball of measured in the uniform metric, . The lower bound uses disjoint bump functions of spatial scale , height proportional to and independently chosen zero/one coefficients: there are functions separated at scale . For the upper bound, Multivariable Jackson approximation gives a trigonometric polynomial of degree . Its coefficients are bounded and can be rounded with coefficient accuracy proportional to divided by the coefficient count. Counting those rounded coefficient arrays supplies the logarithmic factor. The continuous-function unit ball without derivative bounds has infinite entropy for , by an infinite sequence of disjoint height-one bumps.
An -net of a metric space is a set such that every point lies within distance of a point of . A Cartesian grid of coordinate spacing is a finite -net of a bounded cube in the Euclidean norm. A Lipschitz bound transfers control on the grid to control over the whole cube.
Suppose with a random finite . On , a finite net with radius bounds the full supremum by the grid maximum plus . The Markov inequality controls the exceptional event using , and a union bound controls the grid maximum. Choosing the net spacing balances these two costs.
For a continuous path in a metric space, take the supremum over finite partitions of . This definition allows and needs no derivative. A metric geodesic parametrized on has length . In a Riemannian manifold, it agrees with the usual arc length integral for a smooth curve.
A metric space in which every two points are joined by a metric geodesic segment. Equivalently, they admit a continuous path whose metric path length equals their distance. In this general setting no Riemannian metric or covariant derivative is required.
A unit-speed metric geodesic in a metric space is an isometric embedding of a real interval. Every restricted segment realizes the distance between its endpoints. A one-point interval permits a constant segment. In a unit-edge graph, shortest edge paths parametrized by metric path length are metric geodesics; no smooth structure is required. This is stronger than the differential definition of a geodesic in a Riemannian manifold, which need only minimize locally: on a unit circle, an arc of angle is a Riemannian geodesic but its endpoint distance is only .
A metric geodesic triangle consists of three points of a geodesic metric space and a chosen metric geodesic segment between each pair. Multiple choices are allowed, and coincident vertices give degenerate triangles. A Gromov-hyperbolic metric space has a uniform bound on the distance from each side to the other two sides for every such choice. This definition applies to Cayley graphs and trees without tangent vectors or curvature assumptions; it does not invoke the surface angle formula for a geodesic triangle.
The metric topology consists of the sets such that, for every , some open ball lies in . Thus open sets describe which sufficiently small changes remain inside a region; they do not specify the numerical size of those changes.
For , the L1 norm, Euclidean norm, and maximum norm satisfyThese bounds make them equivalent norms. For example, : every open ball contains a sufficiently small open ball for either other metric. Hence all three define the same open sets, convergent sequences, and continuous maps. More generally, any two norms on a real or complex finite-dimensional vector space are equivalent norms; see H. A. Priestley, Functional Analysis I, §§0.5–0.7 and Theorem 4.3.
The metric topology therefore does not determine numerical distances. Multiplying a metric by preserves its open sets while multiplying every distance by . Nor does the general equivalence of metrics require constant-factor bounds: that stronger comparison holds for the three norms used here.
The Euclidean topology on is the metric topology induced by the Euclidean norm. A subset is open exactly when each of its points has an open ball contained in it. It agrees with the finite product topology on copies of the real line: the inequalities put a coordinate box inside every sufficiently small ball and a ball inside every sufficiently small coordinate box. The case is the one-point topological space.
A subset of a metric space is bounded if it lies in some finite-radius ball: there are and such that for every .
A subset of a metric space has boundedness when it lies in some ball of finite radius, equivalently when its diameter is finite. A function is bounded when its range is a bounded set. For real-valued functions, this means that has a finite upper bound.
Failure of boundedness: for every finite radius, some point lies outside the proposed bounding ball. A real-valued function is unbounded if its range is unbounded.
For a point and a nonempty closed set in a metric space, the distanceis a continuous function of . It vanishes exactly on .
- : distances are nonnegative and finite.
- if and only if : distinct elements have positive distance.
- : exchanging the endpoints leaves the distance unchanged.
- : the triangle inequality.
A metric equips its underlying set with a metric space structure; the distance function and the space carrying it are distinct concepts. The second requirement distinguishes a metric from a pseudometric, which may identify distinct elements at zero distance. The symmetry requirement also explains why directed travel times, such as uphill versus downhill times, need not define a metric.
A tempting alternative on the real numbers is . It is nonnegative, symmetric, and zero exactly on equal endpoints, but fails the triangle inequality: . Checking only the first three requirements would miss the failure.
The increasing function is subadditive on nonnegative arguments: each summand and is at least its numerator divided by . Thus is a metric whenever is. It is bounded and induces the same topology because and its inverse near zero preserve convergence to zero.
A metric is compatible with a given topology when its open balls generate exactly that topology. Compatible metrics on a compact topological space are uniformly equivalent: the identity maps between the resulting compact metric spaces are uniformly continuous. Consequently they define the same proximality and the same asymptotic-pair relation for a fixed continuous map.
This metric identifies isometrically with the open interval in the usual real distance. It induces the usual topology but is incomplete: the integer sequence has transformed limit outside that interval. This illustrates that completeness depends on the metric, not solely on its topology.
The discrete metric sets and for distinct points. It induces the discrete topology, and its Cauchy sequences are exactly the eventually constant sequences.
Every nonempty set equipped with the discrete metric is a bounded set, even if it is an infinite set. For , both the open ball and closed ball about are the singleton . At , the open ball is still , but the closed ball is the whole space; for , both are the whole space. Every subset is both an open set and a closed set. Consequently the boundary of the radius-one closed ball is empty, even though every point other than is at distance exactly one. Also, the closure of is , rather than the radius-one closed ball.
Zero distance in a pseudometric defines an equivalence relation: the triangle inequality proves transitivity. If and have zero distance, as do and , the triangle inequality in both directions gives . Thus distance descends to the quotient and becomes a metric, since zero quotient distance means the classes coincide.
The metric induced by the L1 norm gives taxicab geometry. Each difference in Cartesian coordinates contributes its absolute value independently, so an axis-aligned route with no backtracking realizes the endpoint distance.
The metric induced by the maximum norm measures the largest difference in Cartesian coordinates. Simultaneous changes of Cartesian coordinates cost only as much as the slowest coordinate requires.
A compact metric space is a metric space that is compact. Equivalently, it is complete and totally bounded.
A metric space is compact exactly when it is both complete and totally bounded. For the nontrivial direction, successively choose a point from a nested sequence of finite -nets; a diagonal construction gives a Cauchy subsequence of every sequence, and completeness gives its limit.
A metric space is totally bounded when, for every , it is covered by finitely many open balls of radius .
A metric space is totally bounded when, for every , finitely many open balls of radius cover it. Equivalently it has a finite -net at every positive scale.
A sequence converges to in a metric space when , equivalently when every neighbourhood of contains all sufficiently late terms.
A map between metric spaces is continuous exactly when always implies . If an inverse image of an open set were not open, points outside it could be chosen within distance of a point inside it, proving the converse by contradiction.
Every sequence in a compact metric space has a convergent subsequence. Conversely, sequential compactness and compactness are equivalent for metric spaces.
Every metric space is normal. For disjoint closed sets , the functionis continuous, equals zero on , and equals one on ; inverse images of disjoint neighbourhoods of zero and one separate the sets.
A metric space is compact exactly when every continuous function is bounded. For the converse, a noncompact metric space contains a closed discrete sequence; the unbounded function assigning its th point the value extends to by the Tietze extension theorem.
A metric satisfies : visiting an intermediate point cannot beat the direct endpoint distance. A norm satisfies the corresponding inequality .
Take , , and . For Euclidean distance, the triangle inequality reads . The direct line segment has metric path length , while the route through has metric path length . For Manhattan distance, the same comparison becomes : both routes are shortest. The line segment and the bent route both become metric geodesics when progress is measured by metric path length. For Chebyshev distance, the direct line segment has metric path length , while the same bent route still costs .
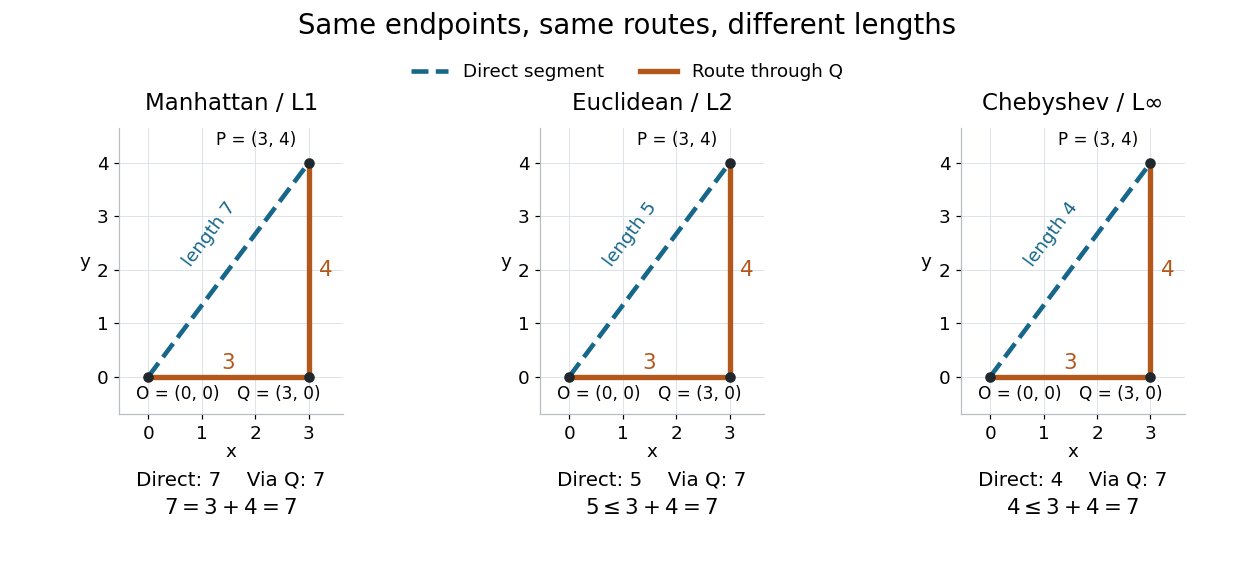


Repeated application of the triangle inequality bounds the endpoint distance by the sum along any finite chain of intermediate points. This explains why metric path length is always at least the distance between endpoints. Equality reveals a shortest route, but its shape and uniqueness depend on the chosen metric.
In a metric space, applying the triangle inequality in both directions gives . In a normed vector space, its corresponding form is . In particular, distance to a fixed point is a Lipschitz continuous real function.
For four points in a metric space,Both steps follow from the triangle inequality. The first also holds with an absolute value around the difference, by the reverse triangle inequality. This transports a difference of distances measured from one point into a sum measured from another.
For an integrable function with values in a finite-dimensional normed vector space,For the Euclidean norm, pair the integral with a unit vector in its direction and apply the Cauchy-Schwarz inequality pointwise.
For nonzero complex numbers , equality holds exactly when is a positive real number, equivalently when the two numbers have the same complex argument modulo .
If a surface lies outside a sphere centered at the origin, its minimum distance to the sphere is its minimum radial distance minus the sphere radius. For each surface point, the triangle inequality gives that lower bound, and the radial point on the sphere attains it. Thus minimizing the squared norm on the surface suffices.
For a line with , its unit normal is . Choose any point on the line and project the displacement to onto this normal. The absolute value of that projection gives the title formula. This is the shortest Euclidean distance, because any displacement to a different point on the line has the same normal component and an additional orthogonal tangential component.
For distinct points , the cross product in the numerator has magnitude twice the area of the triangle with third vertex . The same double area is the base length times the perpendicular height from , proving the displayed Euclidean distance. Equivalently, let and project onto the line direction. The squared distance is ; Lagrange's identity gives the same cross-product formula.
For two planes and with linearly independent normal vectors, put , , and . Their intersection is a line parallel to . Its closest point to the origin is orthogonal to that direction, hence has the form . The constraints give , , soFor every other point , orthogonality gives squared distance , proving the global minimum and its uniqueness. The positive determinant also proves that an intersection exists for every real . Parallel normals require a separate consistency check and do not define a unique intersection line.
With fixed positive scale estimates , this is Euclidean distance in standardized coordinates. It removes marginal units but ignores correlations. Small estimated variances can greatly amplify measurement noise; a zero scale must be handled separately.
The diameter of a nonempty subset of a metric space is . For a Euclidean circle it is the longest chord length; the same definition applies to arbitrary metric subsets.
In a normed vector space, the diameter of the convex hull of finitely many points equals their greatest pairwise distance. For and , with nonnegative coefficients each summing to one,The triangle inequality gives . The reverse inequality holds because all the vertices belong to the convex hull. Thus a continuum of distances inside a convex polygon can be controlled by finitely many vertex pairs.
Uniform continuity requires one input tolerance to work at every point of the domain for a chosen output tolerance.
Suppose is nonnegative, integrable and uniformly continuous on the positive half-line. If at times tending to infinity, uniform continuity supplies intervals of one fixed positive length around those times on which . An infinite disjoint subsequence of these intervals contradicts integrability. Thus the displayed implication holds. Mere smoothness at every finite time is insufficient: smooth peaks of shrinking widths can have finite integral and heights bounded away from zero.
Choose the uniform continuity input tolerance corresponding to output tolerance one. A totally bounded domain is covered by finitely many balls of smaller radius centred in the domain. Every function value differs by less than one from the value at one of their finitely many centres. Taking the largest centre value bounds the whole function. Compactness or closedness of the domain is unnecessary.
A product of two uniformly continuous functions need not have uniform continuity on an unbounded domain. The functions give the counterexample , since inputs and approach each other while their squared values remain separated. For bounded factors the estimate restores uniform continuity.
If a uniformly continuous function belongs to Lp space for some , then as . Otherwise choose points escaping to infinity with . Uniform continuity gives one radius on which around every . Extract disjoint such balls. Their contributions to are each at least , a contradiction. The finite- condition is essential: the constant function one lies in and does not vanish at infinity.
Every continuous can be approximated with pointwise convergence by uniformly continuous functions. Set and . The map is Lipschitz continuous with constant one and is uniformly continuous by the Heine-Cantor theorem, so is uniformly continuous on the whole line. On every fixed bounded interval, eventually.
The modulus of continuity of a function isIt quantifies uniform continuity by recording the largest oscillation of across pairs of points at distance at most .
Set and extend for . This positive, nondecreasing modulus of continuity is weaker than a linear Lipschitz continuity bound but still has . At small distances it is equivalent to . A signed cannot be an upper modulus at distances less than one. The planar vorticity velocity kernel maps into velocity fields with this modulus.
A uniform limit of uniformly continuous maps between metric spaces is uniformly continuous. Approximate the limit at both endpoints by one fixed member of the sequence and use its uniform continuity between them.
A function between metric spaces is uniformly continuous exactly when implies for every two sequences and . Failure of uniform continuity supplies pairs with input distance below but output distance bounded below.
Two metrics are equivalent when they induce the same topology. Global two-sided constant bounds imply equivalence, but equivalence alone need not supply such bounds.
On , the usual metric and induce the same topology, but their ratio along tends to zero. Thus no positive global lower comparison constant exists.
Topological equivalence does not determine uniform convergence. For the usual and arctangent metrics on , maps that change the value to at a single domain point have arctangent sup-error tending to zero while their usual sup-error diverges.
For a nonempty subset of a metric space, the distance to a set is . The triangle inequality gives ; swapping proves . Thus it is one-Lipschitz. Its zero set is exactly the closure of : every neighbourhood of meets precisely when this infimum vanishes. For a closed set, zero distance therefore implies membership. When the empty set is allowed, use the convention ; the finite-valued Lipschitz assertion applies to nonempty sets.
The set distance is the infimum of pairwise metric distances. Two nonempty disjoint compact sets have positive set distance: continuity attains the minimum on their Cartesian product, and a zero minimum would give a common point. Disjoint closed sets without compactness need not have positive separation.
In a metric space , let the nonempty compact set lie in the open set . If is nonempty, the distance to a set is a continuous function of : the triangle inequality gives . Since is a closed set, this distance is strictly positive on . The extreme value theorem attains its minimum on , soIf is empty, the extended-real convention gives . This result provides a single positive neighbourhood radius that stays inside at every point of . Compactness is essential: in the real line has zero distance between two sets from , although each point of has positive distance to a set from that complement.
A point of a metric space is isolated when some open ball about contains no other point of the space, equivalently when the singleton is open.
Articles were limited to the first 100 out of 156 total.
Articles by others on the same topic
There are currently no matching articles.