Two scalar labels constant along a magnetic field line are Euler potentials when their crossed gradients give the magnetic field. The magnetic vector potential proves that this representation is a solenoidal vector field. Conversely, two independent local line labels yield ; replacing by absorbs the factor. This is a local construction; a global regular single-valued pair requires compatible magnetic field line topology. Fixing boundary labels preserves their paired-footpoint connections in an ideal variation.
For an ideal infinitely long solenoid with interior magnetic field and radius , an axisymmetric Coulomb gauge representative of the magnetic vector potential isThis follows from by Stokes theorem. The exterior has zero curl but nonzero circulation around the enclosed magnetic flux. The Coulomb gauge condition alone does not eliminate every residual gauge transformation; symmetry and regularity select this customary representative.
The magnetic helicity integrates the dot product of a magnetic vector potential and its magnetic field. It measures linkage and twisting of magnetic flux. For a solenoidal vector field tangent to the boundary, it is unchanged by the gauge transformation , since the change is . If its density satisfies with both vector fields tangent to the boundary of a fixed volume, the divergence theorem gives conservation of its integral. This is an instance of helicity conservation by tangent boundary conditions.
For regular globally defined electromagnetic potentials, use , and the homogeneous Maxwell equations to prove the displayed identity. With vanishing spatial surface flux, its spacetime integral is minus one half the change of magnetic helicity. Zero integral therefore needs matching temporal helicity boundaries, not merely localized electric fields and magnetic fields. The Gaussian potential has helicity and supplies an explicit spatially localized counterexample when changes from zero to one.
For a magnetic vector potential , a solenoidal magnetic field and constant magnetic diffusivity , write . In a fixed closed volume with zero helicity surface flux, integration by parts makes the two differentiated factors in equal; the scalar-potential boundary term vanishes when . One sufficient boundary gauge is ; another standard setting is integration over all space with sufficient decay. Orthogonality of to gives the displayed identity. Unlike the resistive magnetic energy loss, is not sign definite. The zero normal magnetic field also makes gauge invariance under single-valued smooth gauge transformations.
With the closed-boundary assumptions of the resistive magnetic-helicity balance, define the nonnegative resistive magnetic energy loss . The Cauchy-Schwarz inequality gives the displayed bound. Consequently, in a family of fields with bounded as , resistive magnetic helicity loss tends to zero even when remains finite. This is an absolute conservation estimate; it is not a universal comparison of fractional decay times. For a single Beltrami field with and no motion, both and have the same fractional decay rate .
In a bounded regular domain, fix the global extension or circulation convention for the magnetic vector potential. A bounded inverse of curl on tangent solenoidal vector fields gives . The Cauchy-Schwarz inequality then gives . One construction extends the tangent field by zero outside the domain and uses the whole-space Biot-Savart law; its kernel of size is integrable over a bounded region, giving the required bound. Nonzero conserved magnetic helicity therefore prevents complete decay of magnetic energy.
Current helicity correlates a magnetic field with its curl, which is proportional to electric current density. It differs from magnetic helicity, which uses a magnetic vector potential. For a solenoidal monochromatic field of wavenumber in a periodic domain, choose . Then and .
An open flux tube carries magnetic flux through its end caps. Its ordinary magnetic helicity can therefore change under a single-valued gauge transformation. For inside and zero outside, a regular family of magnetic vector potentials is , inside and , outside. Their tangential components agree at . Inside, , so the helicity per unit length is . Changing is the gauge transformation , and changes this result whenever . The convention outside gives and helicity per unit length , while gives zero. Without an end-cap or gauge convention the ordinary helicity is not unique.
For smooth ideal magnetohydrodynamics, write and . The continuity equation and induction equation give . The vector-potential equation becomes . Contracting these two equations cancels their velocity-gradient terms and provesConsequently the magnetic helicity in a material volume satisfies . It is conserved when the magnetic field is tangent to the boundary. A single-valued gauge transformation changes by , which also vanishes under that condition.
For a smooth divergence-free field on , the differential form is closed. The radial homotopy formula gives a global magnetic vector potential with curl . For constant , this reduces to .
The Coulomb gauge imposeson the magnetic vector potential. A gauge transformation reaches this gauge when solves
For a free electromagnetic field with suitable boundary conditions, combine Coulomb gauge with . Gauss's law makes the second condition consistent in the source-free problem. The remaining field operator is spatially transverse and describes the two radiative photon polarizations. A constrained scalar potential must be restored when charges are present.
For the Maxwell field, the variation is time translation combined with a gauge transformation. With constant , , and the Lagrangian changes by . Its Noether current is directly the time component of the gauge-invariant Maxwell stress-energy tensor, providing the physical energy density without a potential-dependent improvement step.
A magnetic dipole moment is a vector that summarizes the strength and orientation of a localized magnetic source. For a planar current loop, it is the electric current times the vector area: . The right-hand rule fixes the unit normal vector : curl the fingers of the right hand along the conventional current, and the thumb points along . This single vector predicts both the distant magnetic dipole field and the turning effect of an imposed magnetic field.[ref]
11.5 Force and Torque on a Current Loop. §11.5, equations 11.20–11.22: loop moment, winding count and torque
The SI unit is ampere times square metre, , equivalently joule per tesla. A magnetic dipole moment is neither a magnetic field nor a magnetic monopole: a closed current loop can have a nonzero magnetic dipole moment while its net outward magnetic flux through any closed surface remains zero, as required by Gauss's law for magnetism.
For a localized, steady electric current density , the more general definition isHere the cross product is integrated over the complete source, including return paths. Steadiness requires , and localization requires sufficiently rapid decay for the boundary terms to vanish. Under these assumptions the localized steady-current moment identities give : shifting the origin by changes the proposed magnetic dipole moment by . An isolated open wire segment does not satisfy these assumptions. [ref].
The magnetic moment inferred from the weak-field Curie constant of a localized angular-momentum multiplet. Uniform zero-field occupation of its substates gives , yielding . Here is the Landé g-factor and the Bohr magneton. The dimensionless number differs from the saturated projection .
For each particle the moment includes its signed charge and inverse mass. Writing both moments with one reference magneton requires effective signed magnetic factors. A shared symbol must not hide the sign change or imply equal magnitudes; the reference magneton is distinct from the SI vacuum permeability.
With energy convention , the difference of physical moments is the negative derivative of a transition energy. Some trapping conventions instead call the positive energy slope an effective magnetic moment. The sign convention must be stated; either gives the same absolute sensitivity of transition frequency to a field fluctuation.
For a uniformly charged spherical shell rotating rigidly in the quasistatic nonrelativistic model, a latitude strip carries current . Its loop area is , so integration uses and gives . For an isolated conducting shell, . Clockwise and counterclockwise descriptions require a viewing direction; the vector formula fixes the sign without that ambiguity.
In the small-sphere oscillatory-field limit, surface current density excludes the changing magnetic field. Adding a central magnetic dipole to a uniform applied field and imposing zero normal field at the sphere gives . The minus sign expresses diamagnetism; it does not make this dipole's backward radiation cancel the electric contribution.[ref]
The energy of a magnetic dipole in an external field is . For dimensionless angular-momentum projection and , the energy is .
The spin-only magnetic moment neglects orbital contributions and approximates by two: for parallel unpaired electrons. Four unpaired electrons give .
For uncoupled centres with approximately equal , squared magnetic moments add: . This does not assume that the individual spins add to a definite total spin; appreciable exchange interaction invalidates the independent-centre approximation.
A small linearly magnetizable sample has a magnetic dipole moment induced by its applied field. In a fixed principal direction, write ; this convention gives units . A uniformly magnetized ellipsoid of volume has . The effective interaction potential energy at fixed source current is . The factor one half arises because the moment must be induced as the field is raised; differentiating as though it described a permanent moment would count the response twice. The response model excludes remanence, nonlinear saturation and hysteresis.
For constant scalar response and a body small compared with the applied field's spatial variation scale, the gradient of the induced magnetic dipole energy gives . Along an axis this is . For an ellipsoidal body, put to obtain . Positive effective magnetic susceptibility attracts the body towards stronger field; a negative response repels it. Reversing the source current leaves the force unchanged because both the induced moment and the field gradient reverse. Shape and orientation enter through the demagnetizing factor, not merely through volume.
The Barnett effect is the change of a body's magnetization caused by mechanical rotation. Turning the whole specimen can bias the internal angular momentum carrying its magnetic moments, even with zero applied magnetic field. It is the reciprocal physical question to the Einstein-de Haas effect: impose rotation and measure magnetization, rather than change magnetization and observe mechanical motion. The relation between the two becomes especially transparent when the same signed gyromagnetic ratio connects magnetic moment and internal angular momentum.
Samuel Jackson Barnett published Magnetization by Rotation on 1 October 1915 in Physical Review. The Barnett rotation magnetometry experiment below provides an inspected modern example. The important distinction is between an equivalent term in a Hamiltonian and the actual external magnetic field measured by a magnetometer: the first biases the material; its resulting magnetization produces the second.
Let the specimen rotate uniformly with angular velocity . In its rotating reference frame, the internal Hamiltonian containsHere is the internal angular momentum operator about the rotation axis, and contains the internal interactions and any imposed magnetic field expressed in that frame. It does not include the separately treated rigid body's rotational kinetic energy. For a sector with magnetic moment , the rotational term has exactly the form of a magnetic dipole potential energy:This Barnett equivalent magnetic field has tesla units, with the angular convention for the signed gyromagnetic ratio: is in radians per second, not revolutions per second. Its sign matters. For an electronic contribution with , positive favors positive and negative . A sector with has the opposite magnetic sign. Equal need not correspond to equal Barnett fields for sectors having different gyromagnetic ratios.
A short derivation fixes the sign independently of any material model. Put and transform a laboratory quantum state by . The Schrödinger equation givesThe transformed laboratory term is denoted by ; a laboratory perturbation not stationary in the rotating frame can make it time dependent. Establishing a steady thermal response also requires exchange of internal angular momentum with the rotating body, for example through spin-lattice relaxation. A mere relabeling of coordinates cannot polarize isolated, unrelaxed spins.
The Barnett field is a useful description of spin-rotation coupling, not a claim that empty laboratory space acquires a uniform magnetic flux density . In particular, inserting it into the Lorentz force on an unrelated test electric charge is unjustified. A nearby magnetometer detects the specimen's actual stray magnetic field and backgrounds, rather than directly detecting this internal Hamiltonian parameter.
Consider an explicitly stipulated dilute independent spin-one-half two-level system with zero applied magnetic field. Each constituent has and , with constant signed gyromagnetic ratio . Ignore interactions and the specimen's own magnetic field. At positive temperature , thermal equilibrium with the rotating lattice gives energy levels . Define the dimensionless variable , where is the reduced Planck constant and is the Boltzmann constant. The partition function and Boltzmann distribution giveTaking the expected value giveswhere is number density. This is the rotational version of the independent-moment magnetic response. The angular momentum aligns with positive rotation even when the magnetic moment points oppositely. The probability ratio provides a direct population check of the sign.
For , expand the hyperbolic tangent to obtainThe slope against is positive for either sign of , while the slope against has the sign of . At fixed , reversing reverses both means, and gives zero. At fixed nonzero , the formal limit saturates at ; the linear approximation must not be extrapolated there. At , the response vanishes. These limits describe the toy canonical ensemble, whose equilibration is assumed.
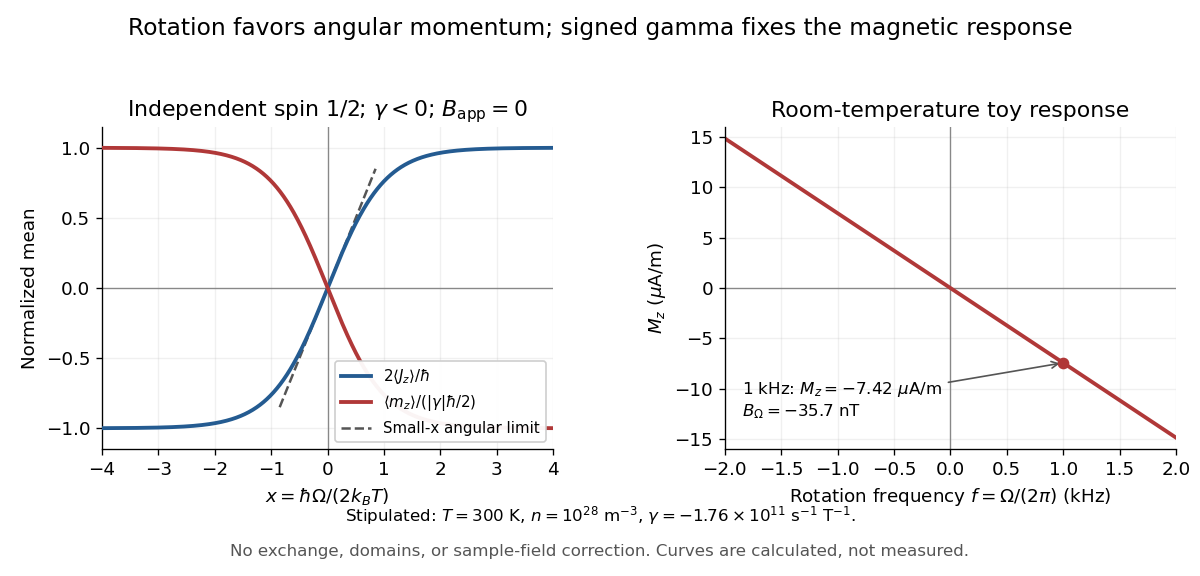
For a numerical example, stipulate , , , and rotation frequency . With , , and , the model givesThese are teaching inputs and calculated outputs, not measured material values. The corresponding internal angular momentum density is . Keeping a rotor at prescribed while its internal angular momentum changes requires the drive to supply the appropriate angular impulse. In an isolated body the mechanical part instead changes oppositely, as in magnetomechanical angular momentum balance. There is no creation of net angular momentum by choosing a rotating frame.
The two-state calculation is not a general formula for a ferromagnet. Exchange interactions, magnetic domains, magnetic domain-wall pinning, magnetic anisotropy, and hysteresis can determine which response is accessible. Both spin angular momentum and orbital angular momentum can contribute; a single constant gyromagnetic ratio may be only a restricted effective description. Rotation sets an internal bias, while the material and its preparation determine magnetization. The Barkhausen effect illustrates why a smooth bias can produce jumps instead of the toy smooth curve.
For a limited, reversible, isotropic linear model, suppose the same intrinsic volume magnetic susceptibility responds to the applied bias and to . For a uniformly magnetized ellipsoid along a principal axis, include its demagnetizing factor :Solving this linear equation yieldsHere and are actual magnetic field intensities; the added rotational bias is an equivalent drive in the constitutive response. In SI, dimensionless multiplies an intensity in , so would omit and have the wrong units. A susceptibility defined instead as has different units. State the convention before comparing formulas.
At zero applied magnetic field intensity, a stipulated gives prefactor in a sphere, with , and a prefactor approaching in a long axial ellipsoid. This is a geometry check of the assumed linear model. A real cylinder does not have an exactly uniform demagnetizing field, and an irreversible ferromagnet cannot in general be represented by this single linear equation. Inferring an intrinsic gyromagnetic ratio requires an independently calibrated material response and a geometry-dependent conversion of the measured stray magnetic field.
The 2015 experiment used an air-driven nonmagnetic rotor containing polycrystalline gadolinium, with magnetic shielding and an external fluxgate magnetometer. Air drive reduced motor backgrounds. Measurements at 297–305 K were above the Curie temperature, at rotation frequencies up to 1.5 kHz. Reversing airflow reversed rotation and the magnetic signal; an empty capsule showed no speed-dependent signal. The readout measured stray magnetic field; geometry converted it to magnetization. Sample temperature was checked immediately after stopping. Heating and the conversion model limit inference.[ref]
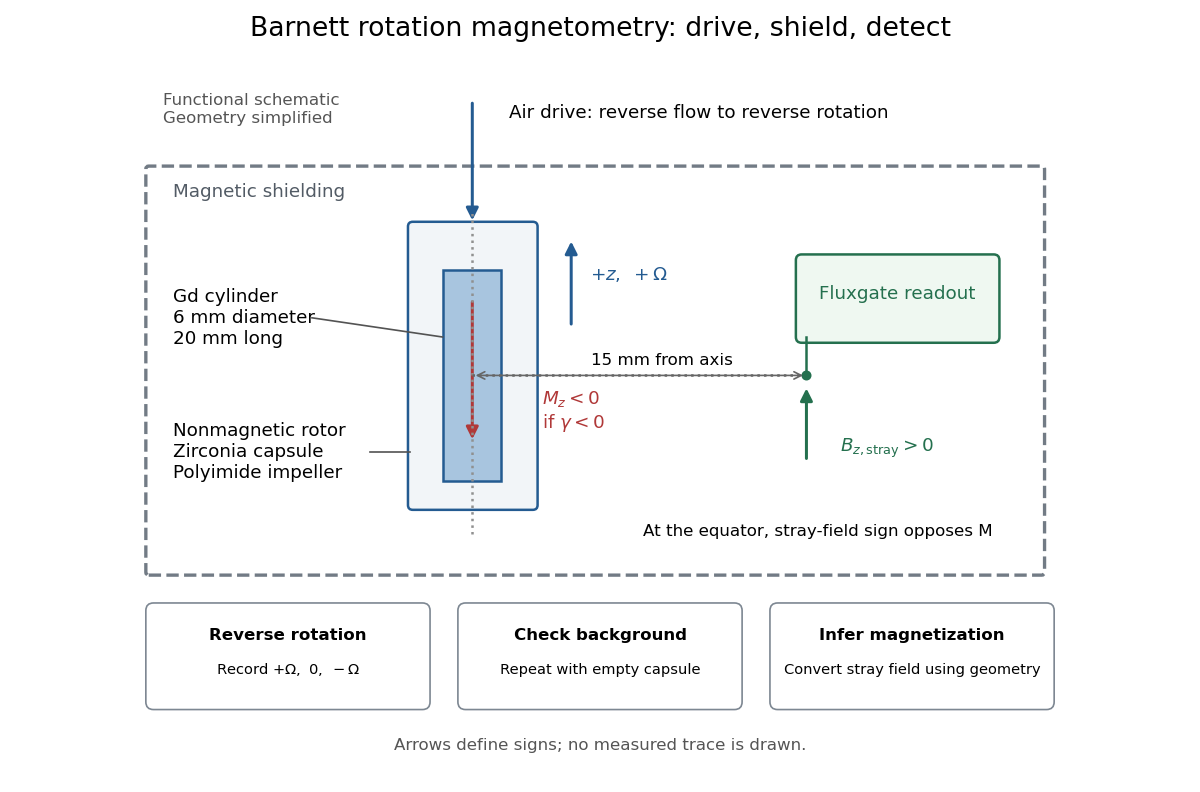
An additional analysis check follows from rotation symmetry. For signed sensor output , separateAn ideal linear Barnett effect appears in the odd component; a fixed offset appears in the even component. This is a proposed diagnostic, not a claim about the paper's processing. A background correlated with direction can also be odd: reversal alone is insufficient. Empty-rotor checks, zero-speed readings, calibration of sensor polarity, and controlled temperature changes test different errors. Equatorial stray-field sign must also be converted to magnetization sign: for an axial magnetic dipole moment, the magnetic dipole field at its equator points opposite to that magnetic moment. The apparatus diagram makes this otherwise easy-to-miss sign change visible.
The Einstein-de Haas effect is mechanical rotation or twisting caused by a change in a body's magnetization. The microscopic carriers of magnetic dipole moment also carry angular momentum: changing their net orientation can transfer angular momentum to the body. A freely suspended ferromagnet can therefore turn when its magnetization reverses. A suspension instead stores part of the response as an elastic twist. This makes a microscopic property accessible through a macroscopic angle.
The central measurement compares a change of magnetic dipole moment with transferred angular momentum, giving a gyromagnetic ratio. It complements an ordinary magnetic dipole torque measurement: even with the applied magnetic field parallel to the suspension axis, so that an ideal axial magnetic dipole moment has , changing magnetization can drive an axial twist. The external drive supplies energy; conservation of angular momentum still requires accounting for the suspension and any external axial torque.
Let be the axial magnetic dipole moment, where is the axial magnetization. Write for the internal angular momentum associated with that magnetic dipole moment, and for the body's rotational angular momentum, with moment of inertia . In a regime admitting a constant signed gyromagnetic ratio , axial conservation of angular momentum givesHere names the internal reaction torque on the body, not an additional external torque. The external term includes the suspension. The model assumes that the changing internal angular momentum is transferred to the measured mechanical motion, with other storage or escape channels negligible on the observation timescale. A changing or non-collinear mixture of orbital angular momentum and spin angular momentum need not admit a single constant .
During a reversal fast compared with the mechanical response, with negligible external angular impulse, integrating the balance givesFor and an electronic , the body acquires : its initial rotation is toward by the right-hand rule. Reversing the reversal reverses the impulse. Over a complete periodic cycle, , so the net reaction angular impulse vanishes; a resonant alternating response does not imply steadily accumulating angular momentum.
The orbital angular momentum prediction can be derived without a material model. A charge traveling around a circle of radius at angular frequency has loop electric current and magnetic dipole moment . Its orbital angular momentum is , hence, for an electron with electric charge ,The electron magnetic moment associated with intrinsic spin instead obeysHere is the elementary charge, is the electron mass, and is the electron spin g-factor.[ref]
The magnetic moment of the electron by Polykarp Kusch. pp. 299–300: orbital and intrinsic moments and the Dirac value
Thus the same change of magnetic dipole moment corresponds to about half as much transferred angular momentum in the pure-spin model as in the orbital angular momentum model. This factor of two is a relation between magnetic dipole moment and angular momentum, not evidence that an electron is literally a rotating charged sphere. In a material with both contributions, the inferred coefficient is a material-dependent magnetomechanical gyromagnetic ratio.In 1915, Albert Einstein and Wander Johannes de Haas suspended a soft-iron cylinder by glass fibre between coaxial coils. Alternating magnetization drove torsional resonance; a mirror reflected lamplight onto a scale. They compensated Earth's magnetic field, tilted the coils, and rotated the suspension attachment to test unwanted magnetic dipole torques. Added known moment of inertia calibrated the mechanical response.[ref]
Experimental proof of the existence of Ampère's molecular currents by Albert Einstein and Wander Johannes de Haas. §§4–5, pp. 702–706: apparatus, controls, calibration
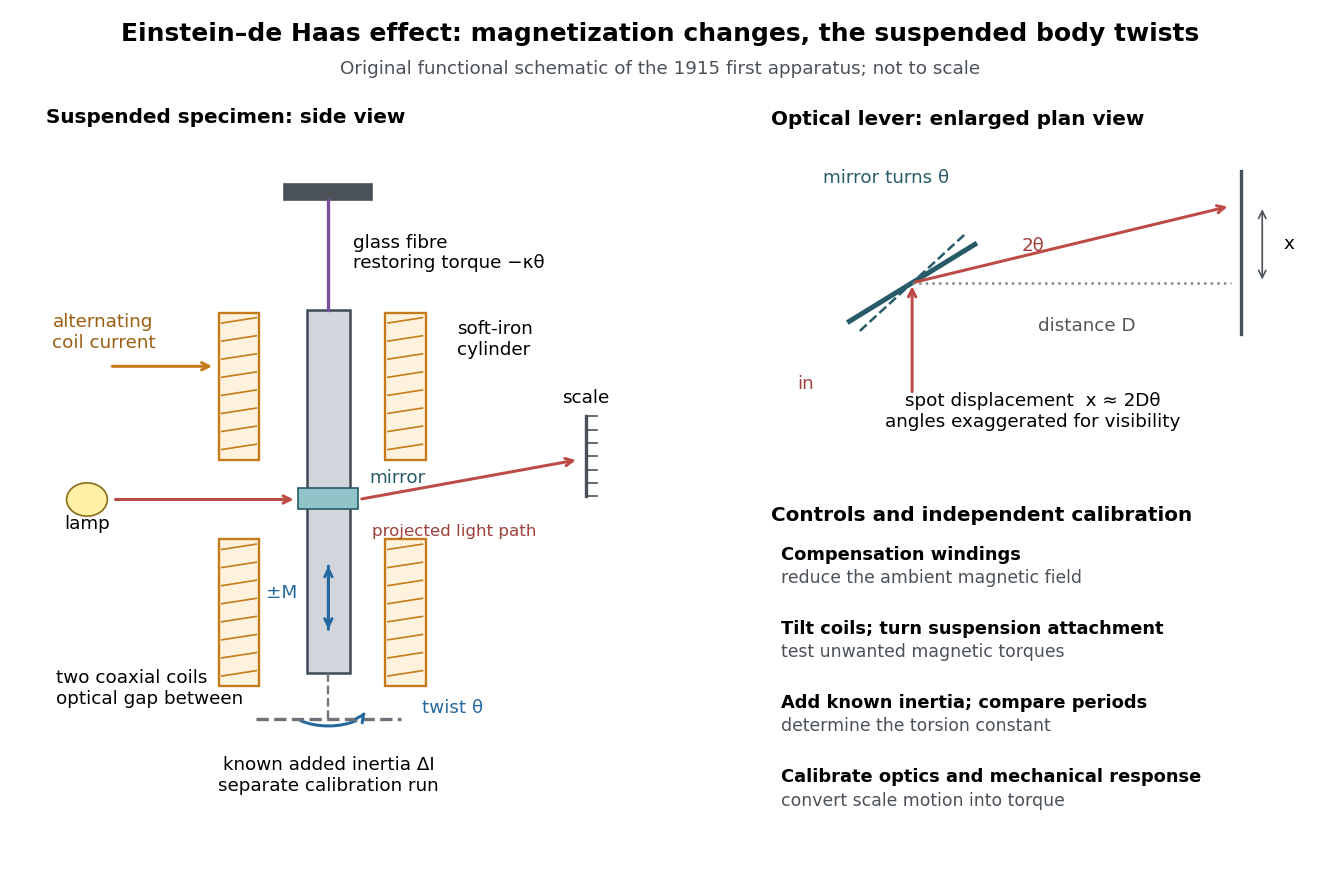
Einstein-de Haas experiment: suspended magnet, drive and optical readout
. Original functional schematic of the first apparatus, rather than a scale reconstruction. The split coaxial coils leave an optical gap. The enlarged plan view explains the optical lever; the calibration bar is attached for a separate calibration run. Compensation windings are represented by their function. Details.Their paper acknowledges a failed phase determination and claims only ten-percent precision for the revised measurement. Its agreement with the orbital gyromagnetic ratio prediction was not a direct discovery of spin.[ref]
Experimental proof of the existence of Ampère's molecular currents by Albert Einstein and Wander Johannes de Haas. §6, pp. 706–707: phase failure; §7, pp. 707–711: resonance, precision
Comparing that orbital gyromagnetic ratio prediction with the electron spin g-factor explains why a successful qualitative demonstration of angular momentum transfer can coexist with an inadequate quantitative interpretation. The stated precision is the authors' estimate; it does not establish that all systematic errors were bounded by that amount.The general control problem follows directly from the model. Unwanted magnetic dipole torque can drive the same mechanical resonance as the desired reaction torque. In the ideal geometry and alone produce no axial cross product, but transverse magnetic dipole moments, stray transverse magnetic fields and imperfect alignment can. Nulling stray magnetic fields and deliberately varying alignment test this contribution. Merely observing a large resonant twist cannot identify its cause.
For a nearly instantaneous magnetic response, a sinusoidal magnetization makes follow the drive while is in phase quadrature. An ordinary magnetic contribution proportional to is then distinguishable by phase, after removing the mechanical frequency response. Hysteresis or delayed magnetic response can spoil this simple separation. The measured magnetization, rather than the coil electric current alone, must set the reference. Mechanical vibration, magnetostriction coupled through imperfect geometry, and changing suspension properties require separate checks; none is eliminated simply by reversing the coil electric current.
An original reduced model makes the calibration explicit. Let the torsion pendulum have restoring torque , with torsion constant , and viscous damping torque , with . Allow an unwanted axial torque :Here is the undamped natural angular frequency and the quality factor. The forced harmonic oscillator response must be included before a twist can be interpreted as a torque.
Using the complex amplitude convention and similarly for and , differentiation multiplies by . Substitution givesThis is the torque-to-twist transfer function. With and real positive , the twist amplitude isFor , the twist phase relative to is . At it is zero, although the reaction torque leads by . A phase measured at the mirror is not automatically the phase of the applied torque.
A fixed-amplitude reference torque measures directly. The Einstein-de Haas effect instead contains an extra factor when stays fixed. Consequently its twist amplitude peaks exactly at in this model, whereas the fixed-torque peak is at when . To verify the first statement, divide the squared denominator of by : the quantity to minimize is , minimized at . Both response curves tend to zero at high frequency; only the magnetomechanical curve also tends to zero at zero frequency.
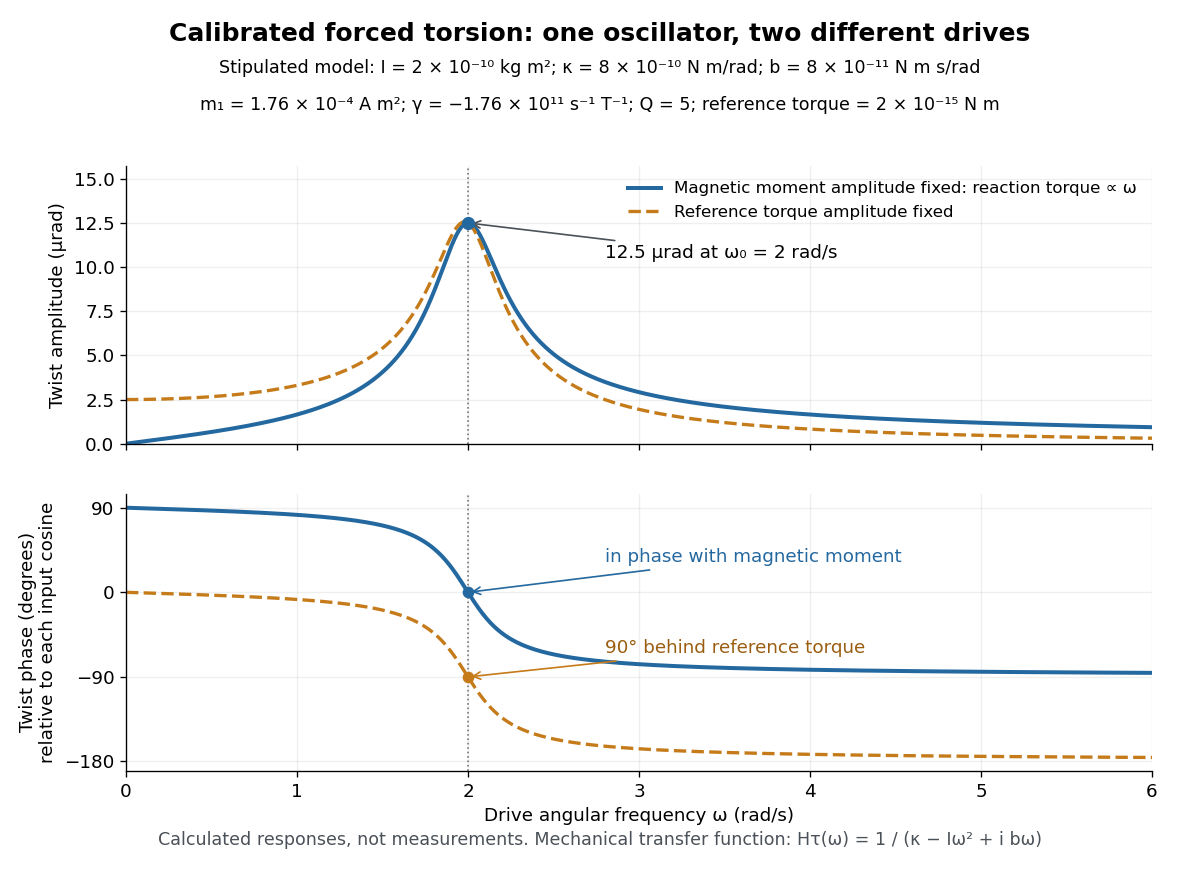
Calibrated forced torsion: distinguish the mechanical response from the magnetic drive
. Original calculated curves, not historical measurements or fitted data. A constant reference torque and a constant-amplitude magnetic dipole moment share the same mechanical transfer function. The lower plot uses each input's own cosine as its phase reference. Markers at show equal twist amplitudes but different phases. Details.For a fully stipulated example, choose , , , , and . These teaching inputs give , , reaction torque amplitude at , andAn optical lever at distance gives small-displacement spot amplitude ; its full peak-to-peak width is . For a fast reversal from to , the same inputs give and initial , provided the external angular impulse is negligible.
One independent mechanical calibration adds known moment of inertia , keeping unchanged. If are the undamped oscillation periods before and after adding it, thenFor in the stipulated example, and , recovering the chosen and . Real damped periods require a damping correction: a free decay has angular envelope and oscillation angular frequency . Measuring that decay determines . Calibrating the optical scale, mechanical response and change of magnetic dipole moment separately is what makes the inferred gyromagnetic ratio meaningful.
A current loop is a closed path carrying electric current. For a thin wire following a closed curve , the volume integral defining its magnetic dipole moment becomes a line integral:The vector area is for a planar current loop. For a nonplanar current loop, use the vector area, rather than the scalar area of an arbitrarily chosen spanning surface. Reversing the electric current reverses without changing the geometry. [ref].
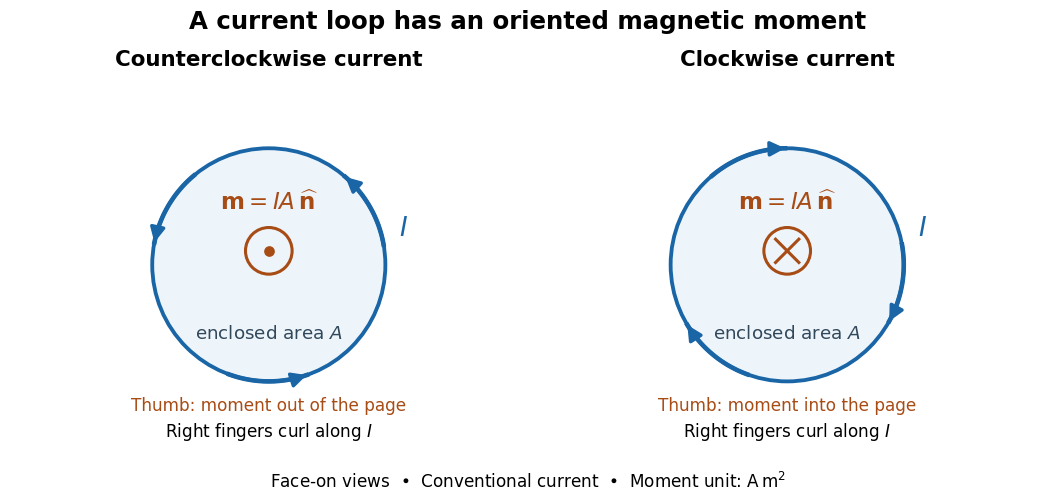
For closely spaced identical turns carrying the same electric current, the magnetic dipole moments add: . Each turn contributes its own vector area; unequal areas or differently oriented turns require a vector sum. As a calculated example, twelve circular turns of radius carrying give . This is an idealized example, not an experimental measurement.
A Helmholtz coil arrangement uses two identical coaxial circular windings separated by their radius, carrying equal electric currents in the same circulation sense. Their combined magnetic field is especially uniform near the midpoint, making it useful for a current-loop torque experiment. The cancellation of the axial second derivative there follows from the on-axis magnetic field of a circular current loop.
An externally imposed magnetic field that is nearly uniform over a rigid current loop produces the torqueThe angle is measured between the magnetic dipole moment and the external magnetic field, not between the plane of the current loop and the magnetic field. The magnetic dipole potential energy uses a dot product, whereas the torque uses a cross product. The torque is largest when the magnetic dipole moment is perpendicular to the magnetic field; parallel alignment minimizes the potential energy.[ref]
11.5 Force and Torque on a Current Loop. §11.5, equations 11.22–11.23: vector torque and orientation energy
For the sign convention and , positive rotation increases andThus at the torque turns the magnetic dipole moment toward the external magnetic field. Both parallel and antiparallel alignment have zero torque, but they are respectively a stable equilibrium and an unstable equilibrium. With no damping, a freely released current loop can undergo oscillation around the stable equilibrium; settling requires damping.
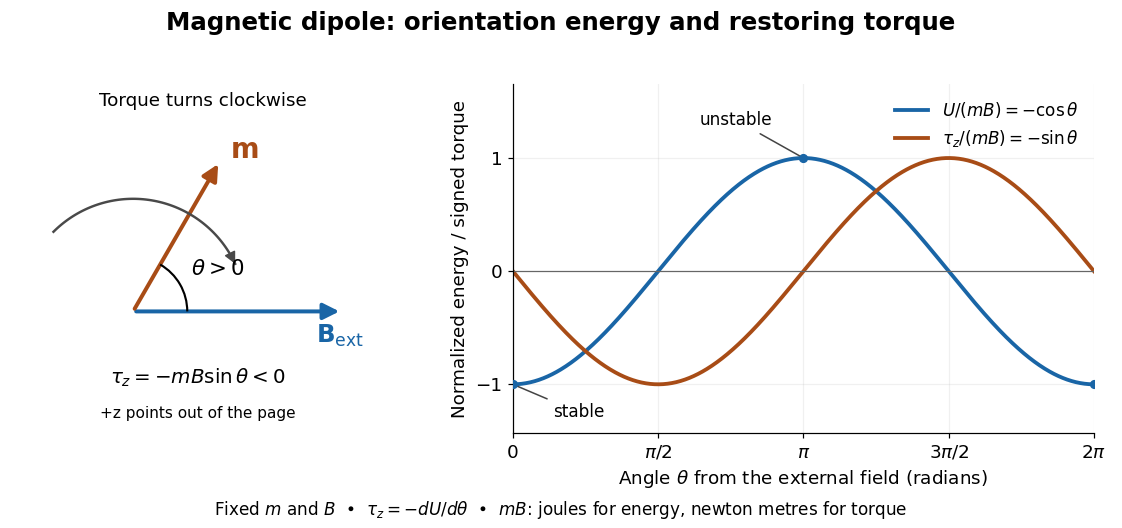
In the twelve-turn example, take and . The predicted torque is and the magnetic dipole potential energy is . The unit check is ; torque and energy have the same physical dimensions but different physical meanings.
A short derivation starts with the magnetic force on a current-carrying wire, . In an exactly uniform magnetic field, the net force is , but its torque need not vanish: opposite sides produce a turning couple. Integrating gives . Integrating at fixed and gives the orientation potential energy. This is the mechanical orientation potential energy for a maintained electric current, with the external source held fixed; the energy accounting for field and power supply is a separate problem. A varying external magnetic field requires corrections across a finite current loop, and can also give a net force.
The PHYWE guide Magnetic moment in the magnetic field makes the magnetic dipole moment measurable. A circular test current loop sits between a pair of Helmholtz coils, with separate supplies and meters for the test electric current and field-producing electric current . The test current loop is mounted on a torsion dynamometer. The guide varies , the number of turns, the test electric current, diameter, and the angle between the magnetic dipole moment and magnetic field. Its angular settings are spaced by . The leads hang loosely and are twisted together to suppress extra torque; the instrument zero is checked frequently because moving leads can shift it. Its reported results include approximately linear dependence on each electric current and on winding count, and approximately quadratic dependence on diameter.[ref]
The readout is a balance of torques. According to the manufacturer's Torsion dynamometer 0.01 N operating instructions, a metallic band supplies the restoring torque. First set the indication to zero with the applied force absent and center the lever using the zero knob. Apply the load, then turn the indicating knob until the lever returns to its original zero position. The scale then reads a force equivalent, not a torque directly. The quoted scale division is . For a force applied perpendicular to the calibration lever arm at distance , the conversion is ; a current loop applies a couple, so its torque must be compared with the calibrated restoring torque.[ref]
Torsion dynamometer 0.01 N operating instructions. §§1–4: metallic-band compensation, zero procedure, force indication and scale specification
For a quantitative repeat, independently check that conversion with known forces at a measured perpendicular lever arm, and check the imposed magnetic field at the test current loop. These are proposed calibration checks, not additional measurements reported here. The ideal Helmholtz coil model predictswhere and are the winding count and radius of each field-producing Helmholtz coil, distinct from and of the test current loop. Derive by adding the on-axis magnetic field of a circular current loop at distances from both coils. Independently calibrating and the restoring torque lets a fitted torque amplitude determine as amplitude divided by , to compare with .
Useful additional controls are to reverse only , reverse only , and reverse both: the signed torque should reverse in either single reversal and be unchanged in the double reversal. Record baselines with each electric current separately zero, and subtract a nearby zero reading to reduce torsion balance zero drift. Repeat angular settings in both directions to reveal lead-dependent offsets. These are suggested controls. Limits include finite magnetic field uniformity, uncertainty in effective winding area and angular zero, meter calibration, Joule heating, and residual lead torque. An apparently sinusoidal trace alone does not establish the absolute magnetic dipole moment. No raw laboratory data or new measured values are claimed here.
A torsion dynamometer compares an applied torque with the restoring torque of a twisted elastic element. Returning the lever to its zero position allows a current-loop torque experiment to hold the test orientation fixed while reading the compensating torque.
Far outside a localized steady source of size , at distance , its multipole expansion starts with the magnetic dipole moment if that moment is nonzero. In vacuum, using SI units,where is the vacuum permeability, , and the magnetic field is the curl of the magnetic vector potential. The magnetic dipole field falls as , and the magnetic vector potential as . The localized steady-current moment identities remove the putative term in the magnetic vector potential. No magnetic monopole is needed. If different current loops cancel the total magnetic dipole moment, a higher term of the multipole expansion supplies the leading distant magnetic field. [ref].
The approximation is not valid at the center of a finite current loop. For a circular current loop of radius and electric current , the exact on-axis magnetic field of a circular current loop and the distant approximation areTheir ratio is : at , the approximate magnetic field exceeds the exact magnetic field by about relative to the exact value. Near the source, retain its geometry rather than replacing it with a point source specified only by its magnetic dipole moment.
A localized steady electric current density satisfies . Integrate the divergences of and over a region enclosing its support; all boundary fluxes vanish. The first identity removes the monopole term from the magnetic vector potential expansion. The antisymmetric first moment is equivalent to the magnetic dipole moment .
For a small fixed magnetic dipole moment in a slowly varying external magnetic field, gives the displayed force. For a compact current loop, integrate to first order in the field's spatial variation to get the same result. For a coaxial small loop with , this becomes . A spatially uniform field can exert torque but gives zero net force; a field gradient is essential. The approximation assumes the field does not appreciably vary over the dipole's dimensions.
The orientation-dependent interaction of two distant localized magnetic dipole moments. Its scale makes close approach important in a concentrated magnetic-particle dispersion. Depending on geometry, it can favor chains, collective alignment or frustrated configurations.
A dimensionless factor relating a system's magnetic dipole moment to its angular momentum, with a specified charge and mass convention. Electron spin, orbital motion, and a combined atomic level have different g-factors; the convention must be stated before comparing them.
For a charged spin one-half particle with the Dirac equation reference value , the anomalous magnetic moment is conventionally expressed by the dimensionless quantity . For the electron, write . A stipulated would therefore mean : a excess of the spin-component moment over one Bohr magneton. This is a teaching input, not a quoted measurement.
The electron magnetic moment couples an electron's angular momentum to a magnetic field. Its intrinsic spin contribution isHere is the Bohr magneton, and is the positive electron spin g-factor under this sign convention. The minus sign makes magnetic dipole moment antiparallel to spin angular momentum. An electron in a chemical atom can also contribute an orbital magnetic dipole moment; the measured response of a whole atomic level combines these contributions.
Measuring a tiny departure of from tests how well a theory predicts an electron's interaction with its surroundings. The Dirac equation gives before radiative corrections; the anomalous magnetic moment makes a small correction experimentally accessible.[ref]
The magnetic moment of the electron by Polykarp Kusch. pp. 299–300: spin moment and Dirac prediction
A useful strategy is to compare two atomic energy levels whose orbital and spin contributions have different weights, rather than trying to calibrate an absolute magnetic field more accurately.The dimensionless coefficient in the spin part of the electron magnetic moment. It is distinct from a gyromagnetic ratio, which has units: in the angular convention, . It is also distinct from the Landé g-factor of a combined atomic angular momentum and from a nuclear or hyperfine g-factor.
For spin one-half, the largest magnitude of a spin-component magnetic dipole moment is , not . Thus the ideal value gives one Bohr magneton. This follows directly from the spin angular momentum projections .
Polykarp Kusch and Henry Michael Foley compared hyperfine structure resonance frequencies for different electronic states of gallium, indium and sodium. Their 1948 paper reports mutually consistent departures from the ratios expected with orbital factor and spin factor . Comparing several states constrained the alternative explanation of perturbed atomic levels.[ref]
The Magnetic Moment of the Electron by Polykarp Kusch and Henry Michael Foley (1948). Abstract: atomic states, frequency comparisons and interpretation
The Rabi molecular beam magnetic resonance experiment explains the readout principle: a resonant transition changes an atom's magnetic response, and hence its transmitted beam signal. Kusch describes rapidly interchangeable ovens, several radio frequency oscillators and careful field homogenization. Measurements taken during monotonic field drift were reduced to a common field.[ref]
The magnetic moment of the electron by Polykarp Kusch. pp. 303–304: resonance analysis, ovens, oscillators and field drift
Compare differently weighted atomic magnetic moments
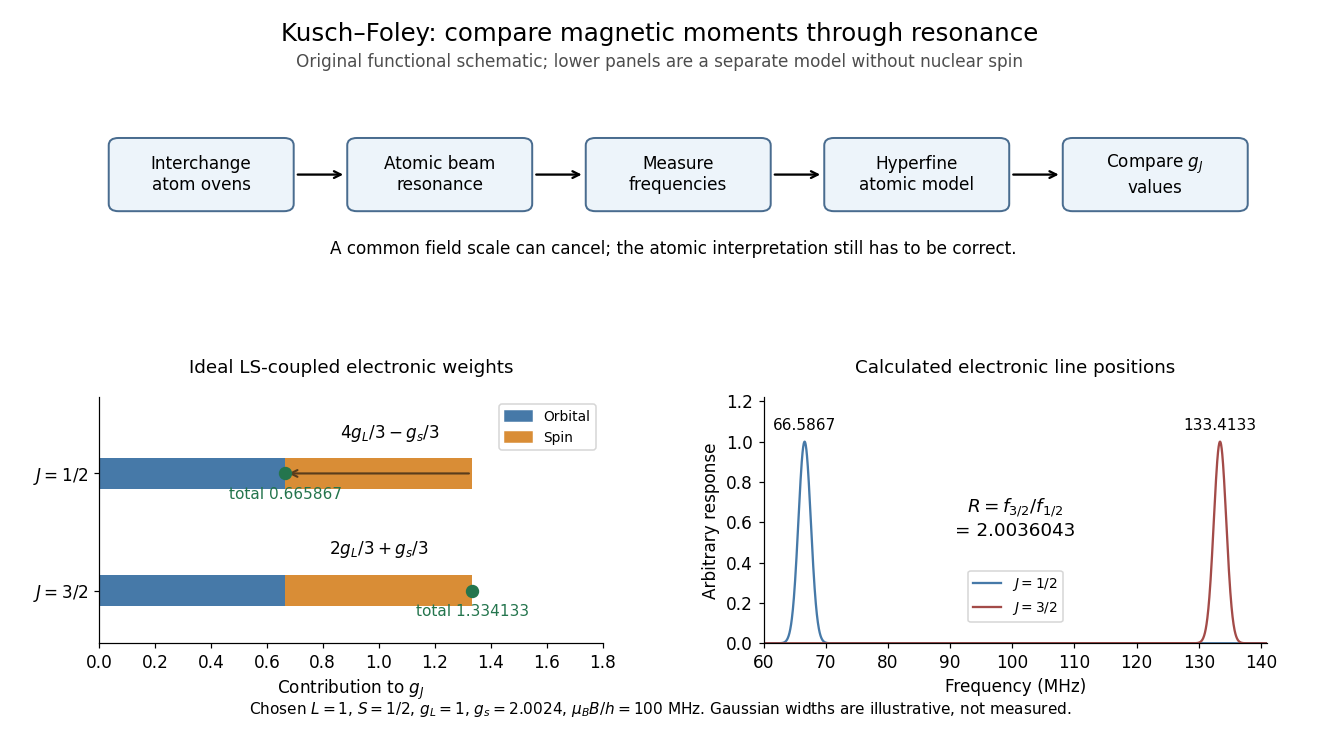
. Original functional diagram of the Kusch-Foley magnetic moment experiment and a separate ideal LS coupling calculation. The upper flow identifies the functions of beam preparation, resonance readout and atomic modeling; it is not a surviving apparatus drawing. The lower weights are calculated for , , and chosen , without nuclear spin. The frequencies in the teaching model cannot be substituted directly for measured hyperfine lines. Details.Real hyperfine structure lines are not simply bare electronic times field. Nuclear magnetic moments, known interaction constants and nonlinear field dependence enter the inference.[ref]
The magnetic moment of the electron by Polykarp Kusch. pp. 303–305: hyperfine modeling and atomic-state perturbations
Field homogeneity controls line broadening; alternating species addresses drift. Neither control removes an error in the atomic model. The beauty of the comparison is the separation of two problems: cancelling a shared calibration scale and testing whether several physical systems imply the same electron spin g-factor.An original reduced model makes the cancellation explicit. Assume LS coupling, neglect nuclear spin, and write the electronic magnetic dipole moment as . For , , the projection used to derive the Landé g-factor givesThese coefficients follow by substituting or into the angular-momentum projection formula; neither level measures pure spin alone. In a weak uniform magnetic field, adjacent electronic projections have spacing when . ThereforeThe common magnetic field and Bohr magneton cancel. The ratio determines , not without further knowledge of . For , it gives . Small departures from are magnified differently from small departures of from ; the two fractional changes should not be identified.
With the stipulated inputs , and , the two electronic frequencies are and . Their ratio is approximately , and inversion recovers . These are ideal electronic lines, not historical gallium data. Nuclear spin, mixing between levels and other deviations from LS coupling require a more complete model in an actual atom.
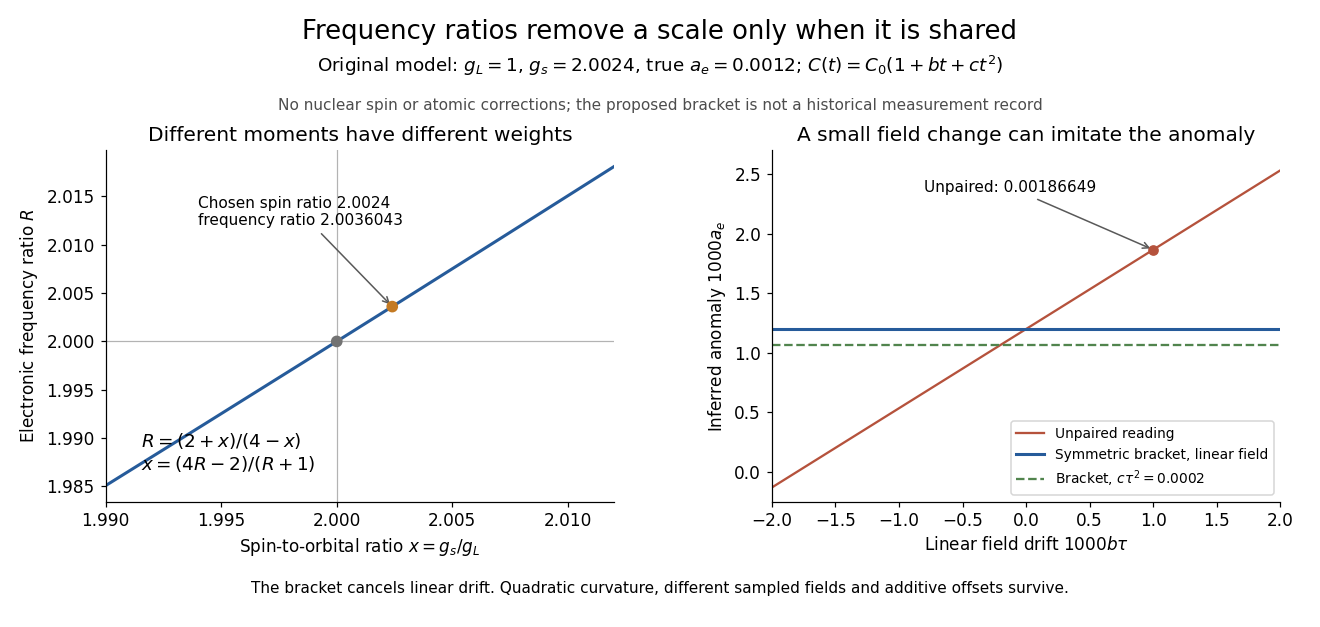
Even a shared field does not cancel if it is sampled at different times. Write and , where . As an original proposed diagnostic, bracket the -state reading at with -state readings at :If , the denominator is exactly , so . A single earlier reading instead gives . For the preceding numerical model and , this unpaired comparison falsely gives approximately ; interpolation recovers . The sequence illustrates cancellation and is not asserted to be Kusch and Foley's exact historical timing protocol.
Cancel a shared calibration scale without hiding its limitations
. Original calculations for spin-orbit g-factor ratio from two P states and drift cancellation in a g-factor comparison. All inputs are stipulated. The left plot shows the nonlinear inversion from a frequency ratio to a spin-to-orbital g-factor ratio. The right plot contrasts an unpaired reading with a symmetric bracket under linear field drift; the dashed curve adds chosen quadratic curvature . No curve is a measured resonance or a historical fit. Details.For a curved field , the same calculation givesThe linear drift cancels but the curvature remains. Different fields sampled by the two beams, additive frequency offsets and incorrect atomic corrections also survive. For a small ratio error , direct differentiation of the inverse relation givesRepeated readings can reduce random measurement uncertainty; agreement among genuinely different state comparisons is what tests shared systematic errors in their interpretation.
The proportionality coefficient between a system's magnetic dipole moment and angular momentum when applies. In the angular convention, is expressed in radians per second per tesla; is the corresponding coefficient in cycles per second per tesla. Its sign determines the relative orientations of the magnetic dipole moment and angular momentum.
The scalar and Dirac magnetic spectra do not determine every higher-spin spectrum. Extrapolating to assumes gyromagnetic ratio two. For a spin-one field with that coupling the lowest aligned mode becomes unstable once its squared frequency turns negative; spin alone does not imply this coupling.
The magnetic dipole moment of an atomic nucleus. Its relation to nuclear spin is expressed by the gyromagnetic ratio; its interaction with an applied magnetic field underlies nuclear magnetic resonance.
The dimensionless coefficient in the nuclear-moment relation when I is in hbar units. The saturated projection is . Distinguish a ratio of these coefficients from a ratio of moments when the nuclear spins differ.
The nuclear magneton is the unit of magnetic momentwhere is the proton mass. For a nuclear spin operator , the nuclear magnetic moment is . Consequently its gyromagnetic ratio is , and its Larmor frequency in a uniform magnetic field of magnitude is . The nuclear magneton is smaller than the Bohr magneton by the electron-to-proton mass ratio.
A circular charge distribution rotating with angular speed can be decomposed into current loops. A hoop of line density and radius has ; a disc of surface density has .
A uniformly charged solid sphere of total charge , radius and angular velocity has magnetic dipole momentFor a uniformly charged thin spherical shell the coefficient is instead of . At large distances the magnetic field is a magnetic dipole field, . Its angularly averaged magnitude and root mean square magnitude both scale as ; its angularly averaged vector is zero. Steady rotation of this axisymmetric charge distribution produces magnetostatics, not radiation.
A uniformly charged rotating sphere has an exactly dipolar exterior magnetic vector potential. For a concentric equatorial loop of radius outside the sphere, Stokes theorem gives . If its effective source electric current is defined by , its mutual inductance is . The finite-source vector potential is regular through the spanning disk; an exterior point-dipole expression should not be integrated through its singular origin.



