Multilinear algebra studies maps linear in each of several arguments, including determinants, tensors, and exterior products.
Index notation describes vectors, matrices and tensors by their components relative to a chosen basis. For example, matrix multiplication reads . The free indices identify the resulting component, while is summed. An explicit summation sign avoids depending on an implicit Einstein summation convention.
A linear subspace of a coalgebra satisfying the displayed conditions. These are exactly the conditions for the comultiplication and counit to descend to the quotient vector space . An ideal that is also a coideal in a bialgebra gives a quotient bialgebra.
For unital algebras over a field , a coalgebra measures into when a linear map satisfies the displayed identity and . Group-like elements therefore act by unital algebra homomorphisms over a field.
A terminal measuring coalgebra: every measuring map from factors uniquely through its universal measuring map by a coalgebra homomorphism . Composition of universal measurings makes a bialgebra, with the identity map providing its unit.
An element of a coalgebra satisfying the displayed identities. A group-like element in a Hopf algebra is invertible with inverse its antipode image.
A right comodule is an object with a coaction satisfying the coassociativity and counit laws. This definition extends from coalgebras to comonoids in a monoidal category.
A natural underlying transformation of tensor bifunctors on right comodules over a field has components . Recover ; colinearity and monoidal axioms impose further equations.
For a transformation from the tensor built using to the tensor built using , colinearity is : . Scalar maps enter this convolution product for coalgebra maps via the common algebra unit.
A comonoid morphism induces a functor on right comodules, replacing by and preserving underlying objects and arrows. For bimonoids, it is strict monoidal exactly when is also a monoid morphism.
A natural transformation between corestriction functors over a field has components , recovered by . Monoidality forces to be a unital algebra homomorphism over a field; for a Hopf algebra, supplies the inverse.
The structure map of a comodule; a right coaction satisfies with coherent parentheses, and is the inverse right unitor.
For a coalgebra and a unital associative algebra over a commutative ring , maps have convolution , with unit . The two-sided convolution inverse of is the antipode.
The notation suppresses the summation index of a comultiplication; iterated indices use coassociativity. For a comodule, write .
A multilinear map is a map between vector spaces that is linear in each argument when all other arguments are fixed. For example the evaluation is bilinear, and the determinant is multilinear in its columns. The universal property of a tensor product replaces this separate linearity by a single linear map from .
Multilinearity is the property of being a multilinear map: each argument enters linearly while every other argument is fixed.
A bilinear map is a map between vector spaces that is linear in each argument when the other is fixed. The nonlinear temperature advection can be written as the diagonal of a bilinear map, , when velocity depends linearly on temperature. Unlike a bilinear form, its output need not be a scalar.
A bilinear map between normed vector spaces is jointly continuous exactly when it satisfies the displayed product bound. Continuity at zero gives a bound on a product of balls; rescale each nonzero input separately to obtain the inequality. Conversely, expand the increment as and apply the product bound to every term. Thus continuity at zero already implies joint continuity everywhere for a bilinear map.
A map between vector spaces is bilinear when it is linear in either argument with the other held fixed. A scalar-valued bilinear form is the case and is the scalar field. Checking bilinearity is one of the algebraic steps in verifying a real inner product; being a symmetric bilinear form and having positive squared norm impose further conditions.
Let be a symmetric bilinear map on a finite-dimensional real vector space. If is parallel to for every , then it has the displayed form for one covector . Write in a basis. Applying the condition to and excludes every component outside their span and gives . Set and extend by bilinearity. Dimension one follows by the same definition. The trace identity proves uniqueness without depending on the chosen basis.
A continuous bilinear map obeys . Expanding leaves the displayed linear term and remainder . For product norm , the remainder has norm at most , hence is . This proves the Fréchet derivative formula.
Let be nonzero finite-dimensional complex vector spaces, and let have injective restrictions when either nonzero factor is fixed. It induces a map from to , where , , and . Pullback of the degree-two generator is , since both factor restrictions are projective linear embeddings. Its th power is in integral cohomology. The target must therefore have complex dimension at least . Positivity of both factor dimensions is necessary; a zero factor can make the claimed inequality false.
For nonzero finite-dimensional complex vector spaces , suppose a bilinear map never vanishes on a pair of nonzero vectors. Equivalently, each map obtained by fixing one nonzero argument is injective. If its associated map on has image dimension , projectivization gives a map to whose positive degree-two class pulls back to . The nonzero top power in the product cohomology ring of complex projective space proves the bound. Multiplication of polynomials of bounded degree attains equality. Nonzero hypotheses matter: with a zero factor, slice conditions can be vacuous.
An alternating multilinear map vanishes whenever two arguments are equal. Swapping two arguments reverses its sign.
A multilinear map is antisymmetric when swapping two arguments negates its value. Over a field of characteristic different from , this is equivalent to being an alternating multilinear map: repeated arguments give , hence ; conversely expand to get the sign change. In characteristic , the repeated-argument condition is stronger than the sign-change condition alone.
An alternating trilinear form is a scalar-valued map, linear in three arguments, which vanishes whenever two arguments agree. In characteristic zero, interchanging two arguments negates its value, while cyclic permutation preserves it. For a symmetric bilinear form on a Lie algebra, the tensor is alternating exactly when is an invariant bilinear form on a Lie algebra.
A tensor product turns a bilinear map into a linear map. For vector spaces over the same field , its elements are finite sums of pure tensors , subject to bilinearity:The scalar belongs to ; writing makes this choice explicit. These rules preserve separate linearity while allowing arbitrary linear combinations of products.[ref]
Linear Algebra Done Right by Sheldon Axler (4th edition). §9D, 9.71–9.74, printed pp. 372–373: tensor products, bilinearity, and bases
For a concrete example, take , with basis vectors in the first copy and in the second. The four tensor-product basis elements areThe pure tensor made from and expands toEach basis vector in one factor can interact with each basis vector in the other. This is why dimensions multiply; the tensor-product coefficient matrix displays these four interactions as a two-by-two grid.
The tensor product is different from the Cartesian product . With componentwise vector addition and scalar multiplication, the latter contains pairs and has dimension . The map is bilinear, generally neither linear on that Cartesian product nor injective nor surjective. In our example, , and ; the separability of a tensor explains why some outputs cannot be reached at all. Both spaces happen to have dimension four when , but this coincidence does not identify their structures.
A partial inner product contracts one factor of a bipartite state against a fixed bra, leaving a vector in the other factor. For and , the result is . It is linear in and conjugate-linear in . For a normalized rank-one projective outcome on the first factor, its squared norm is the outcome probability; divide by that norm to obtain the conditional pure state when it is nonzero.
For two unital associative algebras over a field , their tensor product carries the multiplication in the title, extended by bilinearity, with identity . Choosing a basis of the second factor gives the basis of a module for the resulting left -module; dual basis functionals recover the coefficients uniquely.
For associative algebras of finite dimension over a field , write a central tensor as in a basis of . Commutation with every forces each into the center of an associative algebra . Reexpand in a basis of and commute with every to force the second coefficients into . The reverse inclusion follows by multiplying pure tensors.
For a bilinear map , there is exactly one linear map satisfying . Equivalently, , where . The universal property of a tensor product concerns the vector space together with this distinguished bilinear map.[ref]
Linear Algebra Done Right by Sheldon Axler (4th edition). §9D, Theorem 9.79(a), printed p. 375: unique linear factorization
Here is a complete calculation over the real numbers. Define the bilinear mapIts values on pairs of basis vectors determine on the four tensor-product basis elements:Consequently, for ,For and , the direct calculation gives . Using the expansion of instead gives . The linear map also handles a nonseparable tensor such as : , even though no single pair has .
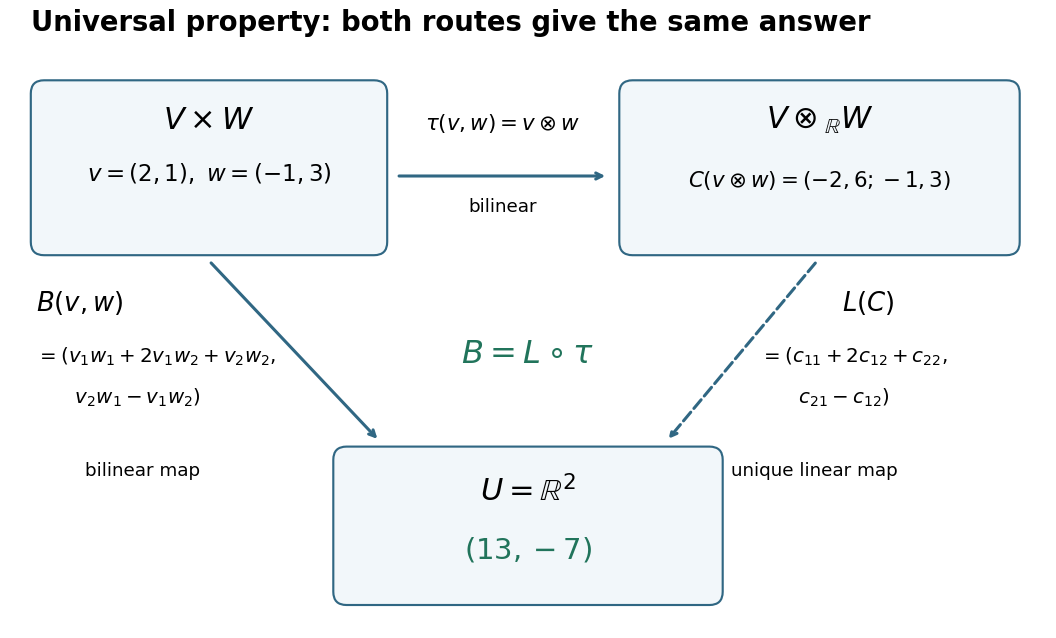
A short proof uses a tensor-product basis: assign and extend by linearity. Expanding both inputs verifies by bilinearity; the assigned values on a basis force uniqueness. More generally, every multilinear map factors uniquely through a linear map from . This lets formulas involving several inputs define linear maps without choosing coordinates; tensor contraction uses the evaluation pairing between a vector and a covector.
If and are bases of finite-dimensional vector spaces over , then the products form a basis of . There is one independent coordinate for every pair of indices.[ref]
Linear Algebra Done Right by Sheldon Axler (4th edition). §9D, Theorems 9.72 and 9.74, printed pp. 372–373: dimension and tensor-product basis
For a proof outline, bilinearity expands each pure tensor asso these products form a spanning set. For linear independence, take the coordinate functionals from the two dual bases. The bilinear map induces a linear functional on the tensor product, satisfying . Applying it to a proposed zero linear combination selects just , forcing every coefficient to vanish. Thus dimensions multiply, rather than add. This finite-dimensional count includes a zero factor, whose tensor product has dimension zero.
After choosing ordered bases, identify a tensor with its matrix . This is a linear isomorphism between and the vector space of -by- matrices: each tensor-product basis element becomes the matrix with one entry equal to one and all others zero. In particular, a pure tensor has the outer product coefficient formulaHere on the right denote column coordinate vectors. The identification depends on the chosen bases, while the tensor itself does not. Over the complex numbers, the same formula uses the ordinary transpose , with no complex conjugation; replacing it by the conjugate transpose would conjugate the scalar in the second input, violating bilinearity.
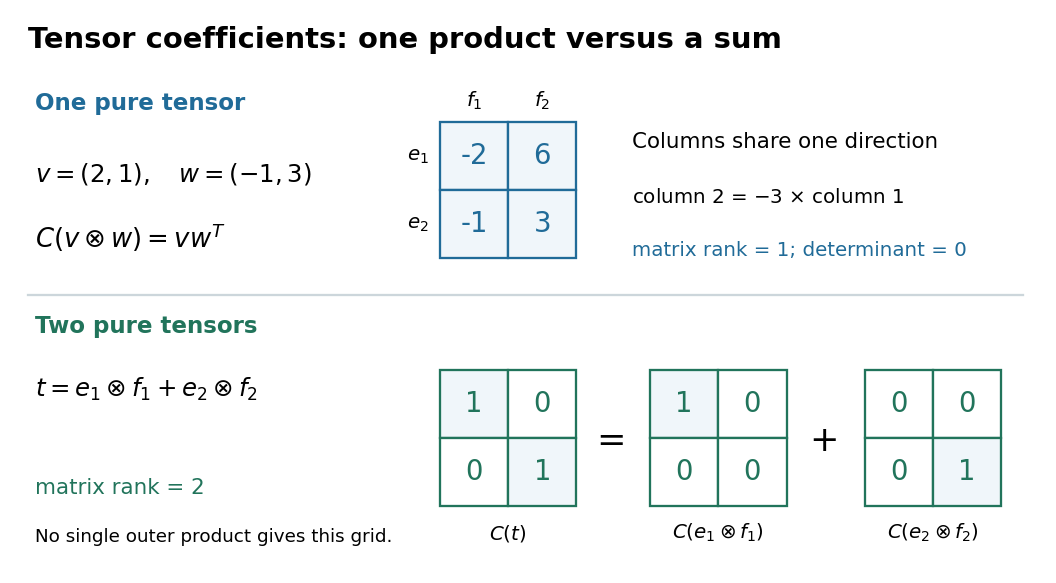
In a two-factor tensor product over a field, a pure tensor is also called a separable or decomposable tensor: it can be expressed as one product . Every tensor is a finite sum of pure tensors, but a sum need not itself be a pure tensor.[ref]
Tensor Products I by Keith Conrad. §3, printed p. 9: elementary, simple, decomposable, and pure tensors; Example 2.1, printed pp. 4–5: outer products do not fill the matrix space
For finite-dimensional vector spaces, the tensor-product coefficient matrix gives a decisive test: a nonzero tensor is a pure tensor exactly when its matrix rank is one. Indeed, every column of is a scalar multiple of . Conversely, if all columns of a nonzero matrix are multiples of one nonzero column , collect their multipliers in to obtain . The zero tensor is also a pure tensor, for example , but its matrix rank is zero.
In , the tensoris nonseparable: its matrix rank is two and its determinant is one, whereas . Directly, trying requires and . The first two equations force all four scalars nonzero, contradicting the others. In contrast, products sharing a factor do combine: . Thus being written as two summands alone does not establish nonseparability.
The two-factor tensor rank is the smallest number of pure tensors whose sum equals , with zero allowed as the empty sum. For two finite-dimensional vector spaces over the same field, it equals the matrix rank of the tensor-product coefficient matrix. A sum of outer products has column space contained in the span of their first factors, so its matrix rank is at most . Conversely, choose a basis for the column space, express each column in that basis, and collect the coefficients into row vectors . This yields , hence a sum of pure tensors.
The pure tensor therefore has two-factor tensor rank one, whereas has two-factor tensor rank two. Both have two factors: the number of factors and the minimum number of product summands are different counts. Over the real numbers, the singular value decomposition supplies a useful decomposition , with one nonzero term per matrix rank. The two-factor rank equality does not extend to three or more factors by merely choosing one matrix layout.
The tensor algebra of a vector space is the graded algebrawith multiplication given by concatenation of tensors.
The truncated tensor algebra discards products of degree greater than . Its multiplication is . Every element with scalar part is invertible by a finite geometric series in its positive-degree part. Truncated exponential and logarithm are finite polynomials.
The tensor square is the second tensor power . Over a field of characteristic different from two it decomposes as the direct sum of the symmetric square and exterior square.
The symmetric algebra is the quotient of by the ideal generated by . It is graded by symmetric powers:
The nth symmetric power is the quotient of that identifies tensors differing by a permutation of their factors. Equivalently, over characteristic zero it is the subspace of symmetric tensors.
In the symmetric power of the defining unitary group representation, diagonal torus weights are indexed by nonnegative integer tuples summing to , with one monomial per weight space. Torus averaging extracts a monomial from any nonzero invariant complex subspace. The complexified Lie algebra acts by on the symmetric algebra. Whenever , the displayed action moves one unit of degree from to with nonzero coefficient. Finite transfers connect every degree- monomial, so the subspace is the entire representation. The case is the one-dimensional trivial representation. This proof needs neither the Weyl character formula nor the Weyl dimension formula.
The three-dimensional irreducible representation of SU(2) has weights . Thus the character of its th symmetric power is . Its weight has multiplicity for . Subtracting adjacent weight multiplicities gives one copy of each . The invariant subspace is one-dimensional for even and zero for odd .
For eigenvalues of a finite-order linear action, its symmetric power characters satisfy . The denominator is the alternating generating polynomial of its exterior power characters.
For , contraction with the invariant symmetric bilinear form splits off the trivial line in the symmetric square of the defining special orthogonal group representation. Its null space is the traceless symmetric square. It contains a highest-weight vector of weight , and the Weyl dimension formula gives , exactly its dimension. Complete reducibility of compact-group representations therefore makes that null space irreducible. The entire symmetric square is reducible because of the invariant line.
For , , the symmetric square splits into an invariant line and its irreducible traceless part of highest weight . The exterior square of the defining orthogonal representation is the adjoint module of highest weight . For , the exterior square splits instead into highest weights and . This exception reflects that so4 Lie algebra is semisimple but not simple.
Over every field, including characteristic two, there is a natural isomorphismThe middle summand maps to the mixed product . Monomial bases prove bijectivity, and the Leibniz rule makes the map equivariant for Lie algebra representations.
For the defining real representation of , the symmetric square splits as a scalar trace plus symmetric trace-free tensors: . The trace projection is , so the second summand has dimension .
For the trace-free summand is an irreducible real group representation. To see this, diagonalize a nonzero symmetric trace-free matrix in a nonzero invariant subspace. Two diagonal entries differ. Infinitesimal rotation in their plane yields a nonzero symmetric off-diagonal matrix; rotations carry it to every coordinate pair, and a rotation through produces a difference of two diagonal entries. These off-diagonal matrices and diagonal differences span all symmetric trace-free matrices, so the invariant subspace is the whole summand. For , its dimension is 299, the third-level nontrivial multiplet of the lowest levels of a fully transverse ND bosonic string.
The exterior algebra of a vector space combines scalars, vectors, and higher-dimensional oriented elements in one graded algebra. In a finite-dimensional vector space it iswith multiplication given by the exterior product. Degree zero is the scalar field, degree one is , and degree two is the space of bivectors. Multiplication adds degrees: combining two vectors produces a bivector, rather than another ordinary vector.[ref]
The essential rule is . Repeating the same direction cannot produce a nonzero oriented area. Bilinearity then gives : expand and remove the two zero self-products. The alternating rule remains part of the definition in characteristic two, where sign reversal alone would not force a self-product to vanish.
If with standard basis , every element of its exterior algebra has the formThere are four independent coefficients: one scalar, two vector components, and one area component. In , the respective degree dimensions are , giving eight components in total. More generally, the exterior power basis gives total dimension .
This language is useful when direction and orientation matter together. Determinants measure the action on top-degree exterior powers; differential forms use exterior powers of a dual space to describe quantities integrated along paths, surfaces, and higher-dimensional regions. The Grassmann algebra viewpoint also makes the sign changes in anticommuting generators systematic. A single multiplication rule connects geometry and algebra.
A bivector is an element of the second exterior power . A simple bivector is one exterior product ; in real Euclidean space, it records the oriented area generated by those two vectors. A general bivector is a sum of such elements and need not describe just one plane. Covariant counterparts are differential two-forms, which take two vectors as inputs rather than belonging to .
In , chooseExpanding by bilinearity givesThe three coefficients are signed areas of the projections onto the , , and coordinate planes. They are three components of one bivector, not the three coordinates of either input vector.
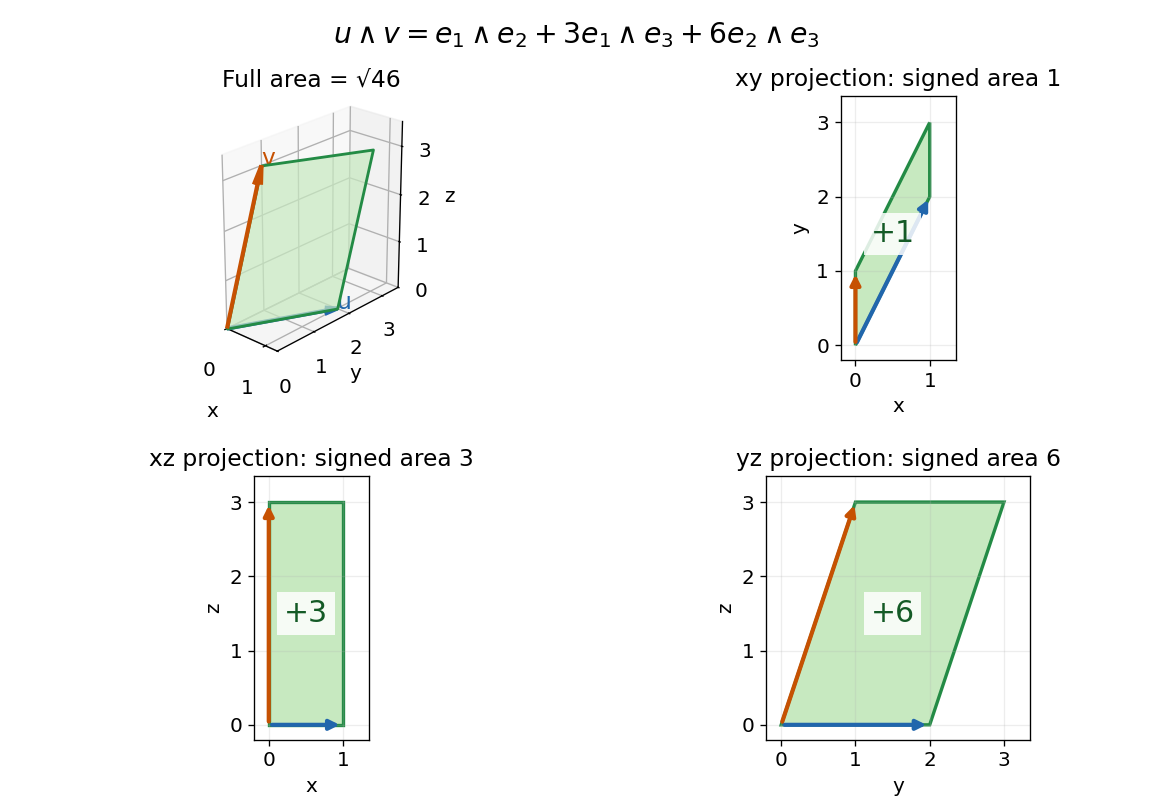
With the usual dot product and a fixed orientation of a vector space, the cross product represents this area element by the normal vector . The order of the components matters: corresponds to , while corresponds to . The Gram determinant checks the full area:Here the norm on bivectors is the one induced by the Euclidean inner product. The exterior product exists without that metric and in arbitrary dimension; the familiar cross product description relies on the additional three-dimensional geometry.
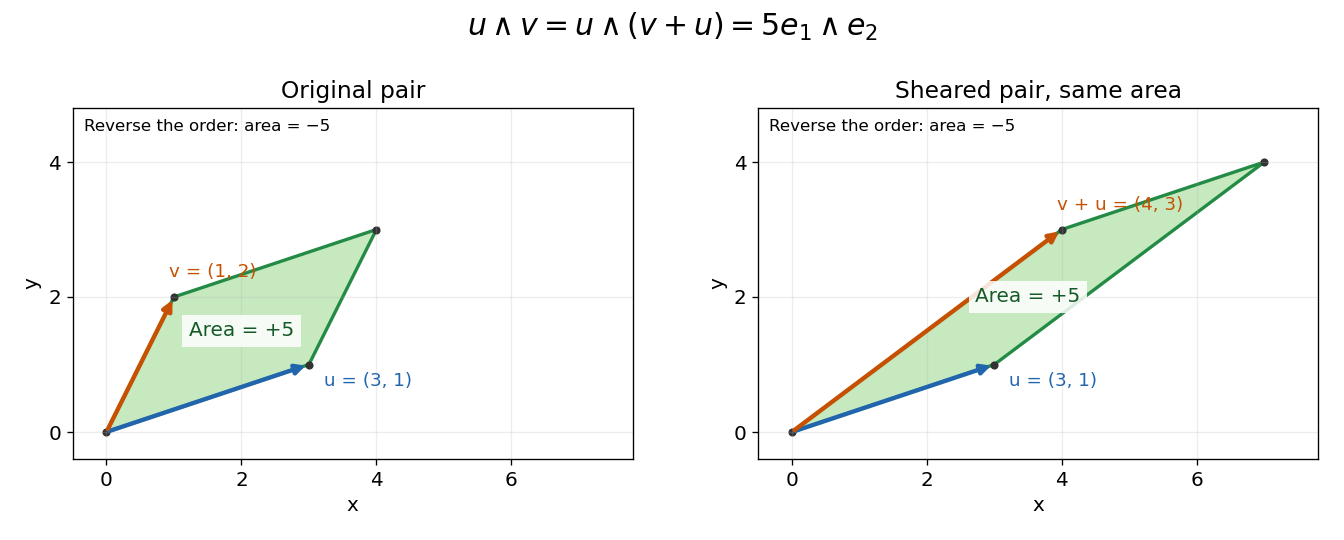
A simple bivector can be expressed as one exterior product of two vectors. Changing the pair need not change its area element: for every scalar , by bilinearity and . This operation shears the represented parallelogram while preserving its oriented area.
Every bivector in a real vector space of dimension at most three is simple, but this fails in dimension four. For an ordered basis , considerThe two components describe independent coordinate planes. Their square iswhereas because the factors repeat. Thus this cannot be one simple bivector. Over the real numbers in dimension four, the converse also holds: a nonzero bivector with is simple. The nonzero factor two is important; that criterion cannot be applied unchanged in characteristic two.
The exterior product, also called the wedge product, combines oriented elements through the multiplicationFor two vectors, it is bilinear and alternating:These rules imply . They distinguish the exterior product from both the symmetric dot product and the unconstrained tensor product.[ref]
Linear Algebra Done Right by Sheldon Axler (4th edition). §9B, Definition 9.27 and Theorem 9.30, printed pp. 347–348: alternation and the sign of a swap
In an oriented orthonormal plane, write and . Expanding in its standard basis givesThe determinant is the signed area of the parallelogram formed by the two inputs. Its absolute value is the ordinary area. Reversing the input order reverses the sign; parallel inputs produce zero.
For the original example and ,Replacing by changes the shape but preserves the product: . Both parallelograms have the same oriented area element. If , the exterior product is zero, since .
The same rule adds directions in higher dimensions. With and the three-dimensional inputs under bivector,Its coefficient is the oriented volume of the three-dimensional parallelepiped. Repeating or linearly depending on earlier inputs collapses the volume, giving zero.
For homogeneous elements of a graded algebra of degrees , the general commutation rule isSwapping a bivector with another bivector therefore produces a positive sign, since . It is the number of individual vector swaps that controls the sign, not a rule that every pair of objects must anticommute.
For a polynomial ring , a degree- polynomial polyvector field is an element of . Its product is the exterior product. Together with the Schouten-Nijenhuis bracket these spaces form a Gerstenhaber algebra.
The left Schouten-Nijenhuis bracket on polynomial polyvector fields is the degree-minus-one Gerstenhaber bracket extending the commutator of derivations and by graded antisymmetry and the left graded Leibniz rule. For , this convention gives and . A right insertion convention reverses the degree-two-with-function formula.
A Grassmann algebra is an exterior algebra regarded as an algebra of anticommuting generators. Its odd elements satisfy .
The parity grading records whether a homogeneous element has even or odd Grassmann degree. Homogeneous elements obey . An odd differential uses the graded Leibniz rule; this is the sign bookkeeping behind left-acting BRST differential calculations.
A Grassmann derivative is an odd differentiation operation on a Grassmann algebra. A left Grassmann derivative obeys for homogeneous . Right derivatives use the corresponding right-sided product rule. Their placement must be fixed when differentiating fermionic sources in a generating functional, since commuting ordinary derivatives would lose fermionic signs.
Left differentiation with respect to an odd Grassmann variable is the odd linear operation , with zero derivative on every other generator. For a homogeneous element of parity , it obeys the graded product ruleFor independent odd generators, . This sign comes from moving the derivative through the first odd factor in the Grassmann algebra. It fixes chirality in the chiral-superfield component expansion; an ordinary commuting-variable product rule would give the wrong sign.
A Grassmann variable is an odd generator of a Grassmann algebra. In characteristic zero it obeys , so functions of finitely many Grassmann variables have finite Taylor expansions.
The th exterior power is the quotient vector space of the tensor power that makes every elementary tensor with two equal factors zero. More precisely, take the quotient vector space by the linear span of all such tensors. Its elementary products turn alternating multilinear maps into linear maps: every alternating -linear map on factors uniquely through .[ref]
Exterior Powers by Keith Conrad. Exterior Powers, §3, Definition 3.1 and Theorem 3.3: quotient construction and universal property
If is an ordered basis, the increasing productsform a basis of . There is one for each -element choice of basis directions, soRepeated directions vanish; products with a different order can be sorted using their sign. Coordinate determinants distinguish the remaining increasing products, establishing linear independence.[ref]
Exterior Powers by Keith Conrad. Exterior Powers, §4, Theorem 4.2: basis and rank of an exterior power
For , a basis of is . This explains the three bivector components in the worked example. The top exterior power has one basis element, , while : four independent directions cannot fit into that vector space. By convention is the scalar field, even when has dimension zero.
The exterior square of a direct sum splits into wedges of two vectors from , two from , or one from each. The mixed map sends to . A combined basis proves it is an isomorphism, and the exterior-power Lie algebra representation proves equivariance for modules. No division by is used.
For a symplectic vector space , contraction is the map defined by . It is equivariant for the symplectic Lie algebra. In dimension four its five-dimensional kernel is irreducible of highest weight , while the invariant inverse-form bivector spans a complementary trivial Lie algebra representation.
The primitive exterior square of a symplectic vector space is the kernel of its symplectic contraction of an exterior square. In dimension four, the invariant inverse-form bivector has nonzero wedge square. Choose ; the symmetric bilinear form is nondegenerate on . The primitive subspace is , and therefore inherits a nondegenerate form of dimension five. The symplectic Lie algebra acts on it by infinitesimal orthogonal transformations.
A rank- tensor on a vector space is a multilinear map of vector or covector arguments, equivalently an element of an -fold tensor product. Its components transform by one copy of the change-of-basis matrix for each index.
A contravariant vector has coordinate components obeying the displayed transformation law. A tangent vector to a parametrized curve provides the basic example: the chain rule transforms in precisely this way. Pairing it with a covector produces a coordinate-independent scalar. Conversely, if an array pairs invariantly with every contravariant vector, coefficient comparison forces the covector transformation law for that array.
An equality of tensors of the same type. Its tensor component transformation law makes the equality independent of the chosen coordinates. The status of each tensor as dynamical or a fixed background structure is additional information.
A Cartesian tensor invariant under all proper rotations fixing a unit vector is axisymmetric. Without assuming a symmetric tensor, its general second-order form is the displayed combination of the transverse identity, axial projector and axial antisymmetric part. For this isIndeed, imposing for a quarter-turn about forces , and all mixed axial-transverse entries to vanish. The planar block is a linear combination of the identity and the planar rotation generator, so it commutes with every rotation about the axis. Thus quarter-turn invariance already suffices for a second-order tensor. A symmetric tensor has , recovering the axisymmetric symmetric rank-two tensor form. The antisymmetric term is allowed because only proper rotations about the fixed axis are imposed.
A contravariant tensor transforms with one forward coordinate Jacobian for each upper index. A Lorentz four-vector is the rank-one example; the electromagnetic field tensor with two upper indices is a rank-two example. Lower-index covariant tensors transform with inverse Jacobians, and full contractions yield scalars. Index position specifies a transformation law rather than implying that the numerical components are invariant.
Antisymmetrization over selected tensor indices averages their permutations with the sign of a permutation. Square brackets denote it, for example . It projects onto the alternating part. Antisymmetrized second derivatives of a scalar vanish for a torsion-free connection, but antisymmetrized later derivatives act on a tensor and can produce curvature.
Symmetrization over selected tensor indices is the average over all permutations, with every sign positive. Parentheses denote this operation, for example . It is a projection onto the symmetric part and commutes with a covariant derivative acting on indices outside the parentheses.
A Cartesian second-rank tensor invariant under every proper rotation preserving an unoriented axis has this form. Rotations about the axis give a planar block and eliminate mixed axial-planar entries. A half-turn about a transverse axis reverses , forcing . If only rotations about the oriented axis are imposed, this planar antisymmetric term may survive.
The six-element dihedral group generated by the displayed rotations already forces every invariant second-rank tensor to have the same form as an axially invariant second-rank tensor. The axial threefold rotation eliminates mixed entries and leaves only a planar scalar plus a planar antisymmetric part; the transverse half-turn eliminates the latter. No smaller finite subgroup suffices: cyclic rotation groups retain an axial antisymmetric tensor, while a four-element noncyclic rotation group retains arbitrary diagonal tensors along its three mutually perpendicular half-turn axes.
A Cartesian tensor has components in each orthonormal basis of a Euclidean space, related by the displayed rule under an orthogonal component change . Each index contributes one transformation matrix. The Euclidean inner product identifies upper and lower indices in orthonormal coordinates, so the distinction between covariant and contravariant components does not change this rule. An isotropic tensor has unchanged components under all proper rotations; requiring invariance under reflections as well excludes the ordinary odd-parity cases. A Cartesian second-rank tensor is the matrix case, with transformation .
A Cartesian second-rank tensor has component matrix in each orthonormal basis, with transformation under an orthogonal component change . Both indices transform; this is why assigning arbitrary matrices independently in different bases does not define a tensor. The determinant, trace, and Frobenius inner product with another such tensor are unchanged by these basis transformations.
For a real symmetric Cartesian second-rank tensor and a nonzero vector , require and symmetric and traceless with . Put , , , and . The unique decomposition isThe orthogonal projection isolates the plane perpendicular to . Splitting on both sides of gives its longitudinal, mixed and transverse blocks, proving reconstruction. The transverse trace fixes , the longitudinal component fixes , and the mixed block fixes , proving uniqueness. The remaining transverse block has two degrees of freedom. Together carry components, the number in a symmetric three-by-three matrix.
For a differentiable three-dimensional vector field , split its gradient tensor into symmetric and antisymmetric parts. The symmetric part is . Contracting the antisymmetric part with the Levi-Civita symbol gives the axial vector , proving the decomposition. If , the divergence of the symmetric part is . This lets a vector Laplacian be converted into a boundary integral of a symmetric tensor by the divergence theorem.
A Cartesian second-rank tensor in three dimensions invariant under quarter-turn rotations about all three coordinate axes is a scalar multiple of the identity matrix. Squaring the quarter-turns gives coordinate half-turns; invariance under these forces every off-diagonal component to vanish. The quarter-turns then equate the three diagonal components. This conclusion does not require the original tensor to be symmetric.
Every three-dimensional Cartesian second-rank tensor splits into scalar, symmetric-traceless, and antisymmetric parts. Their coefficients are , , and . The epsilon contraction identity reconstructs the antisymmetric part and proves uniqueness. Under proper rotations behaves as a vector, but under reflections it is an axial vector.
For a constant orthogonal Cartesian coordinate change , a Cartesian second-rank tensor obeys . The chain rule gives . Consequently , the transformation rule for a vector. Under non-Cartesian position-dependent coordinate changes, partial derivatives must be replaced by the appropriate covariant derivative.
A Cartesian second-rank tensor invariant under all rotations about an oriented unit axis has the displayed form. A half-turn about the axis eliminates the mixed axial-transverse entries, and a quarter-turn makes the transverse block a scalar matrix plus an antisymmetric planar rotation generator. Conversely both transverse terms commute with every rotation about the axis. The antisymmetric term is allowed unless symmetry or an additional axis-reversing rotation is imposed. This differs from an axially invariant second-rank tensor for an unoriented axis.
For a real conductivity tensor invariant under every rotation about a unit vector , the electric current density is . Its collinearity with a nonzero real electric field has three cases. Axial fields are always mapped to an axial current. Purely transverse fields give a collinear current exactly when , equivalently when this tensor is symmetric. Fields with nonzero axial and transverse parts require both and , making the tensor isotropic. The zero vector is included as a scalar multiple; requiring a nonzero current also requires the relevant scalar conductivity to be nonzero.
To prove necessity, take the dot product of with . If this gives ; the transverse and axial equations then respectively give and, when , . Reversing these steps proves sufficiency. Rotations about the axis alone permit ; symmetry under a transverse half-turn would eliminate this antisymmetric term.
A Cartesian second-rank tensor invariant under half-turns about all three coordinate axes is diagonal. Each half-turn has diagonal signs, and each off-diagonal entry changes sign under at least one of them. Invariance therefore kills all off-diagonal entries. It does not make the diagonal entries equal: that requires additional rotational invariance, as for an isotropic second-rank tensor.
A type- tensor identifies with an endomorphism of a finite-dimensional vector space. Composing two such maps produces another type- tensor, because is a multilinear map. In output-first components the result is ; the contracted index implements composition, and a basis change conjugates the corresponding matrices.
Under an orthogonal coordinate transformation , a Cartesian pseudotensor has the usual tensor transformation law multiplied by . Thus proper rotation matrices act as on ordinary tensors, while an orientation-reversing change contributes an extra minus sign. Interpreted as a rank-three pseudotensor, the Levi-Civita symbol has the same numerical components in every orthonormal frame, because its ordinary three-index transformation already contributes a factor .
A symmetric tensor is unchanged by every permutation of its slots. A symmetric second-rank tensor is the rank-two case; symmetry for higher rank requires invariance under every such slot exchange.
For with , the symmetric tensor has principal axeswith eigenvalues , respectively. This follows directly from the outer product: , while it annihilates vectors perpendicular to . The orthogonal matrix with rows gives .
If depend on position, this is a pointwise eigenframe, not necessarily one fixed Cartesian change of axes throughout space. For , the displayed tensor vanishes and every orthonormal basis is a principal basis. Subtracting a scalar multiple of the identity leaves its eigenvectors unchanged and shifts every eigenvalue by the same amount; this is a simple case of coaxial symmetric tensors.
A symmetric tensor invariant under rotations about a fixed nonzero vector has the form . Choose the third coordinate axis parallel to : rotation by a half-turn makes the mixed axial-transverse entries vanish, and all transverse rotations make the transverse block a scalar multiple of the identity. Its two transverse eigenvalues are and its axial eigenvalue is . The trace and the quadratic contraction determine these two coefficients. Full isotropy holds exactly when .
For and , this surface integral is finite: near its integrand has size and the two-dimensional area element supplies one further power of distance. Rotational covariance and symmetry make it an axisymmetric symmetric rank-two tensor. Put . Polar integration about the axis gives and . Solving and gives and . Thus the weighted chord tensor becomes an isotropic tensor exactly at .
Over a field of characteristic zero, degree- symmetric tensors are spanned by pure powers . Inclusion-exclusion expands into the sum of all permutation orderings of . Every surviving term uses each of the labels once. This converts an invariant-tensor spanning problem into pure tensor powers.
A second-rank tensor is symmetric when . Every second-rank tensor has the unique decompositioninto symmetric and antisymmetric parts.
Suppose an array is specified in each right-handed orthonormal basis. If transforms as a vector for every vector , then is a second-order Cartesian tensor under those basis changes. Indeed , imply for every , hence . The condition on every test vector is essential; one contraction is insufficient.
If contraction of an array with every symmetric second-rank tensor is a vector in every orthonormal frame, its part symmetric in the contracted slots obeys the rank-three tensor transformation law. The difference between its proposed transformation and actual components is symmetric and contracts to zero against every symmetric matrix, so it vanishes. The antisymmetric part is invisible, by the blindness of symmetric contraction tests to antisymmetric arrays, and need not be tensorial.
If an array specified in each orthonormal basis has invariant Frobenius inner product with every Cartesian second-rank tensor, it transforms as such a tensor. For a component change , invariance says for every matrix . Nondegeneracy of the Frobenius inner product forces the difference to vanish. Testing every tensor, rather than a single selected tensor, is essential.
If an array is antisymmetric in every orthonormal basis and its contractions with every antisymmetric second-rank tensor are invariant scalars, it obeys the Cartesian second-rank tensor transformation law. The difference is antisymmetric and orthogonal to every antisymmetric test matrix. Choosing the test matrix equal to gives , hence . The Frobenius inner product is nondegenerate on the antisymmetric subspace.
The Frobenius inner product of a symmetric matrix and an antisymmetric matrix is zero. Thus invariant contractions of an array with all symmetric second-rank tensors test only its symmetric part; an arbitrary basis-dependent antisymmetric part is invisible. A nonzero antisymmetric matrix in one basis and the zero matrix in another passes all such tests with scalar zero but is not a Cartesian second-rank tensor.
A second-rank Cartesian tensor is traceless when the contraction vanishes. For a symmetric second-rank tensor, this is equivalent to its eigenvalues summing to zero. The orientational nematic order parameter is both symmetric and traceless, excluding an isotropic scalar contribution.
For finite sets and a field , a three-variable tensor has slice rank at most when it is a sum of terms, each of which separates one variable from the other two. Such terms have one of the formsThe slice rank is the least possible .
Articles were limited to the first 100 out of 162 total.
Articles by others on the same topic



Multilinear algebra is a branch of mathematics that extends linear algebra by dealing with multilinear functions, which are functions that are linear in each of several arguments. This area of study is essential for understanding vector spaces and can be thought of as a natural progression from linear algebra into more complex structures.