For the intended ideal Venturi effect, take steady flow, incompressible flow, negligible viscous losses, and the same height at the two stations shown. The Bernoulli equation along a streamline givesUsing water mass density ,Thus the outlet pressure is lower by . The increased kinetic energy per unit volume comes from the drop in pressure.
The source's assumption of laminar flow alone does not imply negligible viscosity or losses. The numerical result uses the usual lossless Bernoulli equation approximation, with the quoted speeds interpreted as representative streamline speeds. A real tube with significant viscous losses requires additional data; in a uniform-velocity energy balance its pressure drop would include an extra positive loss term.
The principal moments of inertia are the eigenvalues of the symmetric inertia tensor. In units of , its characteristic determinant isTherefore the requested algebraic answer isAn orthonormal basis of principal axes is , , and ; the last two span the degenerate eigenspace and may be replaced by any orthonormal basis of it.
There is a physical inconsistency in calling the supplied matrix a rigid body's inertia tensor. The moment-of-inertia triangle inequalities require each principal moment to be no greater than the sum of the other two. Here . In principal coordinates, cannot be negative for a nonnegative mass distribution. Thus the eigenvalue calculation is well defined, but no ordinary rigid mass distribution realizes this tensor. The positive second-moment matrix test for an inertia tensor makes the same obstruction explicit.
Use local east, north and upward unit vectors at the equator, with Earth's rotation . The parcel starts at rest relative to the ground. To first order in , its unperturbed vertical velocity is and its fall time from height isThe Coriolis acceleration is . Since north crossed with downward points west, its negative points east:Integrating with gives the equatorial Coriolis deflection in free fall,For , and , andThis neglects air resistance, variation of over the fall, and terms of order . The measured local already includes the background centrifugal correction. “Stationary” is interpreted as hovering above a fixed ground location, not being stationary in an inertial frame.
Under a uniform compressive pressure , each normal stress is . The isotropic Hooke's law gives each longitudinal strain asThus . By the definition of bulk modulus, , so the isotropic elastic modulus relation isPositive finite Young's modulus and bulk modulus requireThe incompressible limit is with at finite . If positivity of the shear modulus is also imposed, the full stable isotropic range is . Negative Poisson's ratio is not ruled out; the displayed bulk-modulus relation alone supplies the upper bound.
For the intended reversible adiabatic process, an ideal gas obeys . A monatomic gas has heat capacity ratio , soThe required extra assumption is that “adiabatic” denotes the usual quasistatic isentropic process. Absence of heat transfer alone would not fix the final temperature: an ideal gas undergoing free expansion into vacuum is also adiabatic but leaves its temperature unchanged.
- Kepler's first law: a bound planetary orbit is an ellipse with the central attracting body at one focus.
- Kepler's second law: the line from that focus to the planet sweeps equal areas in equal times, equivalent to constant areal velocity.
- Kepler's third law: the squared orbital period is proportional to the cube of the semi-major axis, when the orbiting mass is negligible.
The first law includes a circular Kepler orbit as a special case. The third-law constant is the same for bodies orbiting the same dominant mass.
Choose zero gravitational potential energy at infinite separation. The spacecraft's conserved total orbital energy isAt periapsis and apoapsis, the radial velocity vanishes, so the velocity is perpendicular to the radius. The conserved angular momentum magnitude is thereforeThe angular momentum vector is normal to the fixed orbital plane. The respective units are joules and . These expressions use Newtonian gravity and the approximation .
Eliminate using the angular momentum expressions from part (b):HenceFor distinct turning radii, factor the difference of squares and cancel the common factor to obtainThe circular Kepler orbit case is recovered continuously by setting , giving . Combining this with the energy expression also gives for the transfer ellipse.
Use a Hohmann transfer orbit. At the initial radius , make a short prograde burn parallel to the existing velocity. The increased speed changes the circular Kepler orbit into an elliptic orbit whose periapsis is the burn point and whose apoapsis lies on the desired larger circle. Coast for half the transfer orbital period to apoapsis.
At that point the transfer velocity is again tangent to the target circle, but its magnitude is smaller than the circular speed there. A second short prograde burn raises it to the required circular speed. Thus both burns increase the instantaneous speed and preserve its direction at the burn, even though the final circular speed is lower than the original one. During the coast the spacecraft loses kinetic energy while gaining gravitational potential energy.
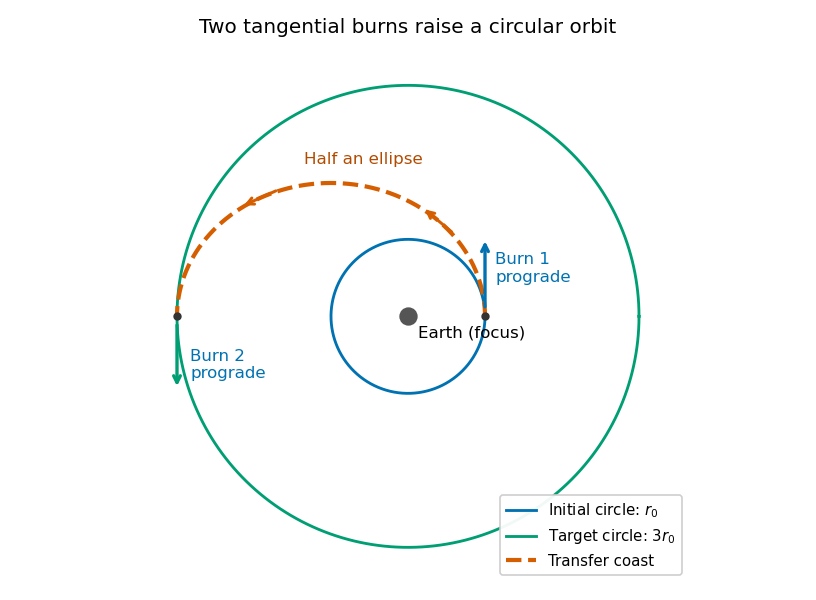
Original transfer-orbit construction for the later example with outer radius three times the inner radius; arrows show the two prograde burns
. Details. The figure illustrates for the subsequent parts, but the same construction works for any larger target radius. The impulsive approximation neglects the distance travelled during each burn and keeps both circles and the transfer ellipse coplanar.
The original circular Kepler orbit has . For the transfer ellipse, set , in part (c):The first required speed increase is . Under the question's negligible-mass-change fuel model, fuel use is proportional to the magnitude of the impulse. Since the full fuel supply corresponds to ,This is the stated “about a quarter” of the original fuel supply. It is an instance of the Hohmann transfer impulse fractions; no variable-mass rocket model is required under the stipulated assumptions.
At transfer apoapsis, angular momentum conservation givesThe desired circular Kepler orbit has speed . Thusof the original fuel supply is used in the second burn. This is about of the fuel remaining after the first burn. The total transfer consumes of the original supply, leaving about . The two positive impulse magnitudes are added for the fuel budget, even though their directions at opposite ends of the orbit differ.
A normal mode of a linearized mechanical system is a motion in which every generalized displacement oscillates at a single common angular frequency, with fixed relative amplitudes and phases. In coordinates , an undamped oscillatory mode may be writtenwhere the amplitude vector is fixed; negative components describe relative phase . An arbitrary small motion is a linear combination of the normal modes when the mode vectors form a complete basis.
Let be each sphere's moment of inertia about the fibre, and let be the common fibre filament torsional stiffness, so a length exerts restoring torque . The single-sphere torsion pendulum obeysFor the two coupled torsional pendulums, the upper fibre has twist and the joining fibre has relative twist . The joining fibre exerts equal and opposite torques on the two spheres:Using the measured givesThe fibre's own rotational inertia and damping are neglected, so its twists supply elastic torques without additional dynamic coordinates.
Set and use normal mode amplitudes , with real physical displacements obtained at the end. In units of , the stiffness matrix isWriting , the eigenvalue condition isThereforeFor finite positive fibre lengths both eigenvalues are positive. The corresponding amplitude ratio isThe lower normal mode has the spheres twisting in the same sense, and the higher one has opposite signs of angular displacement.
In terms of ,Both curves decrease monotonically: with , , while . The limits, including their leading approach, areThus the limiting squared angular frequencies are and infinity for short joining fibre, and zero and for very long joining fibre. For orientation, at the values are . The high-frequency curve stays above and the low-frequency curve below .
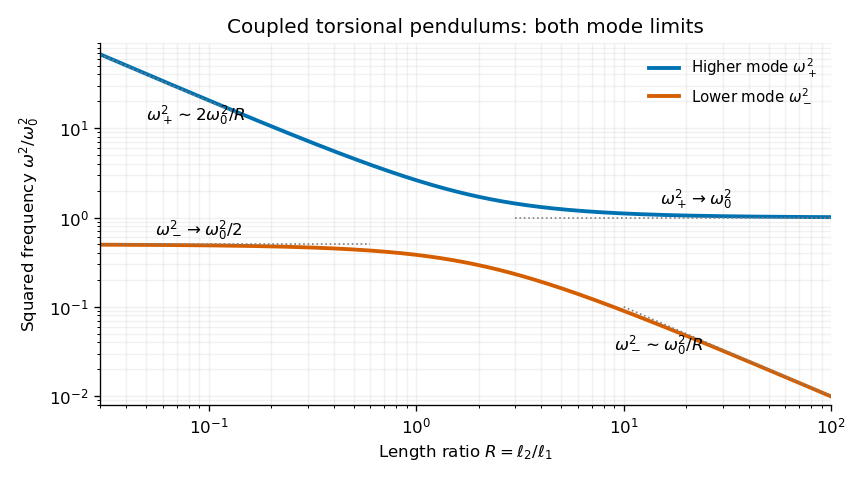
Calculated squared normal-mode frequencies versus fibre-length ratio; both axes are logarithmic to show all four asymptotic limits
. Details. As , the short joining fibre is very stiff and the lower normal mode has . The spheres therefore behave as one torsional load with combined moment of inertia , suspended by the upper fibre of torsion constant . Its angular frequency satisfiesThe high-frequency opposite-twist mode costs increasingly large elastic energy and moves to arbitrarily high frequency in the massless-fibre model.
As , the joining fibre is very compliant. In the higher normal mode the lower sphere scarcely moves: the amplitude ratio tends to . The upper sphere approaches the original single torsion pendulum, givingThe other mode is then a slow twist of the almost freely suspended lower sphere. These interpretations assume the formal limits do not invalidate the thin massless-fibre approximation.
In a linear isotropic dielectric of relative permittivity , the electric displacement field and electric field satisfyHere denotes the free charge density called in the question. For spatially constant , these also give . Equivalently, and . The electric displacement field has units and the electric field has units .
The local equations determine the fields once their geometry and boundary conditions are specified; a density value alone does not determine a unique vector field without that information.
Let point from medium 1 to medium 2. Integrate over a thin Gaussian pillbox crossing the interface. As its thickness tends to zero, the side contribution vanishes and any free surface charge density givesApply to a thin rectangular loop spanning the same interface. Its short sides vanish in the limit, so the tangential electric field is continuous:For a clean dielectric interface with no free surface charge density, these electrostatic interface boundary conditions reduce to and . In particular ; the normal electric field itself need not be continuous. Bound polarization charge is already incorporated into .
Consider a long uniform length of a coaxial cylindrical capacitor, with permittivity and inner-cylinder charge per unit length . A cylindrical Gaussian surface givesThe electric potential difference isThus its capacitance per unit length is .
In the partially filled coaxial capacitor, the vacuum section of length and the dielectric section of length share the same two conductors and hence the same electric potential difference. They are electrically in parallel, not in series. The radial electric field is tangent to the axial dielectric interface, consistent with the boundary condition in part (b). Adding their charges givesThis is the leading long-capacitor expression, neglecting end and interface-fringing corrections. The stated supports a long filled section; treating the other section as uniform also requires it to be well away from the end regions when those corrections matter.
Let increasing overlap mean that the dielectric moves farther into the capacitor. Its capacitance derivative isAt fixed electric potential difference , the capacitor energy rises by , but the voltage source supplies electrical work . The difference is available as mechanical work :The dielectric insertion force at fixed voltage is thereforeFor the usual , it pulls the dielectric inward, increasing ; its magnitude is constant within the long-overlap approximation. In the original longitudinal diagram this is to the left. The units are newtons, since is energy per length. Differentiating the field energy alone with a minus sign at fixed would miss the source contribution; the correct fixed-voltage capacitor energy balance is essential.
Use for the magnitude of charge on either plate. The fully filled capacitance is , while the initial value is given in part (c). At the same fixed electric potential difference,For and positive , this is an increase in the positive plate's electric charge magnitude, supplied by the voltage source; the negative plate acquires an equal opposite change. The net free charge of the two-plate capacitor remains zero. Thus “charge on the capacitor” has its usual circuit meaning, not the algebraic sum over both plates.
The electric field is approximately radial in the long interior, but near an electrode end its lines spread into a fringing field of a capacitor. The electric field magnitude falls on moving outward through that end region. The dielectric's induced electric dipoles experience a net force toward the stronger field, pulling the material into the capacitor. For a weakly perturbing polarizable element this is expressed by , with positive electric polarizability .
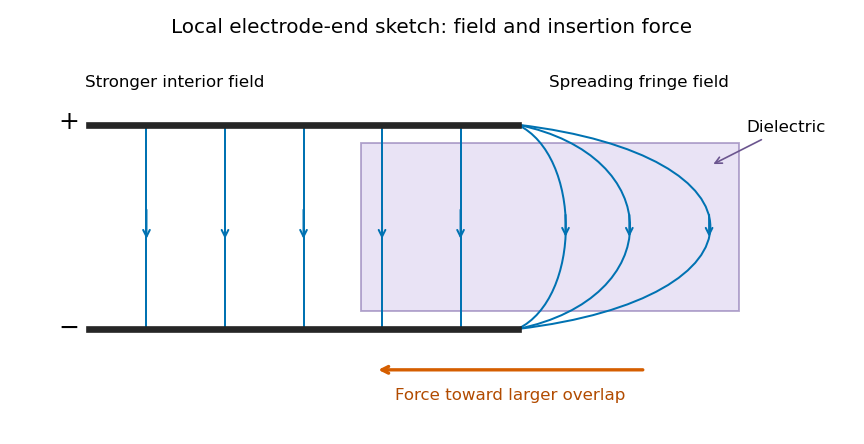
Local schematic of field lines at an electrode end and dielectric insertion; this illustrates the fringe rather than the full coaxial geometry
. Details. In the sketch the field lines run from the positive electrode to the negative one, curving outward near their ends. The material is attracted toward the interior where the field is stronger. A perfectly uniform interior field by itself would not give a longitudinal dipole-gradient force; the end region is essential to the local explanation. Neglecting its small contribution to the total capacitance does not justify omitting the finite insertion force that it transmits. The energy argument of part (d) gives that force without needing the detailed fringe solution.
For a steady filamentary electric current in vacuum, the Biot-Savart law isThe line element points with conventional electric current, and the cross product fixes the magnetic flux density direction by the right-hand rule.
As an application, an infinitely long straight wire has circular symmetry about its axis. At perpendicular distance ,Its direction follows the right-hand rule. The following part applies the same law to a circular current loop.
Parameterize the loop by and choose positive electric current counterclockwise as seen from . At the observation point ,The numerator of the Biot-Savart law isThe distance is constant round the loop. The transverse terms integrate to zero, while the axial term integrates to . HenceFor use below, define the undisturbed magnetic field intensity . This distinguishes the applied field from the internal field after adding the magnetic sample.
The printed formula has a physical problem for the specified geometry. Let be the linear magnetic susceptibility, where is the source's relative magnetic permeability. The constitutive equation is , not in general .
For a small uniformly magnetized ellipsoid with its principal axis along the applied field, include its demagnetizing field through the SI demagnetizing factor :Solving givesA slender rod aligned along the field has as its aspect ratio grows. Its ideal slender-rod limit at fixed is thereforeprovided . A finite cylinder generally has nonuniform magnetization, so an ellipsoidal shape factor is an approximation, and its aspect ratio is needed for a more precise correction. Small sample length compared with the field-variation scale makes approximately uniform across it; that condition does not set the demagnetizing factor to one.
The source's displayed instead follows from , the thin-plate limit with field normal to the plate. It can also be obtained by imposing , but that identification is not justified for a thin rod parallel to the field. Consequently the requested extra cannot honestly be derived from the stated rod geometry. The next part gives both the shape-consistent result and the force conditional on using the printed magnetisation.
In the small-body approximation, write , with . The induced magnetic dipole moment is . Its effective interaction potential energy at fixed source current isThe factor accounts for inducing the moment: differentiating as if the moment were permanent would double the force. Equivalently, the instantaneous dipole force is . Thus the force on a small linearly magnetizable body isFrom part (b), . HenceFor the ideal slender rod, . If the source's printed magnetisation is imposed instead, its corresponding conditional answer isFor and , both expressions point toward the loop, where the applied magnetic field is stronger; for the direction reverses toward the loop plane. A material with diamagnetism, , reverses this attraction. The force is in newtons, since a magnetic dipole moment times a field gradient has units . Both formulas assume linear response, negligible saturation and approximately uniform applied field across the sample.
For a linear induced response, reversing reverses and the sample magnetization, while also reversing the field gradient. Their product in therefore keeps the same sign and magnitude:This is also explicit in the dependence in part (d), for both the shape-consistent and printed alternatives. The conclusion assumes no independent permanent moment, remanence or hysteresis; those would require a different response model.
Changing shape changes the demagnetizing field, and hence the magnetization induced by the same applied magnetic field intensity. For a small linear sample in the ellipsoid approximation, the force magnitude scales withFor , a more elongated body aligned with the field has smaller and a stronger response. A sphere has , giving ; a very thin plate with field normal to it has , giving . Thus an axially slender rod generally experiences a stronger attraction than a sphere or a transverse thin plate of the same material and volume, within the linear uniform-applied-field approximation.
The shape response is precisely why the factor in part (c) cannot apply universally to every small magnetic body. Orientation also matters through the appropriate principal demagnetizing factor; for general nonellipsoidal bodies the internal field is not uniform and a single scalar correction need not be exact.
This is the one-mole, or equivalently molar volume, form of the Van der Waals equation, an approximate equation of state for a real gas:Here is the gas pressure, its absolute temperature, the molar gas constant, and the volume occupied by one mole. If denotes molar volume explicitly, its units are .
The positive parameter represents excluded volume arising from the finite size and short-range repulsion of the molecules. The volume available for translational motion is reduced from to . This is an effective excluded volume, not simply the sum of the molecules' geometric volumes. Its molar units are .
The positive parameter measures intermolecular attraction in a mean-field approximation. Attractions reduce the force exerted on the walls, lowering the measured pressure by relative to the repulsion-only expression. Thus is the pressure corrected for this attraction. The squared inverse-volume dependence reflects a contribution proportional to the square of the molecular number density. The molar units of are .
For an arbitrary amount measured in moles, with total container volume , the corresponding formula isAt low density, when and , it reduces to the ideal gas law. The model captures qualitative attraction, repulsion and liquid-gas behavior, but does not supply an exact equation of state for every material.
The Third law of thermodynamics, in its perfect-crystal form, states that the entropy of a pure, perfectly ordered crystal with a unique ground state tends to zero as . Its more general entropy-difference formulation says that the entropy difference between equilibrium states related by a finite change of a regular external control parameter tends to zero at absolute zero:The common limiting entropy is independent of . Ground-state degeneracy or frozen disorder can produce residual entropy, so zero entropy is not an unconditional assertion about every sample.
In the usual regular thermodynamic setting, absolute zero cannot be attained from positive temperature by a finite sequence of cooling operations with finite resources. An entropy-temperature plot shows why a finite reversible adiabatic step cannot reach the common zero-temperature endpoint from a state with positive entropy above that endpoint: an isentropic process follows a horizontal line, while all the regular entropy curves meet only at .
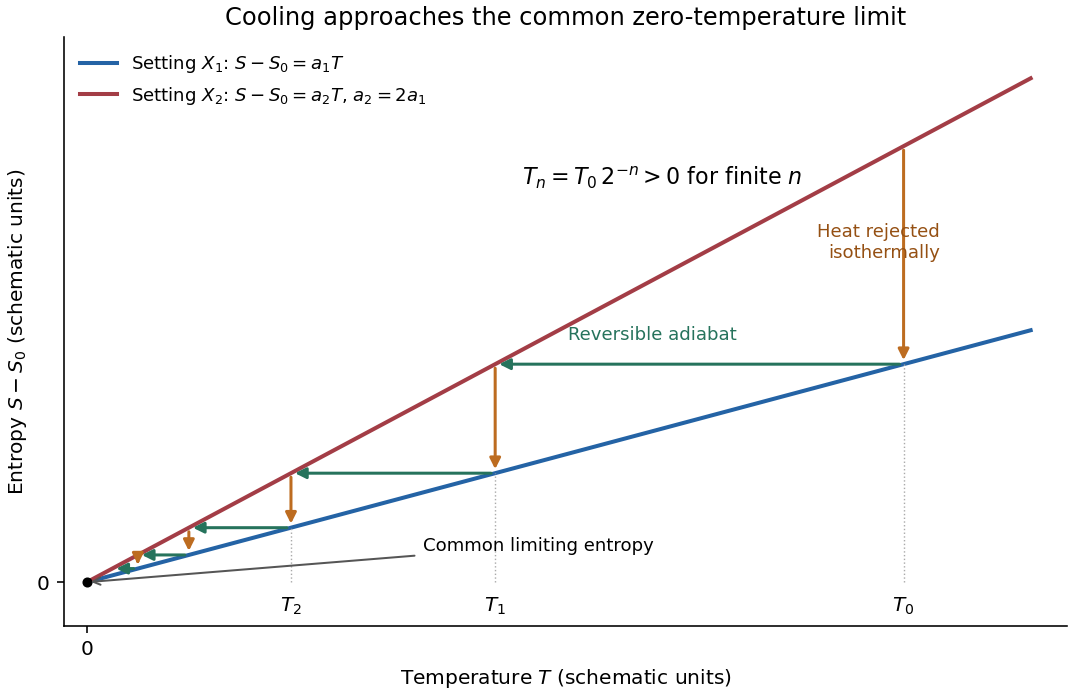
The figure illustrates this with two possible settings having and , where . First change the setting isothermally from the upper to the lower curve, rejecting heat; then change it reversibly and adiabatically back to the upper curve. Entropy conservation on the latter step givesfor every finite . The staircase approaches the origin but reaches it only after infinitely many such stages. Irreversibility generates entropy and cannot improve on the reversible endpoint.
This is a thermodynamic illustration of unattainability of absolute zero, not a claim that every cooling apparatus has this particular linear entropy law. Its conclusion presumes regular equilibrium states and bounded control parameters; dynamical statements about finite cooling time additionally require physical assumptions about the available interactions and cooling rates.
Assume a hollow, perfectly conducting rectangular electromagnetic waveguide filled with air approximated by vacuum. Let its wider side be and its narrower side . The longitudinal propagation constant of a mode isso the waveguide cutoff frequency isFor a mode with transverse electric polarization, one of may vanish, but they cannot both vanish. For a mode with transverse magnetic polarization, both must be positive. A single hollow conducting guide has no transverse electromagnetic mode with zero cutoff.
The lowest cutoff therefore belongs to the mode, varying across the wider side:Strictly, a traveling mode transporting energy down the guide requires . At exactly , and the axial group velocity vanishes. Below cutoff the field is evanescent. A different dielectric filling would replace by the wave speed in that material.
For a fixed magnetic dipole moment in an externally imposed uniform magnetic field, the torque is . Its component in the direction of increasing is . Since , integration giveswhere the arbitrary additive constant has been chosen so that at .
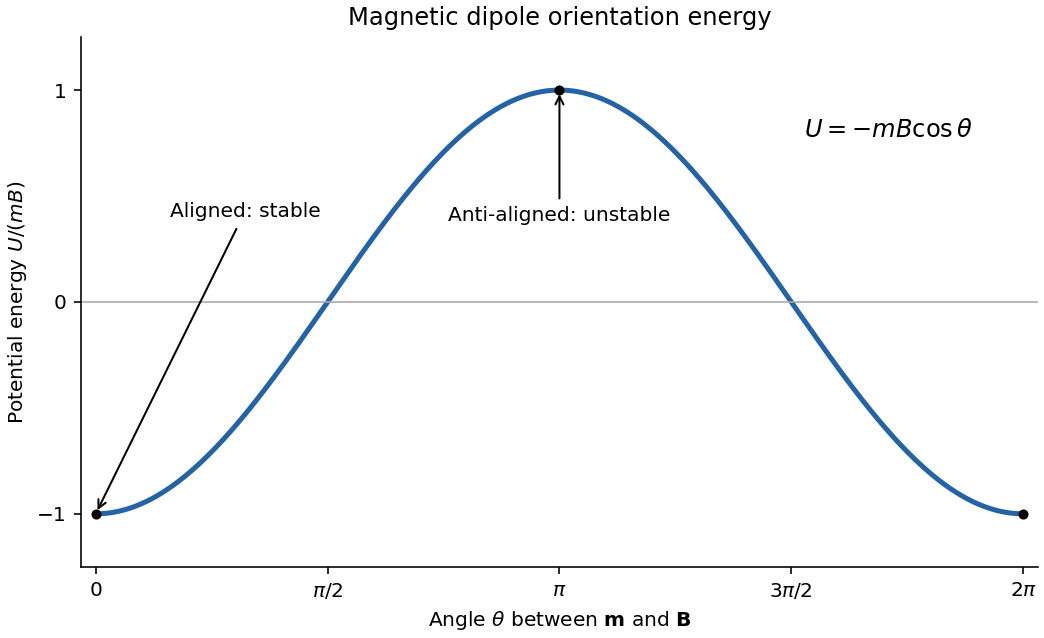
The aligned orientation has the minimum and is stable against small rotations; the anti-aligned orientation has the maximum and is unstable. The graph repeats every . Rotating quasistatically from alignment to anti-alignment requires external work .
For charge sharing between distant connected spheres, use the standard approximation that the spheres are sufficiently far apart for mutual electrostatic effects to be negligible, and that the wire adds negligible capacitance. The capacitance of an isolated conducting sphere is . ThusThe initial charges are . Connecting the spheres allows charge to flow until their potentials are equal. Charge conservation givesThe initial and final electrostatic energies are and . Their difference becomes Joule heating in the resistive wire:Numerically,The resistance determines how fast this happens, not the final energy difference. Sufficient damping suppresses sustained charge-current oscillations; the calculation also neglects energy radiated away. At finite sphere separation the capacitance matrix would be needed, and the radii and initial potentials alone would not specify an exact correction.
The examination requires three notes. All four options are developed here for completeness.
For torque-free precession of a symmetric top, take principal moments of inertia and , with no external torque. In an inertial frame moving with its centre of mass, its angular momentum is constant in an inertial frame, and its rotational kinetic energy is conserved.
In the principal body axes, Euler equations for a torque-free rigid body reduce toTherefore is constant andThus the transverse angular velocity rotates uniformly in the body frame; its signed rate reverses between oblate and prolate inertia tensors. This body-frame wobble rate should be distinguished from the space-frame precession of the symmetry axis.
Let be the body's symmetry axis. Sinceits angle to is constant, with , andHence the symmetry axis describes a cone about fixed at the space-frame precession rateThere is no nutation of this angle for torque-free motion of an exactly symmetric top. In the usual Euler angles, , so . Both rates describe the same motion in different axes. A freely tossed axisymmetric disc illustrates the effect; a top supported at a point under gravity is a different, externally torqued problem.
Lagrangian mechanics expresses dynamics through generalized coordinates that respect the constraints. For a system with conservative, velocity-independent forces and standard kinetic energy, the Lagrangian is . Its equations follow from the principle of stationary action:for variations that vanish at the endpoints. Varying the integral and integrating the term by parts givesIndependent variations therefore yield the Euler-Lagrange equations:Additional nonconservative generalized forces appear on the right-hand side as . The action is stationary, not necessarily a minimum. For ideal holonomic constraints, using suitable generalized coordinates removes the need to solve explicitly for constraint forces.
The conjugate momentum is . If a coordinate is cyclic, and its conjugate momentum is conserved. If has no explicit time dependence, the energy functionis conserved. It equals for the usual quadratic kinetic energy with time-independent geometry, but that identification is not universal for every Lagrangian or constraint.
For example, a simple pendulum with angle , length and bob mass hasThe tension does no virtual work in the allowed angular displacement and never needs to be calculated to obtain the angular equation. The method scales naturally to coupled systems and coordinates with complicated geometry.
For a slender elastic beam, the Euler-Bernoulli beam equation assumes small strain, small deflection slopes and cross-sections that remain plane and normal to the deflected centreline. A fibre at signed distance from the neutral axis has longitudinal strain , where is the centreline curvature. Hooke's law gives , with Young's modulus .
Choose the internal bending-moment sign so that . ThenHere is the second moment of area, with units , not the mass moment of inertia of a rotating body. For a uniform material under pure bending, zero axial resultant places the neutral axis through the section's centroid.
For small slopes, . Combining the moment-curvature relation with transverse force and moment balance gives, with a consistent load sign convention,For constant stiffness this becomes . The bending stiffness has units . Boundary conditions specify displacement and slope at a clamped end, or bending moment and shear force at a free end.
For a cantilever of length carrying a transverse end load , take deflection positive towards the load. The moment magnitude is , and integration with givesThe free-end moment vanishes and the tip shear supplies the applied load. For a rectangular section of width and bending thickness , , so increasing thickness strongly increases bending resistance. The model ceases to be reliable for large deflections, plastic strains or short thick beams where shear deformation matters.
The Magnus effect is the transverse force produced when a spinning body moves relative to a fluid. Rotation changes the flow and circulation around the body; the resulting asymmetric pressure and wake deflect the fluid, with the opposite transverse force on the body. Examples include the curved flight of spinning balls and the lift of rotating-cylinder sails.
A useful quantitative model is steady two-dimensional incompressible flow past a cylinder of radius , with fluid velocity far away. Let circulation be positive anticlockwise as viewed from . The potential-flow velocity at the cylinder surface isThe Bernoulli equation outside the boundary layer givesIntegrating the pressure force around the cylinder, per unit span, yieldsThus the Kutta–Joukowski theorem givesThe sign here refers to the fluid velocity relative to the cylinder. For a body moving through otherwise stationary fluid, that relative fluid velocity points opposite to the body's translational velocity.
Real viscosity and the no-slip boundary condition transmit the surface rotation to the fluid and help set the circulation and separation pattern. Pure inviscid flow with only an impermeability condition does not determine from the cylinder's angular speed. Therefore the circulation must not be assigned a universal spin-rate formula without additional assumptions. The cylinder result illustrates the lift mechanism; quantitative forces on a finite spinning ball also depend on its geometry, Reynolds number, rotation rate, surface roughness and wake.
Electromagnetic waves drive mobile charges in a conducting medium. Their current changes both the phase and attenuation of the wave. A description in terms of a real, frequency-independent refractive index is therefore generally insufficient: the material response and the propagation constant are complex and frequency dependent.
Use phasors proportional to , with and for a passive medium. In a homogeneous, isotropic, linear material, let represent the permittivity associated with bound-charge electric polarization, the magnetic permeability and the mobile-charge conductivity. The macroscopic Maxwell equations giveFor a transverse plane wave, taking another curl yieldsThis division of the response avoids counting mobile Electrons both in and in . Define the complex refractive index . For a nonmagnetic medium, . Its real part determines the phase variation, while the positive optical extinction coefficient gives amplitude attenuation and intensity attenuation . The amplitude penetration length is
A simple microscopic explanation comes from the Drude model. Let Electrons of charge , mass and number density move against an effectively stationary positive background. Collisions relax their mean velocity at rate :ConsequentlyWith a vacuum-like bound-charge background, this givesIts imaginary part is positive for positive , consistent with dissipation under the chosen phasor convention. Real materials can require an effective Electron mass, a nontrivial bound-charge response, or additional absorption associated with the electronic band structure.
A plasma is a conducting ionized medium with mobile Electrons and ions, approximately neutral on large scales because of plasma screening. For the electron-frequency transverse waves considered here, the heavy ions can often be treated as stationary. In a dilute weakly collisional plasma, , soFor , is real in this collisionless model and the wave propagates. Its phase velocity is , while its group velocity is ; their product is . A phase crest exceeding does not imply superluminal information transport. For , the refractive-index square is negative andThe transmitted field is evanescent rather than a traveling bulk wave. A sufficiently thick collisionless plasma reflects such radiation without Ohmic absorption. Collisions make the response complex and permit absorption. This accounts for a plasma cutoff and, qualitatively, the reflection of some radio frequencies by ionized atmospheric layers. The simple model describes transverse waves; plasmas also support longitudinal collective modes.
In a metal, positive ions usually form a crystal lattice. Mobile conduction Electrons occupy states described by the electronic band structure and normally form a degenerate Fermi gas. The conduction-electron density is usually much higher than in a dilute gas plasma. Thus its plasma frequency is commonly in the optical or ultraviolet range, rather than the lower radio-frequency values possible in dilute plasmas. Electron scattering from the lattice, defects and other excitations gives a finite relaxation rate. The distinction is not that every plasma is collisionless and every metal collisional: the controlling ratio for either material is , together with its carrier density and bound-charge response.
At sufficiently low frequency, , the metal's conductivity is approximately real, . In a good conductor the conduction current dominates the displacement current, . The wave equation then givesFor example, a tangential electric field varies asThe current is therefore concentrated within a few skin depths of the surface: this is the skin effect. As frequency increases within this regime, . In a wire whose radius greatly exceeds , only a thin outer region carries appreciable alternating current, increasing the effective resistance. In a conducting shield, the same penetration suppresses the field transmitted through a sufficiently thick wall.
The Poynting theorem identifies the loss as Joule heating. The cycle-averaged heating density for a complex conductivity isThe wave impedance is . For incidence from vacuum at normal incidence, the electric reflection amplitude is , where . A good conductor has small and therefore strong reflection, while the part of the incident power entering it is dissipated over the skin depth.
At high enough frequency that , a metal's free-electron response also approaches the collisionless plasma form. The low-frequency formula must not simply be extrapolated into that regime. Real optical behavior additionally depends on the electronic band structure and transitions between bands. Both plasmas and metals are therefore described by the same electromagnetic response framework, but their relevant densities, scattering rates and frequency regimes differ.
The relation describes the slope of the phase coexistence curve of a pure substance in the pressure-temperature plane:Here is the common equilibrium pressure of the two phases, is their common absolute temperature in kelvins, and the derivative is taken along their coexistence curve. Choose a direction of transformation from phase 1 to phase 2. Then is the reversible latent heat for that transformation and is the corresponding volume change, using the same amount of substance for both quantities.
In the molar convention used below, has units and has units , so the right-hand side has units . For vaporization, both and are positive. The displayed general relation is also called the Clapeyron equation; the ideal-vapor approximation used in (c) gives its usual Clausius form.
At coexistence, the two phases of a pure substance have equal chemical potential, or equivalently equal molar Gibbs free energy:For either phase, . Move an infinitesimal distance along the coexistence curve, where the equality must remain true. Subtracting the two differentials givesA reversible transformation at this common temperature absorbs latent heat . ThusThe derivation assumes thermodynamic equilibrium between two bulk phases of a single pure substance, with the same temperature and pressure, and only ordinary pressure-volume work. Surface-curvature shifts, additional external-field work and composition changes are omitted. It applies to a first-order phase boundary where the latent heat and volume discontinuity are defined. No ideal-gas assumption and no constant- assumption are needed for this differential relation. At the critical endpoint both discontinuities vanish, so their ratio requires a limiting treatment rather than direct substitution of two zeros.
For liquid-vapor equilibrium, use molar quantities. At low vapor pressure the gas is dilute, approximately ideal, and has a much larger molar volume than the liquid. HenceSubstitution into the Clapeyron equation givesIf the molar latent heat varies sufficiently slowly to be treated as constant over the temperature interval, integration givesThe positive constant has pressure units and is an integration constant. It is not necessarily a real infinite-temperature pressure, since the approximations fail before that limit.
For mercury between and , the original plot places this range above the triple point and below the normal boiling and critical temperatures. Its vapor pressure is low relative to the critical pressure, making a dilute-gas description reasonable; the vapor's molar volume greatly exceeds that of the dense liquid. The interval is also far from the critical region where tends to zero, so a roughly constant latent heat is a useful first approximation. The approximations are not exact: Kirchhoff's law of thermochemistry gives, at fixed pressure, the temperature derivative of a transformation enthalpy as the difference between the two molar heat capacities, so a precise fit over a wide interval would allow to vary.
Taking a derivative of the logarithmic form gives a direct way to use the plot's base-ten vertical axis:Alternatively, use two nearby readings and eliminate the unknown :Reading the original PDF graph approximately gives at and at . These bracket the requested temperature and give an average latent heat near :Thus a suitable graph-based estimate isThe graph does not warrant several significant figures; a local tangent or different reasonable nearby readings give a comparable estimate. The factor is essential when using a base-ten logarithmic axis.
The phase diagram must contain three coexistence curves meeting at the triple point: a solid-gas sublimation curve, a solid-liquid melting curve and a liquid-gas vaporization curve. The vaporization curve ends at a liquid-gas critical point; beyond it liquid and gas are continuously connected as a supercritical fluid.
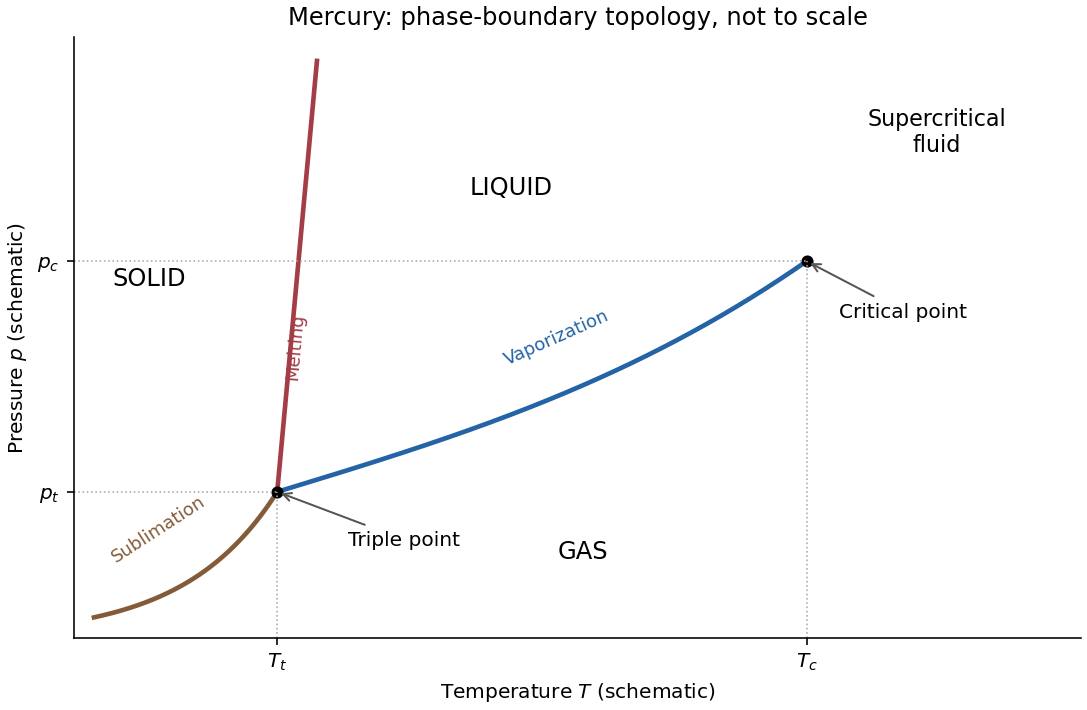


The imposed contraction on freezing means . Melting therefore has and . The Clapeyron equation then requiresThus raising the pressure raises the melting temperature. The liquid-gas and solid-gas slopes are also positive because the transformations into gas increase both entropy and volume. The liquid region lies between the positively sloping melting line and the vaporization curve, while gas occupies the low-pressure side. The figure is a qualitative solution sketch, not a reproduction or fit of the paper's vapor-pressure measurements; its axes are schematic.
Articles were limited to the first 100 out of 111 total.
Articles by others on the same topic
There are currently no matching articles.