The minimal polynomial of the linear map is the unique monic polynomial of smallest degree satisfying . An annihilating polynomial exists because the powers lie in the finite-dimensional vector space and are therefore linearly dependent. If two monic annihilating polynomials had the same least degree, their difference would be an annihilating polynomial of smaller degree, so they coincide.
Write . If , evaluation at the linear map gives . Since commutes with every polynomial in itself, this is a two-sided inverse:Conversely, if is an invertible linear map and , then and multiplication of by gives , contradicting the defining least degree. Thus invertibility is equivalent to a nonzero constant term of the minimal polynomial. In the zero-dimensional case the minimal polynomial is and the same conclusion holds.
The image is a ring torus: a circle of radius is rotated about the vertical axis at distance from that axis. Put . Since , every image point has , and the image is preciselyConversely, on this level set the pairs and are unit vectors, so choosing their angles gives a preimage.
The specified angular rectangle removes two closed circles from the torus. More explicitly its image isHere is the outer equatorial circle and is a meridian. The given openness property makes open in . On , the angles of and are uniquely chosen in ; their continuous argument branches give the inverse . Thus the restriction is a homeomorphism onto , and the inverse is locally smooth.
For the immersion condition, the two derivatives have inner productsThey are linearly independent everywhere, since . Hence this is a smooth embedded surface parametrization.
The angular cuts do not represent singularities of the embedded torus of revolution. To give a direct proof covering all points, define on the open region . On ,The implicit function theorem therefore describes near every point as a smooth graph of two coordinates. The whole torus is a smooth embedded surface.
The Cauchy integral formula states that if is holomorphic on a neighborhood of a positively oriented simple closed contour and its interior, then for inside,For the given counterclockwise circle, divide the rational function:The contour integral of is zero because it has a primitive, while both points lie inside the circle. Applying the Cauchy integral formula to the constant function at each point givesThe sign reverses if the contour orientation is reversed.
Use Minkowski spacetime coordinates and the Minkowski metric of signature . For a massive particle with three-velocity and , proper time satisfiesThus the four-velocity components areHere upper indices indicate components in the chosen coordinates; lowering with the Minkowski metric changes the signs of the spatial components. Its invariant product defined by the Minkowski metric is
The four-momentum is , so and . The Taylor expansion of the Lorentz factor at small isConsequently , recovering ordinary momentum. At rest the four-momentum has energy , so subtracting this rest energy gives the kinetic energyThus the nonrelativistic limit preserves the rest-energy offset as well as the usual kinetic energy.
For a two-dimensional incompressible flow , the continuity equation is . Locally, or globally on a simply connected fluid region, this permits a streamfunction withIndeed, the one-form is closed by incompressibility and hence is locally the differential of . Conversely these expressions automatically give zero divergence by equality of mixed derivatives.
A streamline at a fixed time is tangent to the instantaneous velocity field. Along it,Thus streamlines are connected curves on which the streamfunction is constant; wherever , the level curves have exactly the required tangent direction. At a stagnation point, the tangent is degenerate and distinct branches of a level set need not form a single streamline. For unsteady flow this argument fixes time: it does not identify streamlines with particle pathlines.
Integrating and imposing gives the streamfunctionup to an arbitrary function of time. At the specified time, the streamlines areFor , the connected branches are rectangular hyperbolas. The zero level consists of the lines and , with the stagnation point at their intersection; their half-lines and the stationary point are the distinct streamlines.
A particle pathline follows the time-dependent velocity field, so its coordinates satisfy and . The second equation and the initial data give . Using the integrating factor in the first,Therefore the complete pathline isIf , its first coordinate grows without bound in magnitude. If , the first coordinate remains bounded and periodic while . The unique release coordinate giving a bounded particle path is .
For the Cholesky decomposition , choose lower triangular with positive diagonal whenever is positive-definite. Successive entries areThe equation gives , so . Finally,Thus for ,It is nonsingular, and for every nonzero vector , .
Necessity also follows from the leading principal determinants , and , or directly from the second elimination pivot. HenceAt the displayed limiting factor still satisfies , but has rank two and zero second diagonal entry: is positive semidefinite, not positive-definite. For , taking gives , so no real factor exists.
Under the null hypothesis of equal population probabilities, the three counts have a multinomial distribution with probabilities and expected counts each. The Pearson chi-squared goodness-of-fit test usesNo probabilities have been estimated from the data, and the three counts sum to a fixed total. Hence the null reference chi-squared distribution has statistical degrees of freedom. The supplied upper critical value is , and . At the 5% significance level there is insufficient evidence to reject equal popularity.
The asymptotic P-value is . The expected counts are all large, so the approximation is appropriate if the sampled choices are independent and representative of this branch. The conclusion depends on the chosen significance level; for instance, a test would reject. Nonrejection does not establish the null hypothesis, and a survey at one branch does not by itself justify a population claim about every branch.
Associate free real dual variables and with the row and column equality constraints. The Lagrangian for the transportation problem isIts infimum over is finite exactly when for every pair. The linear programming duality therefore givesThe dual variables have no sign restrictions because the primal constraints are equalities.
A feasible shipment is optimal if and only if there exist feasible transportation dual potentials satisfying complementary slackness:Thus every occupied route must have . To see sufficiency explicitly, the primal minus dual objective isand complementary slackness makes it zero. This is the weak duality certificate. Necessity follows from strong duality for the feasible, bounded linear program. If the total supply is positive, gives feasibility; if , does. The feasible shipments form a closed bounded set, so the primal optimum is attained. This also covers zero supplies and demands. The one redundant equality merely leaves the dual gauge freedom .
Let and . Extend a basis of the vector subspace to of , and let be its dual basis. Every linear functional is uniquely . It vanishes on exactly when . Thus the annihilator of a vector subspace has basis , and
To apply this to a matrix, regard its rows as elements of and let be their linear span. Elementary invertible row and column operations reduce a rank- matrix to a block identity , showing that . The equations require that every functional in vanish on . The canonical identification sends to evaluation : it is injective because coordinate functionals separate points, and is bijective by equal dimensions. Consequently the solution vector space is the annihilator of under this identification. The dimension formula just proved givesA basis of this kernel consists of exactly linearly independent solutions, and every solution is their linear combination.
Let act on its left cosets by . This is well-defined and gives a group homomorphism . Its kernel is a normal subgroup. An element lies in this kernel exactly when it fixes every coset, soThis is the normal core of a subgroup. By the first isomorphism theorem, , a subgroup of . The Lagrange theorem therefore givesIn particular has finite index even when is infinite.
Now let be generated by an element of order in a group of order . Then and . The preceding result gives a normal with . Since has prime order, its subgroup is either or all of . The first choice would imply , which is impossible because the prime divides none of the factors of . Therefore , proving that every subgroup generated by an element of order is normal. No classification of groups of order is needed.
Fix and . By uniform convergence, choose so that for every . By continuity of relative to , there is such that and imply . The triangle inequality givesThis proves the uniform limit theorem without requiring to be open or closed.
For the series, fix an arbitrary and put . On each summand is continuous andThe Weierstrass M-test gives uniform convergence of the series on . Its partial sums are continuous, so the uniform limit theorem makes its sum continuous on that interval, in particular at with the appropriate relative topology if . Since was arbitrary, the sum is continuous on .
This is local uniform convergence, not uniform convergence on the entire half-open interval. Indeed, for any finite partial sum length , its tail as is bounded below by arbitrarily long tails of the divergent harmonic series. There is no continuity claim at the excluded endpoint .
The sum of the two metrics is nonnegative and symmetric. It vanishes exactly when both coordinate distances vanish, hence exactly when the two points agree. Adding the two component triangle inequalities gives the triangle inequality on the Cartesian product, so the displayed function is a metric. Moreover,so the projection map is -Lipschitz and therefore continuous.
To prove sequential compactness directly from compactness, take a sequence in . If every point had a neighborhood containing sequence terms at only finitely many indices, these neighborhoods would form an open cover with a finite subcover, implying that only finitely many sequence terms exist, a contradiction. Thus some has infinitely many indices in every neighborhood. Choose increasing indices with ; then .
Now let be closed and suppose converges to . Choose such that . A convergent subsequence exists by the preceding argument. In the product metric, , and the fact that is closed gives . Thus , proving that the projection with a compact factor is closed. The sequential criterion for a closed set in a metric space follows by choosing points at distance less than from any point of its closure.
For a counterexample without a compact factor, take with their usual metrics andThe continuous product function makes closed, but is not closed. Thus compactness of the discarded factor is essential to the general conclusion.
Use the Möbius transformation , the principal square root with , and then . The resulting conformal map isAll branches here are single-valued: the inverse shows that the deleted segment corresponds to the nonpositive real axis. However, the exact first image issince would require a source point at infinity. Thus the next image is , andThe strict inequality follows from . None of the component derivatives vanishes. For completeness the inverse on this punctured disk isGiven , the inverse Cayley transform has positive real part, and reversing the three maps proves both injectivity and surjectivity onto this exact image.
This distinction matters for interpreting the printed request. The displayed function is a conformal map into the unit disk, but no conformal bijection from the specified plane domain onto the full unit disk exists. To prove the obstruction, the loop surrounds , a point outside the domain, with winding number . A contraction within the source would remain in and preserve winding number, whereas a constant loop has winding number . Hence the source is not simply connected; a disk is simply connected, as straight-line contraction shows, and a conformal bijection is a homeomorphism.
The hinted construction becomes a bijection onto the full disk if the source is instead , including infinity on the Riemann sphere. Near infinity, , so the map extends with and nonzero derivative in the coordinate . This is the precise filled-in version of the conformal map of a segment complement to a punctured disk.
The Fourier coefficients satisfy andThus the square wave has Fourier seriesIt equals away from its jump discontinuities, and converges to at the jumps. The assigned endpoint values do not affect its Fourier coefficients.
For the Poisson equation, use separation of variables . The radial equation is . Its bounded solution with zero Dirichlet boundary condition at isIndeed the negative power is excluded at the centre, and the boundary fixes the coefficient of . No resonance at occurs because only odd modes are forced. ThereforeThis is a Poisson equation on a disk with angular forcing. The series converges uniformly on the closed disk: for each term is bounded by a constant times . Its first spatial derivatives also converge uniformly. For instance the radial derivative and times the angular derivative of each term are bounded by constants times ; the harmonic term is smooth in Cartesian coordinates. It defines a function with zero boundary data and the required weak formulation. Applying the Laplacian to finite partial sums gives the Fourier partial sums of , which converge in ; passing to the limit against smooth compactly supported test functions verifies the Poisson equation. It holds classically off the jump rays and the centre, where the forcing is locally constant. It cannot be interpreted as a global classical equation with continuous second derivatives for discontinuous forcing. Uniqueness follows from the zero-boundary Dirichlet energy identity for the difference of two solutions.
Finally orthogonality gives . The radial integral isUniform convergence of and boundedness of justify integration term by term, soThe negative sign also agrees with . The original PDF's radial denominator is ; the converted TeX's is a transcription error.
Inside the infinite square well, the time-independent Schrödinger equation is with . For the exponential solutions cannot satisfy both conditions except trivially, and for neither can a linear function. For put . The first boundary condition selects , and the second gives . Thuson , with outside. Their squared integrals are one, and the sine orthogonality identity gives an orthonormal set. The sine Fourier basis on the interval is complete: odd extension to an interval of length reduces this to completeness of the Fourier series basis. Hence these are a complete set of normalized energy eigenstates.
Choosing the harmless sign of the second energy eigenstate so that and , the specified wave function is . The Born rule therefore giveswith no other possible measured energies. The two energy eigenvalues are and .
After the first measurement gives the ground state, the old state is . Doubling the width puts the walls at , and the new normalized ground state is . The stipulated unchanged state is zero outside the original interval, so the probability amplitude isSquaring givesThe ground-state overlap after sudden expansion of a square well stays unchanged during subsequent evolution in the fixed new well, because the energy-basis coefficients acquire only phases. The answer is conditional on the already observed old ground state; its earlier probability is not another factor in this conditional question.
Fix the electric potential to vanish at infinity and assume a localized, nonsingular charge density of finite electrostatic energy. Assemble the charge by scaling from to . Linearity gives , so the work isThe factor prevents double counting of pair interactions. Using Gauss law, , and integration by parts,The boundary integral at infinity vanishes for a localized distribution since and . Singular point-charge self-energies require a separate regularization and are not finite instances of this identity.
For the uniform solid sphere, spherical symmetry and Gauss law giveIntegrating inward from infinity and matching the continuous electric potential at givesThe value of the electric field at the centre is the zero vector.
Writing , the electrostatic energy of a uniformly charged solid sphere follows either from the charge-potential integral or from the field integral including the exterior:For the nuclear scaling, while constant volume per proton gives . Therefore the electric contribution scales as in this uniform-density model.
For potential flow in an inviscid fluid of constant density under the conservative force per unit mass , the unsteady Bernoulli equation isIt follows by inserting the velocity potential into the Euler equations and integrating the resulting spatial gradient. A time-only change of the velocity potential changes without altering the velocity field.
For spherical motion in an unbounded liquid, incompressibility gives ; the kinematic condition gives . Choose , vanishing at infinity. To obtain the displayed bubble relation, take no spatial body-force contribution, neglect viscosity and surface tension, and equate the liquid-side interface pressure to . With the far-field pressure , Bernoulli equation evaluated at the surface uses the partial derivative at fixed :Hence the Rayleigh equation for an inviscid spherical bubble is
The exterior kinetic energy isDifferentiating it and using gives the pressure-work energy balance for a spherical bubble:This derivation also holds at a turning point , without dividing by .
For constant and the stated inverse-volume bubble pressure, integrate this exact time derivative:The relation is valid on physically accessible portions of the motion, where the resulting kinetic energy is nonnegative. In particular makes the bracket nonpositive, as expected for the restoring pressure about .
A simple hypothesis specifies the entire probability distribution. A critical region is the set of observations for which the null hypothesis is rejected. The size of a statistical test is , which reduces to for a simple hypothesis. The power function is as a function of the true parameter or distribution. At a specified alternative, the Type II error probability is , the chance of failing to reject a false null hypothesis. The Type I error probability is the corresponding rejection probability under the null hypothesis.
The Neyman-Pearson lemma says that, for two simple hypotheses, a test rejecting where , accepting where , and if necessary randomizing on equality to achieve prescribed size , has maximal statistical power among tests of size at most . Conversely a most powerful test can be taken in this likelihood ratio form, up to equality sets and null sets.
Here the likelihood ratio for isIts value is infinite at , which has probability zero under both continuous distributions. Large likelihood ratios correspond to small . Thus the best critical region is , whereThere is no boundary randomization to worry about. The complete answer is
For the minimum sum of errors in a simple hypothesis test, write the error sum as . At each observation its smaller contribution is obtained by rejecting exactly where . This proves optimality over all tests, including randomized ones, rather than just optimizing within an assumed family. Here it gives , and thereforeThe minimum error sum is . This criterion weights the two error probabilities equally; it does not impose a conventional significance level.
Let be the shorter circular separation after swaps, so . There are equally likely unordered swaps. Six swap only guests, one swaps the distinguished pair, and eight swap one distinguished diner with a guest. Rotations, reflections and exchangeability of the guests ensure that the next-separation probabilities depend only on . Thus this is the separation chain for two labels in a circular transposition shuffle, a lumped Markov chain.
Counting all swaps gives the transition matrixwith states ordered . To verify the counts, fix one distinguished diner at seat and the other at seat . For , swaps moving the diner at to seats give separations ; swaps moving the diner at to those seats give . Along with the seven separation-preserving swaps this gives . For , moving the first diner to seats gives , while moving the second gives ; the total is . For , each distinguished diner has two moves to separation and two to separation , giving .
If , the last column yieldsSubtracting the fixed point and iterating solves the affine recurrence:For one swap this gives , agreeing with direct counting. The limit also agrees with the stationary distribution of the separation Markov chain: given one diner's seat, one of the five remaining seats is opposite. The complete permutation shuffle alternates parity, but that does not prevent this lumped separation probability from converging.
Direct matrix multiplication gives the multiplication tableTogether with acting as the identity, this shows that the product of any two real linear combinations is again a real linear combination. Thus is closed under multiplication. It is the complex matrix representation of quaternions.
Its general element has the formIf this matrix is zero, real and imaginary parts of its first row give . Hence are linearly independent over and form a basis:Put . Since distinct imaginary units anticommute, the mixed terms in cancel, leaving . Scalars commute with , soThe reversed product is the same. The coefficient is strictly positive for every nonzero element. ConsequentlyThis also identifies as a real noncommutative division algebra, not as the full algebra of complex two-by-two matrices.
A group automorphism is a bijective group homomorphism from to itself. The multiplication in is composition: . Composition is associative, the identity map is the identity element, and each inverse bijection is again a homomorphism, so these maps form the automorphism group.
For conjugation by , multiplication is preserved becauseConjugation by is its inverse, so is an group automorphism. MoreoverHence is a homomorphism, with image the inner automorphisms. Its group homomorphism kernel is the group center of , since is the identity precisely when for every .
Every uniformly continuous function on is bounded. Choose the tolerance for and an integer with . The finitely many centers , , cover the interval by cells of radius . For each , one center satisfies . Thus . This is the uniformly continuous function on a totally bounded set is bounded argument; closedness of the interval is unnecessary.
The reciprocal function is not uniformly continuous on . It is unbounded, already contradicting the preceding result. Directly, and have distance tending to zero while .
The oscillating function is not uniformly continuous either, despite being bounded. TakeTheir distance tends to zero, but their function values are and . The fixed output gap of two contradicts the uniform-continuity condition, for example with .
Suppose the union has a separation into disjoint, nonempty, relatively open subsets. Each connected must lie entirely in one of them: otherwise its intersections with and would separate in its subspace topology. In particular lies on one side, say . Every other intersects , so it cannot lie in and must also lie in . Then , contradicting . The union is connected. This is the connected union with a connected hub argument.
For path-connectedness, take any and . Choose and . There is a path from to inside , a path from to inside , and a path from to inside . Concatenate the three paths on successive thirds of . They agree at the joining points, so the resulting map is continuous and remains in . The union is path-connected. There need not be a single point common to all the subsets.
Use the causal Green function: it vanishes before the forcing time . For it solves the homogeneous equation, is continuous at with value zero, and has first-derivative jump one. These conditions giveIndeed the right derivative at the forcing time is one and the left derivative is zero, so distributionally. If , use the continuous limit on its causal support.
For , differentiating the integral solution givesBoth initial values vanish and . This verifies the requested representation and its sign. The formula similarly gives .
In SI units, the sourced Maxwell equations areTake the divergence of the last equation. The divergence of a curl vanishes; using the first equation gives the necessary local conservation lawFor sources supported in a fixed region, integrate over a containing surface where the current vanishes. The divergence theorem givesThus the total charge is constant. For each component of the electric dipole moment, integration by parts givesThe surface term again vanishes, soSmooth compact support suffices for these manipulations; equivalently one may integrate the charge continuity equation over all space and use the fixed support to identify the integrals with those over .
Set , and . In Alice's inertial coordinates the departure, turn and return events are , and . Alice's worldline is vertical; Bob's consists of two straight timelike segments of slopes , joined by the short turnaround. Equal speeds and the same endpoints give equal coordinate durations on the two legs.
The Minkowski proper-time element for Bob is , while Alice at rest has . Integrating on both legs givesAcceleration itself need not cause a large direct change in the clock rate. Its role is to make Bob change inertial frames and reunite with Alice, so the two worldlines have different proper lengths between the same events.
To describe Bob's assignment of Alice's age, apply relativity of simultaneity to lines of equal coordinate time in his instantaneous inertial frames. At the turn the outbound line is ; it intersects Alice at . The inbound line is and intersects her at . Thus the negligibly short change of rest frame advances Bob's assigned Alice age by . On each inertial leg he assigns Alice an aging rate per unit of his own proper time, but the frame dependence expressed by relativity of simultaneity removes the apparent symmetric-time-dilation paradox.
If “sees” means clocks read from received light, there is no instantaneous jump in Alice's displayed age. A light signal received at Bob's event was emitted from Alice at . On the outbound leg ; on the inbound leg . Consequently the observed aging rates per Bob proper time areHe receives slowly running, redshifted clock signals on the outward leg and rapidly running, blueshifted signals on the return. Integrating both rates over the equal proper durations gives total received Alice aging , with the two expressions continuous at the turn.
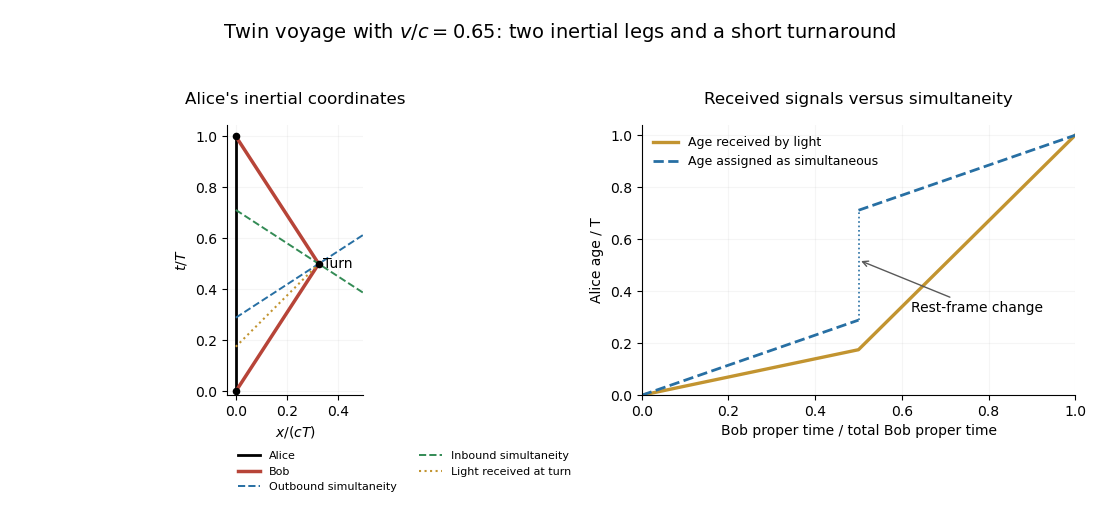
Twin voyage: inertial worldlines, turnaround simultaneity lines, and Alice ages assigned or optically received by Bob
. Details. 
The diagram distinguishes the reassignment due to relativity of simultaneity from the continuous optical observation; both descriptions give the same ages when the twins meet again.
The intended dynamical assumption is steady inviscid Euler flow of constant density, with conservative body-force potential . Its equation is . The vector identitythen givesWith no body force take . Taking the scalar product with yields , so the Bernoulli function is constant along streamlines, though not necessarily the same constant on different streamlines.
Choose the planar streamfunction convention . Then with , andIf locally , comparison with giveson the nonstagnant part of that flow. It extends to isolated stagnation points by continuity. Where the streamfunction is constant on an entire open region, cancellation of its zero gradient alone imposes no derivative condition on an arbitrarily extended .
Steadiness and incompressibility alone, without the inviscid dynamical assumption, do not imply the stated identity. In a steady Newtonian viscous flow the correct form has . For example, a pressure-driven planar Poiseuille flow has a nonzero streamwise pressure gradient balanced by viscosity, while has no streamwise component. This identifies the required qualification of the printed premise.
In a finite two-person zero-sum game the row player chooses , the column player chooses , and the row player receives while the column player receives . The row player maximizes that payoff and the column player minimizes it. Mixed strategies are probability vectors and , giving expected row payoff .
Against a fixed row mixture, the worst column is a pure column, so the row problem introduces its guaranteed payoff :Similarly the column player minimizes an upper guarantee :The values are unrestricted real variables; no positivity shift of the matrix is required.
To see the linear programming duality explicitly, introduce nonnegative multipliers for the first problem's payoff inequalities and multiplier for its normalization. Its upper-bound Lagrangian isThe supremum over free and nonnegative is finite precisely when and , and is then . Minimizing it gives the displayed column problem, proving that the programs are a dual pair.
A sufficient optimality certificate is a pair of probability vectors and a common value satisfyingEquivalently, both programs are feasible with equal values. Positive-probability rows then have and positive-probability columns have , the complementary slackness conditions. These conditions certify a saddle point and hence optimal mixed strategies for both players.
For a complex square matrix, define its determinant byThe cofactor is , where deletes row and column . The adjugate is the transposed cofactor matrix, .
The entry of is . For , expansion along column gives . For , this same sum is the determinant of the matrix obtained by replacing column by column : deleting the replaced column leaves all its cofactors unchanged. The new matrix has two equal columns, so its determinant is zero. ThusThis proof does not assume invertibility and therefore also covers singular matrices.
The cyclic matrix acts by . For each fourth root of unity , the vector satisfies , because . This supplies the four distinct eigenvalues and nonzero eigenvectors:Eigenvectors for distinct eigenvalues are linearly independent. Thus, with these columns in the indicated order,They form a basis over , so there are no other eigenvalues. Equivalently the characteristic polynomial is .
Let and . The precise presented group is , with and . It is abelian and has exactly the imposed additive relation and its integer multiples.
Change the integral basis to , . The change-of-basis determinant is , so these are a basis of the free abelian group. Explicitly, and . The relation generator becomes . ThereforeThe image of is nonzero, since is not an integer multiple of , but three times it vanishes. Thus has an element of exact order three. A free abelian group has no nonzero finite-order element, so is not free abelian.
For a Riemannian metric , write . Use the energy of a curve normalization compatible with the requested inequality:The Cauchy-Schwarz inequality here has the direct variance formEquality holds exactly when is constant almost everywhere, hence everywhere for a smooth curve. With the alternative energy of a curve convention containing a factor , the same assertion reads .
In the upper half-plane write , , and use . Let the endpoints be , , . ThenThe first equality requires throughout. Endpoint values force . The second equality requires the derivative of to have one sign, so is monotone. Conversely every smooth monotone positive with these endpoints attains this bound. Consequently the absolute length minimizers are precisely the vertical curves with monotone height, including a constant curve when , and the distance is .
For curves stationary for the energy of a curve, fixed-endpoint variations give the Euler–Lagrange equations for :Thus for a constant . Since , integration gives , hence . The second equation then becomes . ThereforeIt has constant hyperbolic speed, is one of the absolute length minimizers, and also has minimum energy of a curve .
Choose and put . The intersection is nonempty, closed and bounded in , hence compact. The continuous distance function attains a minimum at some . For its value is strictly greater than , while the value at is at most that at , namely . Thus this minimum on is a minimum on all of :The set itself need not be bounded; only the compact portion needed to find the nearest point is bounded.
Suppose two distinct minimizers have the same minimum distance from . Convexity puts their midpoint in . Expanding the Euclidean norm givescontradicting minimality. Therefore the nearest point is unique. Together with the preceding existence proof, this defines the metric projection onto a nonempty closed convex set.
Close the real-line contour by a positively oriented upper semicircle of radius , beyond every pole. The rational function is uniformly on that arc, and . Its arc integral is therefore and vanishes. The real integral is absolutely convergent, while no pole lies on it. The residue theorem givesOnly actual poles contribute; any removable zero of the denominator has zero residue. The same contour proof covers poles of any order.
For the particular denominator, the upper poles are and . They are simple, with residues and . Sincetheir sum isMultiplication by gives the real answer. The sine part of the real-line integral is zero by oddness, so
Fixed endpoint variations yield the Euler–Lagrange equationWhen is independent of , differentiation givesThis is the Beltrami identity. Denote the constant by when nonzero; for a general Lagrangian a zero constant is also possible.
The film area is . Suppressing its harmless positive factor , take . The Euler–Lagrange equation reduces toThe first integral is with . Hence and, using the differential equation without dividing by , . The positive solution obeying that first integral is . Equal endpoint radii force , givingThus every smooth positive stationary film in this axisymmetric class is a catenoid.
Put . The boundary equation is . The function tends to infinity at both endpoints of , andIts minimum occurs when . The function is strictly increasing, with derivative , and has limits and . It therefore has exactly one positive zero . At this point , so . This proves the catenoid existence threshold for equal rings:At equality there is one stationary solution and above it two. The equation describes candidates for an area minimum, not a guarantee that both branches minimize. The thinner-neck branch is unstable to suitable axisymmetric variations; topology-changing collapse can also compete with connected films. In particular two separate planar disks have area . The derived threshold concerns existence of the smooth annular stationary film; it does not exclude such disconnected competitors.
On a suitable dense domain of smooth rapidly decreasing wave functions, the canonical commutator is . Expanding the two ladder operators givesTheir sum and difference giveDirect multiplication, retaining the operator order, givesUsing identifies the Hamiltonian operator:For any admissible wave function, adjointness givesFor the conventional normalized state , this is the stated lower bound . For an unnormalized function the norm factor must be retained; rescaling a wave function cannot leave its unnormalized energy integral bounded below by a fixed positive number.
Equality holds exactly when . In position representation this equation is , whose normalized square-integrable solution isThis construction establishes existence of a state attaining the bound, and hence proves that it is the ground state.
The commutator implies . Repeatedly commuting through the product givesThese vectors are nonzero: the identity gives their norm squared by induction. ThereforeFor time-dependent stationary states multiply each spatial eigenfunction by .
In Cartesian coordinates the magnetic field is . Its divergence is , and all components of its curl vanish. Thus it satisfies the static vacuum magnetic equations and , with no electric current in the region.
Fix clockwise orientation as viewed from above, looking down the positive -axis. Its positive area normal is . The loop's external magnetic flux is thereforeWith the opposite normal its flux has the opposite sign. On the circle and clockwise line element is . The Lorentz force element isThe radial terms cancel around the circle, soThis fixes the current/flux/force signs together.
Neglect self-inductance initially, so Faraday's law and Ohm's law give . Including gravity then givesFor and , the terminal solution is withThe general velocity relaxes exponentially to on time scale . In the terminal state , and the Joule-heating rate isThus all the lost gravitational potential energy becomes resistive heat when kinetic energy is constant.
Within the zero-inductance approximation as ; finite-speed motion would require an unbounded current. This limit is singular, so it is important to describe the physical ideal-conductor limit separately. With finite self-inductance , the circuit equation is . At , total linked flux is conserved and there is no Joule heating. If initially at , thenThis lossless limit of magnetic loop braking has undamped oscillations about , with magnetic energy storing and returning mechanical energy. It has no generic dissipative terminal descent. Thus the vanishing terminal speed is the formal resistive-model limit, not a justification for dropping inductance in a perfectly conducting moving loop.
Take nonzero of exact degree , so are an orthogonal basis of the polynomials of degree at most . Their orthogonal projection isIndeed its residual is orthogonal to every such polynomial. For another polynomial of degree at most , the squared error issince the cross term vanishes. It is uniquely minimized at . The approximation need not have exact degree when the highest coefficient happens to vanish.
Use first-kind Chebyshev polynomials , characterized by . Substituting converts the weighted inner product into . Hence these polynomials are orthogonal, with squared norms for and for .
For the specified function, . Its constant projection coefficient is . For the coefficient is . Symmetry about makes it zero for odd . For , the product-to-sum identity givesTherefore the Chebyshev projection of a semicircle isIn particular the best degree-at-most- polynomial is even, so for odd its actual degree is at most .
For observed data , let be the posterior cumulative distribution function. Assuming finite posterior first moment, the posterior risk under asymmetric absolute-error loss isAt points where the posterior has a density, differentiation gives . Risk is convex, so a global minimum is a posterior quantile:More generally any with minimizes risk. This is the Bayes quantile under asymmetric absolute-error loss; a larger cost for underestimation moves the chosen quantile upward.
For the uniform sampling model set . For a valid positive sample the likelihood is . Multiplying by the prior cancels its power of and gives posterior density proportional to . Normalization yieldsSolving the quantile equation gives the explicit Bayes estimateThe posterior is the sample maximum plus a unit-rate exponential distribution displacement; it has finite first moment, so the preceding risk minimization is justified here.
The transition row sums to one, since . From any state the Markov chain can reach zero, and from zero consecutive upward moves reach every state; hence it is irreducible. Its self-transition at zero has probability , so it is aperiodic. It is the reflected chain with geometric downward jumps.
Put for the hitting problem. The first-step equations for areSubtracting times the equation at gives the linear recurrence relation, valid for ,The separate boundary equation at is . It must not be replaced by the linear recurrence relation with : the absorbing hitting convention at zero is different from applying a first-step return equation there.
For , the linear recurrence relation has roots and , so for . The boundary equation gives . If , then and boundedness of probabilities forces , hence . If , the repeated-root solution is ; boundedness again gives and the boundary equation gives .
For , and the nonnegative harmonic candidate , together with , satisfies every first-step equation. Hitting-by-time- probabilities start from zero off the target and iterate those equations, so by induction they are bounded above by this candidate. Taking their increasing limit gives . But the general bounded solution has limit as , forcing under that bound. ThusIn particular the transient exponent is , fixed by the original boundary equation.
The probability of a subsequent return to zero when starting there is . It is one for , so the Markov chain is recurrent there. For it equals , so the irreducible Markov chain is transient.
For a stationary probability vector , balance at zero and one gives . Subtracting adjacent balance equations givesso this initial ratio propagates and . It can be normalized only when . In that caseDirect substitution verifies all balance equations, including . An irreducible Markov chain admitting this stationary probability law is positive recurrent, with mean return time . At the linear recurrence relation and boundary relation force every equal; no such nonzero sequence is summable. The recurrent chain is therefore null recurrent. In summary,
The conjugate group elements relation is when for some . It is reflexive by taking the identity, symmetric because , and transitive because and imply . Hence it is an equivalence relation.
For a finite group, the centralizer is a subgroup. The map has equal values at exactly when . Its fibers are therefore the left cosets of , givingBy Lagrange's theorem, this index divides . This is also the orbit-stabilizer theorem for the conjugation action, with the centralizer as stabilizer.
For curvature , the Poincare disc model has metric and area elementThe given minimizing-diameter property makes the distance from zero to Euclidean radius equal toRadial symmetry therefore identifies the whole hyperbolic circle in the Poincare disc. Integrating its enclosed hyperbolic area gives
For a geodesic hyperbolic triangle with angles , the Gauss-Bonnet theorem states , in particular , with strict inequality for ordinary finite vertices. Let be the distance of the interior point to the nearest side. The open disc of radius about is contained in the triangle: a path from to an exterior point must first cross the boundary at distance at least . A hyperbolic isometry carries its center to zero, so its area is the area already calculated. ConsequentlyThis uses hyperbolic area bounds an inscribed disc and establishes the requested bound without assuming that is an incenter. A sharper universal triangle bound is possible, but is not needed here.
A function is a differentiable function at if there is a linear map withThe map is its derivative; equivalently for fixed constants. Since every such linear map is bounded, . This proves differentiability implies continuity, not merely continuity along each coordinate axis.
Articles were limited to the first 100 out of 203 total.
Articles by others on the same topic
There are currently no matching articles.