Angular momentum measures how a point mass's momentum passes around a chosen origin. Motion straight toward or away from that origin contributes zero; transverse momentum contributes more when it passes farther away. The picture shows the sign convention before the calculation.
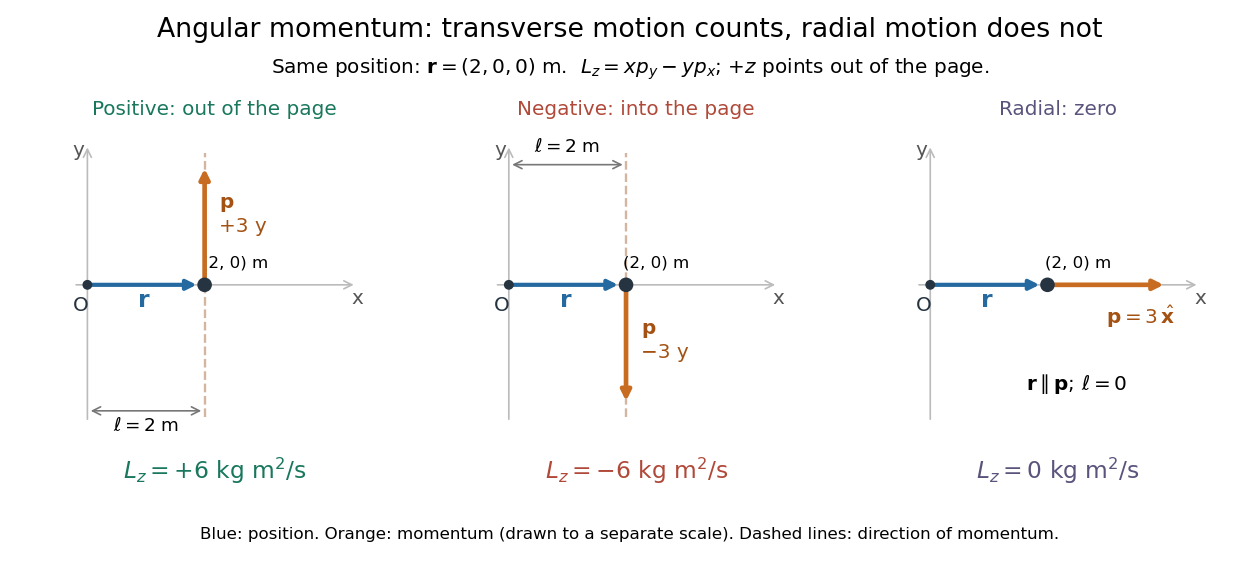
Positive, negative and zero angular momentum about the same origin
. Details. Fix an origin and nonrotating axes in an inertial frame. For a nonrelativistic point mass of constant mass , let be its position from and its mechanical momentum in that same reference frame. Its angular momentum is the cross productHere , , and is the angle between them. The right-hand rule gives the direction: curl from toward , and the thumb points along . Thus angular momentum is an axial vector, perpendicular to both position and momentum. Its International System of Units unit is . A point mass need not follow a circle to have angular momentum.[ref]
With rightward, upward, and out of the page, the cross product gives . TakeThen . Reversing the momentum makes ; radial momentum gives . The factor is the lever arm to the line through the particle parallel to its momentum.
For motion in the plane, plane polar coordinates give , with . ConsequentlyThe signed angular velocity is positive counterclockwise viewed from toward the plane, with measured in radians. Radial velocity does not enter the cross product. Under conservation of angular momentum, this relation predicts faster angular motion at smaller and constant areal velocity for consistently oriented swept area. That is the geometric content of Kepler's second law.
For several point masses, add their angular momenta about the same origin: . The origin matters: angular momentum under an origin shift explains why the same moving particle can have different values about two fixed points. The central axis of a momentum system and angular momentum decomposition about the centre of mass make this dependence useful.
In spatial dimensions, rotations have an antisymmetric tensor of conserved Noether charges when the dynamics is rotationally invariant. There are independent rotation generators. In three dimensions the tensor is equivalent to the axial angular momentum vector through .
Move the fixed origin from to , keeping the axes parallel and the inertial frame's velocity measurements unchanged. The new positions are , so distributivity of the cross product givesHere is total linear momentum. For the angular momentum example with , the new position is and . If total momentum is zero, angular momentum is independent of this origin shift. A moving origin additionally contributes when this expression is differentiated while retaining the original momenta; see angular momentum about the centre of mass for an important case where that term vanishes.
For nonzero total momentum , translating the origin by changes angular momentum to . The displayed line of origins makes this vector parallel to , equal to . The invariant cannot be removed by translation; if it is zero, angular momentum vanishes on this line.
A gyroscope is a rotating instrument whose rapidly spinning, nearly symmetric rotor provides a direction reference through its angular momentum. In an inertial frame, negligible external torque approximately preserves that direction by conservation of angular momentum. A transverse torque turns the angular momentum instead: the surprising sideways motion of a supported spinning wheel is precession. An ideal freely falling test gyroscope in general relativity has its spin undergo parallel transport along its timelike geodesic. Comparing that direction with distant reference axes measures Lense-Thirring precession; the direction need not remain fixed in arbitrary rotating coordinates.
A gyroscope direction reference is useful precisely because its direction can persist while its housing turns. A spinning-wheel precession experiment deliberately supplies gravitational torque to reveal how that persistence fails. The gyroscope vector geometry explains the direction, and slow steady gyroscope precession gives a numerical prediction with a check on its assumptions.
A flywheel's spin angular momentum must turn with the vehicle. The vehicle supplies torque to maintain this precession, and experiences the opposite reaction torque. With right-handed axes forward, left and up, a left turn has . A transverse flywheel with then produces body torque , opposing outward roll. Its magnitude is for turn radius . Reversing the flywheel reverses the effect.
A gyrocompass uses a spinning gyroscope and Earth's rotation to identify geographical north. In an ideal model whose axle is constrained to the local horizontal plane but free to turn about the vertical, the northward direction of the spin angular momentum is stable away from the poles; the opposite spin direction is unstable. A real settling instrument also requires damping. This is different from merely preserving an initial inertial orientation with a freely mounted gyroscope.
For a rapidly spinning gyrocompass with axle constrained horizontally, take azimuth positive from north towards west and positive spin angular momentum . In the terrestrial rotating reference frame, the vertical component of the torque equation, with zero external vertical torque, is . Here is the vertical moment of inertia and terms of order have been neglected. The small-angle approximation about gives simple harmonic motion with the displayed squared angular frequency. Linearizing about reverses its sign and gives an unstable equilibrium. At the poles this restoring effect vanishes. For a thin rotationally symmetric flywheel, the perpendicular axis theorem gives .
Choose a fixed support point and nonrotating axes in an inertial frame. All angular momenta, torques, and moments of inertia below refer to . Let point along the axle from toward the centre of mass, and let point vertically upward. Write for their angle. For a rapidly spinning symmetric top, the dominant angular momentum is , where is signed and is the axial principal moment of inertia. The sign of the axial angular velocity follows the right-hand rule.
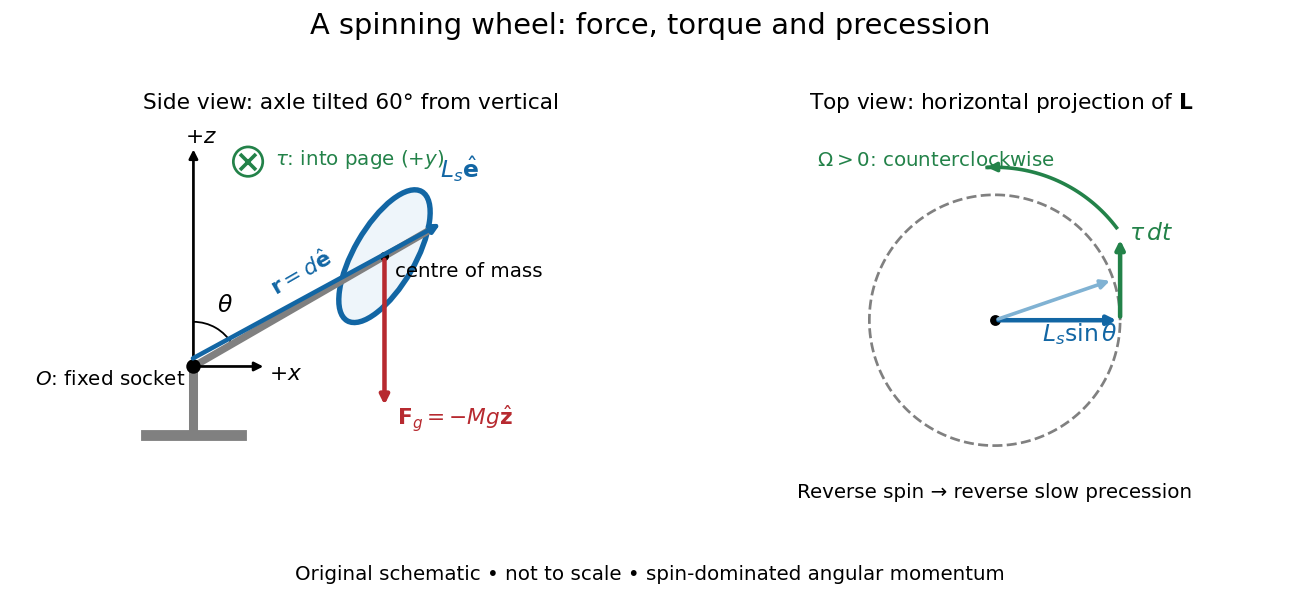
A fixed wheel support separates the downward gravitational force from the transverse torque and sideways precession
. Details. With mass , centre of mass distance , and constant gravitational acceleration , the gravitational force and its torque areAn ideal support applies a force at , so its lever arm and torque about vanish. At the instant the axle lies in the plane with a positive component, the gravitational torque points along . It adds toward , rather than along the downward force. The dot product identity shows why perpendicular torque changes direction without instantly changing magnitude. This vector balance and the slow-turning relation are developed in Chapter 20: Rotation in space (sections 20-2 and 20-3, equations 20.13–20.15).
For steady precession about the vertical, and . Equating the two cross products givesThe angular momentum tip traces a circle of radius : its sideways speed is . Both that radius and the gravitational lever arm contain , explaining its cancellation for . Exactly vertical alignment has zero gravitational torque and no distinguishable azimuthal precession to infer by this cancellation. Positive gives positive precession, counterclockwise viewed from above; reversing the spin reverses the slow precession. [ref]
11.4 Precession of a Gyroscope. University Physics Volume 1, section 11.4, equation 11.12 and the torque and precession-circle derivation
Purdue's Bicycle Wheel Gyroscope demonstration uses a bicycle wheel on a long axle, with a ball at one end seated in a freely rotating socket on a heavy stand. Spin the wheel by hand or with the supplied motor, seat the ball, and release the nearly horizontal axle. The readout is the axle sweeping around the vertical while the wheel continues spinning. Compare with the stopped wheel, which falls when one end is released; reverse the spin with the same support and the precession reverses. These are the page's documented apparatus, presentation, and reversal checks. [ref]
Bicycle Wheel Gyroscope by Purdue University, Department of Physics and Astronomy. 1Q-30, apparatus paragraph, Directions, and Suggestions for Presentation; page updated 30 November 2023
An alternative in Physics Demonstrations by Julien Clinton Sprott (section 1.3, Materials and Procedure) suspends one axle end by stainless steel wire and a fishing-line swivel. The swivel allows precession without winding up the suspension. Sprott describes the axle bobbing as nutation and precession becoming faster as spin decreases. A suspended support can move, whereas the calculation here assumes a fixed ; use the socket version for the closest realization. [ref]
Bicycle Wheel Gyroscope (section 1.3). section 1.3, Bicycle Wheel Gyroscope: Materials, Procedure, and Discussion
A proposed quantitative extension is to record an overhead view of an axle marker against a fixed angle scale, together with a side view for . Time successive overhead passages to estimate ; count passages of a rim mark to estimate . Record the spin sense too. Measure and the centre of mass offset of the whole moving assembly, and determine its axial moment of inertia independently. Wheel, axle, support, release angle, and observation interval should stay the same between spin trials. Measuring both and distinguishes azimuthal precession from nutation; an overhead movie alone can miss the latter. These camera readouts and parameter checks are proposed here, not reported measurements from the demonstration pages.
For slow precession, compare with , and test whether reversing reverses with nearly unchanged magnitude. A brief interval minimizes spin loss from friction; repeat at several starting spin rates rather than interpreting an entire slowing run as one steady state. A suspension restoring torque governed by its torsion constant, socket friction, support motion, a misplaced centre of mass, and a push at release can all supply extra torque or change the initial conditions. The swivel reduces the twist that activates the suspension's torsion constant; it does not demonstrate zero torque.
Steady precession keeps constant; nutation changes while the axle may also precess. Sudden release generally excites both. A small initial drop is consistent with conservation of energy and conserved vertical angular momentum: some gravitational potential energy supplies the motion around the vertical, and the axial contribution to vertical angular momentum adjusts. Bearing friction may damp the bobbing, but an ideal undamped heavy symmetric top need not settle into steady precession. Chapter 20: Rotation in space explicitly distinguishes uniform precession from release transients and nutation (section 20-3, paragraphs following equation 20.15).[ref]
Chapter 20: Rotation in space. section 20-3: sudden release, nutation, and the small drop needed for precessional angular momentum
Model the assembly as a heavy symmetric top with a fixed frictionless support, a uniform gravitational field, and centre of mass on its symmetry axis. Assume constant spin, negligible damping, and initial conditions prepared for uniform precession of a heavy symmetric top. Large spin means the transverse angular momentum from precession is small: . Also require . A large spin rate alone does not select steady motion after an arbitrary release.
For an original illustrative calculation, stipulateThe transverse principal moments of inertia are about the pivot, including the parallel axis theorem contribution. These inputs giveThe ratio is small; the more direct angular momentum ratio is small too. These are model calculations, not experimental results.
Check the approximation against the existing exact uniform precession of a heavy symmetric top condition. Its total angular momentum isAt constant , differentiating this expression and equating it to the gravitational torque givesFor the slow solution can be evaluated without subtracting two nearly equal numbers:It exceeds by about . The other solution is about and violates the assumed slow precession; the quadratic's two roots must not be conflated. Its discriminant must be nonnegative for these steady solutions to exist.
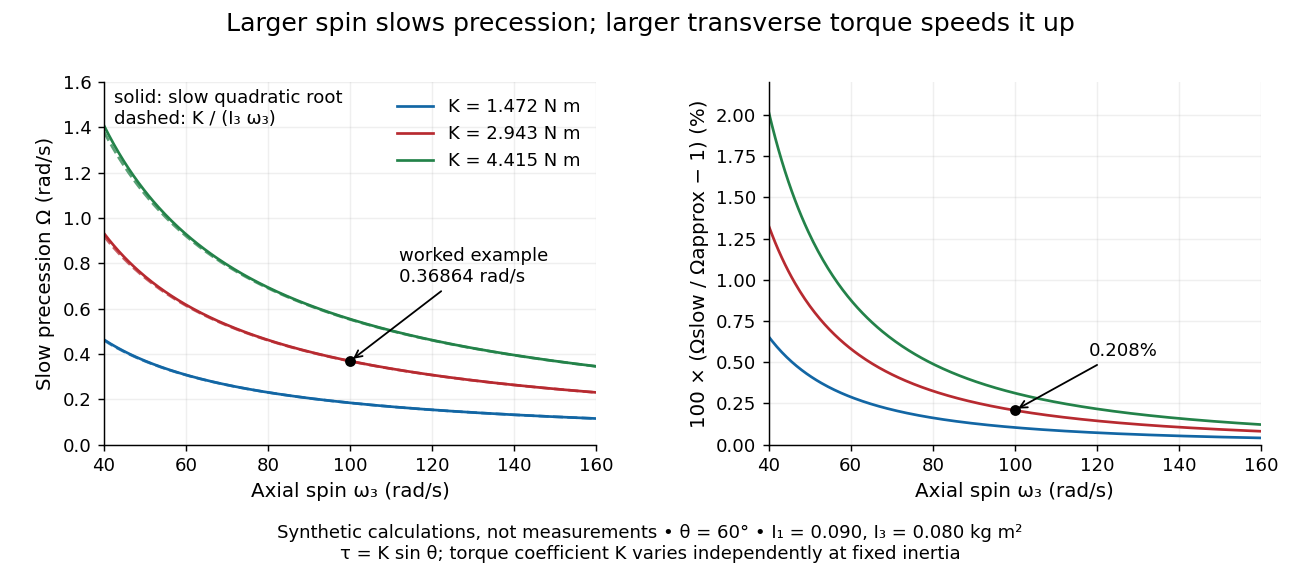
Synthetic steady-precession calculations: larger spin slows the drift and larger transverse torque speeds it up
. Details. The original curves hold fixed and vary spin and the imposed torque coefficient in . For gravity alone, ; the other curves are hypothetical changes in the transverse torque, not observations of this wheel. Solid curves use the slow quadratic root; dashed curves use . The second panel displays their relative difference. Increasing spin improves this approximation for the parameters shown. It does not remove nutation caused by inappropriate initial conditions.
Let a horizontal gyroscope have signed spin angular momentum along the axle. The disk's centre of mass is at and a counterweight is at . Gravity supplies torque . Since , steady horizontal precession gives the displayed signed vertical angular velocity. Neglect the axle's mass and the counterweight's axial spin moment of inertia. The zero-torque choice allows the axle to remain fixed. Moving the counterweight through this position reverses the gravitational torque and the associated slow precession.
For a rotor spinning about a principal axis with its support at the centre of mass, uniform gravity supplies no torque about that centre. With other external torques negligible, conservation of angular momentum preserves its direction in an inertial frame. A mount that permits free axis motion lets the housing rotate relative to that persistent direction, giving an orientation reference when external landmarks are unavailable. This is the useful limit opposite to the deliberately off-centre support in the spinning-wheel precession experiment. It supplies a direction, not a position or a full three-axis orientation from one axis alone.
For a small accumulated transverse torque about the centre of mass, the change in the direction unit vector is, to first order,Here is approximately constant over the short interval. Large angular momentum reduces drift for the same integrated transverse torque; parallel torque instead changes its magnitude. For , a constant transverse torque of over produces approximately , or , of direction change. This is another synthetic calculation. The persistent direction belongs to an inertial frame; its components can change in a rotating reference frame even with zero external torque.
A charged particle in a uniform field and an axially symmetric potential conserves the displayed canonical angular momentum, with the distance from the field axis and its charge. It follows directly by differentiating the expression and using the Lorentz force. For charge , the equivalent invariant is . A radial restoring force has no axial torque.
Consider particles of the same constant mass , interacting through equal-and-opposite central internal forces, with external forces for constant . About a fixed point , internal pair torques cancel and the external torque is . Hence and the displayed exponential decay follows. The same result holds for angular momentum about the centre of mass, because the moving-origin term vanishes. Unequal masses do not generally permit factoring out a single .
For a radial conservative force plus the magnetic-type force , the torque equals . Subtracting from ordinary angular momentum therefore produces a constant vector. Its dot product with is , so motion lies on a cone about that vector. At , ordinary planar central force motion is recovered. This is the classical radial magnetic monopole angular-momentum correction.
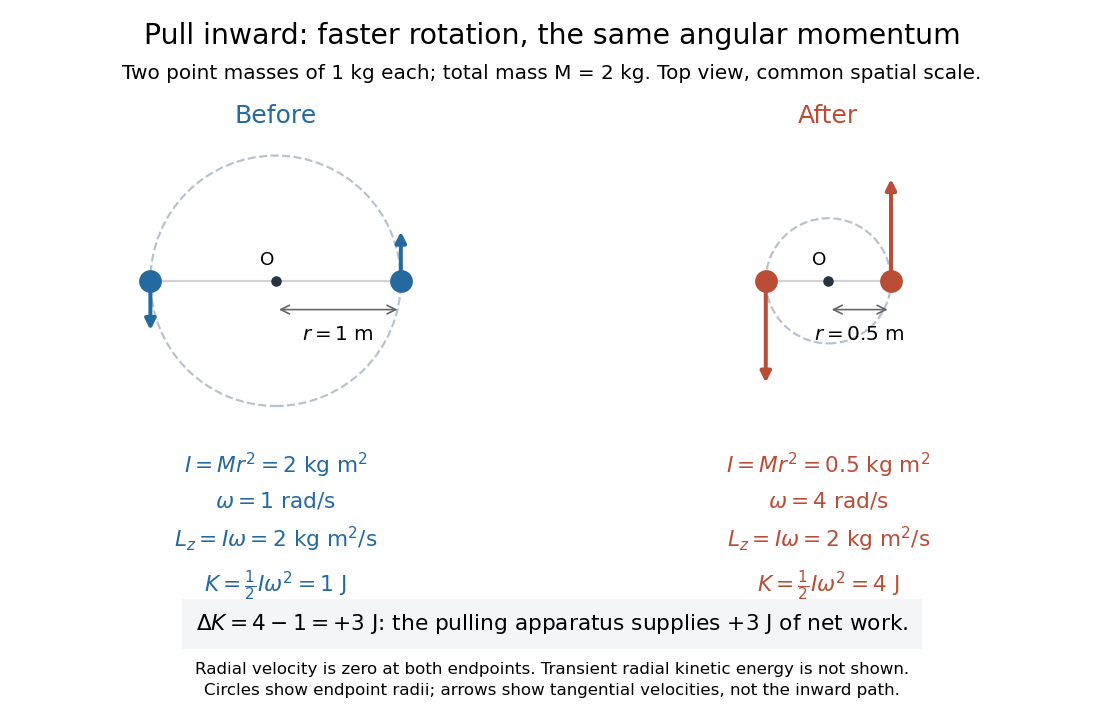
Conservation of angular momentum says that total angular momentum stays fixed when the net external torque about the chosen fixed inertial origin vanishes. Individual angular momenta and angular velocities can change. The radius change at constant angular momentum below makes this distinction visible: pulling two rotating point masses inward lowers the moment of inertia, raises the angular velocity, and supplies work that increases the kinetic energy.
Follow the same constant-mass point masses throughout, in an inertial frame, with all positions measured from a fixed origin . If the internal pair forces are opposite and central, meaning directed along each pair's separation, thenThus zero net external torque throughout an interval implies constant total angular momentum throughout that interval. A vanishing external torque component, such as , conserves the corresponding even when the other components change. This is the balance law for a fixed collection; angular-momentum flux must also be accounted for when matter crosses its boundary. [ref]
The central qualification is essential. Write for the internal force on member from member . Under Newton's third law, , but the sum of their torques isThis vanishes when is parallel to . Equal-and-opposite forces alone do not suffice: two opposite transverse forces with separated lines of action form a couple with nonzero torque. Cancellation of the internal pair torques, together with Newton's second law, proves the total balance above.
For one point mass under a central force about , gives . The force may still change the speed and kinetic energy; its zero torque preserves angular momentum. With nonzero , keeps the motion in a fixed plane. Choosing the axis perpendicular to that plane, governs its angular progress. This removes an unknown from the central-force radial turning point calculation and helps reduce the Kepler orbit to a radial problem.
There is a historical geometric version of this result. In Book I, Section II, Proposition I of the Principia, Newton proves that motion under a central force toward a fixed centre stays in a plane and sweeps equal areas in equal times, using successive central impulses and equal triangle areas. [ref]
https://en.wikisource.org/wiki/The_Mathematical_Principles_of_Natural_Philosophy_(1846)/BookI-II. Newton, Principia, Book I, Proposition I, Motte translation, 1846 edition
In the modern notation above, constant areal velocity is : the old geometric proof and the angular momentum calculation express the same invariant.For two equal point masses joined by a light tether of length , the central moment of inertia is . With conserved angular momentum , the rotational kinetic energy is . Slow, smooth contraction gives with the displayed leading tension. The exact radial correction is and , so the total work-energy theorem remains exact for non-quasi-static schedules too.
Place two equal point masses of each on opposite sides of a fixed origin, at equal radius , and let them share a signed angular velocity in a plane. Their total mass is and their moment of inertia about the perpendicular axis is . Radial pulling forces have zero torque about that origin, soTake an initial radius and angular velocity , and a final radius . ThenandThese are endpoint states with . During the pull, the full kinetic energy also contains radial motion: . Assume the pulling apparatus supplies all net work to the two point masses; the work-energy theorem then fixes its net work at , including any radial acceleration and braking. Each mass spirals inward during the pull, allowing its inward force to do positive work. Conservation of angular momentum therefore predicts the final angular velocity without requiring kinetic energy conservation. For an apparatus included in a larger system, its stored energy supplies the increase consistently with conservation of energy. OpenStax uses the same mechanism to explain a skater pulling her arms inward. [ref]
https://openstax.org/books/university-physics-volume-1/pages/11-3-conservation-of-angular-momentum. OpenStax, section 11.3: work during a change of moment of inertia
The rate at which angular momentum crosses a surface, including advection and stresses. With positive inward mass accretion rate, the net inward flux in a steady accretion disk is .
For unit mass in a central force with potential and conserved angular momentum , a radial turning point has zero radial speed and therefore satisfies
For unit mass, incoming speed , impact parameter , and potential energy , put . At closest approach, conservation of energy and conservation of angular momentum give the displayed radii and tangential speeds . Consequently and . These relations compare equal force magnitudes. The attractive radial case is a singular collision, so the speed-product statement does not extend to that endpoint.
Angular momentum transport moves angular momentum between locations through matter, stresses, waves, or fields. An accretion disk must transport angular momentum outward for most of its mass to move inward.
Torque measures a force's turning effect about a specified origin. The geometry in the angular momentum diagram applies with force replacing momentum: transverse forces give positive or negative torque, while a radial force gives zero. A longer perpendicular lever arm makes the same force more effective, explaining why pushing near the end of a handle is useful.
For a force applied at position from a fixed origin in an inertial frame, its torque, or moment of force, isHere , is the angle between position and force, and is the perpendicular lever arm. Direction follows the right-hand rule; in the plane , positive counterclockwise as viewed from . The International System of Units unit is . Although torque and energy have the same physical dimensions, torque is an axial vector and energy is a scalar; their roles differ.
For and , . Applying the same force at gives ; reversing it gives a negative torque; directing it along gives zero. More generally, sum to find the total torque about one common origin.
For a constant-mass point mass, the product rule and Newton's second law show why net torque changes angular momentum:The first cross product vanishes because its factors are parallel. For a collection with canceling internal torques, the remaining sum is external torque, giving conservation of angular momentum when it vanishes.[ref]
A nonzero torque can turn the direction of angular momentum as well as change its magnitude. Indeed, the dot product gives : a perpendicular torque changes direction without instantaneously changing the magnitude. This is the geometry behind gyroscope precession. For a rapidly spinning symmetric top with a fixed tip, centre of mass distance from the tip, mass , and spin-dominated angular momentum magnitude , the slow steady precession approximation gives , where is gravitational acceleration. [ref]
11.4 Precession of a Gyroscope. OpenStax University Physics Volume 1, section 11.4: Precession of a Gyroscope
This is an approximation with ; the uniform precession of a heavy symmetric top retains contributions omitted by the spin-dominated estimate.A rigid body's axial moment of inertia and a constant resisting torque give constant angular acceleration . Hence and the angular displacement is the displayed expression. Equivalently, the lost rotational kinetic energy equals the resisting work . The total number of revolutions is ; the number of whole revolutions completed is its floor function.
For positive angular velocity, a motor delivering constant mechanical power produces torque . With constant opposing kinetic friction torque , angular momentum balance gives the displayed equation and a steady speed . A small increase in speed reduces the driving torque below the friction torque, making this equilibrium stable within the model. The constant-power idealization is singular at exact rest and requires a separate starting regime in a real motor.
The time integral of torque about a specified origin equals the change in angular momentum about that origin under the usual fixed-origin inertial frame balance. Its units are , equivalently . For rotation about a fixed principal axis, the magnitude is .
The lever arm of a nonzero force about an origin is the shortest distance from that origin to the line through the application point parallel to the force. Its length is , with unit vector . Thus torque magnitude is , maximal at a right angle for fixed and , and zero if the line passes through the origin. Sliding the application point along that line leaves torque unchanged, since . The same perpendicular-distance construction gives angular momentum magnitude for a line parallel to nonzero momentum through the particle.
A pair of equal and opposite forces acting along distinct lines has zero resultant force but a nonzero torque. If acts at and at , the total torque about any origin is . Shifting that origin changes the moment by the cross product of the shift with the resultant force, which is zero. A prescribed couple therefore specifies a pure turning moment independently of its reference point. In Stokes flow it can drive a rotating sphere in Stokes flow without a directly imposed translational force.
Moment balance equates the rate of change of angular momentum to applied torques. A static slender rod obeys .
Areal velocity measures how fast a position vector from a chosen origin sweeps signed swept area. It connects a geometric picture of motion to angular momentum: a long position vector with slow transverse motion can sweep the same area per unit time as a short one with fast transverse motion. Constancy requires a dynamical condition, given by the torque criterion for constant areal velocity.
Choose a fixed origin in an inertial frame and a fixed plane through , with constant unit vector normal to it. For a differentiable trajectory in that plane, let be position relative to and its velocity. Positive swept area follows the right-hand rule about . In positively oriented Cartesian coordinates in the plane, and in plane polar coordinates with angle in radians,Here the dot product selects the normal component of the cross product. Motion away from or towards alone contributes no area. The signed specific angular momentum component obeysfor a constant mass . If is chosen along a nonzero conserved specific angular momentum vector, then and the familiar positive formula is . Reversing the orientation changes the sign; the instantaneous unsigned swept-area rate is .
Signed swept area counts the area traversed by a position vector, positively or negatively according to its direction of turning. For a continuously differentiable planar trajectory, its accumulated value relative to is the line integralA short segment contributes the oriented triangle area ; taking its time derivative gives areal velocity. Repeated turns count repeated area; a reversal subtracts it. Thus this quantity need not equal the area of the union of all previously swept regions. The origin matters: the relevant origin for Kepler's second law is the attracting focus of the ellipse, rather than its geometric centre.
Take an illustrative elliptic Kepler orbit with semi-major axis , orbital eccentricity and gravitational parameter , in consistent dimensionless units. Its semi-minor axis is , mean motion is , and specific angular momentum magnitude is . About the attracting focus,The two sectors below each span , giving . Near periapsis the short radius sweeps a wide angle; near apoapsis the long radius sweeps a narrow angle. Constant areal velocity therefore does not require constant angular velocity or constant speed.
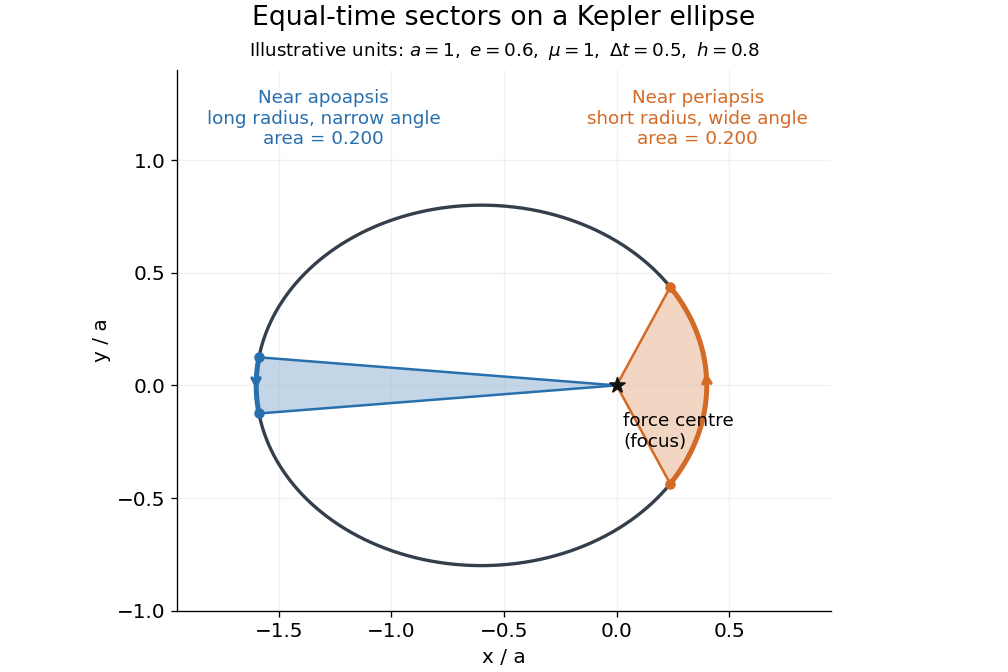
To compute the sectors without mistaking equal angles for equal times, parametrize the ellipse by eccentric anomaly :This follows by integrating . Kepler's equation gives , with mean anomaly measured from periapsis time . Consequently . The displayed sectors use mean anomaly intervals and , rather than equal eccentric anomaly increments.
Why infer an area law from astronomy? In the authored account The great Martian catastrophe and how Kepler fixed it by Owen Gingerich, a 13 August 1593 Mars observation has ecliptic longitude , against predicted and . These are Earth-based directions with a date, not measured Sun-based areas. The observer's armillary sphere used graduated circles and sighting arms to read declination; reversing it allowed a second reading. Comparing stars at different altitudes exposed refraction, and a planet-based check revealed an erroneous solar correction table. The apparent Mars distance signal had been contaminated by that correction. Johannes Kepler subsequently corrected the observer's Earth orbit, then tested Mars trajectories. The account describes typical angular errors of or less ( arcseconds): small residuals needed care.[ref]
The great Martian catastrophe and how Kepler fixed it by Owen Gingerich. pp. 51-53: Fig. 2, refraction checks, 13 August log table, Earth-orbit correction and angular errors
The Tufts class notes Kepler's Astronomia Nova and the Orbit of Mars explain the key limitation: an area requires a trajectory and distances, so Kepler's second law cannot be directly tested from angular observations alone. They describe checking the combined ellipse and area law against 28 dated observations around seven oppositions during 1583-1595, using an Earth model to predict Earth-based directions; agreement improved greatly but some discrepancies remained.[ref]
Kepler's Astronomia Nova and the Orbit of Mars. p. 20, items 3-5, and pp. 26-27, section IV.D: predictions, residuals and dependence of the area test on a trajectory
The inferential chain is useful today too: recover relative positions and times, compare swept areas, and ask what forces are compatible with their evolution. Agreement with equal areas supports zero torque about the chosen origin under the assumptions below; it alone does not identify an inverse-square law. Recovering the radial force also needs the trajectory and its timing, as in inferring an inverse-square force from Kepler laws. The two diagrams here are calculated examples, not the historical measurements.
An angular coordinate around the celestial sphere measured along the Earth's orbital reference plane. An Earth-based ecliptic longitude specifies a viewing direction; it does not by itself give a body's distance or its Sun-based position.
Assume a constant positive mass , a twice differentiable trajectory in the fixed plane, a fixed origin in an inertial frame, and Newton's second law for the net force. The product rule gives the short proofThe term vanishes. This is the planar angular momentum balance written in area language.[ref]
University Physics Volume 1. Section 11.2, equations 11.5-11.6: particle angular momentum and its torque balance
On a connected time interval, areal velocity is constant if and only if throughout. Since both position and acceleration lie in the fixed plane, the net torque has only that normal component. For , zero net torque is therefore equivalent to net force parallel to : its instantaneous direction is central, possibly inward, outward or zero. This diagnoses the net force along this motion, not its dependence on position or time elsewhere. Opposing transverse forces may cancel.
A central force about a fixed origin gives conservation of angular momentum, irrespective of its radial dependence: an inverse-square law is sufficient but unnecessary. With nonzero conserved angular momentum, fixes the orbital plane. Zero angular momentum gives radial motion and zero areal velocity; it does not select a unique orbital plane. The converse needs the fixed-plane assumption: a constant projected areal velocity in three dimensions only constrains one torque component. Also, makes the instantaneous torque vanish regardless of force and makes plane polar coordinates singular. A moving origin or changing plane requires additional terms.
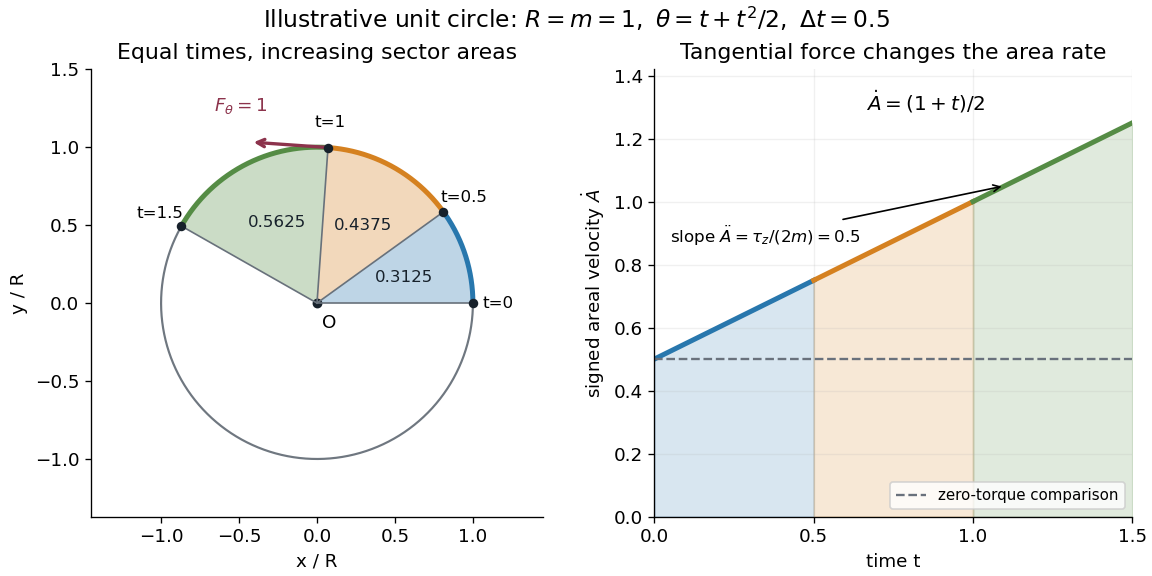
A path along a circle can have variable areal velocity. As an illustrative controlled trajectory, keep a point mass on a circle of radius with angleIts acceleration in polar coordinates and the required net force arewhere and are the radial and transverse unit vectors. A circular guide can supply the radial force, while a tangential drive supplies . HenceFor in illustrative units, the three equal time intervals , and sweep areas , and . Their difference comes from the transverse force's positive torque, even though the radius and path shape stay fixed. The area under each areal velocity graph segment equals the corresponding swept area.
Articles by others on the same topic

Angular momentum is a fundamental physical quantity that describes the rotational motion of an object. It is a measure of the amount of rotation an object has, taking into account its mass, shape, and rotational speed. Angular momentum is a vector quantity, meaning it has both a magnitude and a direction.



